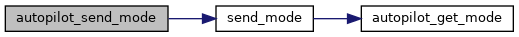|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Core autopilot interface common to all firmwares. More...
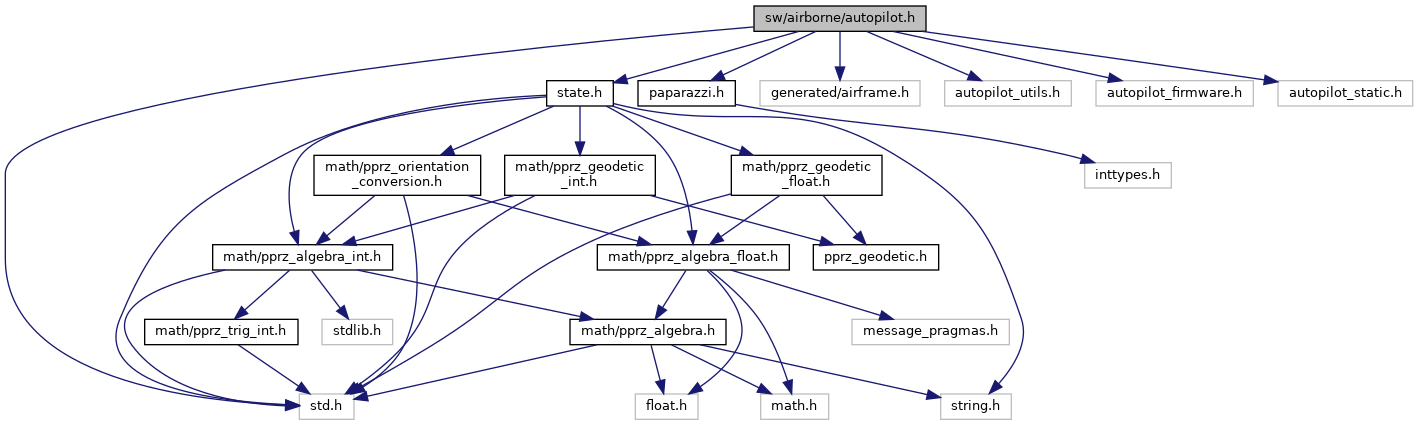
#include "std.h"#include "paparazzi.h"#include "generated/airframe.h"#include "state.h"#include "autopilot_utils.h"#include "autopilot_firmware.h"#include "autopilot_static.h"Go to the source code of this file.
Data Structures | |
| struct | pprz_autopilot |
| PPRZ Autopilot structure definition. More... | |
Macros | |
| #define | USE_GENERATED_AUTOPILOT FALSE |
| #define | autopilot_ResetFlightTimeAndLaunch(_) |
| #define | autopilot_KillThrottle(_kill) |
| #define | autopilot_StoreSettings(_) |
| #define | autopilot_ClearSettings(_) |
Functions | |
| void | autopilot_init (void) |
| Autopilot initialization function. | |
| void | autopilot_periodic (void) |
| Autopilot periodic call at PERIODIC_FREQUENCY. | |
| void | autopilot_event (void) |
| Autopilot event check function. | |
| void | autopilot_on_rc_frame (void) |
| Autopilot RC input event hadler. | |
| void | autopilot_failsafe_checks (void) |
| Autopilot periodic failsafe checks. | |
| bool | autopilot_set_mode (uint8_t new_autopilot_mode) |
| Set new autopilot mode. | |
| void | autopilot_SetModeHandler (float new_autopilot_mode) |
| Handler for setter function with dl_setting. | |
| uint8_t | autopilot_get_mode (void) |
| Get autopilot mode. | |
| void | autopilot_reset_flight_time (void) |
| Reset flight time and launch status Also provide macro for dl_setting backward compatibility. | |
| void | autopilot_force_motors_on (bool motors_on) |
| Force start/stop the motors WARNING This will skip he preflight checks. | |
| bool | autopilot_set_motors_on (bool motors_on) |
| Start or stop motors May have no effect if motors has auto-start based on throttle setpoint or when the preflight checks are failing. | |
| bool | autopilot_arming_motors_on (bool motors_on) |
| Start or stop the motors during arming May not happen when preflight checks are failing. | |
| bool | autopilot_get_motors_on (void) |
| Get motor status. | |
| void | autopilot_set_kill_throttle (bool kill) |
| Enable or disable motor control from autopilot Also provide macro for dl_setting backward compatibility. | |
| bool | autopilot_throttle_killed (void) |
| Get kill status. | |
| void | autopilot_check_in_flight (bool motors_on) |
| Check if airframe is in flight. | |
| void | autopilot_set_in_flight (bool in_flight) |
| Set in flight status. | |
| bool | autopilot_in_flight (void) |
| Get in flight status. | |
| void | autopilot_reset_in_flight_counter (void) |
| reset in_flight counter actual implementation is firmware dependent | |
| void | autopilot_store_settings (void) |
| Store marked settings in flash Try to make sure that we don't write to flash while flying Also provide macro for dl_setting backward compatibility. | |
| void | autopilot_clear_settings (void) |
| Clear marked settings in flash try to make sure that we don't write to flash while flying Also provide macro for dl_setting backward compatibility. | |
| void | autopilot_send_version (void) |
| Report autopilot version on default downlink channel. | |
| void | autopilot_send_mode (void) |
| Report autopilot mode on default downlink channel. | |
Variables | |
| struct pprz_autopilot | autopilot |
| Global autopilot structure. | |
Core autopilot interface common to all firmwares.
Using either static or generated autopilot logic, which depends on the firmware.
Definition in file autopilot.h.
| struct pprz_autopilot |
PPRZ Autopilot structure definition.
Definition at line 62 of file autopilot.h.
| Data Fields | ||
|---|---|---|
| uint8_t | arming_status | arming status |
| bool | detect_ground_once | enable automatic detection of ground (one shot) |
| uint16_t | flight_time | flight time in seconds |
| bool | ground_detected | automatic detection of landing |
| bool | in_flight | in flight status |
| bool | kill_throttle | allow autopilot to use throttle |
| bool | launch | request launch |
| uint8_t | mode | current autopilot mode |
| uint8_t | mode_auto2 | FIXME hide this in a private part ? |
| bool | motors_on | motor status |
| pprz_t | throttle | throttle level as will be displayed in GCS |
| bool | use_rc | enable/disable RC input |
| #define autopilot_ClearSettings | ( | _ | ) |
Definition at line 204 of file autopilot.h.
| #define autopilot_KillThrottle | ( | _kill | ) |
Definition at line 161 of file autopilot.h.
| #define autopilot_ResetFlightTimeAndLaunch | ( | _ | ) |
Definition at line 123 of file autopilot.h.
| #define autopilot_StoreSettings | ( | _ | ) |
Definition at line 197 of file autopilot.h.
| #define USE_GENERATED_AUTOPILOT FALSE |
Definition at line 51 of file autopilot.h.
|
extern |
Start or stop the motors during arming May not happen when preflight checks are failing.
Start or stop the motors during arming May not happen when preflight checks are failing.
Definition at line 281 of file autopilot.c.
References autopilot, preflight_bypass, and preflight_check().
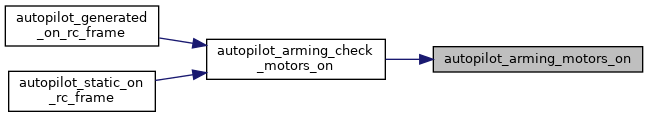
Referenced by autopilot_arming_check_motors_on(), autopilot_arming_check_motors_on(), and autopilot_arming_check_motors_on().
|
extern |
Check if airframe is in flight.
| [in] | motors_on | motors status |
Check if airframe is in flight.
Definition at line 332 of file autopilot.c.
References autopilot, autopilot_in_flight_counter, autopilot_in_flight_end_detection(), AUTOPILOT_IN_FLIGHT_MIN_THRUST, AUTOPILOT_IN_FLIGHT_TIME, and stabilization.
Referenced by autopilot_periodic().
|
extern |
Clear marked settings in flash try to make sure that we don't write to flash while flying Also provide macro for dl_setting backward compatibility.
Clear marked settings in flash try to make sure that we don't write to flash while flying Also provide macro for dl_setting backward compatibility.
Definition at line 368 of file autopilot.c.
References autopilot, settings_clear(), and settings_clear_flag.
|
extern |
Autopilot event check function.
Autopilot event check function.
Autopilot event check function.
used for automatic ground detection
Definition at line 181 of file autopilot.c.
References AP_MODE_FAILSAFE, autopilot, and autopilot_ground_detection().
|
extern |
Autopilot periodic failsafe checks.
Autopilot periodic failsafe checks.
Autopilot periodic failsafe checks.
Checks order:
send mode if changed at the end
Definition at line 196 of file autopilot.c.
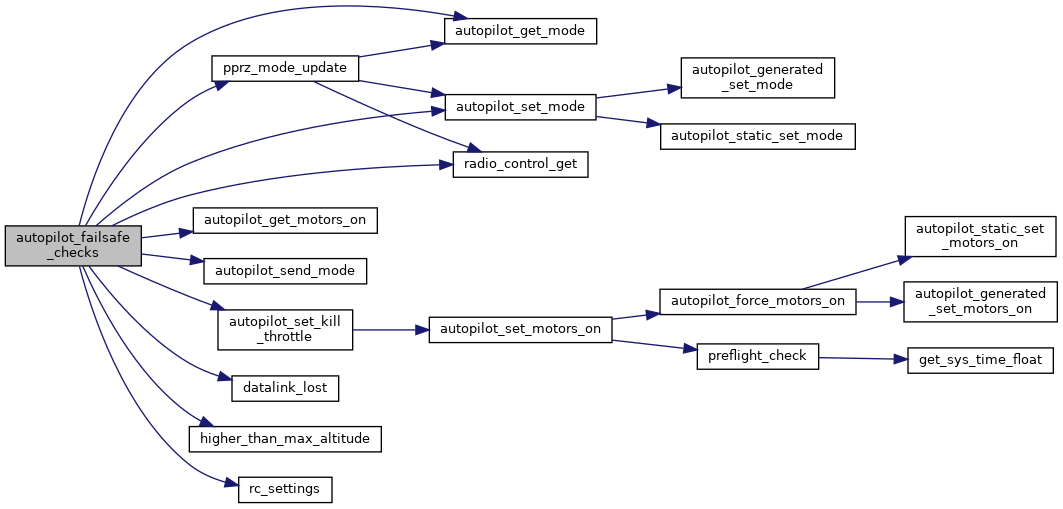
References AP_MODE_AUTO1, AP_MODE_AUTO2, AP_MODE_FAILSAFE, AP_MODE_GPS_OUT_OF_ORDER, AP_MODE_GUIDED, AP_MODE_HOME, AP_MODE_KILL, AP_MODE_MANUAL, AP_MODE_NAV, autopilot, autopilot_get_mode(), autopilot_get_motors_on(), autopilot_set_kill_throttle(), autopilot_set_mode(), datalink_lost(), datalink_time, electrical, gps, GpsIsLost, higher_than_max_altitude(), MIN_PPRZ, sys_time::nb_sec, pprz_mode_update(), radio_control, radio_control_get(), RADIO_KILL_SWITCH, RADIO_THROTTLE, RadioControlIsLost, RC_LOST_MODE, RC_OK, RC_REALLY_LOST, rc_settings(), THROTTLE_THRESHOLD_TAKEOFF, and too_far_from_home.
Referenced by autopilot_periodic(), and main_ap_init().
|
extern |
Force start/stop the motors WARNING This will skip he preflight checks.
| motors_on | Wheter the motors should be forced on/off |
Force start/stop the motors WARNING This will skip he preflight checks.
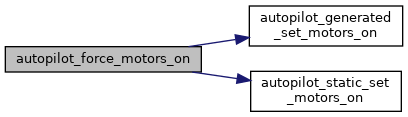
Definition at line 244 of file autopilot.c.
References autopilot, autopilot_generated_set_motors_on(), and autopilot_static_set_motors_on().
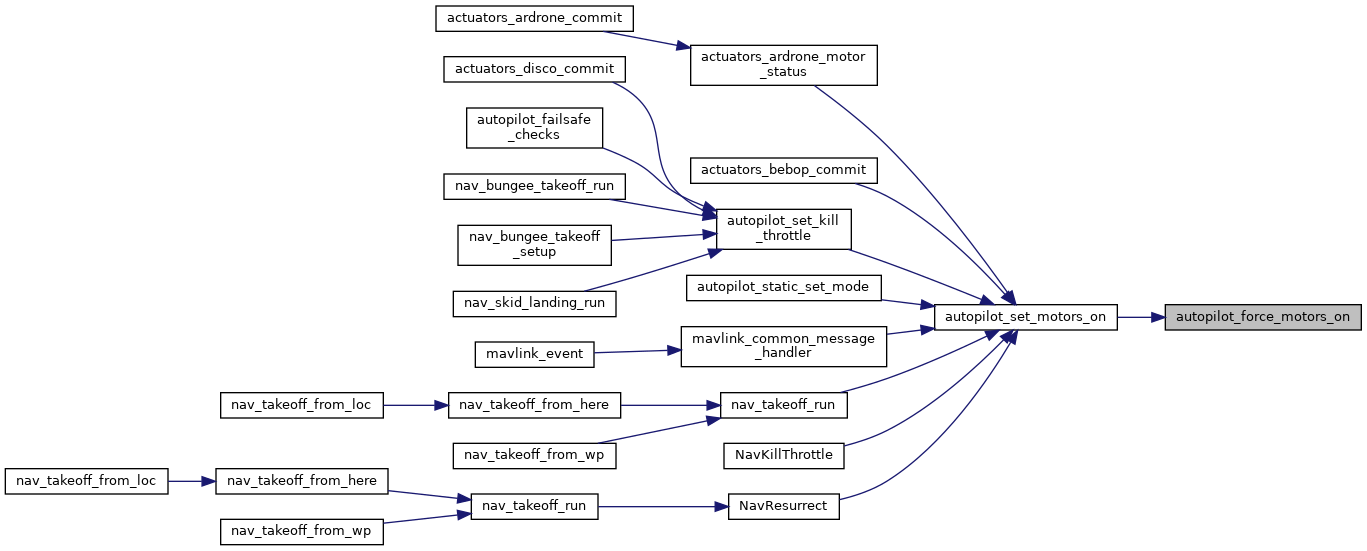
Referenced by autopilot_set_motors_on().
|
extern |
Get autopilot mode.
Get autopilot mode.
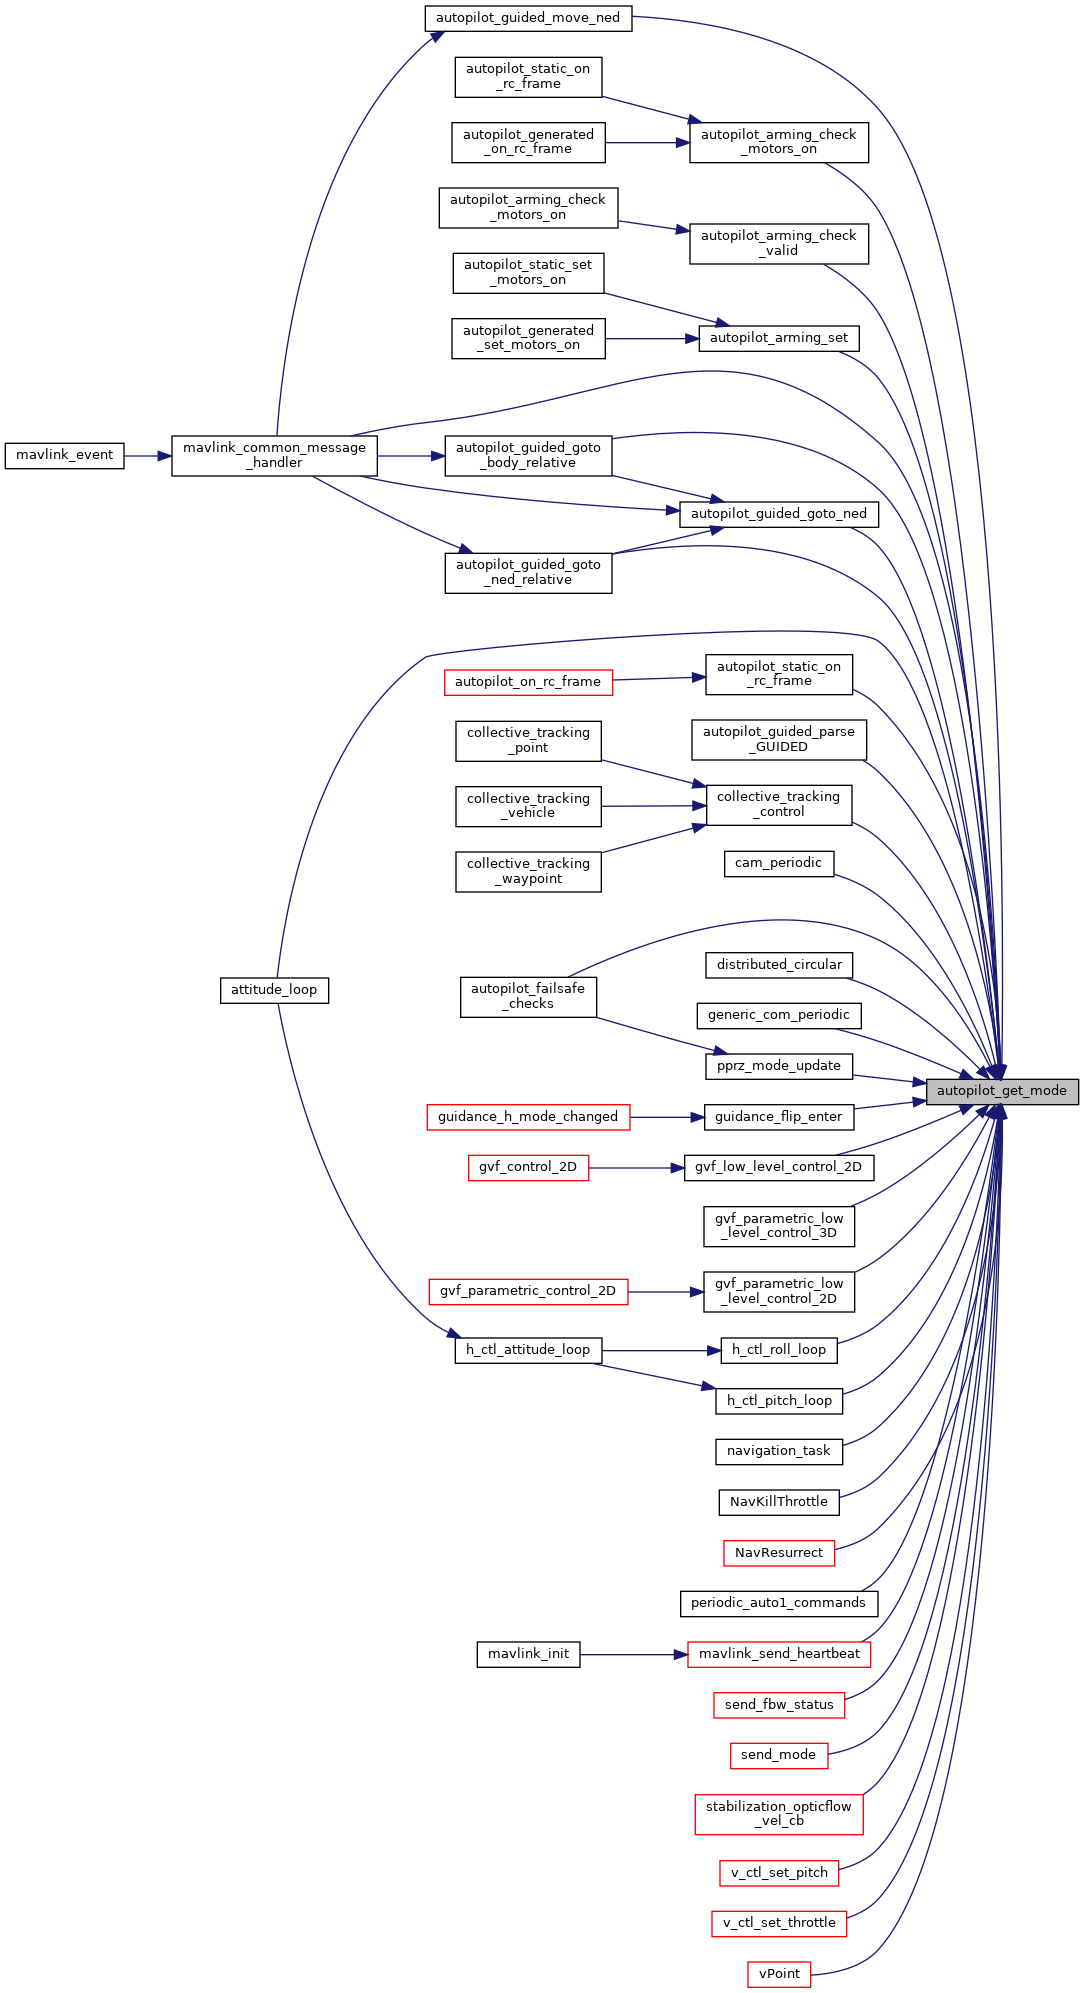
Definition at line 229 of file autopilot.c.
References autopilot.
Referenced by attitude_loop(), autopilot_arming_check_motors_on(), autopilot_arming_check_motors_on(), autopilot_arming_check_motors_on(), autopilot_arming_check_valid(), autopilot_arming_set(), autopilot_failsafe_checks(), autopilot_static_on_rc_frame(), collective_tracking_control(), distributed_circular(), generic_com_periodic(), guidance_flip_enter(), gvf_low_level_control_2D(), gvf_low_level_control_3D(), h_ctl_pitch_loop(), h_ctl_roll_loop(), mavlink_common_message_handler(), mavlink_send_heartbeat(), navigation_task(), NavKillThrottle(), NavResurrect(), periodic_auto1_commands(), pprz_mode_update(), send_fbw_status(), send_mode(), takeoff_detect_periodic(), v_ctl_set_pitch(), v_ctl_set_throttle(), and wedgebug_periodic().
|
extern |
Get motor status.
Get motor status.
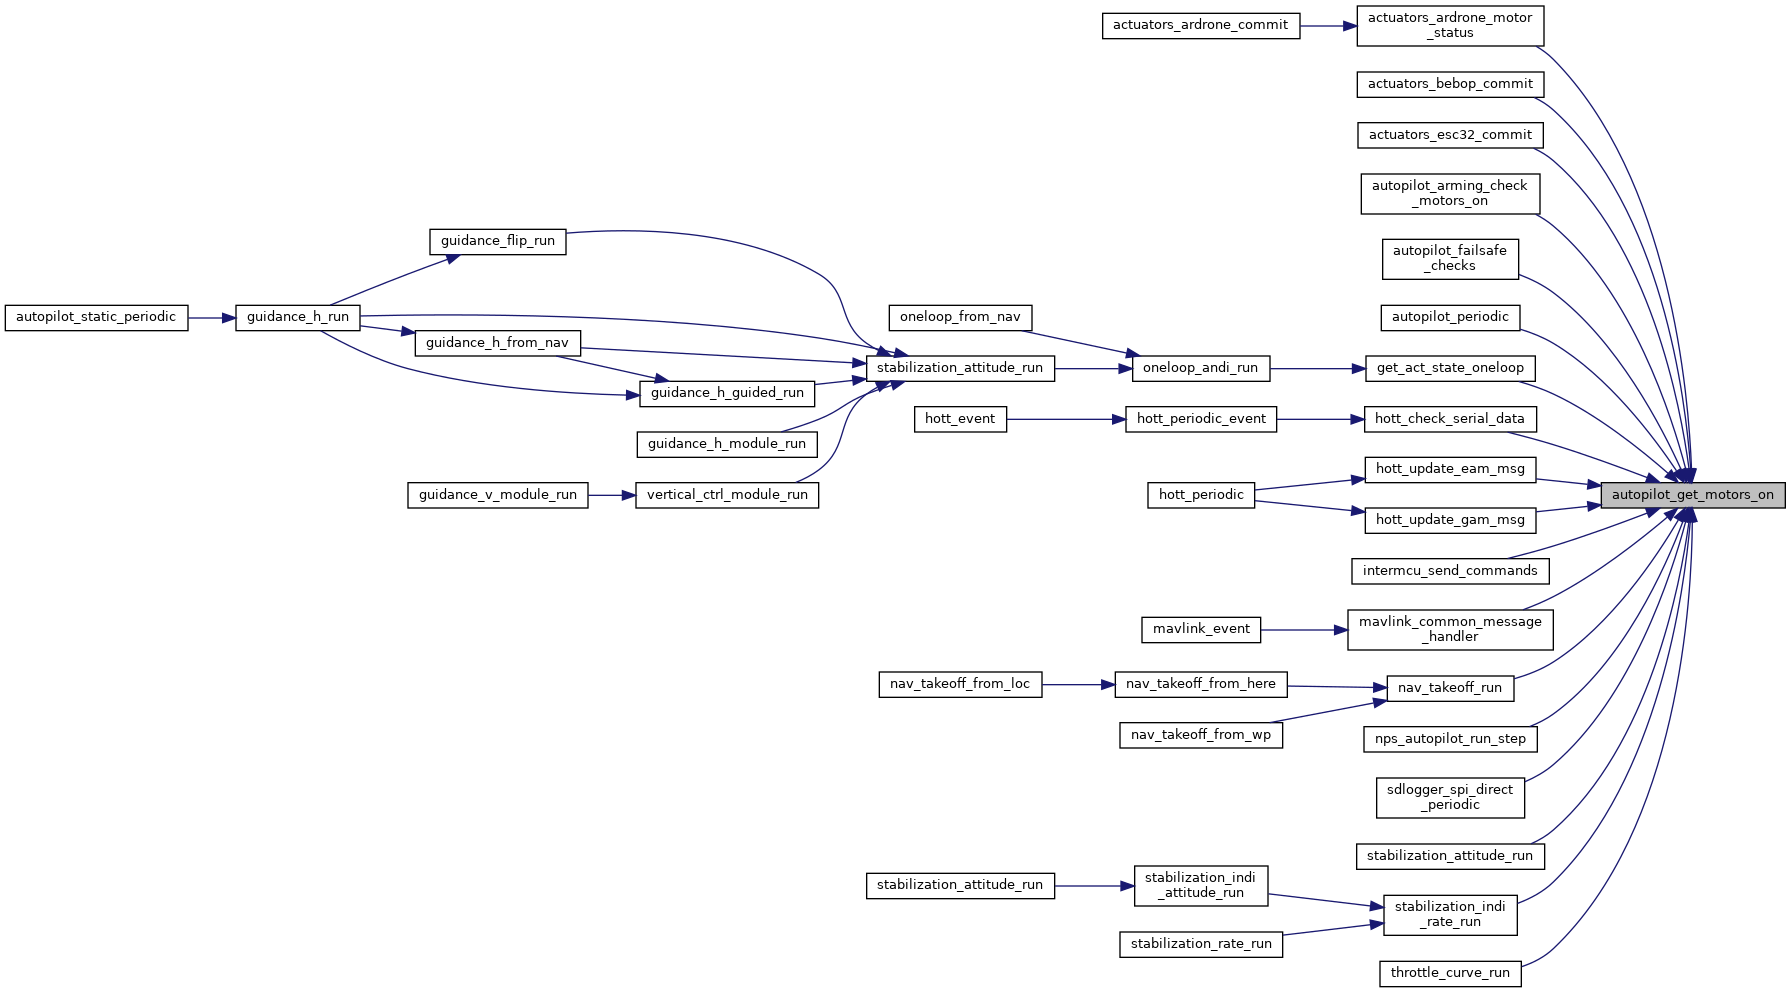
Definition at line 303 of file autopilot.c.
References autopilot.
Referenced by actuators_bebop_commit(), air_data_start_calibration(), autopilot_arming_check_motors_on(), autopilot_failsafe_checks(), autopilot_periodic(), control_mixing_heewing_attitude_direct(), control_mixing_heewing_nav_run(), event_update(), get_act_state_oneloop(), hott_check_serial_data(), hott_update_eam_msg(), hott_update_gam_msg(), ins_ekf2_update_system_flags(), intermcu_send_commands(), mavlink_common_message_handler(), nav_takeoff_run(), nav_takeoff_run(), nps_autopilot_run_step(), stabilization_attitude_run(), stabilization_indi_rate_run(), and throttle_curve_run().
|
extern |
Get in flight status.
Get in flight status.
Definition at line 351 of file autopilot.c.
References autopilot.
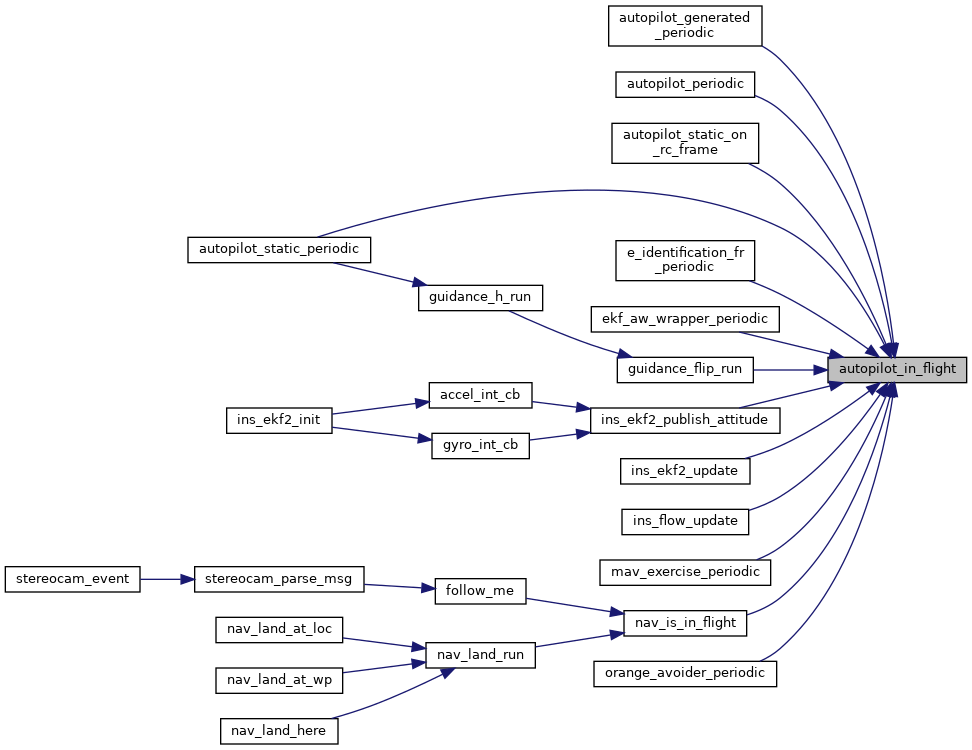
Referenced by autopilot_generated_periodic(), autopilot_periodic(), autopilot_static_periodic(), control_mixing_heewing_attitude_direct(), control_mixing_heewing_attitude_plane(), control_mixing_heewing_nav_run(), e_identification_fr_periodic(), ekf_aw_wrapper_periodic(), guidance_flip_run(), guidance_module_enter(), guidance_module_run(), ins_ekf2_update_system_flags(), ins_flow_update(), mav_exercise_periodic(), mavlink_send_extended_sys_state(), nav_is_in_flight(), orange_avoider_periodic(), rc_cb(), rc_cb(), stabilization_indi_attitude_controller(), and stabilization_indi_rate_controller().
|
extern |
Autopilot initialization function.
Definition at line 114 of file autopilot.c.
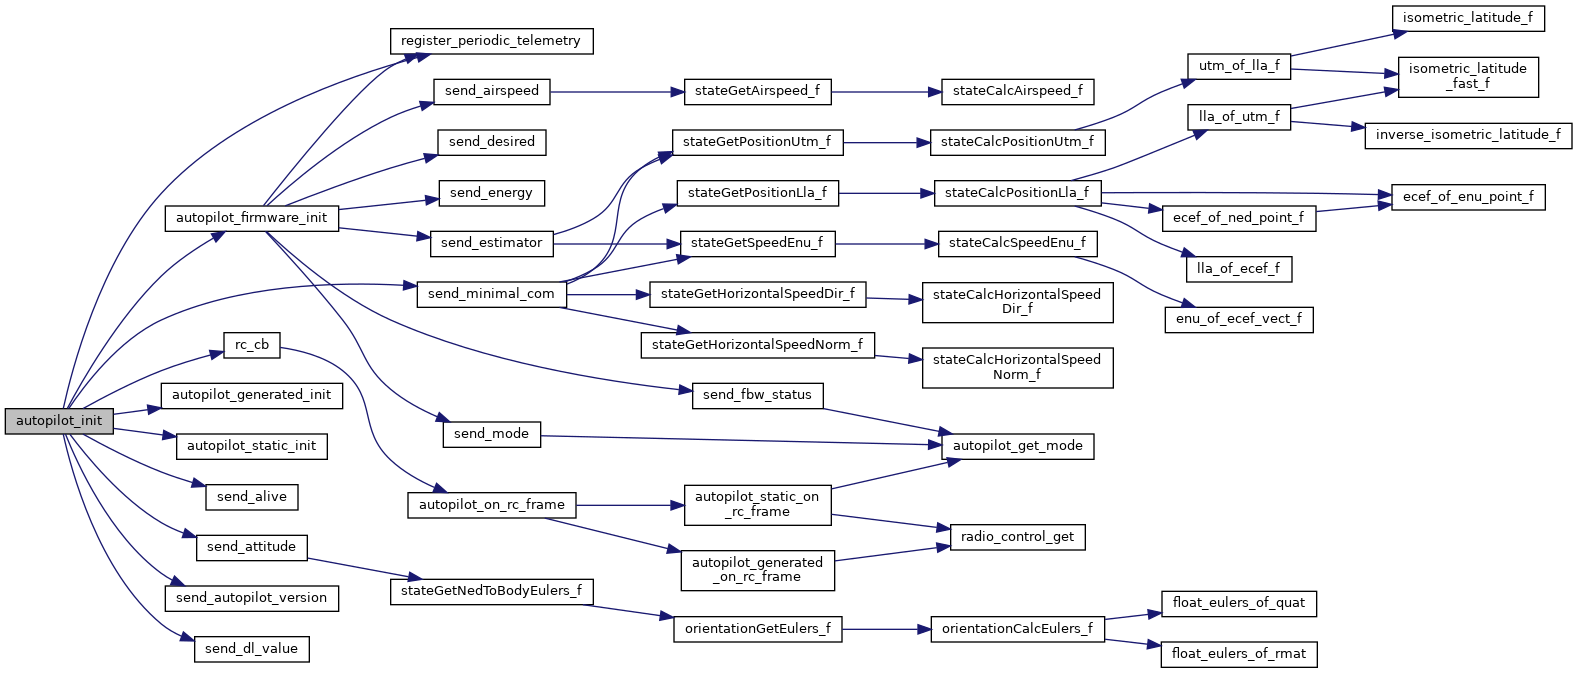
References autopilot, autopilot_firmware_init(), autopilot_generated_init(), AUTOPILOT_RC_ID, autopilot_static_init(), DefaultPeriodic, MODE_AUTO2, rc_cb(), rc_ev, register_periodic_telemetry(), send_alive(), send_attitude(), send_autopilot_version(), send_dl_value(), and send_minimal_com().
|
extern |
Autopilot RC input event hadler.
Autopilot RC input event hadler.
Definition at line 185 of file autopilot.c.
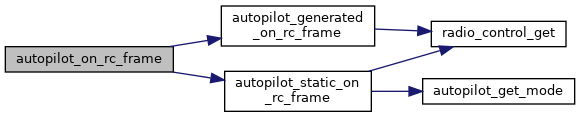
References autopilot_generated_on_rc_frame(), and autopilot_static_on_rc_frame().
Referenced by rc_cb().
|
extern |
Autopilot periodic call at PERIODIC_FREQUENCY.
Autopilot periodic call at PERIODIC_FREQUENCY.
Definition at line 153 of file autopilot.c.
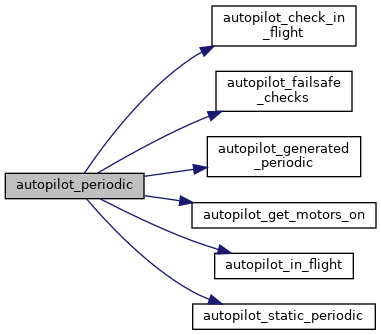
References autopilot, autopilot_check_in_flight(), autopilot_failsafe_checks(), autopilot_generated_periodic(), autopilot_get_motors_on(), autopilot_in_flight(), and autopilot_static_periodic().
|
extern |
Reset flight time and launch status Also provide macro for dl_setting backward compatibility.
Reset flight time and launch status Also provide macro for dl_setting backward compatibility.
Definition at line 236 of file autopilot.c.
References autopilot.
|
extern |
reset in_flight counter actual implementation is firmware dependent
reset in_flight counter actual implementation is firmware dependent
Definition at line 337 of file autopilot.c.
References autopilot_in_flight_counter.
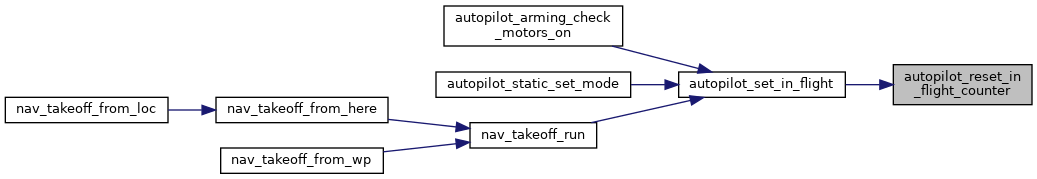
Referenced by autopilot_set_in_flight().
|
extern |
Report autopilot mode on default downlink channel.
Report autopilot mode on default downlink channel.
Definition at line 386 of file autopilot.c.
References DefaultChannel, DefaultDevice, send_mode(), and send_status().
Referenced by autopilot_set_mode().
|
extern |
Report autopilot version on default downlink channel.
Report autopilot version on default downlink channel.
Definition at line 378 of file autopilot.c.
References DefaultChannel, DefaultDevice, and send_autopilot_version().
Referenced by telemetry_reporting_task().
|
extern |
Set in flight status.
| [in] | in_flight | in flight status |
Set in flight status.
Definition at line 341 of file autopilot.c.
References autopilot, and autopilot_reset_in_flight_counter().
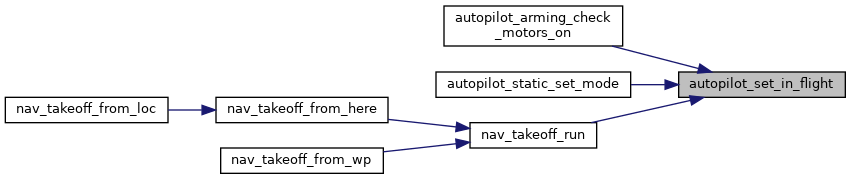
Referenced by autopilot_arming_check_motors_on(), autopilot_static_set_mode(), and nav_takeoff_run().
|
extern |
Enable or disable motor control from autopilot Also provide macro for dl_setting backward compatibility.
| [in] | kill | true to disable (kill), false to enable (un-kill) |
Enable or disable motor control from autopilot Also provide macro for dl_setting backward compatibility.
Resurrect only clears the kill when the motors may run (preflight checks, KILL mode).
Definition at line 312 of file autopilot.c.
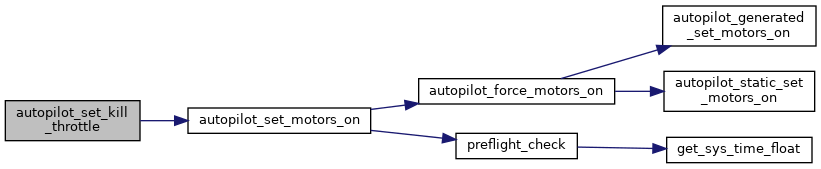
References autopilot, and autopilot_set_motors_on().
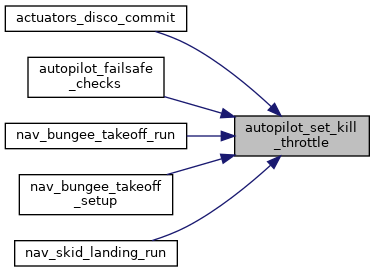
Referenced by actuators_disco_commit(), autopilot_failsafe_checks(), nav_bungee_takeoff_run(), nav_bungee_takeoff_setup(), and nav_skid_landing_run().
|
extern |
Set new autopilot mode.
| [in] | new_autopilot_mode | new mode to set |
Set new autopilot mode.
Definition at line 200 of file autopilot.c.
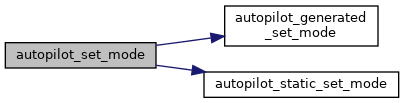
References autopilot, autopilot_generated_set_mode(), autopilot_send_mode(), autopilot_static_set_mode(), and mode.
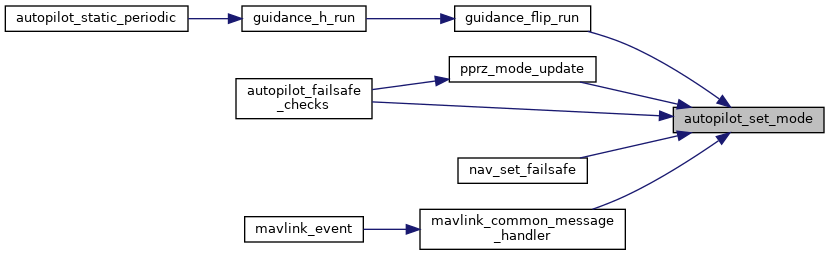
Referenced by autopilot_failsafe_checks(), guidance_flip_run(), guidance_module_run(), mavlink_common_message_handler(), nav_set_failsafe(), and pprz_mode_update().
|
extern |
Start or stop motors May have no effect if motors has auto-start based on throttle setpoint or when the preflight checks are failing.
| [in] | motors_on | true to start motors, false to stop |
Start or stop motors May have no effect if motors has auto-start based on throttle setpoint or when the preflight checks are failing.
Definition at line 258 of file autopilot.c.
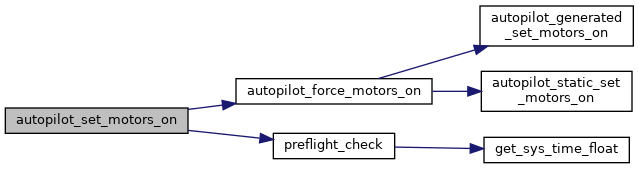
References autopilot, autopilot_force_motors_on(), preflight_bypass, and preflight_check().
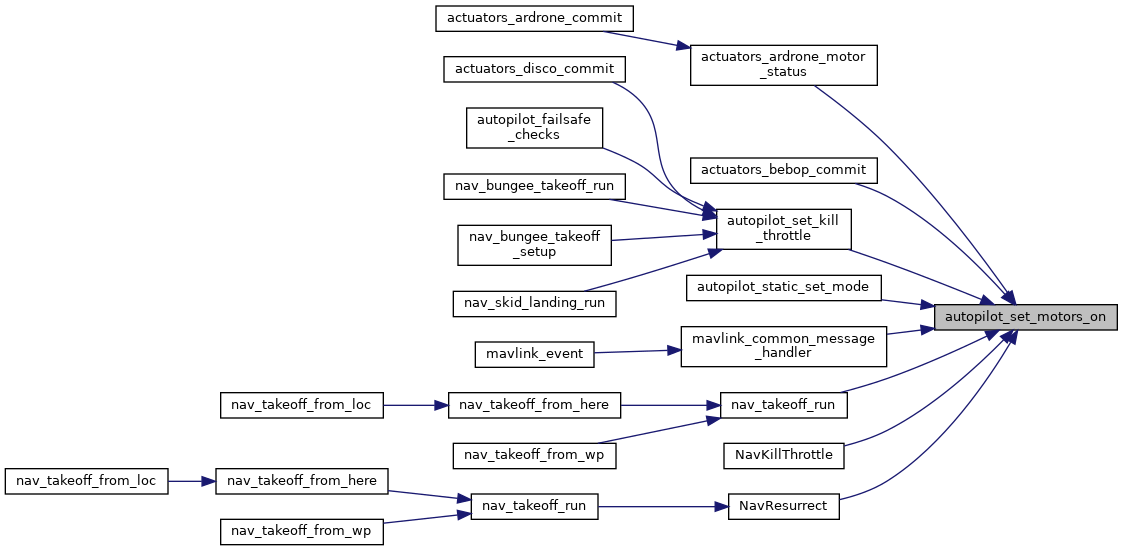
Referenced by actuators_bebop_commit(), autopilot_set_kill_throttle(), autopilot_static_set_mode(), ground_detect_periodic(), mavlink_common_message_handler(), nav_takeoff_run(), NavKillThrottle(), and NavResurrect().
|
extern |
Handler for setter function with dl_setting.
Handler for setter function with dl_setting.
Definition at line 218 of file autopilot.c.
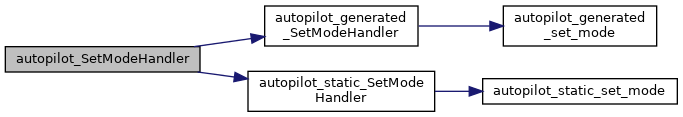
References autopilot_generated_SetModeHandler(), autopilot_static_SetModeHandler(), and mode.
|
extern |
Store marked settings in flash Try to make sure that we don't write to flash while flying Also provide macro for dl_setting backward compatibility.
Store marked settings in flash Try to make sure that we don't write to flash while flying Also provide macro for dl_setting backward compatibility.
Definition at line 358 of file autopilot.c.
References autopilot, settings_store(), and settings_store_flag.
|
extern |
Get kill status.
Get kill status.
Definition at line 324 of file autopilot.c.
References autopilot.
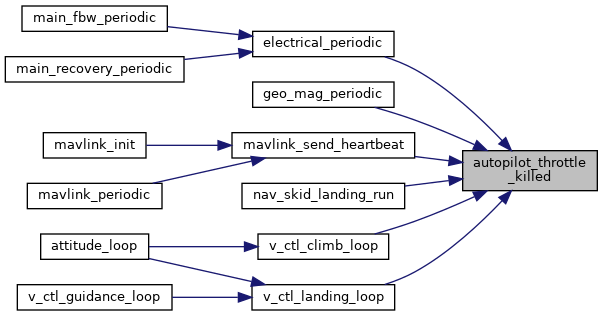
Referenced by electrical_periodic(), geo_mag_periodic(), mavlink_send_heartbeat(), nav_skid_landing_run(), v_ctl_climb_loop(), and v_ctl_landing_loop().
|
extern |
Global autopilot structure.
Definition at line 50 of file autopilot.c.
Referenced by attitude_loop(), autopilot_arming_check_motors_on(), autopilot_arming_check_motors_on(), autopilot_arming_check_valid(), autopilot_arming_check_valid(), autopilot_arming_motors_on(), autopilot_check_in_flight(), autopilot_clear_settings(), autopilot_event(), autopilot_failsafe_checks(), autopilot_force_motors_on(), autopilot_generated_init(), autopilot_generated_on_rc_frame(), autopilot_generated_periodic(), autopilot_generated_set_mode(), autopilot_generated_set_motors_on(), autopilot_get_mode(), autopilot_get_motors_on(), autopilot_in_flight(), autopilot_init(), autopilot_periodic(), autopilot_reset_flight_time(), autopilot_set_in_flight(), autopilot_set_kill_throttle(), autopilot_set_mode(), autopilot_set_motors_on(), autopilot_static_init(), autopilot_static_on_rc_frame(), autopilot_static_periodic(), autopilot_static_set_mode(), autopilot_static_set_motors_on(), autopilot_store_settings(), autopilot_throttle_killed(), calc_flight_time_left(), check_parachute_arming(), check_parachute_trigger(), control_mixing_heewing_attitude_direct(), control_mixing_heewing_attitude_plane(), control_mixing_heewing_manual(), control_mixing_heewing_nav_run(), draw_osd(), Drift_correction(), e_identification_fr_periodic(), gazebo_write(), gazebo_write(), generic_com_periodic(), gsm_send_report_continue(), h_ctl_course_loop(), h_ctl_pitch_loop(), h_ctl_roll_loop(), main_recovery_init(), mf_daq_send_state(), monitor_task(), nav_bungee_takeoff_run(), nav_catapult_highrate_module(), nav_check_wp_time(), nav_check_wp_time(), nav_detect_ground(), nav_home(), nav_takeoff_run(), nps_autopilot_run_step(), oneloop_andi_run(), oneloop_nB_run(), parse_mf_daq_msg(), rotwing_state_choose_state_by_dist(), rotwing_state_periodic(), send_energy(), send_fp(), send_minimal_com(), send_mode(), send_status(), takeoff_detect_periodic(), uav_recovery_periodic(), v_ctl_climb_loop(), v_ctl_guidance_loop(), v_ctl_set_pitch(), and v_ctl_set_throttle().
 1.15.0