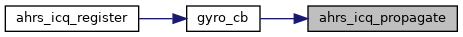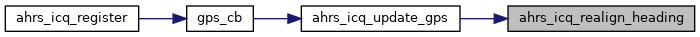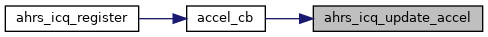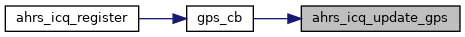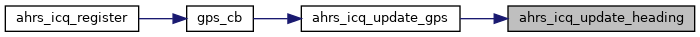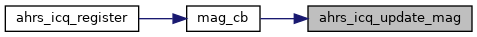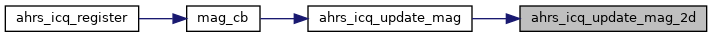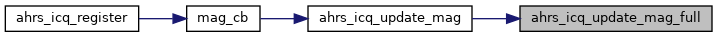|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Quaternion complementary filter (fixed-point). More...
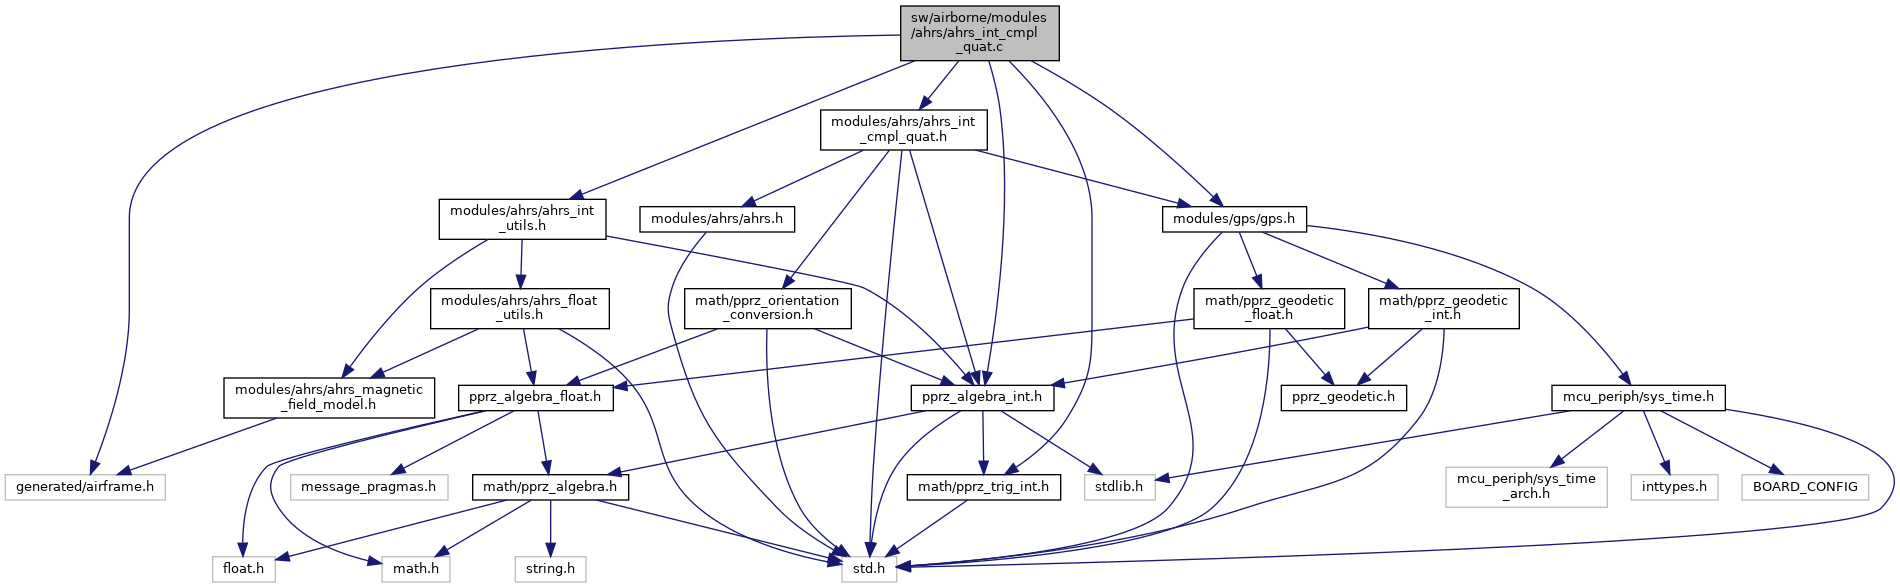
#include "generated/airframe.h"#include "modules/ahrs/ahrs_int_cmpl_quat.h"#include "modules/ahrs/ahrs_int_utils.h"#include "modules/gps/gps.h"#include "math/pprz_trig_int.h"#include "math/pprz_algebra_int.h"Go to the source code of this file.
Macros | |
| #define | AHRS_ACCEL_OMEGA 0.063 |
| #define | AHRS_ACCEL_ZETA 0.9 |
| #define | AHRS_MAG_OMEGA 0.04 |
| #define | AHRS_MAG_ZETA 0.9 |
| #define | AHRS_GRAVITY_HEURISTIC_FACTOR 30 |
| by default use the gravity heuristic to reduce gain | |
| #define | AHRS_BIAS_UPDATE_HEADING_THRESHOLD 5.0 |
| don't update gyro bias if heading deviation is above this threshold in degrees | |
| #define | AHRS_HEADING_UPDATE_GPS_MIN_SPEED 5.0 |
| Minimum speed in m/s for heading update via GPS. | |
| #define | COMPUTATION_FRAC 16 |
| #define | ACC_FROM_CROSS_FRAC INT32_RATE_FRAC + INT32_SPEED_FRAC - INT32_ACCEL_FRAC - COMPUTATION_FRAC |
| #define | FIR_FILTER_SIZE 8 |
Functions | |
| static void UNUSED | ahrs_icq_update_mag_full (struct Int32Vect3 *mag, float dt) |
| static void | ahrs_icq_update_mag_2d (struct Int32Vect3 *mag, float dt) |
| void | ahrs_icq_init (void) |
| bool | ahrs_icq_align (struct Int32Rates *lp_gyro, struct Int32Vect3 *lp_accel, struct Int32Vect3 *lp_mag) |
| void | ahrs_icq_propagate (struct Int32Rates *gyro, float dt) |
| void | ahrs_icq_set_accel_gains (void) |
| update pre-computed inv_kp and inv_ki gains from acc_omega and acc_zeta | |
| void | ahrs_icq_update_accel (struct Int32Vect3 *accel, float dt) |
| void | ahrs_icq_update_mag (struct Int32Vect3 *mag, float dt) |
| void | ahrs_icq_set_mag_gains (void) |
| update pre-computed kp and ki gains from mag_omega and mag_zeta | |
| void | ahrs_icq_update_gps (struct GpsState *gps_s) |
| void | ahrs_icq_update_heading (int32_t heading) |
| Update yaw based on a heading measurement. | |
| void | ahrs_icq_realign_heading (int32_t heading) |
| Hard reset yaw to a heading. | |
Variables | |
| struct AhrsIntCmplQuat | ahrs_icq |
| Default Rate filter Low pass. | |
Quaternion complementary filter (fixed-point).
Estimate the attitude, heading and gyro bias.
Definition in file ahrs_int_cmpl_quat.c.
| #define ACC_FROM_CROSS_FRAC INT32_RATE_FRAC + INT32_SPEED_FRAC - INT32_ACCEL_FRAC - COMPUTATION_FRAC |
Referenced by ahrs_icq_update_accel().
| #define AHRS_ACCEL_OMEGA 0.063 |
Definition at line 66 of file ahrs_int_cmpl_quat.c.
| #define AHRS_ACCEL_ZETA 0.9 |
Definition at line 69 of file ahrs_int_cmpl_quat.c.
| #define AHRS_BIAS_UPDATE_HEADING_THRESHOLD 5.0 |
don't update gyro bias if heading deviation is above this threshold in degrees
Definition at line 93 of file ahrs_int_cmpl_quat.c.
Referenced by ahrs_icq_update_heading().
| #define AHRS_GRAVITY_HEURISTIC_FACTOR 30 |
by default use the gravity heuristic to reduce gain
Definition at line 88 of file ahrs_int_cmpl_quat.c.
| #define AHRS_HEADING_UPDATE_GPS_MIN_SPEED 5.0 |
Minimum speed in m/s for heading update via GPS.
Don't update heading from GPS course if GPS ground speed is below is this threshold
Definition at line 100 of file ahrs_int_cmpl_quat.c.
Referenced by ahrs_icq_update_gps().
| #define AHRS_MAG_OMEGA 0.04 |
Definition at line 76 of file ahrs_int_cmpl_quat.c.
| #define AHRS_MAG_ZETA 0.9 |
Definition at line 79 of file ahrs_int_cmpl_quat.c.
| #define COMPUTATION_FRAC 16 |
Referenced by ahrs_icq_update_accel().
| #define FIR_FILTER_SIZE 8 |
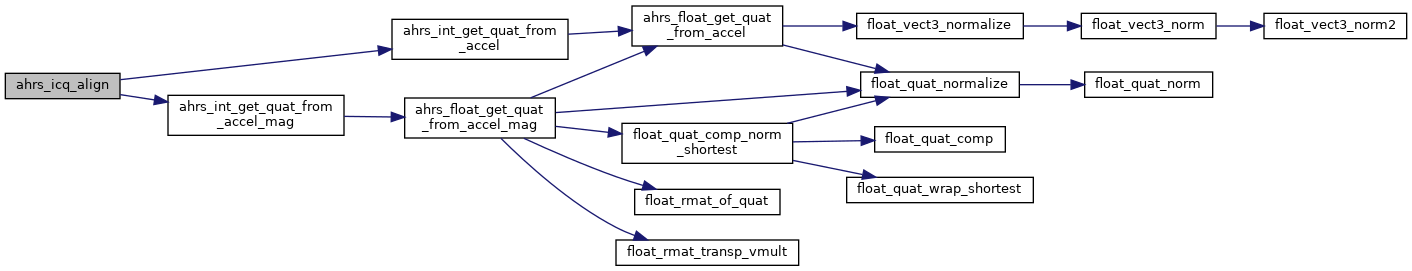
| bool ahrs_icq_align | ( | struct Int32Rates * | lp_gyro, |
| struct Int32Vect3 * | lp_accel, | ||
| struct Int32Vect3 * | lp_mag ) |
Definition at line 161 of file ahrs_int_cmpl_quat.c.
References ahrs_icq, AHRS_ICQ_RUNNING, ahrs_int_get_quat_from_accel(), ahrs_int_get_quat_from_accel_mag(), INT_RATES_LSHIFT, and RATES_COPY.
Referenced by aligner_cb(), and aligner_cb().
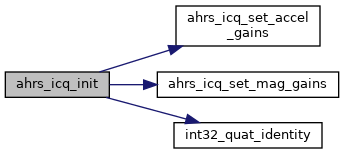
| void ahrs_icq_init | ( | void | ) |
Definition at line 119 of file ahrs_int_cmpl_quat.c.
References AHRS_ACCEL_OMEGA, AHRS_ACCEL_ZETA, AHRS_GRAVITY_HEURISTIC_FACTOR, ahrs_icq, ahrs_icq_set_accel_gains(), ahrs_icq_set_mag_gains(), AHRS_ICQ_UNINIT, AHRS_MAG_OMEGA, AHRS_MAG_ZETA, int32_quat_identity(), INT_RATES_ZERO, MAG_BFP_OF_REAL, and VECT3_ASSIGN.
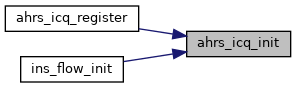
Referenced by ahrs_icq_wrapper_init(), and ins_flow_init().
| void ahrs_icq_propagate | ( | struct Int32Rates * | gyro, |
| float | dt ) |
Definition at line 190 of file ahrs_int_cmpl_quat.c.
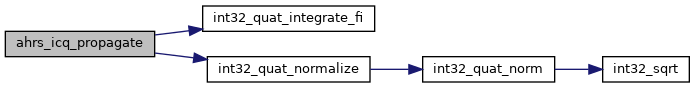
References ahrs_icq, int32_quat_integrate_fi(), int32_quat_normalize(), INT_RATES_ZERO, RATES_ADD, RATES_COPY, RATES_DIFF, RATES_SDIV, and RATES_SMUL.
Referenced by gyro_cb(), and gyro_cb().
| void ahrs_icq_realign_heading | ( | int32_t | heading | ) |
Hard reset yaw to a heading.
Doesn't affect the bias. Sets ahrs_icq.heading_aligned to TRUE.
| heading | Heading in body frame, radians (CW/north) with INT32_ANGLE_FRAC |
Definition at line 618 of file ahrs_int_cmpl_quat.c.
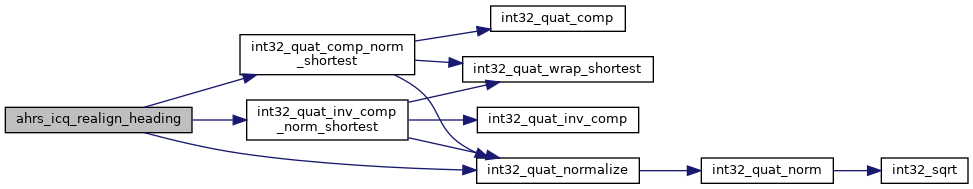
References ahrs_icq, heading, int32_quat_comp_norm_shortest(), int32_quat_inv_comp_norm_shortest(), int32_quat_normalize(), PPRZ_ITRIG_COS, PPRZ_ITRIG_SIN, Int32Quat::qi, QUAT_COPY, Int32Quat::qx, Int32Quat::qy, and Int32Quat::qz.
Referenced by ahrs_icq_update_gps().
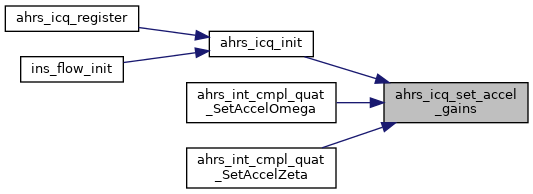
| void ahrs_icq_set_accel_gains | ( | void | ) |
update pre-computed inv_kp and inv_ki gains from acc_omega and acc_zeta
Definition at line 223 of file ahrs_int_cmpl_quat.c.
References ahrs_icq.
Referenced by ahrs_icq_init(), ahrs_int_cmpl_quat_SetAccelOmega(), and ahrs_int_cmpl_quat_SetAccelZeta().
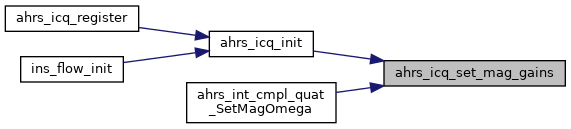
| void ahrs_icq_set_mag_gains | ( | void | ) |
update pre-computed kp and ki gains from mag_omega and mag_zeta
Definition at line 397 of file ahrs_int_cmpl_quat.c.
References ahrs_icq.
Referenced by ahrs_icq_init(), ahrs_int_cmpl_quat_SetMagOmega(), and ahrs_int_cmpl_quat_SetMagZeta().
| void ahrs_icq_update_accel | ( | struct Int32Vect3 * | accel, |
| float | dt ) |
Definition at line 244 of file ahrs_int_cmpl_quat.c.
References ACC_FROM_CROSS_FRAC, ACCELS_FLOAT_OF_BFP, ahrs_icq, c2, COMPUTATION_FRAC, FIR_FILTER_SIZE, FLOAT_VECT3_NORM, int32_rmat_of_quat(), INT32_VECT3_RSHIFT, INT_RATES_RSHIFT, RMAT_ELMT, VECT3_ADD, VECT3_COPY, VECT3_CROSS_PRODUCT, VECT3_DIFF, VECT3_RATES_CROSS_VECT3, VECT3_SDIV, VECT3_SMUL, Int32Vect3::x, Int32Vect3::y, and Int32Vect3::z.
Referenced by accel_cb(), and accel_cb().
| void ahrs_icq_update_gps | ( | struct GpsState * | gps_s | ) |
Definition at line 525 of file ahrs_int_cmpl_quat.c.
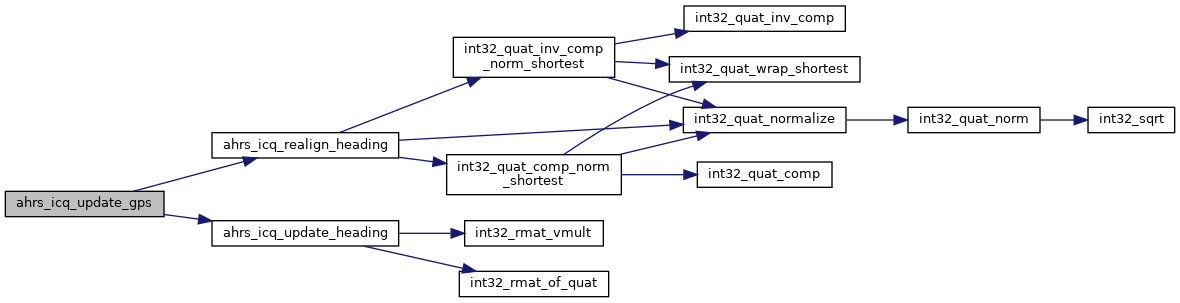
References AHRS_HEADING_UPDATE_GPS_MIN_SPEED, ahrs_icq, ahrs_icq_realign_heading(), ahrs_icq_update_heading(), course, GPS_FIX_3D, INT32_ANGLE_FRAC, and SPEED_BFP_OF_REAL.
Referenced by gps_cb(), and gps_cb().
| void ahrs_icq_update_heading | ( | int32_t | heading | ) |
Update yaw based on a heading measurement.
e.g. from GPS course
| heading | Heading in body frame, radians (CW/north) with INT32_ANGLE_FRAC |
Definition at line 561 of file ahrs_int_cmpl_quat.c.
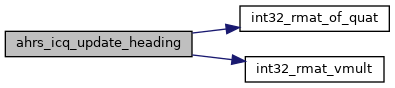
References AHRS_BIAS_UPDATE_HEADING_THRESHOLD, ahrs_icq, heading, INT32_ANGLE_FRAC, INT32_ANGLE_NORMALIZE, int32_rmat_of_quat(), int32_rmat_vmult(), INT_RATES_RSHIFT, PPRZ_ITRIG_COS, PPRZ_ITRIG_SIN, RMAT_ELMT, TRIG_BFP_OF_REAL, Int32Vect2::x, Int32Vect3::x, Int32Vect2::y, Int32Vect3::y, and Int32Vect3::z.
Referenced by ahrs_icq_update_gps().
| void ahrs_icq_update_mag | ( | struct Int32Vect3 * | mag, |
| float | dt ) |
Definition at line 380 of file ahrs_int_cmpl_quat.c.
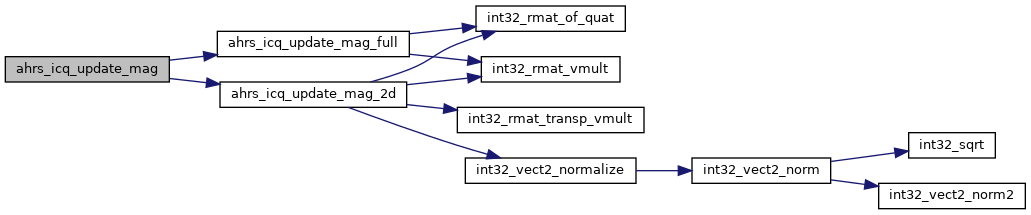
References ahrs_icq, ahrs_icq_update_mag_2d(), and ahrs_icq_update_mag_full().
Referenced by mag_cb().
|
inlinestatic |
Definition at line 459 of file ahrs_int_cmpl_quat.c.
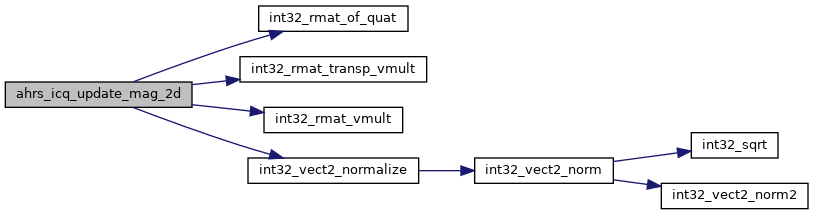
References ahrs_icq, INT32_MAG_FRAC, int32_rmat_of_quat(), int32_rmat_transp_vmult(), int32_rmat_vmult(), int32_vect2_normalize(), INT_RATES_RSHIFT, Int32Vect2::x, Int32Vect3::x, Int32Vect2::y, Int32Vect3::y, and Int32Vect3::z.
Referenced by ahrs_icq_update_mag().
|
inlinestatic |
Definition at line 406 of file ahrs_int_cmpl_quat.c.
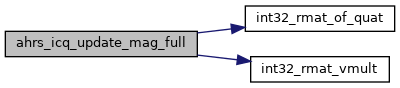
References ahrs_icq, int32_rmat_of_quat(), int32_rmat_vmult(), INT_RATES_RSHIFT, VECT3_CROSS_PRODUCT, Int32Vect3::x, Int32Vect3::y, and Int32Vect3::z.
Referenced by ahrs_icq_update_mag().
| struct AhrsIntCmplQuat ahrs_icq |
Default Rate filter Low pass.
Definition at line 114 of file ahrs_int_cmpl_quat.c.
Referenced by accel_cb(), accel_cb(), ahrs_icq_align(), ahrs_icq_init(), ahrs_icq_propagate(), ahrs_icq_realign_heading(), ahrs_icq_set_accel_gains(), ahrs_icq_set_mag_gains(), ahrs_icq_update_accel(), ahrs_icq_update_gps(), ahrs_icq_update_heading(), ahrs_icq_update_mag(), ahrs_icq_update_mag_2d(), ahrs_icq_update_mag_full(), ahrs_int_cmpl_quat_SetAccelOmega(), ahrs_int_cmpl_quat_SetAccelZeta(), ahrs_int_cmpl_quat_SetMagOmega(), ahrs_int_cmpl_quat_SetMagZeta(), aligner_cb(), aligner_cb(), geo_mag_cb(), gyro_cb(), gyro_cb(), mag_cb(), send_bias(), send_bias(), send_euler(), send_euler(), send_filter_status(), send_filter_status(), send_geo_mag(), send_geo_mag(), send_quat(), send_quat(), set_body_state_from_quat(), and set_body_state_from_quat().
 1.15.0