|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
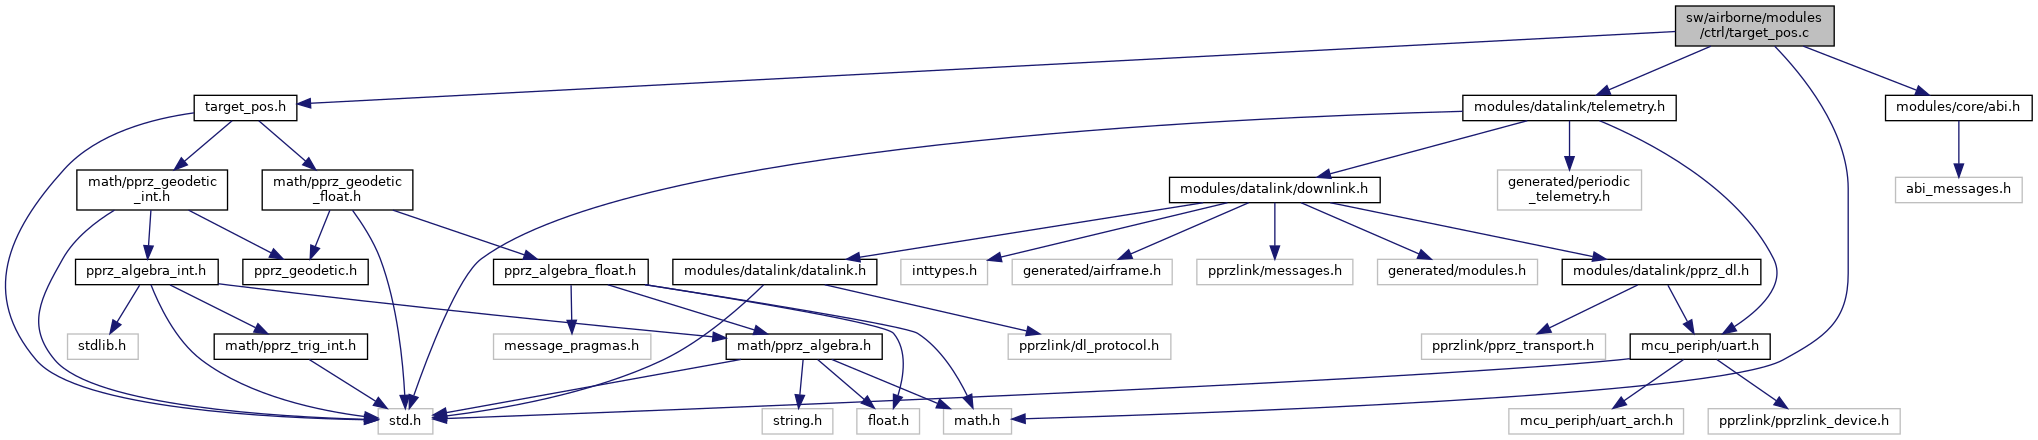
#include "target_pos.h"#include <math.h>#include "modules/datalink/telemetry.h"#include "modules/core/abi.h"#include "state.h"Go to the source code of this file.
Macros | |
| #define | TARGET_POS_TIMEOUT 5000 |
| #define | TARGET_RTK_TIMEOUT 1000 |
| #define | TARGET_OFFSET_HEADING 180.0 |
| #define | TARGET_OFFSET_DISTANCE 12.0 |
| #define | TARGET_OFFSET_HEIGHT -1.2 |
| #define | TARGET_INTEGRATE_XY true |
| #define | TARGET_INTEGRATE_Z false |
Functions | |
| static void | gps_cb (uint8_t sender_id, uint32_t stamp, struct GpsState *gps_s) |
| static void | send_target_pos_info (struct transport_tx *trans, struct link_device *dev) |
| void | target_pos_init (void) |
| void | target_parse_target_pos (uint8_t *buf) |
| Receive a TARGET_POS message from the ground. | |
| bool | target_get_pos (struct NedCoor_f *pos, float *heading) |
| Get the current target position (NED) and heading. | |
| bool | target_get_vel (struct NedCoor_f *vel) |
| Get the current target velocity (NED). | |
| bool | target_pos_set_current_offset (float unk) |
| Set the current measured distance and heading as offset. | |
Variables | |
| struct target_t | target |
| static abi_event | gps_ev |
Definition in file target_pos.c.
| #define TARGET_INTEGRATE_XY true |
Definition at line 57 of file target_pos.c.
| #define TARGET_INTEGRATE_Z false |
Definition at line 61 of file target_pos.c.
| #define TARGET_OFFSET_DISTANCE 12.0 |
Definition at line 49 of file target_pos.c.
| #define TARGET_OFFSET_HEADING 180.0 |
Definition at line 45 of file target_pos.c.
| #define TARGET_OFFSET_HEIGHT -1.2 |
Definition at line 53 of file target_pos.c.
| #define TARGET_POS_TIMEOUT 5000 |
Definition at line 36 of file target_pos.c.
| #define TARGET_RTK_TIMEOUT 1000 |
Definition at line 41 of file target_pos.c.
Definition at line 110 of file target_pos.c.
References LlaCoor_i::alt, LlaCoor_i::lat, GpsState::lla_pos, LlaCoor_i::lon, and target.
|
static |
Definition at line 84 of file target_pos.c.
Referenced by target_pos_init().
| bool target_get_pos | ( | struct NedCoor_f * | pos, |
| float * | heading ) |
Get the current target position (NED) and heading.
Definition at line 143 of file target_pos.c.
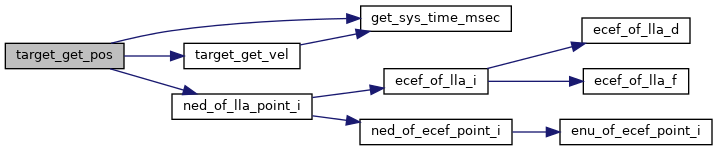
References get_sys_time_msec(), heading, ned_of_lla_point_i(), state, stateGetNedOrigin_i(), target, target_get_vel(), NedCoor_f::x, NedCoor_i::x, NedCoor_f::y, NedCoor_i::y, NedCoor_f::z, and NedCoor_i::z.
Referenced by follow_diagonal_approach().
| bool target_get_vel | ( | struct NedCoor_f * | vel | ) |
Get the current target velocity (NED).
Definition at line 192 of file target_pos.c.
References get_sys_time_msec(), state, target, NedCoor_f::x, NedCoor_f::y, and NedCoor_f::z.
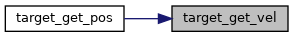
Referenced by follow_diagonal_approach(), and target_get_pos().
| void target_parse_target_pos | ( | uint8_t * | buf | ) |
Receive a TARGET_POS message from the ground.
Definition at line 122 of file target_pos.c.
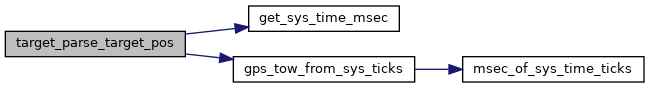
References get_sys_time_msec(), gps_tow_from_sys_ticks(), sys_time::nb_tick, and target.
| void target_pos_init | ( | void | ) |
Definition at line 100 of file target_pos.c.
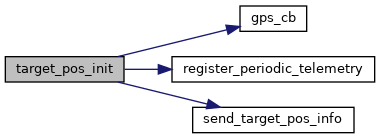
References ABI_BROADCAST, DefaultPeriodic, gps_cb(), gps_ev, register_periodic_telemetry(), and send_target_pos_info().
| bool target_pos_set_current_offset | ( | float | unk | ) |
Set the current measured distance and heading as offset.
Definition at line 210 of file target_pos.c.
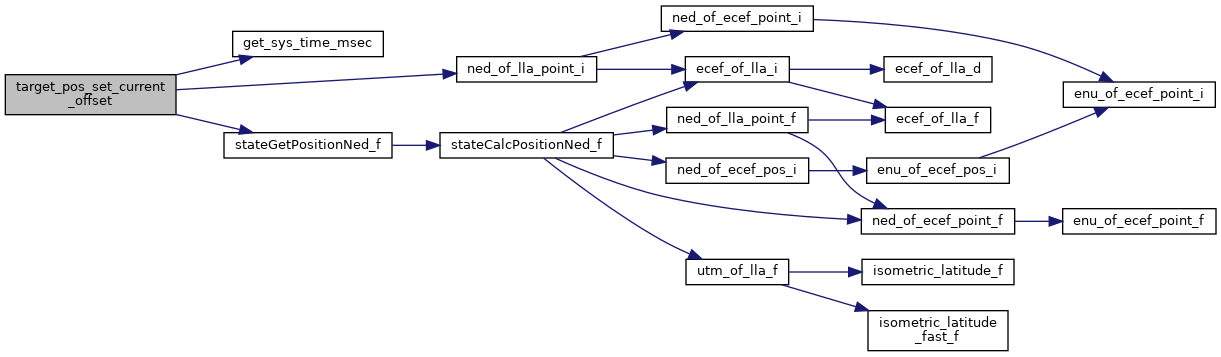
References get_sys_time_msec(), ned_of_lla_point_i(), state, stateGetNedOrigin_i(), stateGetPositionNed_f(), target, NedCoor_f::x, NedCoor_i::x, NedCoor_f::y, NedCoor_i::y, NedCoor_f::z, and NedCoor_i::z.
|
static |
Definition at line 79 of file target_pos.c.
| struct target_t target |
Definition at line 65 of file target_pos.c.
Referenced by cam_gimbal_ac_target(), cam_gimbal_nadir(), cam_gimbal_set_target_pos(), cam_gimbal_target(), cam_gimbal_waypoint_target(), CN_calculate_target(), georeference_run(), gps_cb(), lsm303d_spi_init(), mavlink_common_message_handler(), nav_eight(), nav_get_speed_sp_from_diagonal(), nav_set_heading_towards(), px4flash_event(), recursive_least_squares(), recursive_least_squares(), send_target_pos_info(), spin_man_ramp_ref(), target_get_pos(), target_get_vel(), target_parse_target_pos(), target_pos_set_current_offset(), update_target_point(), and update_target_point().
 1.15.0