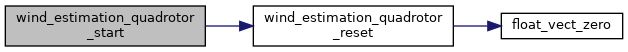|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Go to the source code of this file.
Data Structures | |
| struct | wind_estimation_quadrotor_params |
Functions | |
| void | wind_estimation_quadrotor_init (void) |
| void | wind_estimation_quadrotor_periodic (void) |
| void | wind_estimation_quadrotor_stop (void) |
| void | wind_estimation_quadrotor_start (void) |
| void | wind_estimation_quadrotor_report (void) |
| float | wind_estimation_quadrotor_SetQva (float Q_va) |
| float | wind_estimation_quadrotor_SetQw (float Q_w) |
| float | wind_estimation_quadrotor_SetR (float R) |
Variables | |
| struct wind_estimation_quadrotor_params | we_quad_params |
Definition in file wind_estimation_quadrotor.h.
| struct wind_estimation_quadrotor_params |
Definition at line 29 of file wind_estimation_quadrotor.h.
| Data Fields | ||
|---|---|---|
| float | Q_va | model noise on airspeed |
| float | Q_w | model noise on wind |
| float | R | measurement noise (ground speed) |
|
extern |
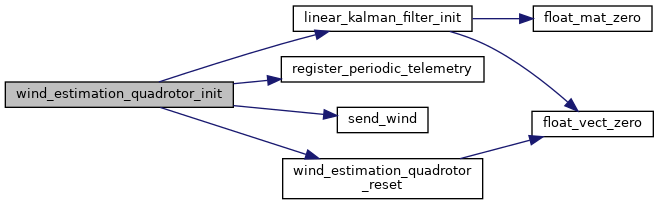
Definition at line 99 of file wind_estimation_quadrotor.c.
References DefaultPeriodic, linear_kalman_filter_init(), register_periodic_telemetry(), send_wind(), we_dt, we_quad, WE_QUAD_CMD_SIZE, WE_QUAD_MEAS_SIZE, we_quad_params, WE_QUAD_Q_VA, WE_QUAD_Q_W, WE_QUAD_R, WE_QUAD_STATE_SIZE, WE_QUAD_STATUS_IDLE, and wind_estimation_quadrotor_reset().
|
extern |
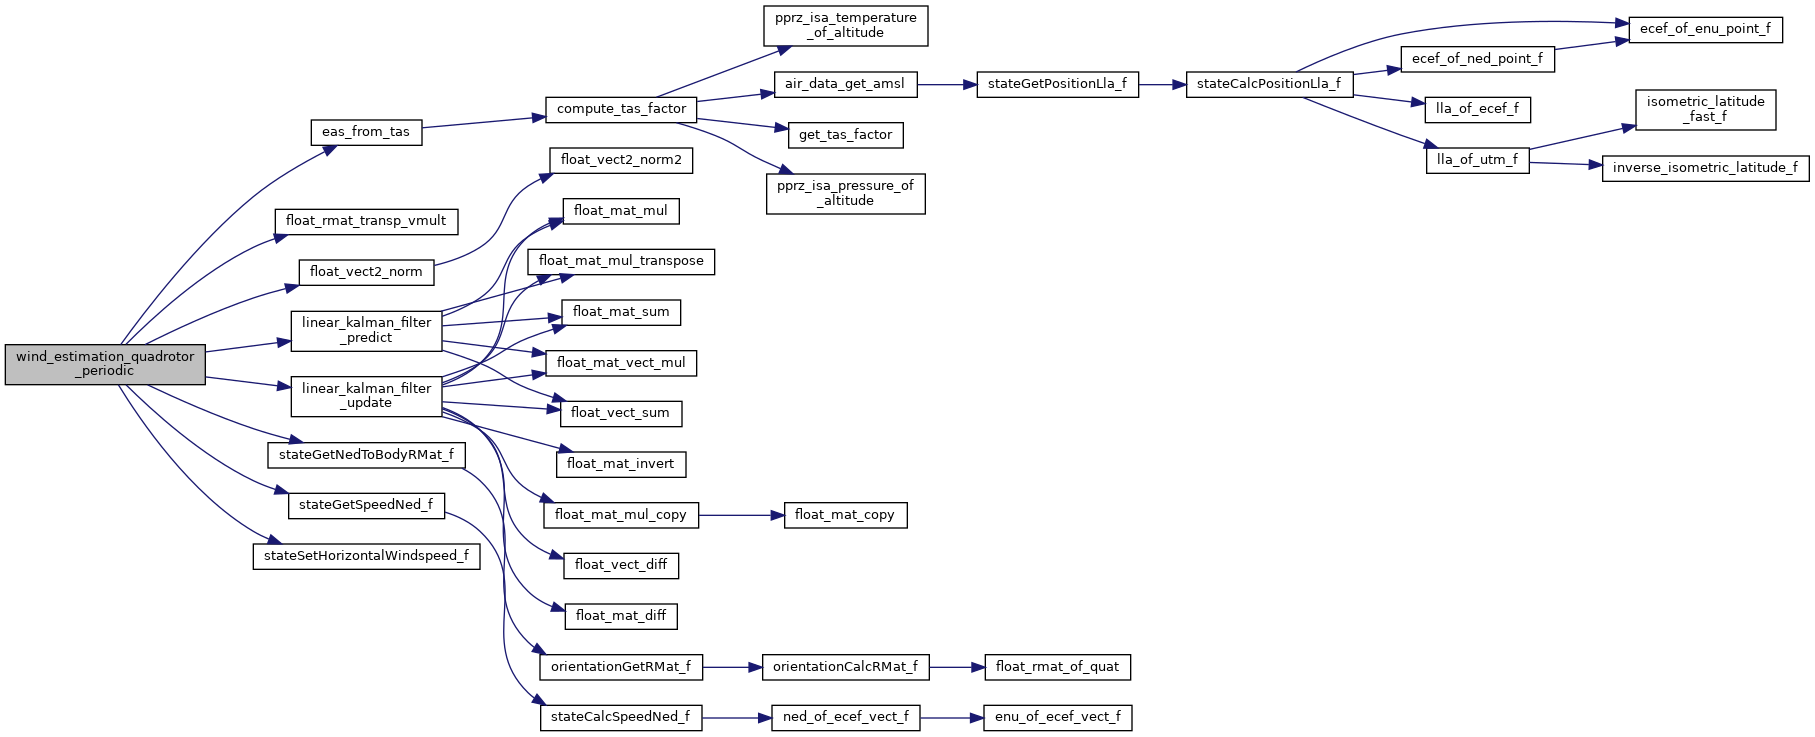
Definition at line 134 of file wind_estimation_quadrotor.c.
References AIRSPEED_WE_QUAD_ID, eas_from_tas(), float_rmat_transp_vmult(), float_vect2_norm(), get_sys_time_usec(), linear_kalman_filter_predict(), linear_kalman_filter_update(), MAT33_ELMT, PPRZ_ISA_GRAVITY, stateGetNedToBodyRMat_f(), stateGetSpeedNed_f(), stateSetHorizontalWindspeed_f(), we_quad, WE_QUAD_CMD_SIZE, WE_QUAD_MEAS_SIZE, WE_QUAD_VA_X, WE_QUAD_VA_Y, WE_QUAD_W_X, WE_QUAD_W_Y, FloatVect3::x, NedCoor_f::x, FloatVect3::y, and NedCoor_f::y.
|
extern |
Definition at line 209 of file wind_estimation_quadrotor.c.
References DefaultChannel, DefaultDevice, we_quad, and WE_QUAD_STATE_SIZE.
|
extern |
Definition at line 185 of file wind_estimation_quadrotor.c.
References we_quad, and we_quad_params.
|
extern |
Definition at line 193 of file wind_estimation_quadrotor.c.
References we_quad, and we_quad_params.
|
extern |
Definition at line 201 of file wind_estimation_quadrotor.c.
References we_quad, and we_quad_params.
|
extern |
Definition at line 179 of file wind_estimation_quadrotor.c.
References we_quad, WE_QUAD_STATUS_RUN, and wind_estimation_quadrotor_reset().
|
extern |
Definition at line 170 of file wind_estimation_quadrotor.c.
References stateSetHorizontalWindspeed_f(), we_quad, and WE_QUAD_STATUS_IDLE.
|
extern |
Definition at line 88 of file wind_estimation_quadrotor.c.
Referenced by wind_estimation_quadrotor_init(), wind_estimation_quadrotor_SetQva(), wind_estimation_quadrotor_SetQw(), and wind_estimation_quadrotor_SetR().
 1.15.0