|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
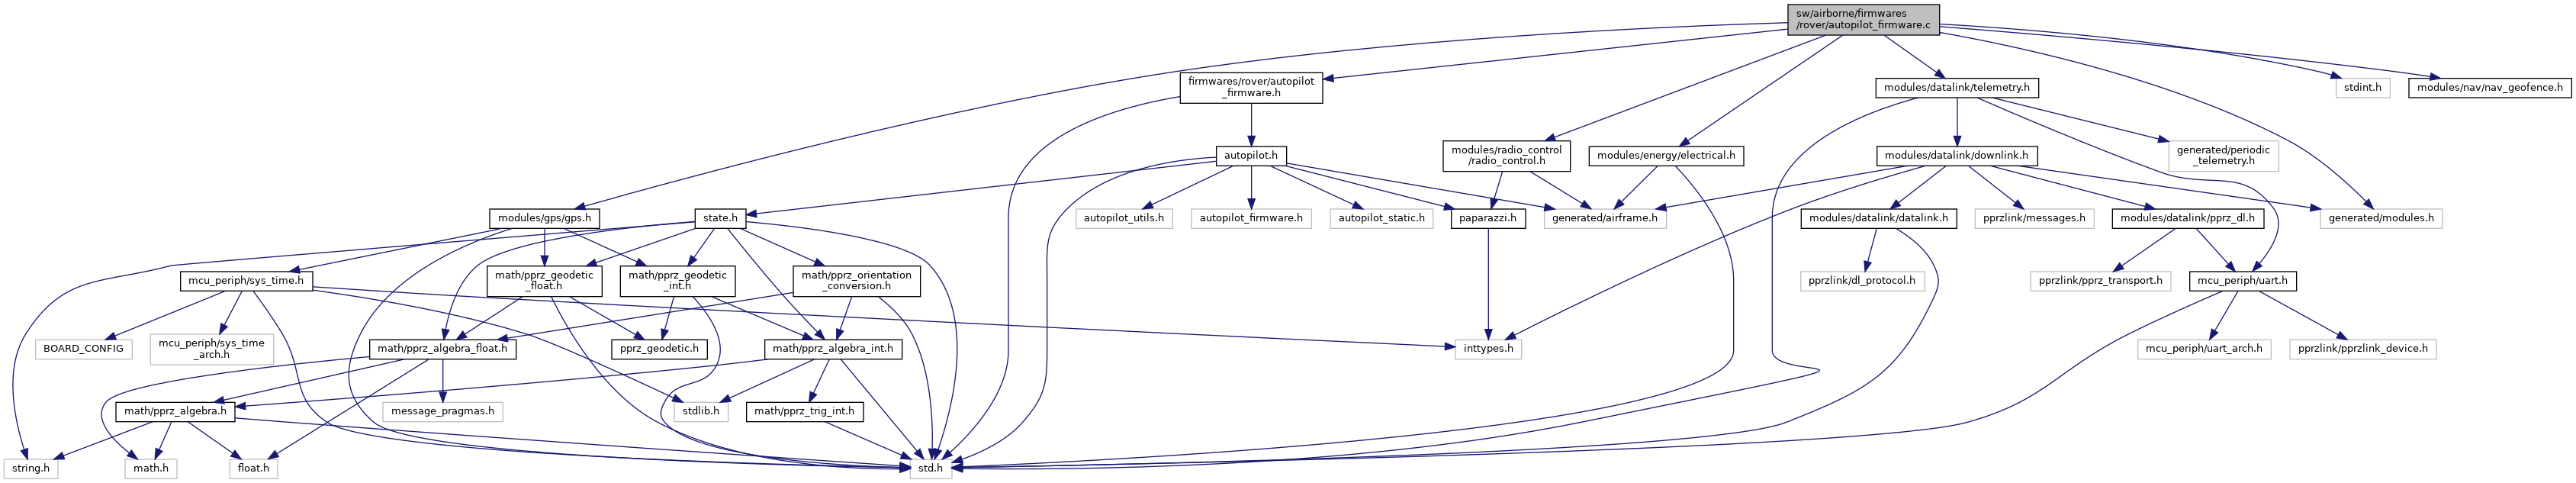
#include "firmwares/rover/autopilot_firmware.h"#include "generated/modules.h"#include <stdint.h>#include "modules/energy/electrical.h"#include "modules/datalink/telemetry.h"#include "modules/radio_control/radio_control.h"#include "modules/gps/gps.h"#include "modules/nav/nav_geofence.h"Go to the source code of this file.
Functions | |
| static void | send_status (struct transport_tx *trans, struct link_device *dev) |
| static void | send_energy (struct transport_tx *trans, struct link_device *dev) |
| static void | send_fp (struct transport_tx *trans, struct link_device *dev) |
| static void | send_rotorcraft_rc (struct transport_tx *trans, struct link_device *dev) |
| void | autopilot_firmware_init (void) |
| Init function. | |
| void | autopilot_event (void) |
| autopilot event function | |
| void autopilot_event | ( | void | ) |
autopilot event function
Autopilot event check function.
Definition at line 142 of file autopilot_firmware.c.
| void autopilot_firmware_init | ( | void | ) |
Init function.
Definition at line 128 of file autopilot_firmware.c.
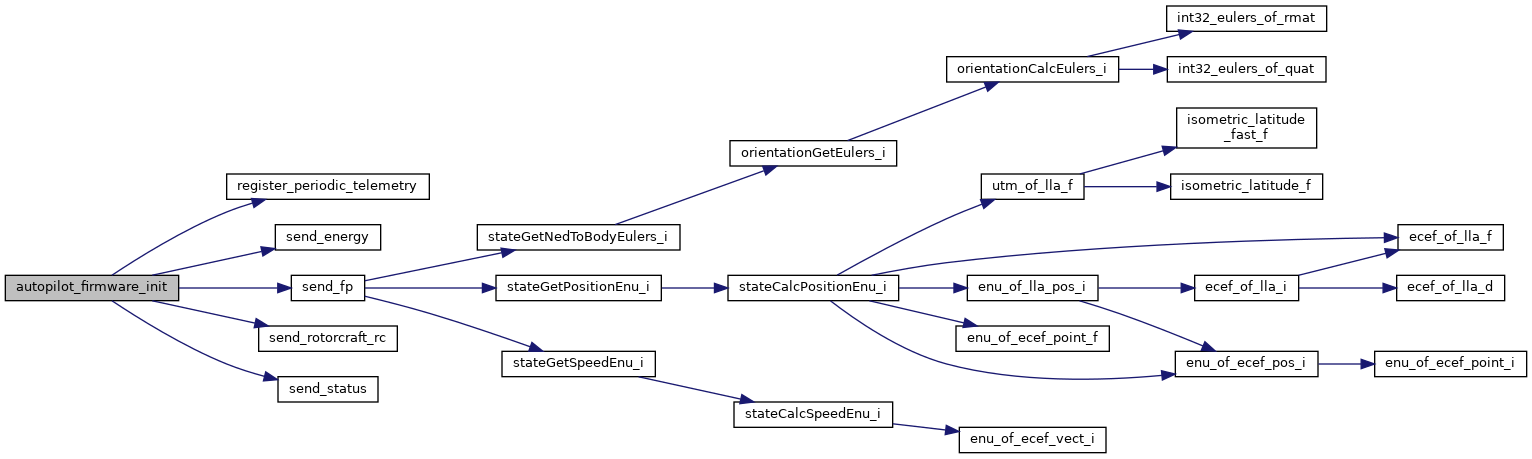
References DefaultPeriodic, register_periodic_telemetry(), send_energy(), send_fp(), send_rotorcraft_rc(), and send_status().
|
static |
Definition at line 70 of file autopilot_firmware.c.
References autopilot, dev, electrical, and MAX_PPRZ.
|
static |
Definition at line 83 of file autopilot_firmware.c.
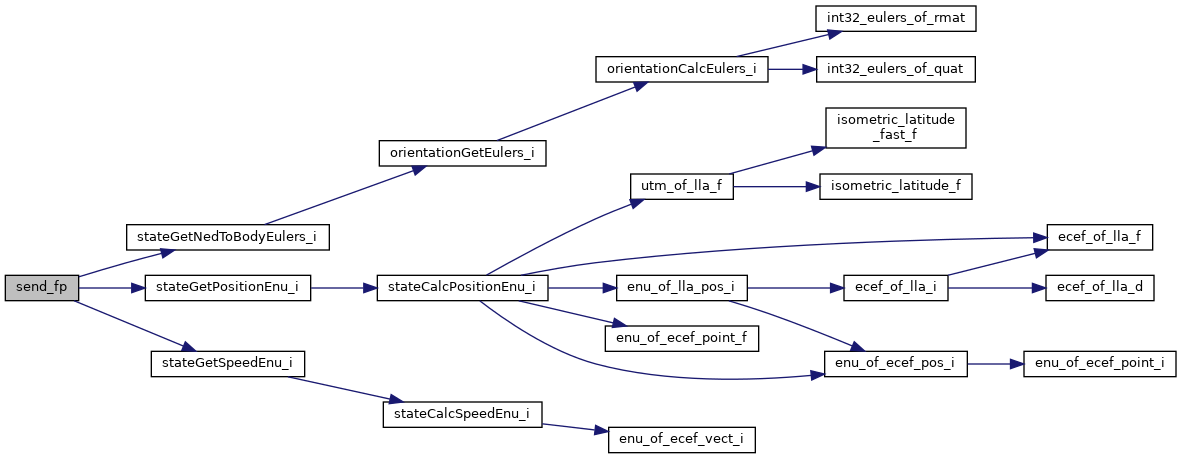
References ANGLE_BFP_OF_REAL, autopilot, dev, nav, POS_BFP_OF_REAL, stateGetNedToBodyEulers_i(), stateGetPositionEnu_i(), and stateGetSpeedEnu_i().
|
static |
Definition at line 110 of file autopilot_firmware.c.
References dev, radio_control, RADIO_KILL_SWITCH, RADIO_MODE, RADIO_PITCH, RADIO_ROLL, RADIO_THROTTLE, and RADIO_YAW.
|
static |
Definition at line 55 of file autopilot_firmware.c.
References autopilot, dev, electrical, gps, sys_time::nb_sec, and radio_control.
 1.15.0