|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
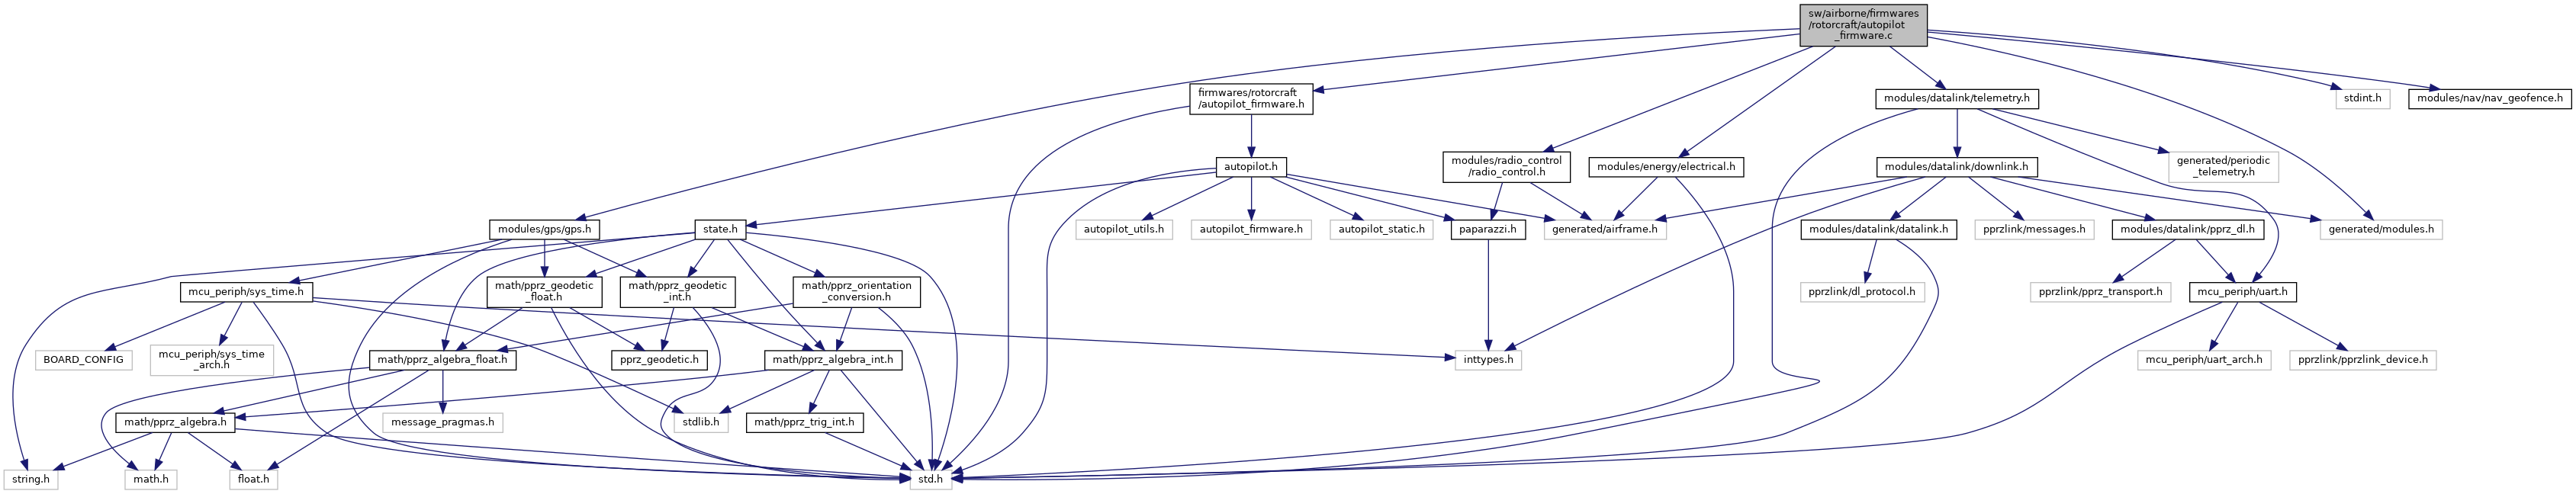
#include "firmwares/rotorcraft/autopilot_firmware.h"#include "generated/modules.h"#include <stdint.h>#include "modules/energy/electrical.h"#include "modules/datalink/telemetry.h"#include "modules/radio_control/radio_control.h"#include "modules/gps/gps.h"#include "modules/nav/nav_geofence.h"Go to the source code of this file.
Macros | |
| #define | AUTOPILOT_IN_FLIGHT_TIME 20 |
| time steps for in_flight detection (at 20Hz, so 20=1second) | |
| #define | AUTOPILOT_IN_FLIGHT_MIN_SPEED 0.2 |
| minimum vertical speed for in_flight condition in m/s | |
| #define | AUTOPILOT_IN_FLIGHT_MIN_ACCEL 2.0 |
| minimum vertical acceleration for in_flight condition in m/s^2 | |
| #define | AUTOPILOT_IN_FLIGHT_MIN_THRUST 500 |
| minimum thrust for in_flight condition in pprz_t units (max = 9600) | |
| #define | THRESHOLD_GROUND_DETECT 25.0 |
| Z-acceleration threshold to detect ground in m/s^2. | |
Functions | |
| bool WEAK | autopilot_ground_detection (void) |
| Default ground-detection estimation based on accelerometer shock. | |
| bool WEAK | autopilot_in_flight_end_detection (bool motors_on UNUSED) |
| Default end-of-in-flight detection estimation based on thrust and speed. | |
| static void | send_status (struct transport_tx *trans, struct link_device *dev) |
| static void | send_energy (struct transport_tx *trans, struct link_device *dev) |
| static void | send_fp (struct transport_tx *trans, struct link_device *dev) |
| static void | send_body_rates_accel (struct transport_tx *trans, struct link_device *dev) |
| static void | send_fp_min (struct transport_tx *trans, struct link_device *dev) |
| static void | send_rotorcraft_rc (struct transport_tx *trans, struct link_device *dev) |
| static void | send_rotorcraft_cmd (struct transport_tx *trans UNUSED, struct link_device *dev UNUSED) |
| void | autopilot_firmware_init (void) |
| Init function. | |
| void | autopilot_send_mode (void) |
| Report autopilot mode on default downlink channel. | |
| void | autopilot_event (void) |
| autopilot event function | |
| void | autopilot_reset_in_flight_counter (void) |
| reset in_flight counter | |
| void | autopilot_check_in_flight (bool motors_on) |
| in flight check utility function | |
Variables | |
| uint8_t | autopilot_mode_auto2 |
| static uint32_t | autopilot_in_flight_counter |
| #define AUTOPILOT_IN_FLIGHT_MIN_ACCEL 2.0 |
minimum vertical acceleration for in_flight condition in m/s^2
Definition at line 67 of file autopilot_firmware.c.
Referenced by autopilot_in_flight_end_detection().
| #define AUTOPILOT_IN_FLIGHT_MIN_SPEED 0.2 |
minimum vertical speed for in_flight condition in m/s
Definition at line 62 of file autopilot_firmware.c.
Referenced by autopilot_in_flight_end_detection().
| #define AUTOPILOT_IN_FLIGHT_MIN_THRUST 500 |
minimum thrust for in_flight condition in pprz_t units (max = 9600)
Definition at line 72 of file autopilot_firmware.c.
Referenced by autopilot_check_in_flight(), and autopilot_in_flight_end_detection().
| #define AUTOPILOT_IN_FLIGHT_TIME 20 |
time steps for in_flight detection (at 20Hz, so 20=1second)
Definition at line 57 of file autopilot_firmware.c.
Referenced by autopilot_check_in_flight(), and autopilot_in_flight_end_detection().
| #define THRESHOLD_GROUND_DETECT 25.0 |
Z-acceleration threshold to detect ground in m/s^2.
Definition at line 77 of file autopilot_firmware.c.
Referenced by autopilot_ground_detection().
| void autopilot_check_in_flight | ( | bool | motors_on | ) |
in flight check utility function
Check if airframe is in flight.
Definition at line 295 of file autopilot_firmware.c.
References autopilot, autopilot_in_flight_counter, autopilot_in_flight_end_detection(), AUTOPILOT_IN_FLIGHT_MIN_THRUST, AUTOPILOT_IN_FLIGHT_TIME, and stabilization.
| void autopilot_event | ( | void | ) |
autopilot event function
Autopilot event check function.
used for automatic ground detection
Definition at line 272 of file autopilot_firmware.c.
References AP_MODE_FAILSAFE, autopilot, and autopilot_ground_detection().
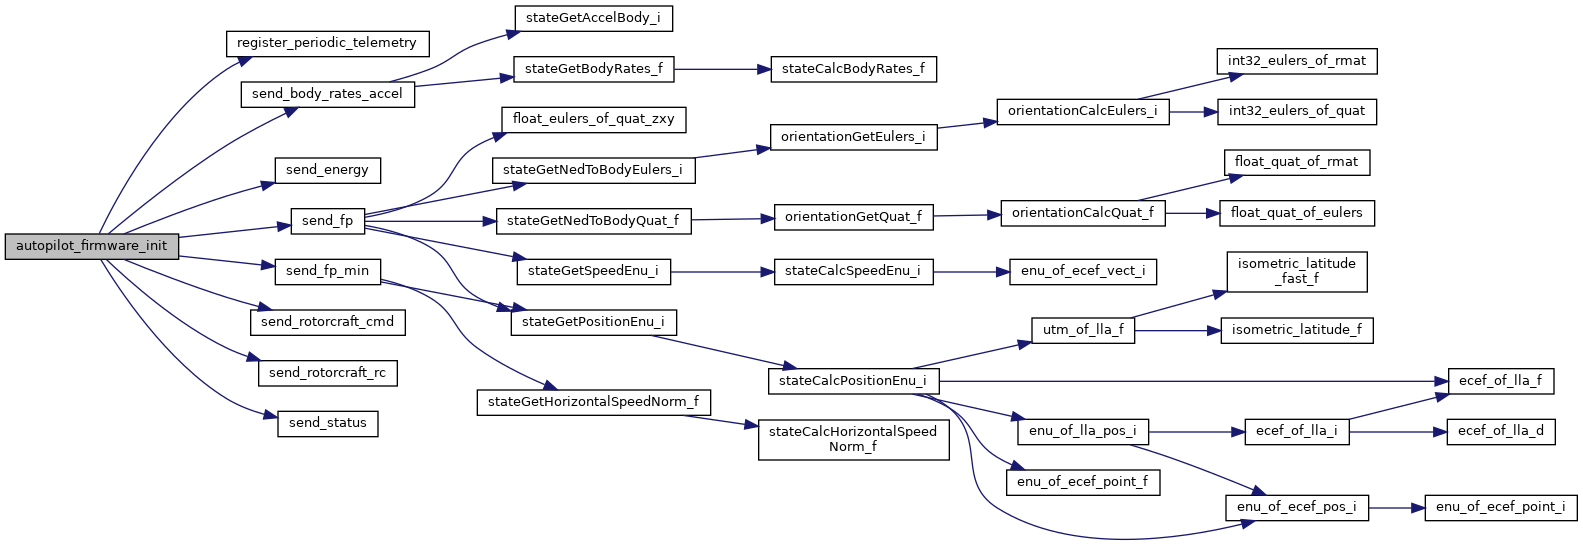
| void autopilot_firmware_init | ( | void | ) |
Init function.
Definition at line 242 of file autopilot_firmware.c.
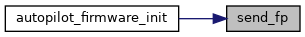
References autopilot_in_flight_counter, autopilot_mode_auto2, DefaultPeriodic, MODE_AUTO2, register_periodic_telemetry(), send_body_rates_accel(), send_energy(), send_fp(), send_fp_min(), send_rotorcraft_cmd(), send_rotorcraft_rc(), and send_status().
| bool WEAK autopilot_ground_detection | ( | void | ) |
Default ground-detection estimation based on accelerometer shock.
Definition at line 81 of file autopilot_firmware.c.
References stateGetAccelNed_f(), THRESHOLD_GROUND_DETECT, and NedCoor_f::z.
Referenced by autopilot_event().
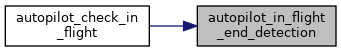
| bool WEAK autopilot_in_flight_end_detection | ( | bool motors_on | UNUSED | ) |
Default end-of-in-flight detection estimation based on thrust and speed.
Definition at line 92 of file autopilot_firmware.c.
References autopilot_in_flight_counter, AUTOPILOT_IN_FLIGHT_MIN_ACCEL, AUTOPILOT_IN_FLIGHT_MIN_SPEED, AUTOPILOT_IN_FLIGHT_MIN_THRUST, AUTOPILOT_IN_FLIGHT_TIME, stabilization, stateGetAccelNed_f(), stateGetSpeedNed_f(), UNUSED, and NedCoor_f::z.
Referenced by autopilot_check_in_flight().
| void autopilot_reset_in_flight_counter | ( | void | ) |
reset in_flight counter
reset in_flight counter actual implementation is firmware dependent
Definition at line 288 of file autopilot_firmware.c.
References autopilot_in_flight_counter.
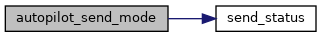
| void autopilot_send_mode | ( | void | ) |
Report autopilot mode on default downlink channel.
Report autopilot mode on default downlink channel.
Definition at line 261 of file autopilot_firmware.c.
References DefaultChannel, DefaultDevice, and send_status().
|
static |
Definition at line 183 of file autopilot_firmware.c.
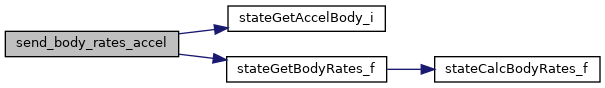
References dev, p, stateGetAccelBody_i(), and stateGetBodyRates_f().
Referenced by autopilot_firmware_init().
|
static |
Definition at line 138 of file autopilot_firmware.c.
References autopilot, dev, electrical, and MAX_PPRZ.
|
static |
Definition at line 151 of file autopilot_firmware.c.
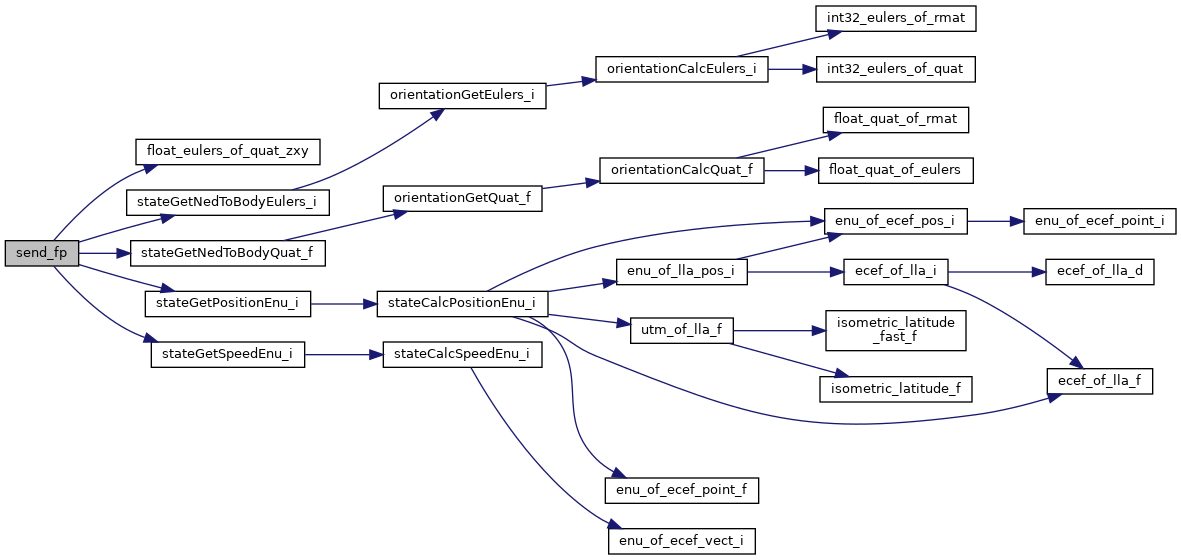
References ANGLE_BFP_OF_REAL, autopilot, dev, EULERS_BFP_OF_REAL, eulers_zxy, guidance_h, guidance_v, Int32Eulers::phi, Int32Eulers::psi, stateGetNedToBodyEulers_i(), stateGetNedToBodyEulersZxy_f(), stateGetPositionEnu_i(), stateGetSpeedEnu_i(), Int32Eulers::theta, EnuCoor_i::x, EnuCoor_i::y, and EnuCoor_i::z.
Referenced by autopilot_firmware_init().
|
static |
Definition at line 194 of file autopilot_firmware.c.
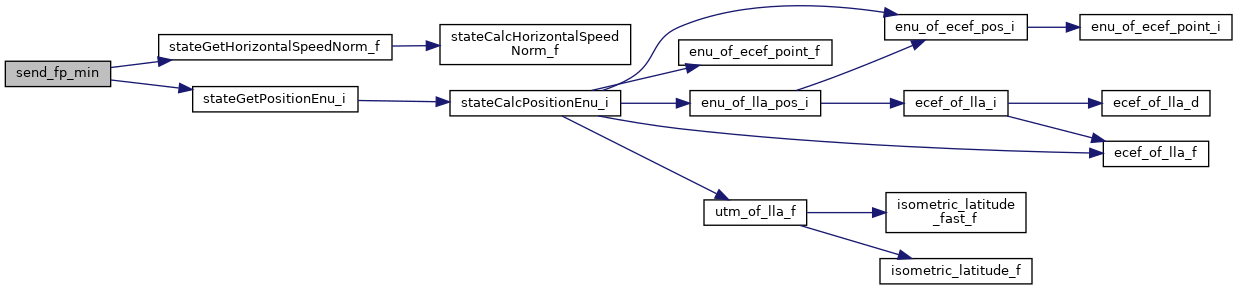
References dev, gps, stateGetHorizontalSpeedNorm_f(), and stateGetPositionEnu_i().
Referenced by autopilot_firmware_init().
|
static |
Definition at line 238 of file autopilot_firmware.c.
Referenced by autopilot_firmware_init().
|
static |
Definition at line 210 of file autopilot_firmware.c.
References dev, radio_control, RADIO_KILL_SWITCH, RADIO_MODE, RADIO_PITCH, RADIO_ROLL, RADIO_THROTTLE, and RADIO_YAW.
Referenced by autopilot_firmware_init().
|
static |
Definition at line 114 of file autopilot_firmware.c.
References autopilot, dev, electrical, gps, guidance_h, guidance_v, motor_mixing, sys_time::nb_sec, and radio_control.
Referenced by autopilot_firmware_init(), autopilot_send_mode(), and intermcu_init().
|
static |
Definition at line 50 of file autopilot_firmware.c.
Referenced by autopilot_check_in_flight(), autopilot_firmware_init(), autopilot_in_flight_end_detection(), and autopilot_reset_in_flight_counter().
| uint8_t autopilot_mode_auto2 |
Definition at line 49 of file autopilot_firmware.c.
Referenced by autopilot_firmware_init(), and guidance_flip_run().
 1.15.0