|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "std.h"Go to the source code of this file.
Macros | |
| #define | PRIMARY_GPS GPS_UWB |
Functions | |
| void | uwb_positioning_update_ekf_q (float v) |
| settings handler | |
| void | uwb_positioning_update_ekf_r_dist (float v) |
| void | uwb_positioning_update_ekf_r_speed (float v) |
| void | uwb_positioning_init (void) |
| void | uwb_positioning_periodic (void) |
| void | uwb_positioning_range_periodic (void) |
| void | uwb_positioning_report (void) |
| void | uwb_positioning_reset_heading_ref (void) |
| Reset reference heading to current heading AHRS/INS should be aligned before calling this function. | |
| void | uwb_range (uint16_t id) |
| Weak empty implementation. | |
Variables | |
| bool | uwb_positioning_use_ekf |
| enable EKF filtering | |
| float | uwb_positioning_ekf_q |
| process and measurements noise | |
| float | uwb_positioning_ekf_r_dist |
| float | uwb_positioning_ekf_r_speed |
Definition in file uwb_positioning.h.
| #define PRIMARY_GPS GPS_UWB |
Definition at line 54 of file uwb_positioning.h.
|
extern |
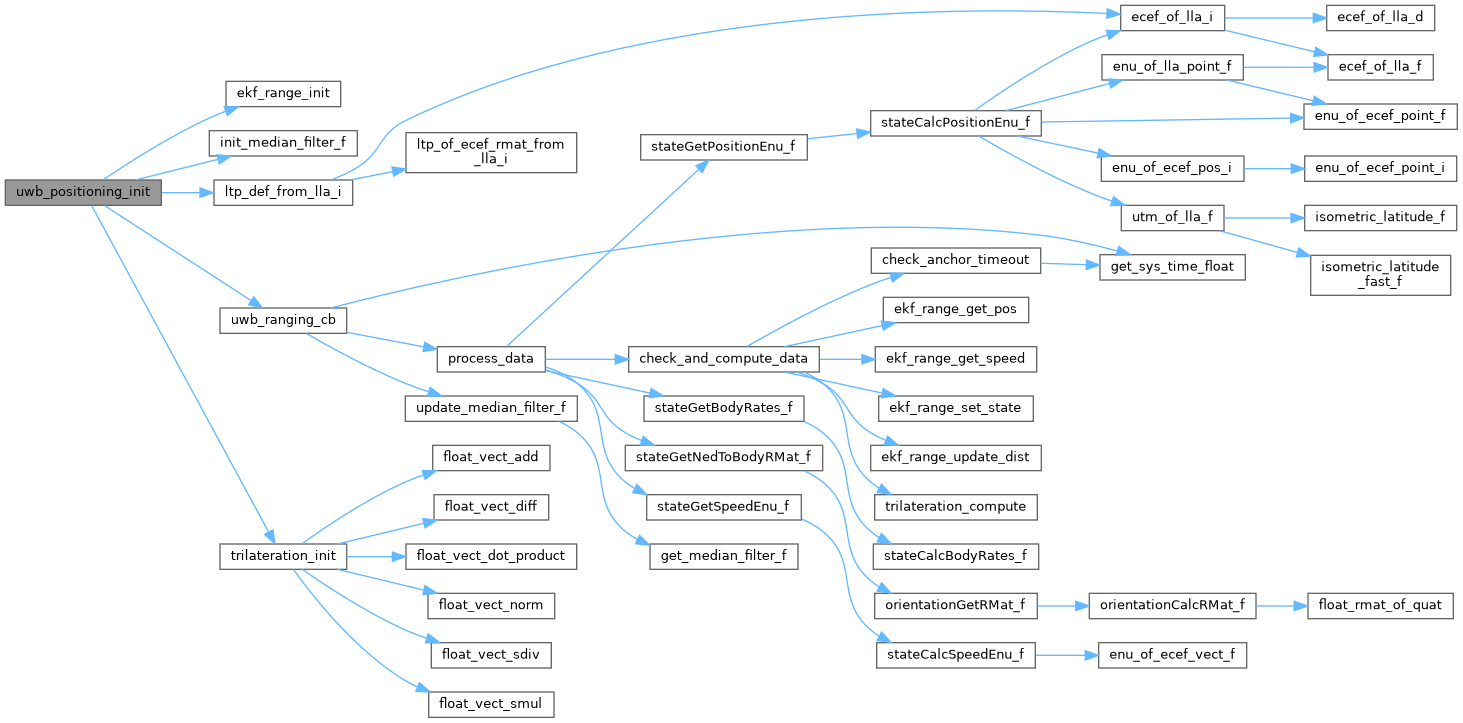
Definition at line 465 of file uwb_positioning.c.
References ABI_BROADCAST, LlaCoor_i::alt, ekf_range_init(), GPS_FIX_NONE, GPS_UWB_ID, ids, init_median_filter_f(), LlaCoor_i::lat, LlaCoor_i::lon, ltp_def_from_lla_i(), pos_x, pos_y, pos_z, trilateration_init(), uwb_positioning, uwb_positioning_ekf_q, uwb_positioning_ekf_r_dist, uwb_positioning_ekf_r_speed, UWB_POSITIONING_INITIAL_HEADING, UWB_POSITIONING_NB_ANCHORS, UWB_POSITIONING_USE_EKF, uwb_positioning_use_ekf, uwb_ranging_cb(), and uwb_ranging_ev.
|
extern |
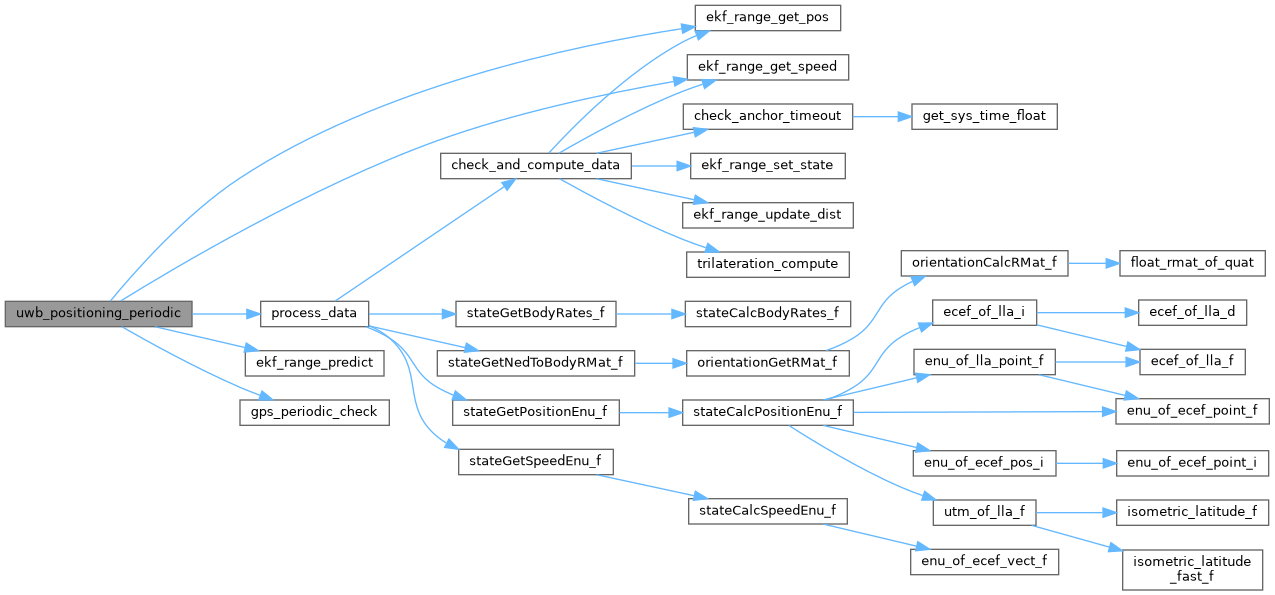
Definition at line 521 of file uwb_positioning.c.
References ekf_range_get_pos(), ekf_range_get_speed(), ekf_range_predict(), gps_periodic_check(), log_started, pprzLogFile, process_data(), sdLogWriteLog(), uwb_positioning, and uwb_positioning_use_ekf.
|
extern |
Definition at line 552 of file uwb_positioning.c.
References Anchor::id, uwb_positioning, UWB_POSITIONING_NB_ANCHORS, and uwb_range().
|
extern |
Definition at line 558 of file uwb_positioning.c.
References DefaultChannel, DefaultDevice, and uwb_positioning.
|
extern |
Reset reference heading to current heading AHRS/INS should be aligned before calling this function.
Definition at line 415 of file uwb_positioning.c.
References FloatEulers::psi, stateGetNedToBodyEulers_f(), and uwb_positioning.
|
extern |
settings handler
Definition at line 579 of file uwb_positioning.c.
References ekf_range_update_noise(), uwb_positioning, uwb_positioning_ekf_q, uwb_positioning_ekf_r_dist, and uwb_positioning_ekf_r_speed.
|
extern |
Definition at line 585 of file uwb_positioning.c.
References ekf_range_update_noise(), uwb_positioning, uwb_positioning_ekf_q, uwb_positioning_ekf_r_dist, and uwb_positioning_ekf_r_speed.
|
extern |
Definition at line 591 of file uwb_positioning.c.
References ekf_range_update_noise(), uwb_positioning, uwb_positioning_ekf_q, uwb_positioning_ekf_r_dist, and uwb_positioning_ekf_r_speed.
| void uwb_range | ( | uint16_t | id | ) |
Weak empty implementation.
Definition at line 433 of file pdec.c.
References pdec_target_cmd_payload::dst_id, and pdec_range().
Referenced by uwb_positioning_range_periodic().
|
extern |
process and measurements noise
Definition at line 187 of file uwb_positioning.c.
Referenced by uwb_positioning_init(), uwb_positioning_update_ekf_q(), uwb_positioning_update_ekf_r_dist(), and uwb_positioning_update_ekf_r_speed().
|
extern |
Definition at line 188 of file uwb_positioning.c.
Referenced by uwb_positioning_init(), uwb_positioning_update_ekf_q(), uwb_positioning_update_ekf_r_dist(), and uwb_positioning_update_ekf_r_speed().
|
extern |
Definition at line 189 of file uwb_positioning.c.
Referenced by uwb_positioning_init(), uwb_positioning_update_ekf_q(), uwb_positioning_update_ekf_r_dist(), and uwb_positioning_update_ekf_r_speed().
|
extern |
enable EKF filtering
Definition at line 186 of file uwb_positioning.c.
Referenced by check_and_compute_data(), uwb_positioning_init(), and uwb_positioning_periodic().
 1.15.0