|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Flight Dynamics Model (FDM) for NPS using the new Gazebo (gz-sim). More...
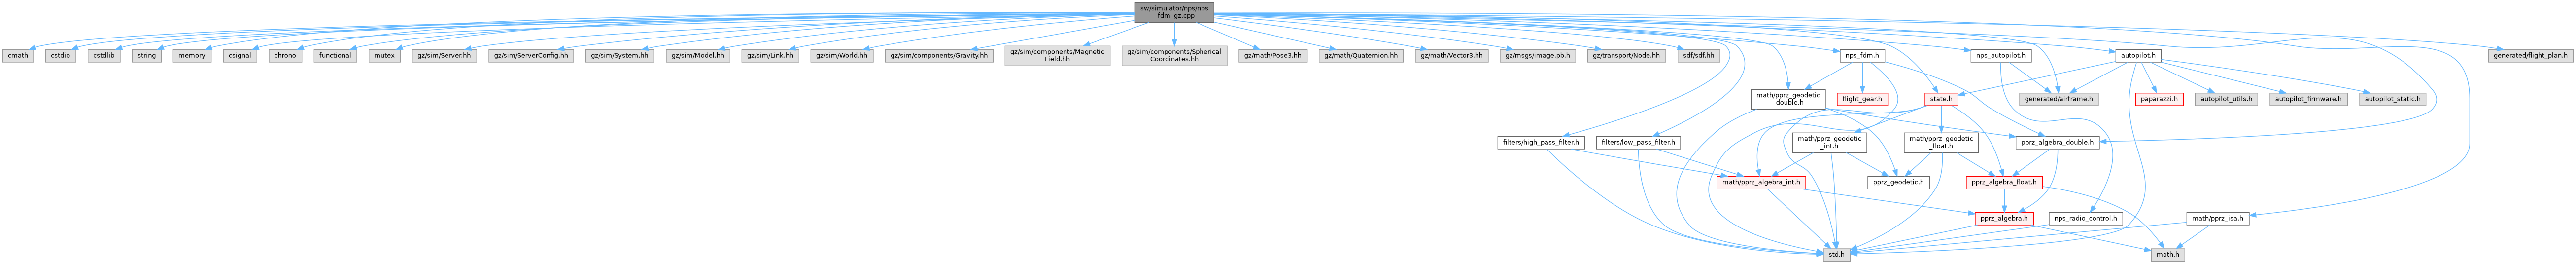
#include <cmath>#include <cstdio>#include <cstdlib>#include <string>#include <memory>#include <csignal>#include <chrono>#include <functional>#include <mutex>#include <gz/sim/Server.hh>#include <gz/sim/ServerConfig.hh>#include <gz/sim/System.hh>#include <gz/sim/Model.hh>#include <gz/sim/Link.hh>#include <gz/sim/World.hh>#include <gz/sim/components/Gravity.hh>#include <gz/sim/components/MagneticField.hh>#include <gz/sim/components/SphericalCoordinates.hh>#include <gz/math/Pose3.hh>#include <gz/math/Quaternion.hh>#include <gz/math/Vector3.hh>#include <gz/msgs/image.pb.h>#include <gz/transport/Node.hh>#include <sdf/sdf.hh>#include "nps_fdm.h"#include "nps_autopilot.h"#include "generated/airframe.h"#include "generated/flight_plan.h"#include "autopilot.h"#include "math/pprz_isa.h"#include "math/pprz_algebra_double.h"#include "math/pprz_geodetic_double.h"#include "filters/low_pass_filter.h"#include "filters/high_pass_filter.h"#include "state.h" Include dependency graph for nps_fdm_gz.cpp:
Go to the source code of this file.
Data Structures | |
| struct | gazebo_actuators_t |
| class | PaparazziSystem |
| gz-sim System that connects NPS with the simulation. More... | |
Macros | |
| #define | NPS_GAZEBO_WORLD "empty.world" |
| #define | NPS_GAZEBO_AC_NAME "bebop" |
Functions | |
| static void | init_gazebo (void) |
| Start an embedded gz-sim server. | |
| static void | gazebo_read (void) |
| Fill the fdm struct from the gz state. | |
| static void | gazebo_write (double act_commands[], int commands_nb) |
| Compute the motor thrusts and torques from the normalized commands [0, 1], with NPS_ACTUATOR_THRUSTS [N] and NPS_ACTUATOR_TORQUES [Nm] from the airframe. | |
| static gz::math::Quaterniond | local_to_enu (void) |
| static struct NedCoor_d | ned_of_enu (const gz::math::Vector3d &enu) |
| static struct DoubleVect3 | vect_ned_of_enu (const gz::math::Vector3d &enu) |
| static struct DoubleVect3 | frd_of_flu (const gz::math::Vector3d &flu) |
| static struct DoubleRates | rates_frd_of_flu (const gz::math::Vector3d &flu) |
| static struct DoubleEulers | eulers_ned_of_enu (const gz::math::Quaterniond &q_enu) |
| NED to FRD euler angles from the ENU to FLU attitude. | |
| void | nps_fdm_init (double dt) |
| NPS FDM rover init. | |
| void | nps_fdm_run_init_step (void) |
| void | nps_fdm_run_step (bool launch, double *act_commands, int commands_nb) |
| Minimum complexity flight dynamic model In legacy Paparazzi simulator, was implemented in OCaml and correspond to the 'sim' target. | |
| void | nps_fdm_set_wind (double speed, double dir) |
| void | nps_fdm_set_wind_ned (double wind_north, double wind_east, double wind_down) |
| void | nps_fdm_set_turbulence (double wind_speed, int turbulence_severity) |
| void | nps_fdm_set_temperature (double temp, double h) |
| Set temperature in degrees Celcius at given height h above MSL. | |
Variables | ||
| struct NpsFdm | fdm | |
| Holds all necessary NPS FDM state information. | ||
| static struct gazebo_actuators_t | gazebo_actuators = { NPS_ACTUATOR_NAMES, NPS_ACTUATOR_THRUSTS, NPS_ACTUATOR_TORQUES, { }, { }, { } } | |
| struct { | ||
| gz::math::Pose3d | pose | |
| gz::math::Vector3d | linear_vel | |
| gz::math::Vector3d | angular_vel | |
| gz::math::Vector3d | gravity | |
| gz::math::Vector3d | magnetic_field | |
| double | heading_offset | |
| heading of <spherical_coordinates> [rad] | ||
| double | sim_time | |
| [s] | ||
| bool | valid | |
| } | gz_state | |
| Simulation state, written in PaparazziSystem::PostUpdate (gz local frame, FLU body) | ||
| struct { | ||
| double | thrusts [NPS_COMMANDS_NB] | |
| double | torques [NPS_COMMANDS_NB] | |
| } | gz_cmd | |
| Actuator commands in the body frame of each motor link, read in PaparazziSystem::PreUpdate. | ||
| static std::unique_ptr< gz::sim::Server > | server | |
| static std::shared_ptr< PaparazziSystem > | pprz_system | |
Flight Dynamics Model (FDM) for NPS using the new Gazebo (gz-sim).
Port of the Gazebo Classic FDM (nps_fdm_gazebo.cpp) to gz-sim (Harmonic and newer). It uses the same models, worlds and airframe defines.
gz-sim only gives access to the simulation state from a System plugin. The PaparazziSystem below is added to an embedded gz::sim::Server, which is stepped from nps_fdm_run_step with a blocking RunOnce call in the same thread, so the shared structs need no locking.
Frames: the worlds keep the Gazebo Classic workaround of a 180 degree heading offset in <spherical_coordinates> (Classic used a WSU frame). With that offset the local x, y, z axes of a world are East, North, Up, as in Gazebo Classic. The heading offset is applied here directly, so the result does not depend on the (changing) frame conventions of gz-math.
Cameras (NPS_SIMULATE_VIDEO) are rendered by the gz Sensors system, which NPS adds to the world. Their images are received over gz-transport and passed to the video thread as with Gazebo Classic.
Not ported yet: the laser range array (NPS_SIMULATE_LASER_RANGE_ARRAY) and the sonar.
Definition in file nps_fdm_gz.cpp.
| struct gazebo_actuators_t |
Definition at line 114 of file nps_fdm_gazebo.cpp.
Collaboration diagram for gazebo_actuators_t:| Data Fields | ||
|---|---|---|
| struct FirstOrderHighPass | highpass[NPS_COMMANDS_NB] | |
| struct FirstOrderLowPass | lowpass[NPS_COMMANDS_NB] | |
| double | max_ang_momentum[NPS_COMMANDS_NB] | |
| string | names[NPS_COMMANDS_NB] | |
| string | names[NPS_COMMANDS_NB] | |
| double | thrusts[NPS_COMMANDS_NB] | |
| double | torques[NPS_COMMANDS_NB] | |
| #define NPS_GAZEBO_AC_NAME "bebop" |
Definition at line 126 of file nps_fdm_gz.cpp.
| #define NPS_GAZEBO_WORLD "empty.world" |
Definition at line 123 of file nps_fdm_gz.cpp.
|
static |
NED to FRD euler angles from the ENU to FLU attitude.
Definition at line 303 of file nps_fdm_gz.cpp.
References foo, DoubleEulers::phi, DoubleEulers::psi, and DoubleEulers::theta.
Referenced by gazebo_read().
Here is the caller graph for this function:
|
static |
Definition at line 290 of file nps_fdm_gz.cpp.
References foo.
Referenced by gazebo_read().
Here is the caller graph for this function:Fill the fdm struct from the gz state.
As with Gazebo Classic, the atmosphere is not simulated and the AHRS and INS should be bypassed (NPS_BYPASS_AHRS, NPS_BYPASS_INS).
Definition at line 496 of file nps_fdm_gz.cpp.
References NpsFdm::agl, NpsFdm::airspeed, LlaCoor_f::alt, NpsFdm::aoa, NpsFdm::body_accel, NpsFdm::body_ecef_accel, NpsFdm::body_ecef_rotvel, NpsFdm::body_ecef_vel, NpsFdm::body_inertial_accel, NpsFdm::body_inertial_rotvel, double_quat_of_eulers(), NpsFdm::dynamic_pressure, LtpDef_d::ecef, LtpDef_f::ecef, NpsFdm::ecef_ecef_accel, NpsFdm::ecef_ecef_vel, ecef_of_ned_point_d(), ecef_of_ned_vect_d(), NpsFdm::ecef_pos, NpsFdm::elevator, eulers_ned_of_enu(), fdm, NpsFdm::flap, foo, frd_of_flu(), gc_of_gd_lat_d(), gz_state, LtpDef_f::hmsl, NpsFdm::hmsl, LlaCoor_d::lat, LlaCoor_f::lat, NpsFdm::left_aileron, LtpDef_f::lla, lla_of_ecef_d(), NpsFdm::lla_pos, NpsFdm::lla_pos_geoc, NpsFdm::lla_pos_geod, NpsFdm::lla_pos_pprz, local_to_enu(), LlaCoor_f::lon, NpsFdm::ltp_ecef_accel, NpsFdm::ltp_ecef_vel, NpsFdm::ltp_g, NpsFdm::ltp_h, LtpDef_f::ltp_of_ecef, NpsFdm::ltp_to_body_eulers, NpsFdm::ltp_to_body_quat, NpsFdm::ltpprz_ecef_accel, NpsFdm::ltpprz_ecef_vel, NpsFdm::ltpprz_pos, NpsFdm::ltpprz_to_body_eulers, NpsFdm::ltpprz_to_body_quat, FloatRMat::m, ned_of_enu(), State::ned_origin_f, NpsFdm::num_engines, pprz_isa_pressure_of_height(), PPRZ_ISA_SEA_LEVEL_PRESSURE, NpsFdm::pressure, NpsFdm::pressure_sl, rates_frd_of_flu(), NpsFdm::right_aileron, NpsFdm::rudder, NpsFdm::sideslip, state, NpsFdm::temperature, NpsFdm::time, vect_ned_of_enu(), NpsFdm::wind, EcefCoor_d::x, EcefCoor_f::x, EcefCoor_f::y, NedCoor_d::z, and EcefCoor_f::z.
Referenced by nps_fdm_run_step().
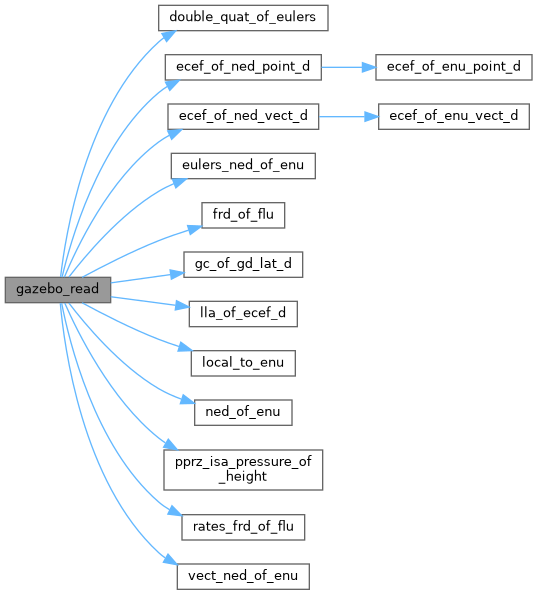
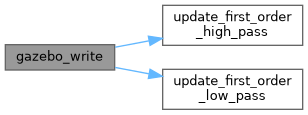
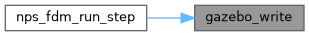
Here is the call graph for this function: Here is the caller graph for this function:Compute the motor thrusts and torques from the normalized commands [0, 1], with NPS_ACTUATOR_THRUSTS [N] and NPS_ACTUATOR_TORQUES [Nm] from the airframe.
Definition at line 591 of file nps_fdm_gz.cpp.
References autopilot, foo, gazebo_actuators, gz_cmd, gazebo_actuators_t::highpass, gazebo_actuators_t::lowpass, gazebo_actuators_t::max_ang_momentum, pprz_autopilot::motors_on, NPS_COMMANDS_NB, gazebo_actuators_t::thrusts, gazebo_actuators_t::torques, update_first_order_high_pass(), and update_first_order_low_pass().
Referenced by nps_fdm_run_step().
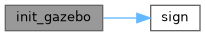
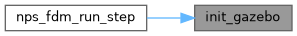
Here is the call graph for this function: Here is the caller graph for this function:Start an embedded gz-sim server.
The vehicle NPS_GAZEBO_AC_NAME is inserted in the world NPS_GAZEBO_WORLD, both found in conf/simulator/gazebo and sw/ext/tudelft_gazebo_models, and the merged world is written to var/gazebo.world (as with Gazebo Classic).
Definition at line 371 of file nps_fdm_gz.cpp.
References dir, fdm, foo, gazebo_actuators, NpsFdm::init_dt, gazebo_actuators_t::max_ang_momentum, MOTOR_MIXING_YAW_COEF, NPS_COMMANDS_NB, NPS_GAZEBO_AC_NAME, NPS_GAZEBO_WORLD, pprz_system, server, sign(), gazebo_actuators_t::torques, and yaw_coef.
Referenced by nps_fdm_run_step().
Here is the call graph for this function: Here is the caller graph for this function:
|
static |
Definition at line 273 of file nps_fdm_gz.cpp.
Referenced by gazebo_read().
Here is the caller graph for this function:
|
static |
Definition at line 278 of file nps_fdm_gz.cpp.
References foo.
Referenced by gazebo_read().
Here is the caller graph for this function:NPS FDM rover init.
NPS FDM rover init.
| dt |
Definition at line 315 of file nps_fdm_gz.cpp.
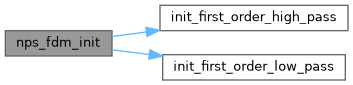
References NpsFdm::curr_dt, fdm, foo, gazebo_actuators, gazebo_actuators_t::highpass, NpsFdm::init_dt, init_first_order_high_pass(), init_first_order_low_pass(), gazebo_actuators_t::lowpass, gazebo_actuators_t::max_ang_momentum, NpsFdm::nan_count, and NPS_COMMANDS_NB.
Here is the call graph for this function:Definition at line 338 of file nps_fdm_gz.cpp.
Minimum complexity flight dynamic model In legacy Paparazzi simulator, was implemented in OCaml and correspond to the 'sim' target.
Johnson, E.N., Fontaine, S.G., and Kahn, A.D., “Minimum Complexity Uninhabited Air Vehicle Guidance And Flight Control System,” Proceedings of the 20th Digital Avionics Systems Conference, 2001. http://www.ae.gatech.edu/~ejohnson/JohnsonFontaineKahn.pdf
Johnson, E.N. and Fontaine, S.G., “Use Of Flight Simulation To Complement Flight Testing Of Low-Cost UAVs,” Proceedings of the AIAA Modeling and Simulation Technology Conference, 2001. http://www.ae.gatech.edu/~ejohnson/AIAA%202001-4059.pdf
Minimum complexity flight dynamic model In legacy Paparazzi simulator, was implemented in OCaml and correspond to the 'sim' target.
| launch | |
| act_commands | |
| commands_nb |
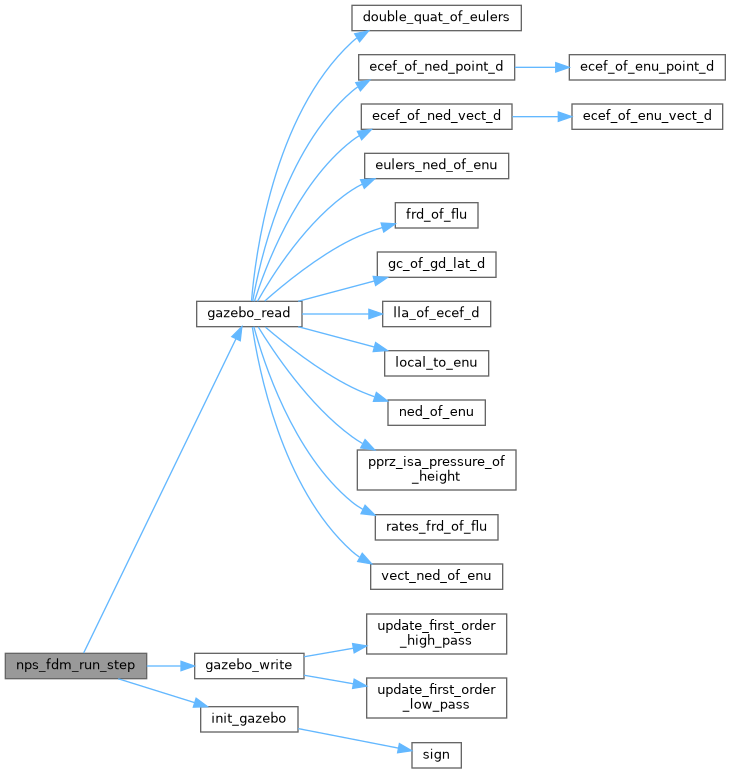
Definition at line 343 of file nps_fdm_gz.cpp.
References foo, gazebo_read(), gazebo_write(), init_gazebo(), and server.
Here is the call graph for this function:Set temperature in degrees Celcius at given height h above MSL.
Definition at line 362 of file nps_fdm_gz.cpp.
Definition at line 360 of file nps_fdm_gz.cpp.
Definition at line 357 of file nps_fdm_gz.cpp.
Definition at line 358 of file nps_fdm_gz.cpp.
|
static |
Definition at line 296 of file nps_fdm_gz.cpp.
References foo.
Referenced by gazebo_read().
Here is the caller graph for this function:
|
static |
Definition at line 284 of file nps_fdm_gz.cpp.
References foo.
Referenced by gazebo_read().
Here is the caller graph for this function:| struct NpsFdm fdm |
Holds all necessary NPS FDM state information.
Definition at line 130 of file nps_fdm_gz.cpp.
Referenced by gazebo_read(), init_gazebo(), and nps_fdm_init().
|
static |
Definition at line 141 of file nps_fdm_gz.cpp.
Referenced by PaparazziSystem::FindModel(), gazebo_write(), init_gazebo(), and nps_fdm_init().
| struct { ... } gz_cmd |
Actuator commands in the body frame of each motor link, read in PaparazziSystem::PreUpdate.
Referenced by gazebo_write(), and PaparazziSystem::PreUpdate().
| struct { ... } gz_state |
Simulation state, written in PaparazziSystem::PostUpdate (gz local frame, FLU body)
Referenced by gazebo_read(), local_to_enu(), and PaparazziSystem::PostUpdate().
|
static |
Definition at line 264 of file nps_fdm_gz.cpp.
Referenced by init_gazebo().
|
static |
Definition at line 263 of file nps_fdm_gz.cpp.
Referenced by init_gazebo(), and nps_fdm_run_step().
 1.9.8