|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "modules/guidance/trajectories/gvf_traj.h"Go to the source code of this file.
Data Structures | |
| struct | gvf_ell_par |
Functions | |
| bool | nav_gvf_ellipse_wp (uint8_t wp, float a, float b, float alpha) |
| bool | nav_gvf_ellipse_XY (float x, float y, float a, float b, float alpha) |
Variables | |
| gvf_ell_par | gvf_ellipse_par |
| struct gvf_ell_par |
Definition at line 36 of file nav_ellipse.h.
| Data Fields | ||
|---|---|---|
| float | a | |
| float | alpha | |
| float | b | |
| float | ke | |
| float | kn | |
|
extern |
Definition at line 103 of file nav_ellipse.c.
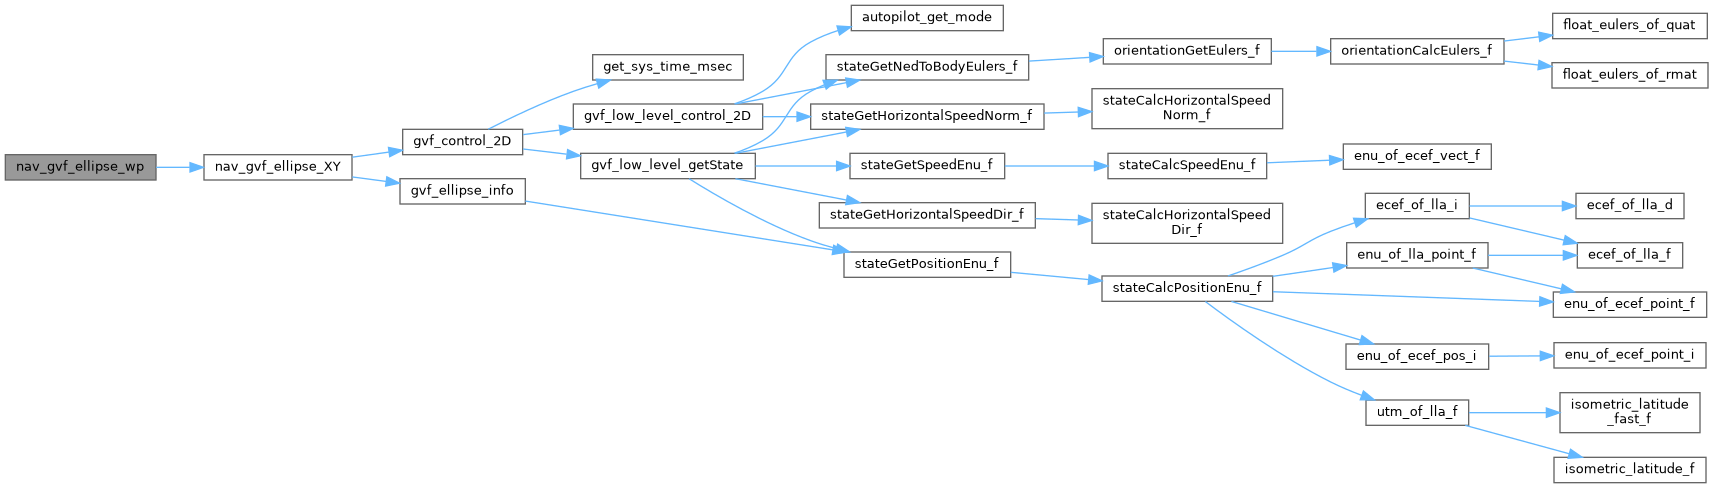
References alpha, b, gvf_p_len_wps, gvf_trajectory, nav_gvf_ellipse_XY(), WaypointX, and WaypointY.
|
extern |
Definition at line 64 of file nav_ellipse.c.
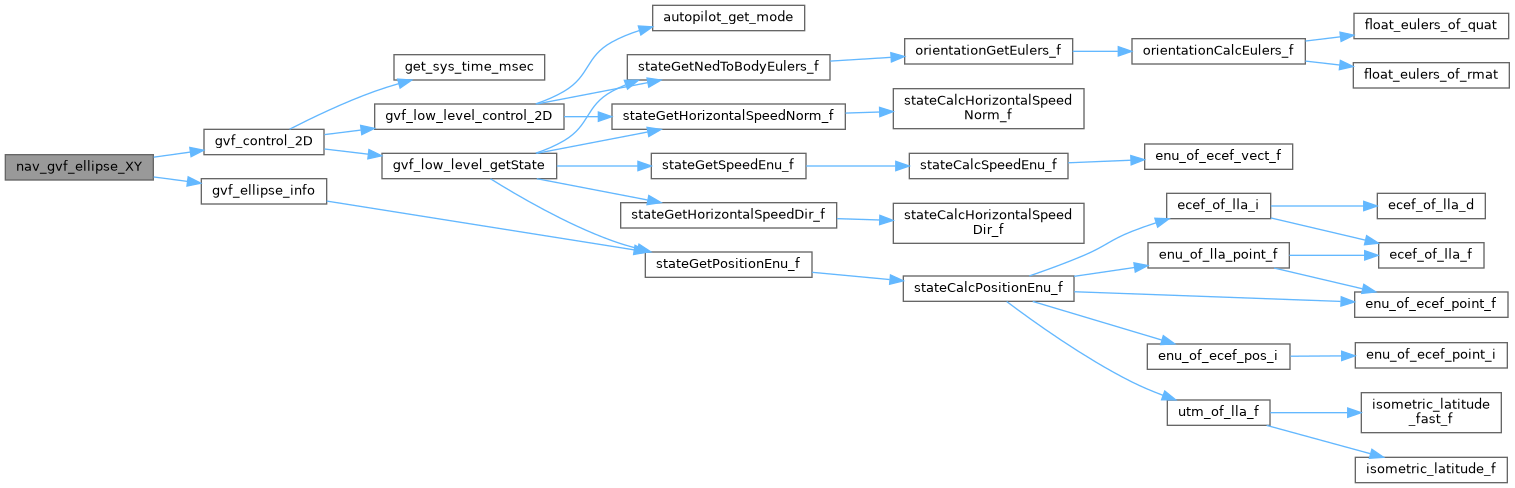
References alpha, b, gvf_control, gvf_control_2D(), gvf_ellipse_info(), gvf_ellipse_par, gvf_p_len_wps, and gvf_trajectory.
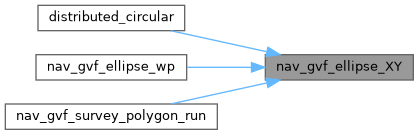
Referenced by distributed_circular(), nav_gvf_ellipse_wp(), and nav_gvf_survey_polygon_run().
|
extern |
 1.15.0