|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Guidance controller for planes in rotorcraft firmware using basic PID controller no airspeed control. More...
Go to the source code of this file.
Data Structures | |
| struct | GuidancePlane |
Functions | |
| void | guidance_plane_init (void) |
| void | guidance_plane_enter (void) |
| struct StabilizationSetpoint | guidance_plane_attitude_from_nav (bool in_flight) |
| run horizontal control loop for position and speed control | |
| struct ThrustSetpoint | guidance_plane_thrust_from_nav (bool in_flight) |
| run vertical control loop for position and speed control | |
Variables | |
| struct GuidancePlane | guidance_plane |
| Guidance PID structyre. | |
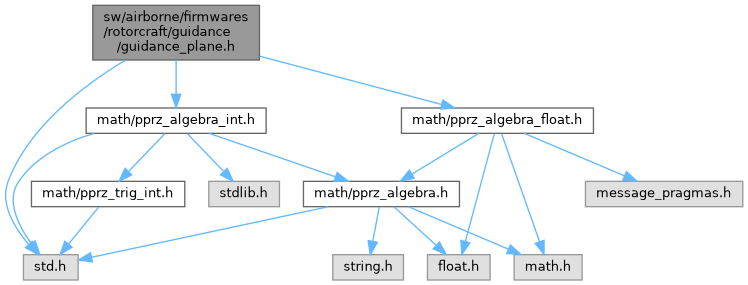
Guidance controller for planes in rotorcraft firmware using basic PID controller no airspeed control.
Definition in file guidance_plane.h.
| struct GuidancePlane |
Definition at line 39 of file guidance_plane.h.
| Data Fields | ||
|---|---|---|
| float | altitude_setpoint | |
| float | climb_kp | |
| float | climb_max_setpoint | |
| float | climb_setpoint | |
| float | climb_throttle_increment | |
| float | course_kd | |
| float | course_kp | |
| float | course_pre_bank_correction | |
| float | course_setpoint | |
| float | cruise_throttle | |
| float | p_kd | |
| float | p_ki | |
| float | p_kp | |
| float | pitch_cmd | |
| float | pitch_max_setpoint | |
| float | pitch_min_setpoint | |
| float | pitch_of_vz | |
| float | pitch_trim | |
| float | roll_cmd | |
| float | roll_max_setpoint | |
| float | t_kd | |
| float | t_ki | |
| float | t_kp | |
| int32_t | throttle_cmd | |
|
extern |
run horizontal control loop for position and speed control
Definition at line 128 of file guidance_plane.c.
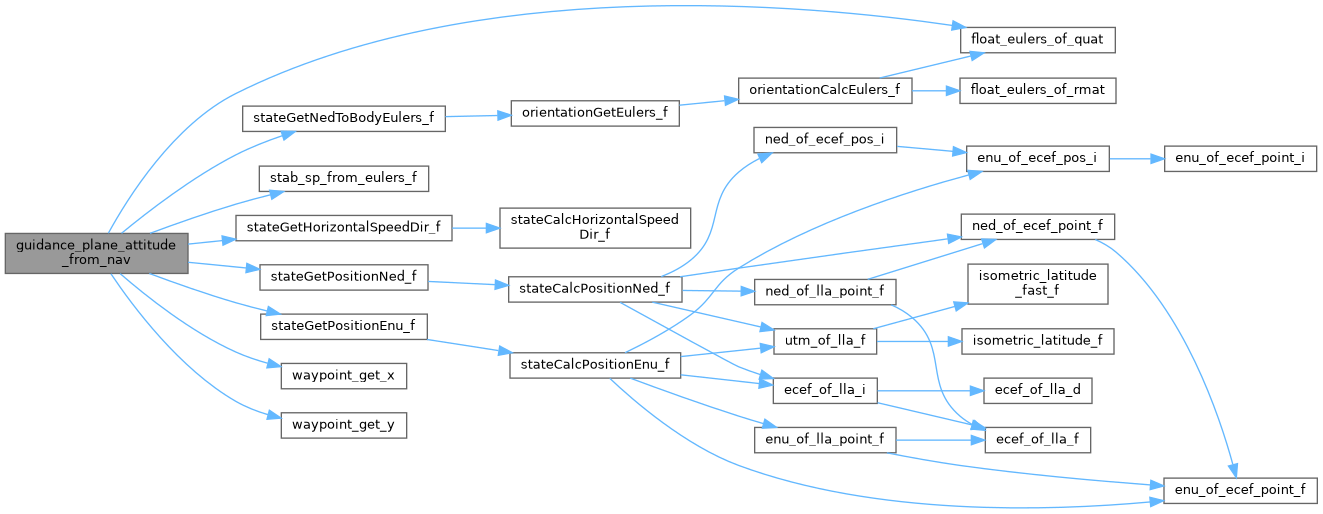
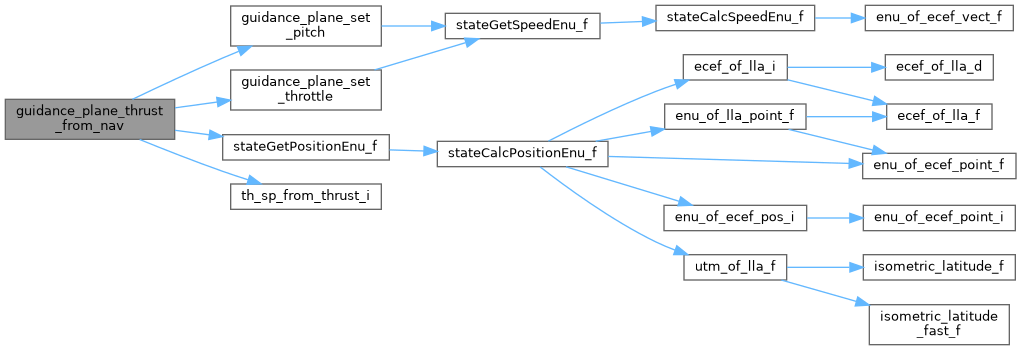
References guidance_plane_attitude_from_nav(), if(), nav, NAV_HORIZONTAL_MODE_ATTITUDE, NAV_HORIZONTAL_MODE_GUIDED, NAV_HORIZONTAL_MODE_NONE, and UNUSED.
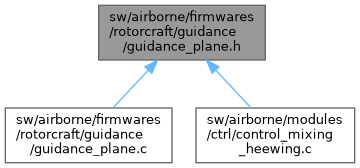
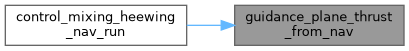
Referenced by control_mixing_heewing_nav_run(), and guidance_plane_attitude_from_nav().
|
extern |
Definition at line 276 of file guidance_plane.c.
References pitch_sum_err, and throttle_sum_err.
|
extern |
Definition at line 90 of file guidance_plane.c.
References GUIDANCE_PLANCE_COURSE_PRE_BANK, guidance_plane, GUIDANCE_PLANE_CLIMB_THROTTLE_INCREMENT, GUIDANCE_PLANE_MAX_BANK, GUIDANCE_PLANE_MAX_CLIMB, GUIDANCE_PLANE_MAX_PITCH, GUIDANCE_PLANE_MIN_PITCH, GUIDANCE_PLANE_PITCH_OF_VZ, GUIDANCE_PLANE_PITCH_TRIM, pitch_sum_err, and throttle_sum_err.
|
extern |
run vertical control loop for position and speed control
Definition at line 253 of file guidance_plane.c.
References guidance_plane, guidance_plane_set_pitch(), guidance_plane_set_throttle(), guidance_plane_thrust_from_nav(), if(), nav, NAV_VERTICAL_MODE_CLIMB, and NAV_VERTICAL_MODE_MANUAL.
Referenced by control_mixing_heewing_nav_run(), and guidance_plane_thrust_from_nav().
|
extern |
Guidance PID structyre.
Definition at line 73 of file guidance_plane.c.
Referenced by control_mixing_heewing_nav_run(), guidance_plane_init(), guidance_plane_set_pitch(), guidance_plane_set_throttle(), and guidance_plane_thrust_from_nav().
 1.15.0