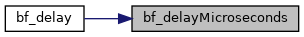|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
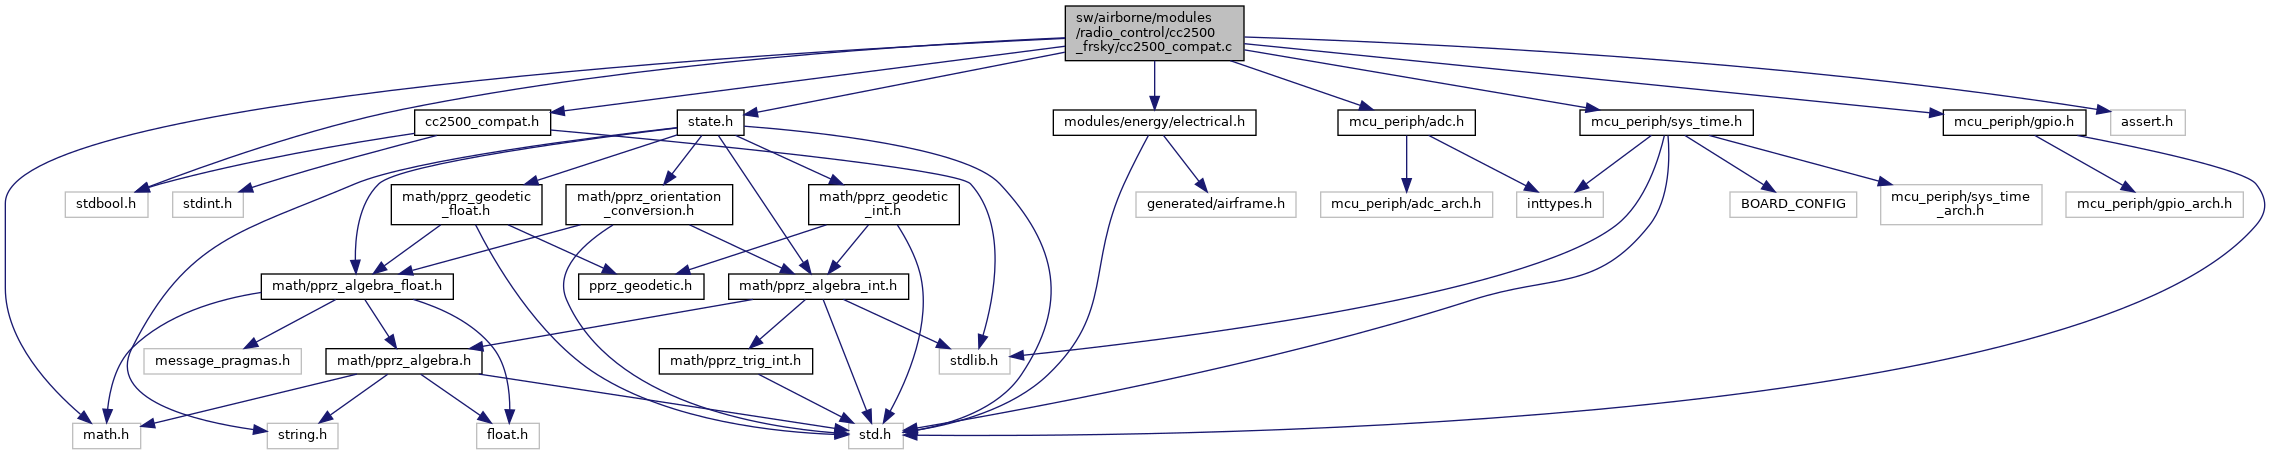
#include "cc2500_compat.h"#include "state.h"#include "mcu_periph/adc.h"#include "mcu_periph/gpio.h"#include "mcu_periph/sys_time.h"#include "modules/energy/electrical.h"#include <stdbool.h>#include <assert.h>#include <math.h>Go to the source code of this file.
Macros | |
| #define | M_PI_FLOAT 3.14159265358979323846f |
Variables | |
| struct attitude_t | bf_attitude = { { 0, 0, 0 } } |
| struct pidProfile_s * | currentPidProfile |
| controlRateConfig_t * | currentControlRateProfile |
| #define M_PI_FLOAT 3.14159265358979323846f |
Definition at line 54 of file cc2500_compat.c.
Referenced by pt1FilterGain().
Definition at line 95 of file cc2500_compat.c.
References electrical.
| void bf_delay | ( | timeMs_t | ms | ) |
Definition at line 81 of file cc2500_compat.c.
References bf_delayMicroseconds().
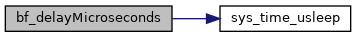
| void bf_delayMicroseconds | ( | timeUs_t | us | ) |
Definition at line 77 of file cc2500_compat.c.
References sys_time_usleep().
Referenced by bf_delay().
| bool bf_featureIsEnabled | ( | const uint32_t | mask | ) |
Definition at line 47 of file cc2500_compat.c.
References FEATURE_RX_SPI, and FEATURE_TELEMETRY.
| int32_t bf_getAmperage | ( | void | ) |
Definition at line 193 of file cc2500_compat.c.
References electrical.
| uint8_t bf_getBatteryCellCount | ( | void | ) |
Definition at line 185 of file cc2500_compat.c.
| uint16_t bf_getBatteryVoltage | ( | void | ) |
Definition at line 181 of file cc2500_compat.c.
References electrical.
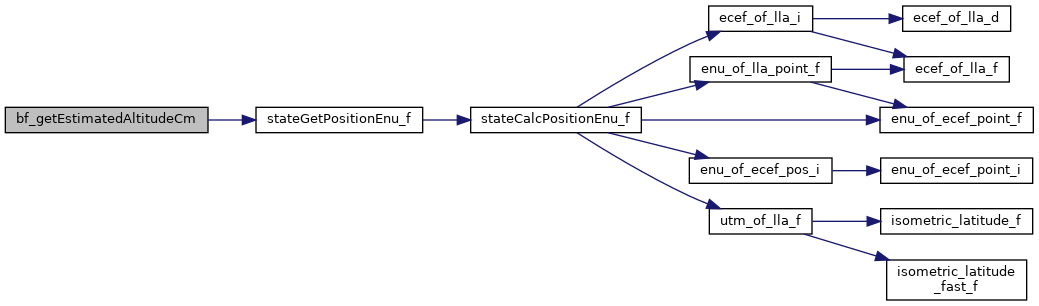
| int32_t bf_getEstimatedAltitudeCm | ( | void | ) |
Definition at line 163 of file cc2500_compat.c.
References stateGetPositionEnu_f(), and EnuCoor_f::z.
| int16_t bf_getEstimatedVario | ( | void | ) |
Definition at line 167 of file cc2500_compat.c.
References stateGetSpeedEnu_f(), and EnuCoor_f::z.
| uint16_t bf_getLegacyBatteryVoltage | ( | void | ) |
Definition at line 177 of file cc2500_compat.c.
References electrical.
| int32_t bf_getMAhDrawn | ( | void | ) |
Definition at line 197 of file cc2500_compat.c.
References electrical.
| void bf_IOConfigGPIO | ( | IO_t | io, |
| enum ioconfig_t | cfg ) |
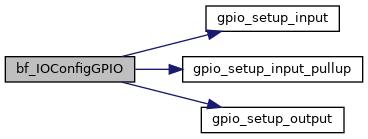
Definition at line 119 of file cc2500_compat.c.
References gpio_setup_input(), gpio_setup_input_pullup(), gpio_setup_output(), IOCFG_IN_FLOATING, IOCFG_IPU, IOCFG_OUT_PP, gpio_t::pin, and gpio_t::port.
Definition at line 109 of file cc2500_compat.c.
| void bf_IOHi | ( | IO_t | io | ) |
Definition at line 142 of file cc2500_compat.c.
References gpio_t::hi, gpio_t::pin, and gpio_t::port.
Definition at line 113 of file cc2500_compat.c.
| void bf_IOLo | ( | IO_t | io | ) |
Definition at line 147 of file cc2500_compat.c.
References gpio_t::lo, gpio_t::pin, and gpio_t::port.
| bool bf_IORead | ( | IO_t | gpio | ) |
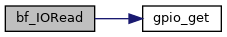
Definition at line 137 of file cc2500_compat.c.
References gpio_get(), gpio_t::pin, and gpio_t::port.
| void bf_IOToggle | ( | IO_t | io | ) |
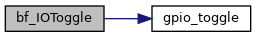
Definition at line 152 of file cc2500_compat.c.
References gpio_toggle(), gpio_t::pin, and gpio_t::port.
| bool bf_isAmperageConfigured | ( | void | ) |
Definition at line 189 of file cc2500_compat.c.
References TRUE.
| bool bf_isBatteryVoltageConfigured | ( | void | ) |
Definition at line 173 of file cc2500_compat.c.
References TRUE.
| timeUs_t bf_micros | ( | void | ) |
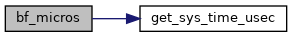
Definition at line 85 of file cc2500_compat.c.
References get_sys_time_usec().
| timeMs_t bf_millis | ( | void | ) |
Definition at line 89 of file cc2500_compat.c.
References get_sys_time_msec().
| bool bf_rxSpiDeviceInit | ( | void | ) |
Definition at line 103 of file cc2500_compat.c.
References TRUE.
| float pt1FilterApply | ( | pt1Filter_t * | filter, |
| float | input ) |
Definition at line 70 of file cc2500_compat.c.
References pt1Filter_s::k, and pt1Filter_s::state.
Referenced by setRssi().
| float pt1FilterGain | ( | float | f_cut, |
| float | dT ) |
Definition at line 55 of file cc2500_compat.c.
References M_PI_FLOAT.
Referenced by rxInit().
| void pt1FilterInit | ( | pt1Filter_t * | filter, |
| float | k ) |
Definition at line 61 of file cc2500_compat.c.
References pt1Filter_s::k, and pt1Filter_s::state.
Referenced by rxInit().
| void pt1FilterUpdateCutoff | ( | pt1Filter_t * | filter, |
| float | k ) |
Definition at line 66 of file cc2500_compat.c.
References pt1Filter_s::k.
| struct attitude_t bf_attitude = { { 0, 0, 0 } } |
Definition at line 39 of file cc2500_compat.c.
| controlRateConfig_t* currentControlRateProfile |
Definition at line 159 of file cc2500_compat.c.
Referenced by processSmartPortTelemetry().
| struct pidProfile_s* currentPidProfile |
Definition at line 43 of file cc2500_compat.c.
Referenced by processSmartPortTelemetry().
 1.15.0