|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Filters altitude and climb rate for fixedwings. More...
Go to the source code of this file.
Data Structures | |
| struct | InsAltFloat |
| Ins implementation state (altitude, float). More... | |
Functions | |
| void | ins_alt_float_init (void) |
| void | ins_alt_float_update_baro (float pressure) |
Variables | |
| struct InsAltFloat | ins_altf |
Filters altitude and climb rate for fixedwings.
Definition in file ins_alt_float.h.
| struct InsAltFloat |
Ins implementation state (altitude, float).
Definition at line 37 of file ins_alt_float.h.
|
extern |
Definition at line 101 of file ins_alt_float.c.
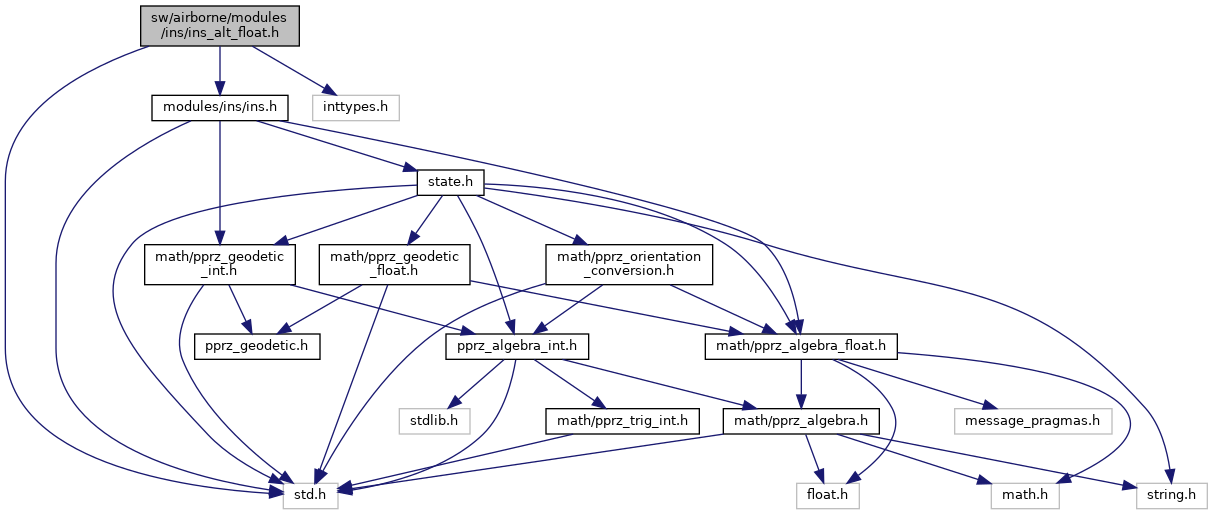
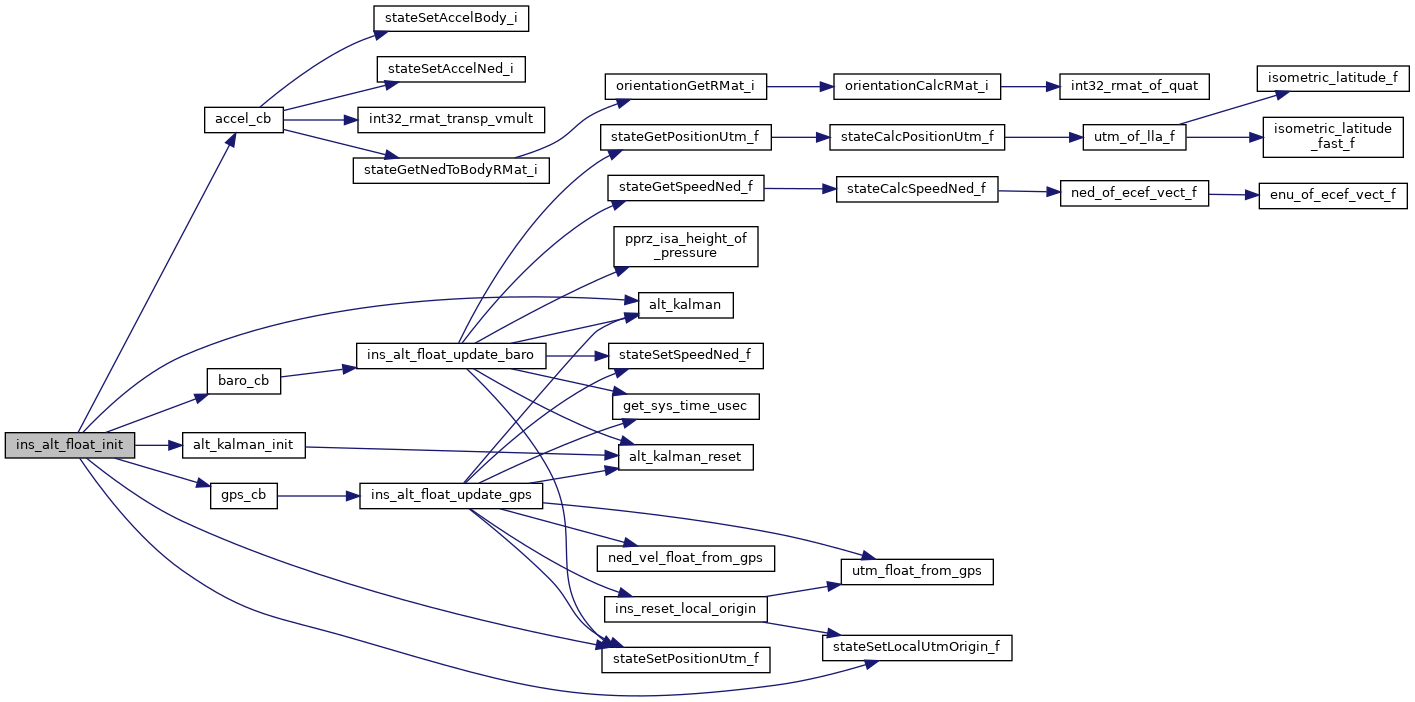
References ABI_BROADCAST, accel_cb(), accel_ev, alt_kalman(), alt_kalman_init(), baro_cb(), baro_ev, gps_cb(), gps_ev, INS_ALT_BARO_ID, INS_ALT_GPS_ID, INS_ALT_IMU_ID, ins_altf, nav_utm_east0, nav_utm_north0, nav_utm_zone0, reset_cb(), reset_ev, stateSetLocalUtmOrigin_f(), and stateSetPositionUtm_f().
|
extern |
Definition at line 172 of file ins_alt_float.c.
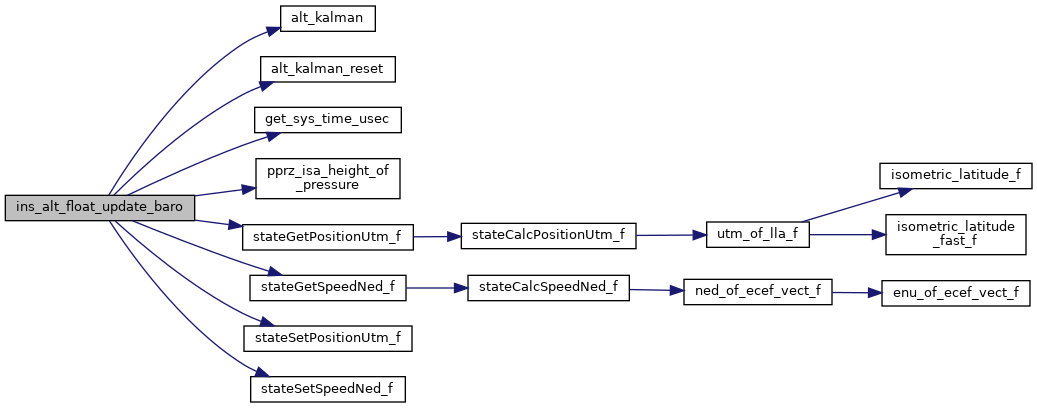
References UtmCoor_f::alt, alt_kalman(), alt_kalman_reset(), get_sys_time_usec(), ground_alt, ins_altf, last_ts, pprz_isa_height_of_pressure(), stateGetPositionUtm_f(), stateGetSpeedNed_f(), stateSetPositionUtm_f(), stateSetSpeedNed_f(), UTM_COPY, and NedCoor_f::z.
Referenced by baro_cb().
|
extern |
Definition at line 54 of file ins_alt_float.c.
Referenced by alt_kalman(), ins_alt_float_init(), ins_alt_float_update_baro(), ins_alt_float_update_gps(), reset_ref(), and reset_vertical_ref().
 1.15.0