|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
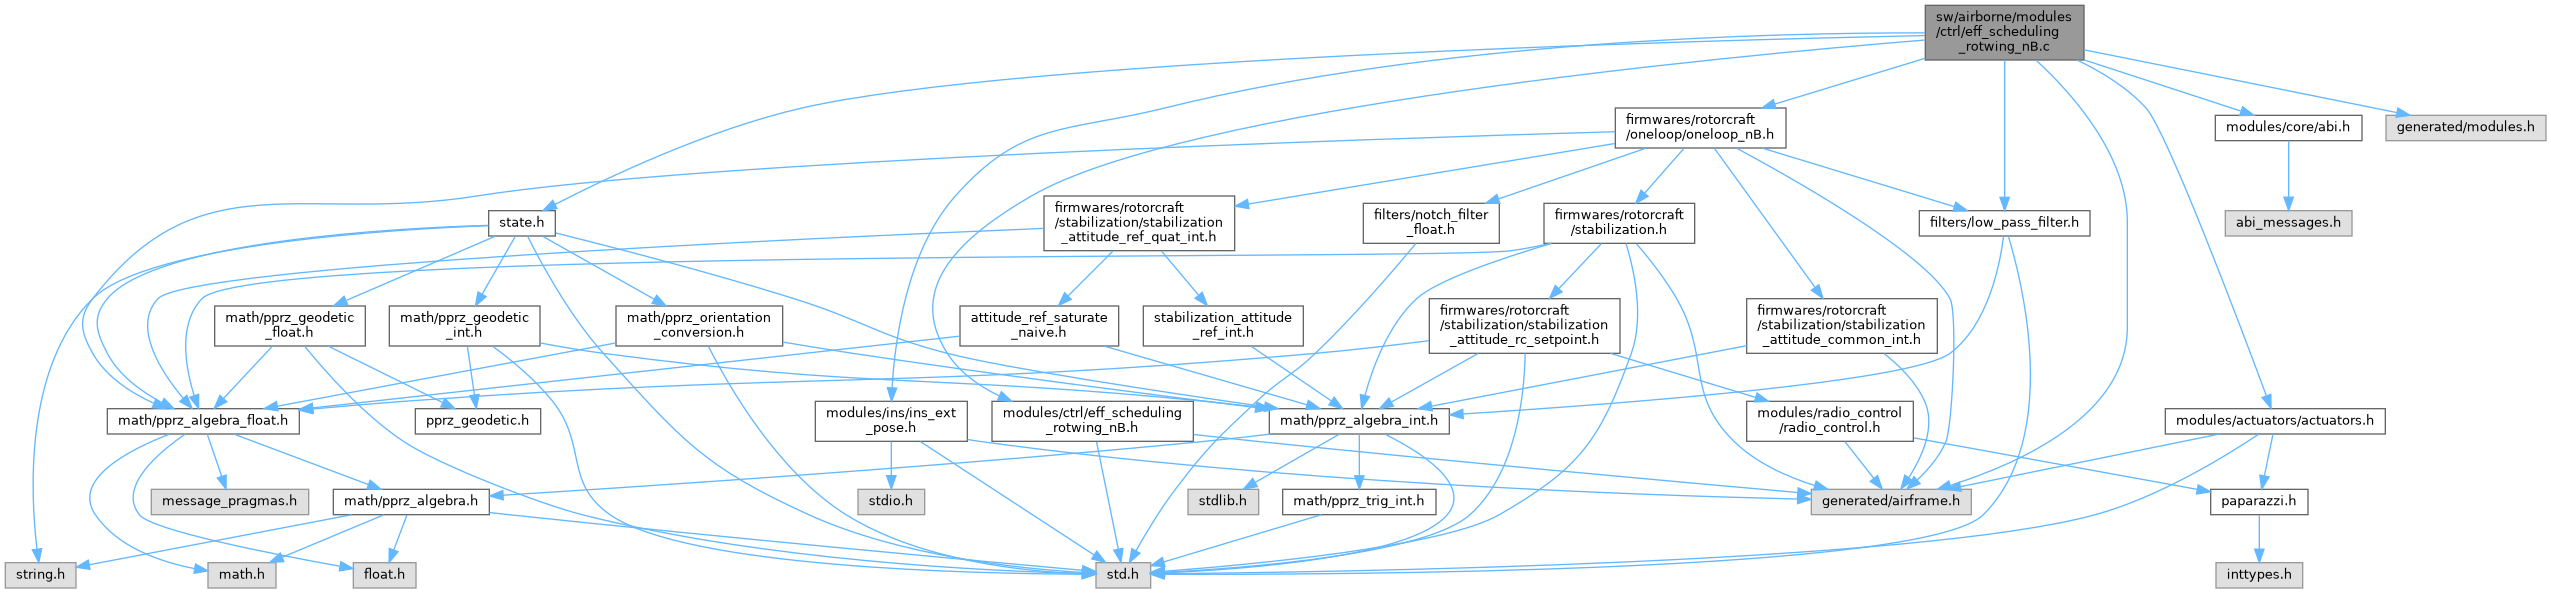
#include "modules/ctrl/eff_scheduling_rotwing_nB.h"#include "generated/airframe.h"#include "state.h"#include "modules/actuators/actuators.h"#include "modules/core/abi.h"#include "filters/low_pass_filter.h"#include "modules/ins/ins_ext_pose.h"#include "firmwares/rotorcraft/oneloop/oneloop_nB.h"#include "generated/modules.h"Go to the source code of this file.
Macros | |
| #define | FORCE_ONELOOP |
| #define | WING_ROTATION_CAN_ROTWING_ID ABI_BROADCAST |
| ABI binding wing position data. | |
Functions | |
| void | eff_scheduling_rotwing_update_wing_angle (void) |
| void | eff_scheduling_rotwing_update_airspeed (void) |
| void | ele_pref_sched (void) |
| void | update_attitude (void) |
| void | sum_EFF_MAT_RW (void) |
| Function that sums g1 and g2 to obtain the g1_g2 matrix. | |
| void | init_RW_Model (void) |
| void | calc_G1_G2_RW (void) |
| float | calc_thrust_curve (float k1, float k2, float k3, float u) |
| float | calc_thrust_curve_d (float k1, float k2, float u) |
| void | calc_all_thrust_curve (void) |
| void | init_all_thrust_curve (void) |
| static void | wing_position_cb (uint8_t sender_id UNUSED, struct act_feedback_t *pos_msg, uint8_t num_act) |
| void | eff_scheduling_rotwing_init (void) |
| void | eff_scheduling_rotwing_periodic (void) |
Variables | |
| float | actuator_state_filt_vect [EFF_MAT_COLS_NB] = {0} |
| bool | manual_roll = false |
| bool | manual_pitch = false |
| bool | manual_yaw = false |
| float | G2_RW [EFF_MAT_COLS_NB] = {0} |
| float | G1_RW [EFF_MAT_ROWS_NB][EFF_MAT_COLS_NB] = {0} |
| float | EFF_MAT_RW [EFF_MAT_ROWS_NB][EFF_MAT_COLS_NB] = {0} |
| float | I_inv [3][3] = {0} |
| static float | flt_cut_a = 1.0e-6 |
| static float | flt_cut_ap = 2.0e-6 |
| static float | flt_cut = 1.0e-6 |
| struct FloatEulers | eulers_zxy_RW_EFF |
| static Butterworth2LowPass | skew_filt |
| static Butterworth2LowPass | phi_filt |
| static Butterworth2LowPass | theta_filt |
| static Butterworth2LowPass | psi_filt |
| int | G2_on = 0 |
| bool | airspeed_fake_on = false |
| float | airspeed_fake = 0.0 |
| float | ele_eff = 19.36 |
| float | roll_eff = 8.9 |
| float | yaw_eff = 0.237 |
| float | ele_min = 0.0 |
| struct RW_Model | RW |
| int | thrust_curve = 1.0 |
| float | temp_mQ_k = 1.37 |
| static abi_event | wing_position_ev |
| float | skew_meas = 0.0 |
| static float | sim_time = 0.0f |
Definition in file eff_scheduling_rotwing_nB.c.
| #define FORCE_ONELOOP |
Definition at line 34 of file eff_scheduling_rotwing_nB.c.
| #define WING_ROTATION_CAN_ROTWING_ID ABI_BROADCAST |
ABI binding wing position data.
Definition at line 111 of file eff_scheduling_rotwing_nB.c.
| void calc_all_thrust_curve | ( | void | ) |
Definition at line 499 of file eff_scheduling_rotwing_nB.c.
References actuator_state_1l, calc_thrust_curve_d(), RW, RW_G_SCALE, temp_mQ_k, and thrust_curve.
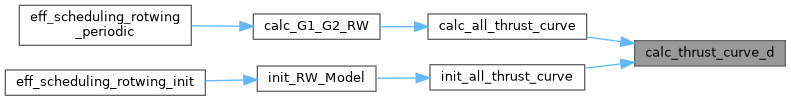
Referenced by calc_G1_G2_RW().
| void calc_G1_G2_RW | ( | void | ) |
Definition at line 256 of file eff_scheduling_rotwing_nB.c.
References calc_all_thrust_curve(), G1_RW, G2_on, G2_RW, I_inv, RW, RW_ap, RW_aq, RW_ar, and RW_aZ.
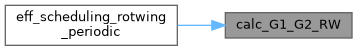
Referenced by eff_scheduling_rotwing_periodic().
| float calc_thrust_curve | ( | float | k1, |
| float | k2, | ||
| float | k3, | ||
| float | u ) |
Definition at line 489 of file eff_scheduling_rotwing_nB.c.
Referenced by init_all_thrust_curve().
| float calc_thrust_curve_d | ( | float | k1, |
| float | k2, | ||
| float | u ) |
Definition at line 493 of file eff_scheduling_rotwing_nB.c.
Referenced by calc_all_thrust_curve(), and init_all_thrust_curve().
| void eff_scheduling_rotwing_init | ( | void | ) |
Definition at line 130 of file eff_scheduling_rotwing_nB.c.
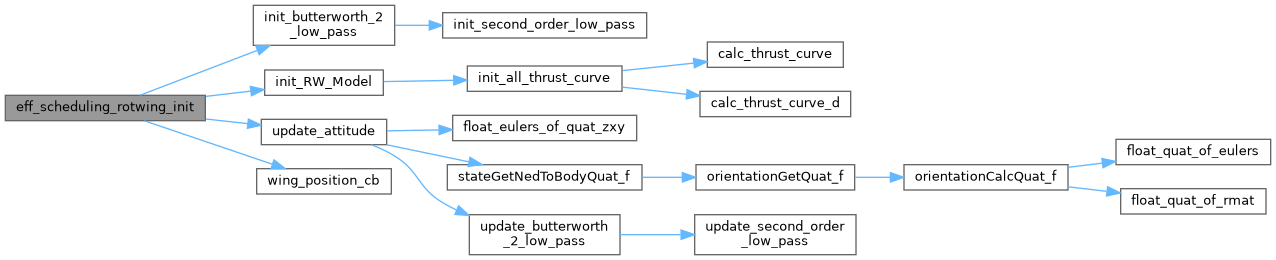
References eff_scheduling_rotwing_init(), init_butterworth_2_low_pass(), init_RW_Model(), phi_filt, psi_filt, skew_filt, theta_filt, update_attitude(), wing_position_cb(), wing_position_ev, and WING_ROTATION_CAN_ROTWING_ID.
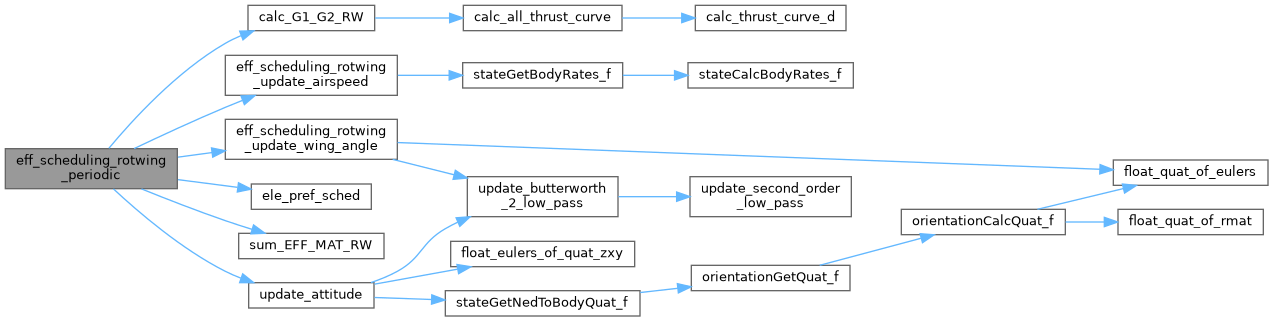
| void eff_scheduling_rotwing_periodic | ( | void | ) |
Definition at line 315 of file eff_scheduling_rotwing_nB.c.
References calc_G1_G2_RW(), eff_scheduling_rotwing_update_airspeed(), eff_scheduling_rotwing_update_wing_angle(), ele_pref_sched(), sum_EFF_MAT_RW(), and update_attitude().
|
inline |
Definition at line 460 of file eff_scheduling_rotwing_nB.c.
References airspeed_fake, airspeed_fake_on, FloatRates::r, RW, sim_time, and stateGetBodyRates_f().
Referenced by eff_scheduling_rotwing_periodic().
|
inline |
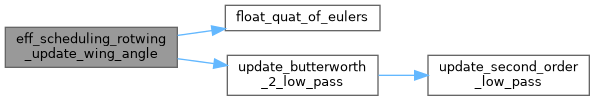
Definition at line 438 of file eff_scheduling_rotwing_nB.c.
References float_quat_of_eulers(), RW, skew_filt, skew_meas, and update_butterworth_2_low_pass().
Referenced by eff_scheduling_rotwing_periodic().
| void ele_pref_sched | ( | void | ) |
Definition at line 479 of file eff_scheduling_rotwing_nB.c.
References ELE_MAX_AS, ele_min, ELE_MIN_AS, RW, and ZERO_ELE_PPRZ.
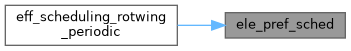
Referenced by eff_scheduling_rotwing_periodic().
| void init_all_thrust_curve | ( | void | ) |
Definition at line 532 of file eff_scheduling_rotwing_nB.c.
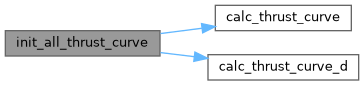
References calc_thrust_curve(), calc_thrust_curve_d(), and RW.
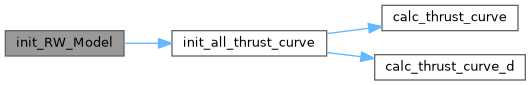
Referenced by init_RW_Model().
| void init_RW_Model | ( | void | ) |
Definition at line 144 of file eff_scheduling_rotwing_nB.c.
References ele_eff, init_all_thrust_curve(), RW, and RW_G_SCALE.
Referenced by eff_scheduling_rotwing_init().
| void sum_EFF_MAT_RW | ( | void | ) |
Function that sums g1 and g2 to obtain the g1_g2 matrix.
It also undoes the scaling that was done to make the values readable FIXME: make this function into a for loop to make it more adaptable to different configurations
Definition at line 332 of file eff_scheduling_rotwing_nB.c.
References COMMAND_PITCH, COMMAND_ROLL, EFF_MAT_COLS_NB, EFF_MAT_ROWS_NB, EFF_MAT_RW, flt_cut, flt_cut_a, flt_cut_ap, G1_RW, G2_RW, manual_pitch, manual_roll, manual_yaw, P, RW, RW_aD, RW_aE, RW_aN, RW_ap, RW_aq, RW_ar, RW_aZ, and RW_Model::T.
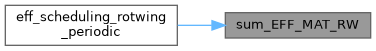
Referenced by eff_scheduling_rotwing_periodic().
| void update_attitude | ( | void | ) |
Definition at line 238 of file eff_scheduling_rotwing_nB.c.
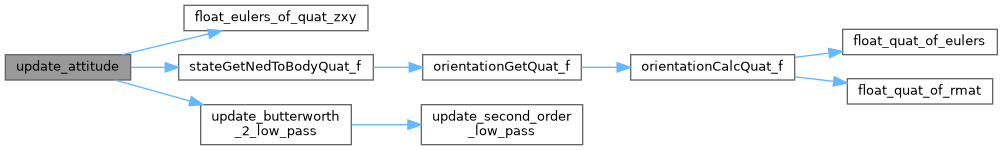
References eulers_zxy_RW_EFF, float_eulers_of_quat_zxy(), phi_filt, psi_filt, RW, stateGetNedToBodyQuat_f(), theta_filt, and update_butterworth_2_low_pass().
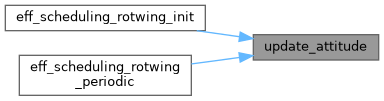
Referenced by eff_scheduling_rotwing_init(), and eff_scheduling_rotwing_periodic().
|
static |
Definition at line 117 of file eff_scheduling_rotwing_nB.c.
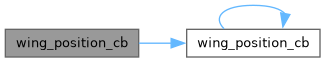
References skew_meas, UNUSED, and wing_position_cb().
| float actuator_state_filt_vect[EFF_MAT_COLS_NB] = {0} |
Definition at line 37 of file eff_scheduling_rotwing_nB.c.
| float airspeed_fake = 0.0 |
Definition at line 86 of file eff_scheduling_rotwing_nB.c.
Referenced by eff_scheduling_rotwing_update_airspeed().
| bool airspeed_fake_on = false |
Definition at line 85 of file eff_scheduling_rotwing_nB.c.
Referenced by eff_scheduling_rotwing_update_airspeed().
| float EFF_MAT_RW[EFF_MAT_ROWS_NB][EFF_MAT_COLS_NB] = {0} |
Definition at line 72 of file eff_scheduling_rotwing_nB.c.
| float ele_eff = 19.36 |
Definition at line 87 of file eff_scheduling_rotwing_nB.c.
Referenced by calc_G1_G2_RW(), and init_RW_Model().
| float ele_min = 0.0 |
Definition at line 90 of file eff_scheduling_rotwing_nB.c.
| struct FloatEulers eulers_zxy_RW_EFF |
Definition at line 78 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 76 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 74 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 75 of file eff_scheduling_rotwing_nB.c.
| float G1_RW[EFF_MAT_ROWS_NB][EFF_MAT_COLS_NB] = {0} |
Definition at line 71 of file eff_scheduling_rotwing_nB.c.
| int G2_on = 0 |
Definition at line 84 of file eff_scheduling_rotwing_nB.c.
| float G2_RW[EFF_MAT_COLS_NB] = {0} |
Definition at line 70 of file eff_scheduling_rotwing_nB.c.
| float I_inv[3][3] = {0} |
Definition at line 73 of file eff_scheduling_rotwing_nB.c.
| bool manual_pitch = false |
Definition at line 67 of file eff_scheduling_rotwing_nB.c.
| bool manual_roll = false |
Definition at line 66 of file eff_scheduling_rotwing_nB.c.
| bool manual_yaw = false |
Definition at line 68 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 80 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 82 of file eff_scheduling_rotwing_nB.c.
| float roll_eff = 8.9 |
Definition at line 88 of file eff_scheduling_rotwing_nB.c.
| struct RW_Model RW |
Definition at line 92 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 459 of file eff_scheduling_rotwing_nB.c.
Referenced by eff_scheduling_rotwing_update_airspeed().
|
static |
Definition at line 79 of file eff_scheduling_rotwing_nB.c.
Referenced by eff_scheduling_rotwing_init(), and eff_scheduling_rotwing_update_wing_angle().
| float skew_meas = 0.0 |
Definition at line 116 of file eff_scheduling_rotwing_nB.c.
Referenced by eff_scheduling_rotwing_update_wing_angle(), wing_position_cb(), and wing_position_cb().
| float temp_mQ_k = 1.37 |
Definition at line 95 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 81 of file eff_scheduling_rotwing_nB.c.
| int thrust_curve = 1.0 |
Definition at line 94 of file eff_scheduling_rotwing_nB.c.
|
static |
Definition at line 114 of file eff_scheduling_rotwing_nB.c.
| float yaw_eff = 0.237 |
Definition at line 89 of file eff_scheduling_rotwing_nB.c.
 1.15.0