|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Go to the source code of this file.
Functions | |
| void | nav_trinity_init (void) |
| Init function called by modules init. | |
| void | nav_trinity_setup (float init_x, float init_y, float init_z, int turn, float desired_radius, float vx, float vy, float vz) |
| Initialized the exploration with a first target point inside the cloud Called from flight plan or with mission parameters. | |
| bool | nav_trinity_run (void) |
| Navigation function Called by flight plan or mission run function. | |
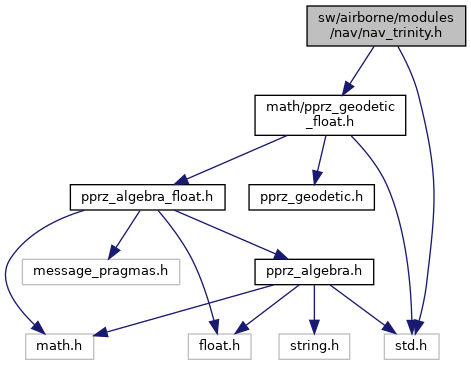
Definition in file nav_trinity.h.
|
extern |
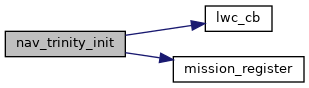
Init function called by modules init.
Definition at line 189 of file nav_trinity.c.
References DEFAULT_CIRCLE_RADIUS, lwc_cb(), lwc_ev, mission_register(), nav_trinity, NAV_TRINITY_LWC_ID, and TRINITY_ENTER.
|
extern |
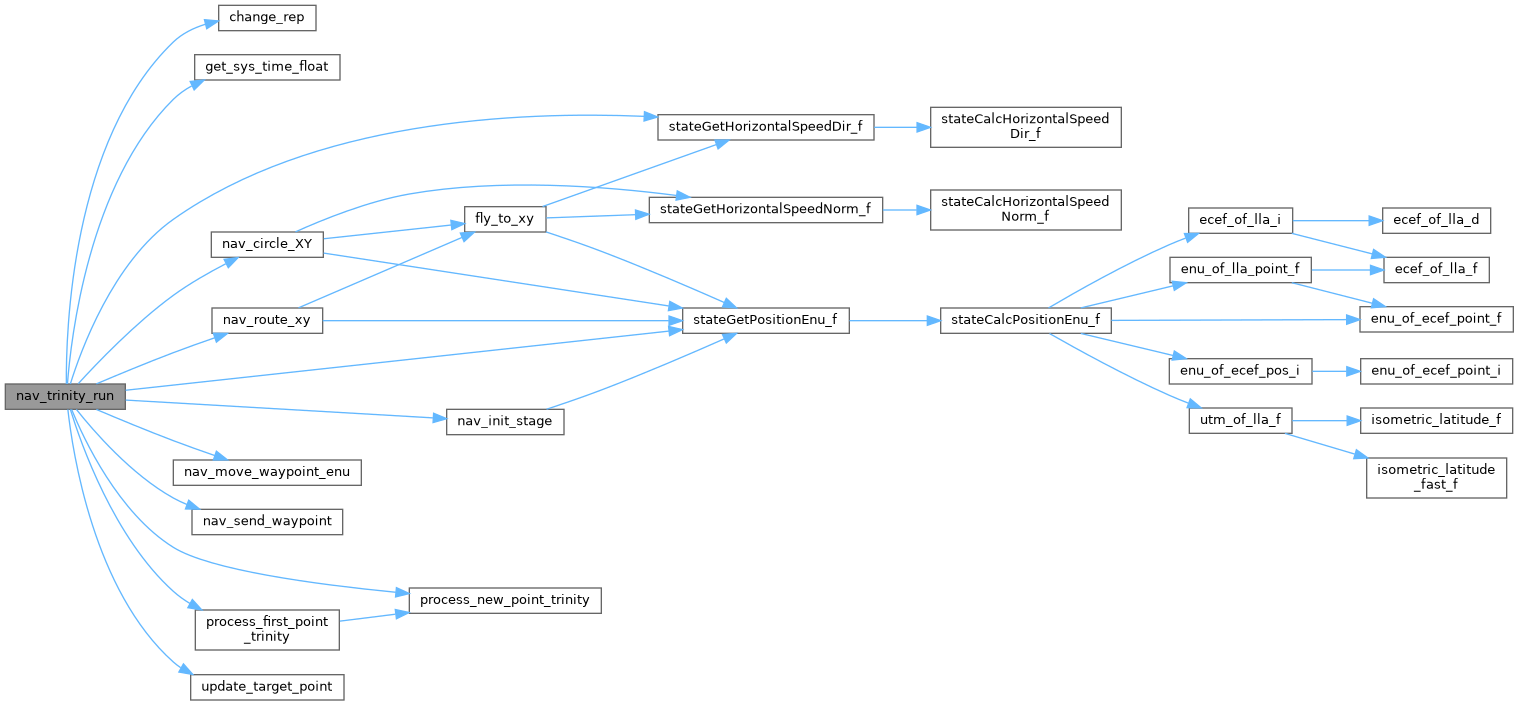
Navigation function Called by flight plan or mission run function.
Definition at line 230 of file nav_trinity.c.
References change_rep(), get_sys_time_float(), ground_alt, nav_circle_XY(), nav_dt, nav_init_stage(), nav_move_waypoint_enu(), nav_route_xy(), nav_send_waypoint(), nav_trinity, NAV_TRINITY_BORDER_FILTER, NAV_TRINITY_RECOVER_MAX_TURN, NavCircleCountNoRewind, NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, process_first_point_trinity(), process_new_point_trinity(), stateGetHorizontalSpeedDir_f(), stateGetPositionEnu_f(), TRINITY_ENTER, TRINITY_INSIDE, TRINITY_INSIDE_FIRST, TRINITY_OUTSIDE, TRINITY_OUTSIDE_START, TRINITY_RECOVER_INSIDE, TRINITY_RECOVER_OUTSIDE, TRINITY_RECOVER_START, update_target_point(), and VECT3_ADD.
|
extern |
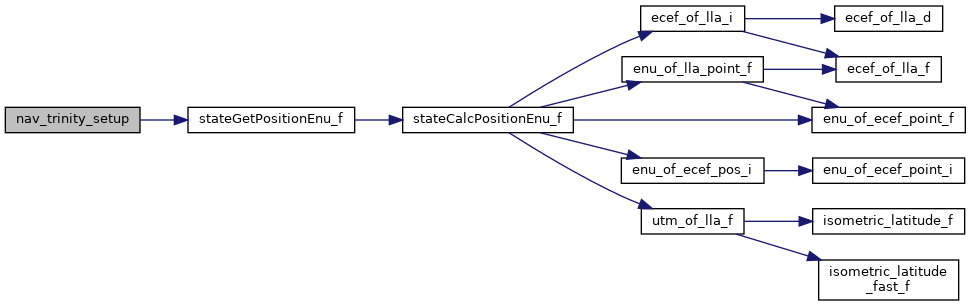
Initialized the exploration with a first target point inside the cloud Called from flight plan or with mission parameters.
Definition at line 205 of file nav_trinity.c.
References nav_dt, nav_trinity, stateGetPositionEnu_f(), TRINITY_ENTER, TRINITY_LEFT, TRINITY_RIGHT, and VECT3_ASSIGN.
 1.15.0