|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
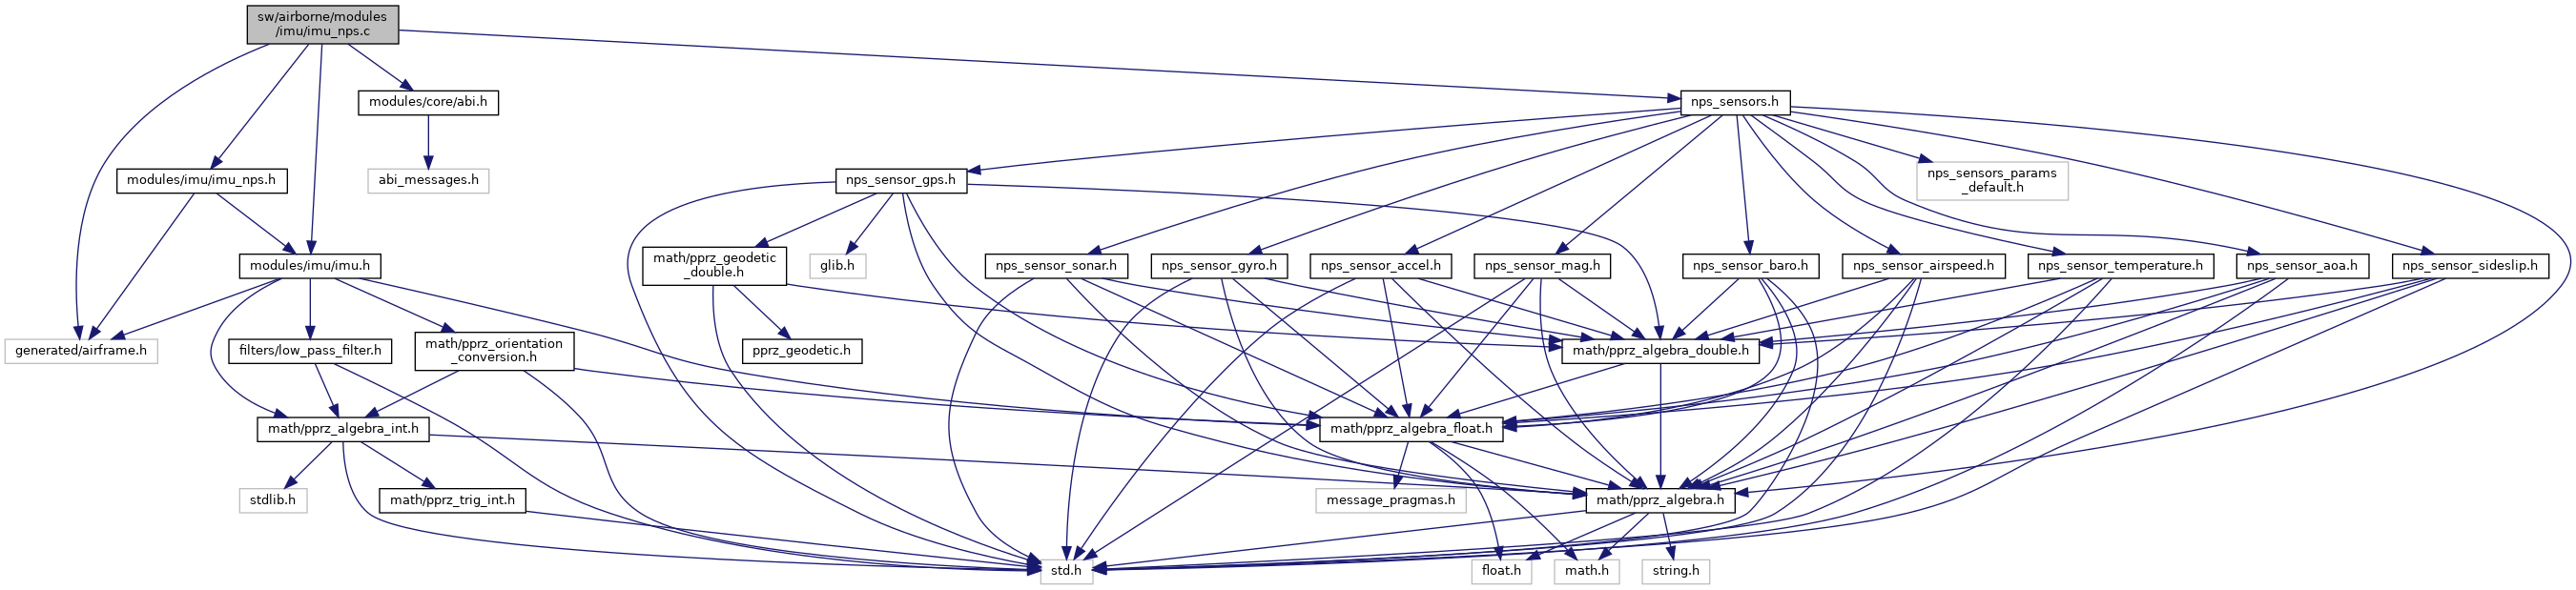
#include "modules/imu/imu_nps.h"#include "modules/imu/imu.h"#include "modules/core/abi.h"#include "generated/airframe.h"#include "nps_sensors.h"Go to the source code of this file.
Functions | |
| void | imu_nps_init (void) |
| void | imu_feed_gyro_accel (void) |
| void | imu_feed_mag (void) |
| void | imu_nps_event (void) |
Variables | |
| struct ImuNps | imu_nps |
| void imu_feed_gyro_accel | ( | void | ) |
Definition at line 50 of file imu_nps.c.
References imu_nps, RATES_ASSIGN, sensors, and VECT3_COPY.
Referenced by nps_autopilot_run_step().
| void imu_feed_mag | ( | void | ) |
Definition at line 61 of file imu_nps.c.
References imu_nps, sensors, and VECT3_COPY.
Referenced by nps_autopilot_run_step().
| void imu_nps_event | ( | void | ) |
Definition at line 68 of file imu_nps.c.
References get_sys_time_usec(), imu_nps, and IMU_NPS_ID.
| void imu_nps_init | ( | void | ) |
Definition at line 30 of file imu_nps.c.
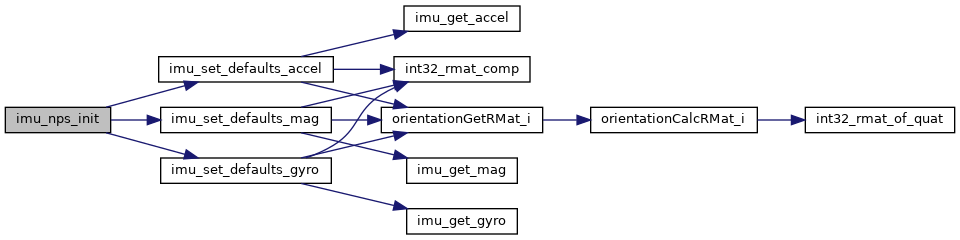
References ACCEL_FLOAT_OF_BFP, imu_nps, IMU_NPS_ID, imu_set_defaults_accel(), imu_set_defaults_gyro(), imu_set_defaults_mag(), MAG_FLOAT_OF_BFP, and RATE_FLOAT_OF_BFP.
| struct ImuNps imu_nps |
Definition at line 28 of file imu_nps.c.
Referenced by imu_feed_gyro_accel(), imu_feed_mag(), imu_nps_event(), and imu_nps_init().
 1.15.0