|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Driver for the Bebop (2) magnetometer, accelerometer and gyroscope. More...
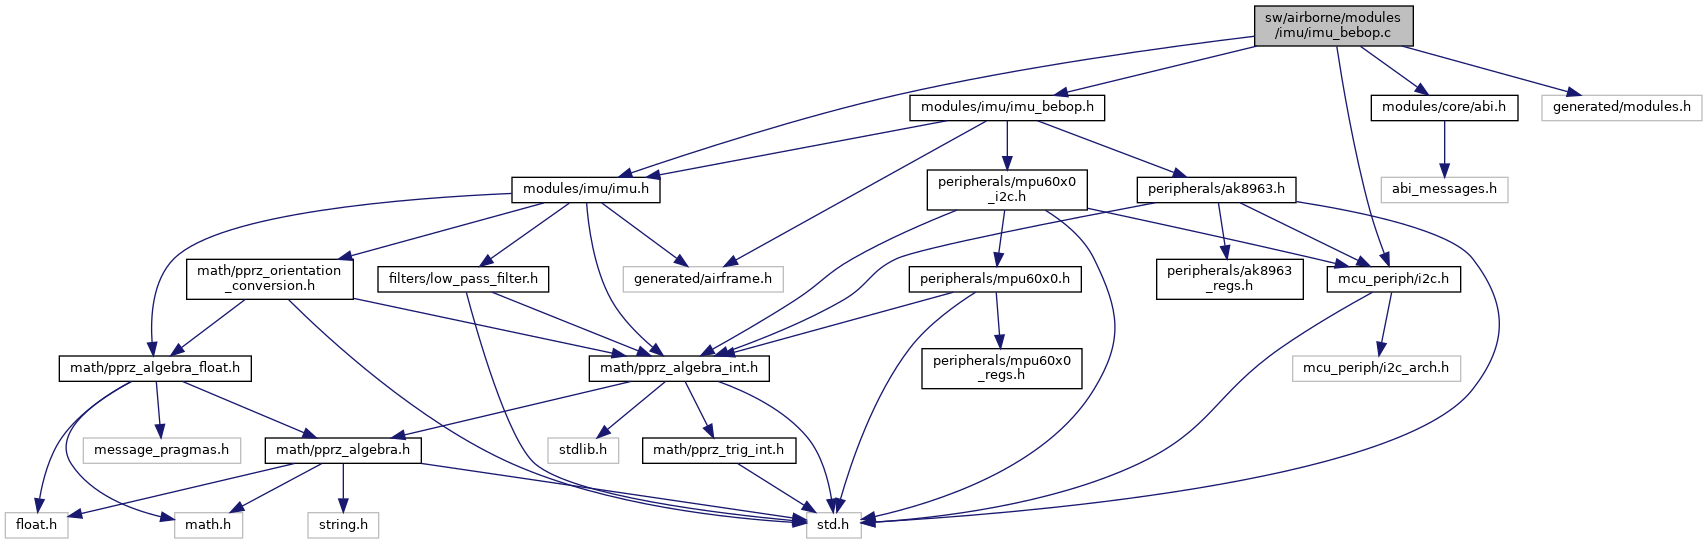
#include "modules/imu/imu_bebop.h"#include "modules/imu/imu.h"#include "modules/core/abi.h"#include "mcu_periph/i2c.h"#include "generated/modules.h"Go to the source code of this file.
Macros | |
| #define | BEBOP_MAG_I2C_DEV i2c1 |
| #define | BEBOP_MPU_I2C_DEV i2c2 |
| #define | BEBOP_LOWPASS_FILTER MPU60X0_DLPF_42HZ |
| #define | BEBOP_SMPLRT_DIV 9 |
Functions | |
| void | imu_bebop_init (void) |
| Navstik IMU initializtion of the MPU-60x0 and HMC58xx. | |
| void | imu_bebop_periodic (void) |
| Handle all the periodic tasks of the Navstik IMU components. | |
| void | imu_bebop_event (void) |
| Handle all the events of the Navstik IMU components. | |
Variables | |
| struct OrientationReps | imu_to_mag_bebop |
| IMU to magneto rotation. | |
| struct ImuBebop | imu_bebop |
| Basic Navstik IMU data. | |
Driver for the Bebop (2) magnetometer, accelerometer and gyroscope.
Definition in file imu_bebop.c.
| #define BEBOP_LOWPASS_FILTER MPU60X0_DLPF_42HZ |
Definition at line 50 of file imu_bebop.c.
Referenced by imu_bebop_init().
| #define BEBOP_MAG_I2C_DEV i2c1 |
Definition at line 36 of file imu_bebop.c.
Referenced by imu_bebop_init().
| #define BEBOP_MPU_I2C_DEV i2c2 |
Definition at line 41 of file imu_bebop.c.
Referenced by imu_bebop_init().
| #define BEBOP_SMPLRT_DIV 9 |
Definition at line 51 of file imu_bebop.c.
Referenced by imu_bebop_init().
| void imu_bebop_event | ( | void | ) |
Handle all the events of the Navstik IMU components.
When there is data available convert it to the correct axis and save it in the imu structure.
Definition at line 128 of file imu_bebop.c.
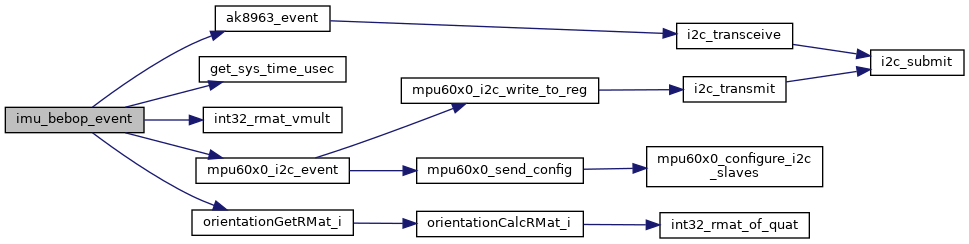
References ak8963_event(), get_sys_time_usec(), imu_bebop, IMU_BOARD_ID, imu_to_mag_bebop, int32_rmat_vmult(), mpu60x0_i2c_event(), orientationGetRMat_i(), RATES_ASSIGN, and VECT3_ASSIGN.
| void imu_bebop_init | ( | void | ) |
Navstik IMU initializtion of the MPU-60x0 and HMC58xx.
Definition at line 86 of file imu_bebop.c.
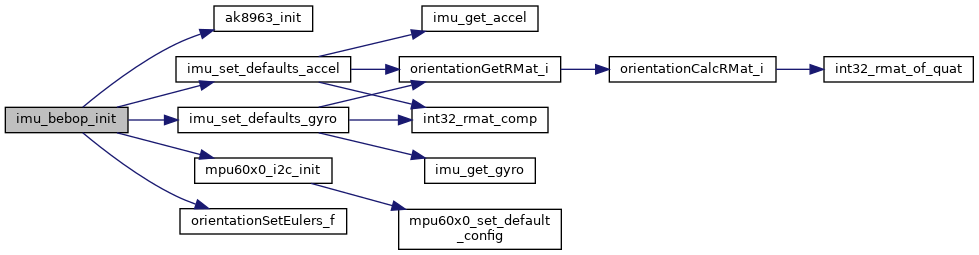
References AK8963_ADDR, ak8963_init(), BEBOP_ACCEL_RANGE, BEBOP_GYRO_RANGE, BEBOP_LOWPASS_FILTER, BEBOP_MAG_I2C_DEV, BEBOP_MPU_I2C_DEV, BEBOP_SMPLRT_DIV, imu_bebop, imu_bebop_init(), IMU_BOARD_ID, imu_set_defaults_accel(), imu_set_defaults_gyro(), imu_to_mag_bebop, MPU60X0_ACCEL_SENS_F, MPU60X0_ADDR, MPU60X0_GYRO_SENS_F, mpu60x0_i2c_init(), and orientationSetEulers_f().
Referenced by imu_bebop_init().
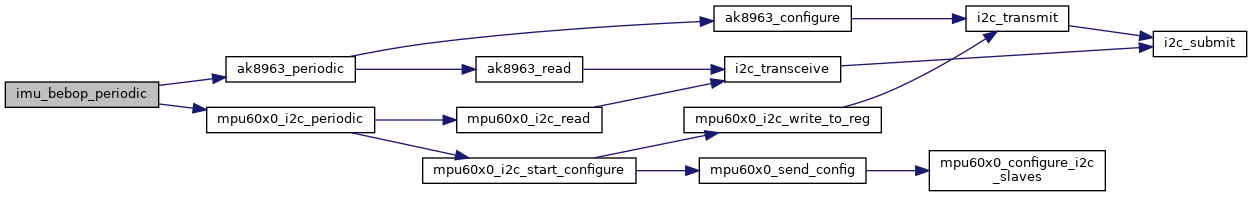
| void imu_bebop_periodic | ( | void | ) |
Handle all the periodic tasks of the Navstik IMU components.
Read the MPU60x0 every periodic call and the HMC58XX every 10th call.
Definition at line 115 of file imu_bebop.c.
References ak8963_periodic(), imu_bebop, and mpu60x0_i2c_periodic().
| struct ImuBebop imu_bebop |
Basic Navstik IMU data.
Definition at line 81 of file imu_bebop.c.
Referenced by imu_bebop_event(), imu_bebop_init(), imu_bebop_periodic(), and imu_temp_ctrl_periodic().
| struct OrientationReps imu_to_mag_bebop |
IMU to magneto rotation.
Definition at line 78 of file imu_bebop.c.
Referenced by imu_bebop_event(), and imu_bebop_init().
 1.15.0