|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
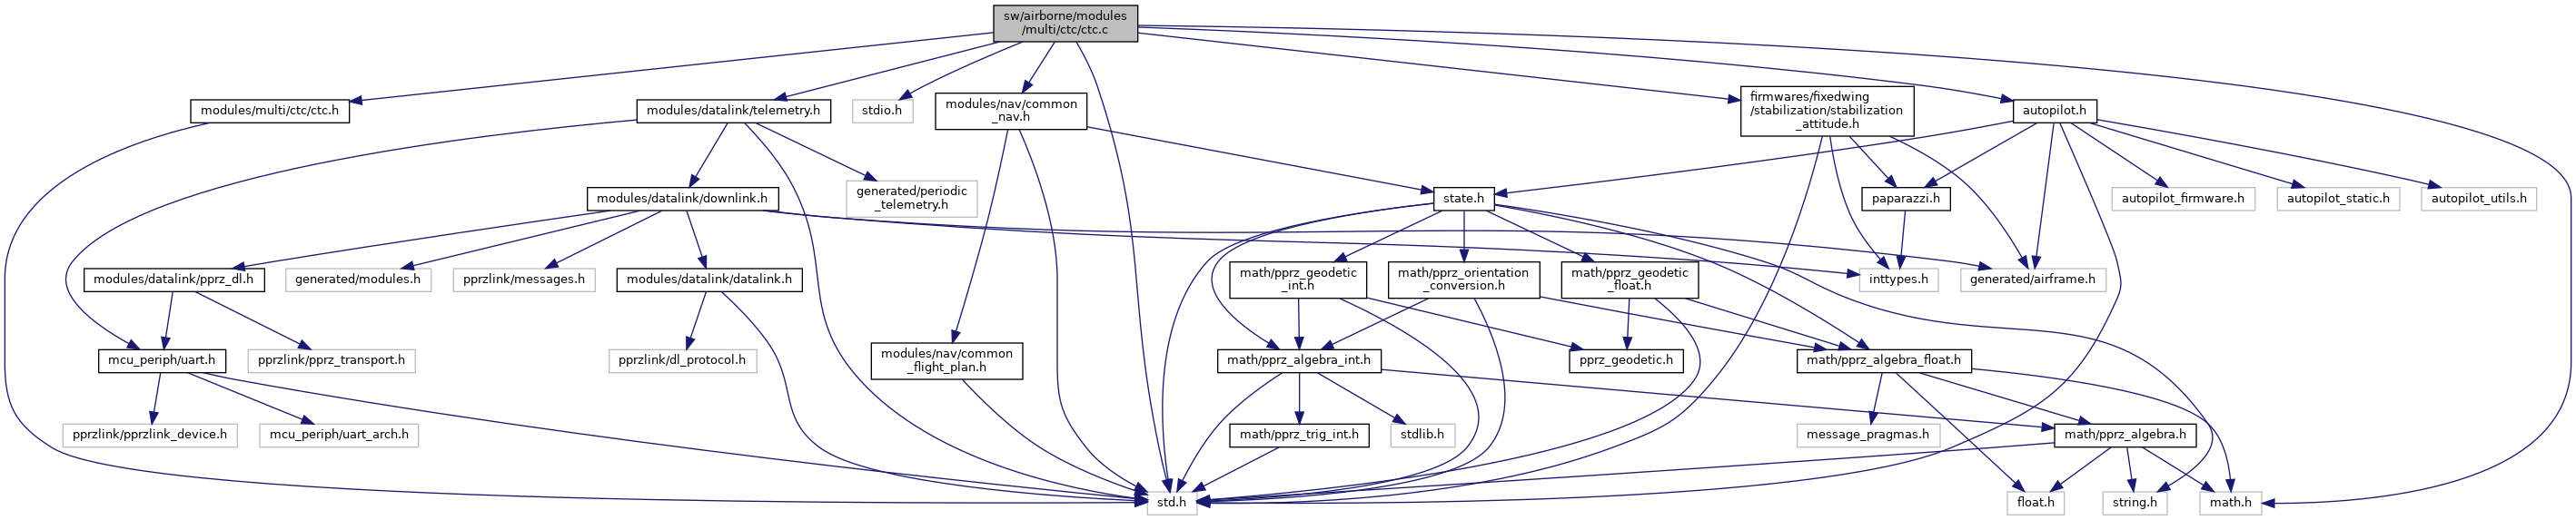
#include <math.h>#include <std.h>#include <stdio.h>#include "modules/multi/ctc/ctc.h"#include "modules/datalink/telemetry.h"#include "modules/nav/common_nav.h"#include "firmwares/fixedwing/stabilization/stabilization_attitude.h"#include "autopilot.h"Go to the source code of this file.
Macros | |
| #define | CTC_MAX_AC 4 |
| #define | CTC_GAIN_K1 0.001 |
| #define | CTC_GAIN_K2 0.001 |
| #define | CTC_GAIN_ALPHA 0.01 |
| #define | CTC_TIMEOUT 1500 |
| #define | CTC_OMEGA 0.25 |
| #define | CTC_TIME_BROAD 100 |
Functions | |
| static void | send_ctc (struct transport_tx *trans, struct link_device *dev) |
| static void | send_ctc_control (struct transport_tx *trans, struct link_device *dev) |
| void | ctc_init (void) |
| bool | collective_tracking_vehicle () |
| bool | collective_tracking_waypoint (uint8_t wp) |
| bool | collective_tracking_point (float x, float y) |
| void | collective_tracking_control () |
Variables | |
| ctc_con | ctc_control |
| int16_t | tableNei [CTC_MAX_AC][6] |
| uint32_t | last_info [CTC_MAX_AC] |
| uint32_t | last_transmision = 0 |
| uint32_t | before = 0 |
| uint32_t | time_init_table |
| float | moving_target_px = 0 |
| float | moving_target_py = 0 |
| float | moving_target_vx = 0 |
| float | moving_target_vy = 0 |
| bool | ctc_gogo = false |
| bool | ctc_first_time = true |
| uint32_t | starting_time |
| #define CTC_MAX_AC 4 |
Max expected number of aircraft
Definition at line 35 of file ctc.c.
Referenced by collective_tracking_control(), ctc_init(), ctc_target_init(), ctc_target_send_info_to_nei(), parse_ctc_target_CleanTable(), parse_ctc_target_RegTable(), and send_ctc().
| #define CTC_OMEGA 0.25 |
| #define CTC_TIME_BROAD 100 |
| #define CTC_TIMEOUT 1500 |
| void collective_tracking_control | ( | void | ) |
Definition at line 144 of file ctc.c.
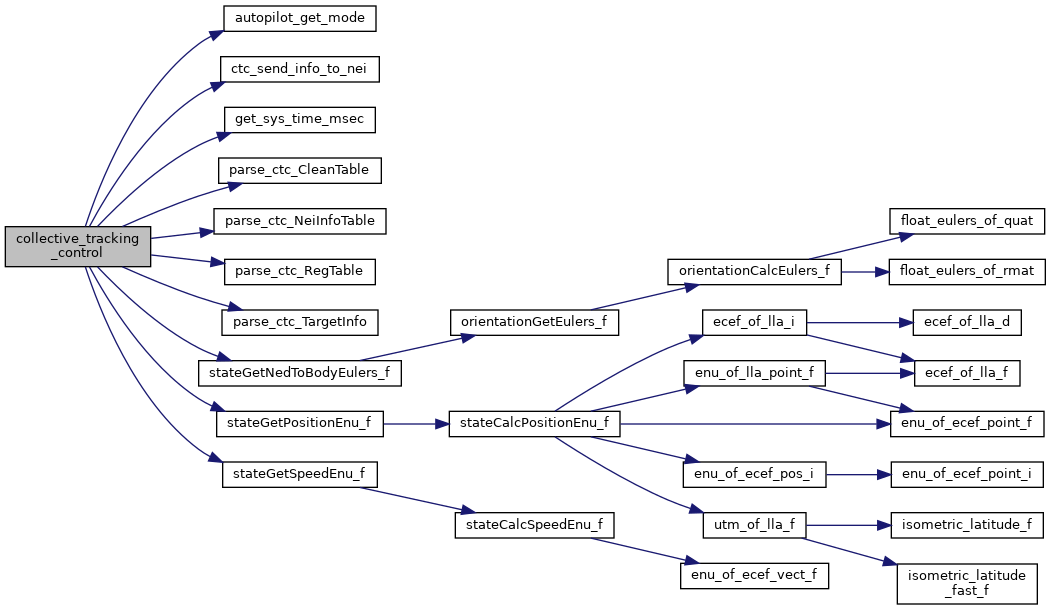
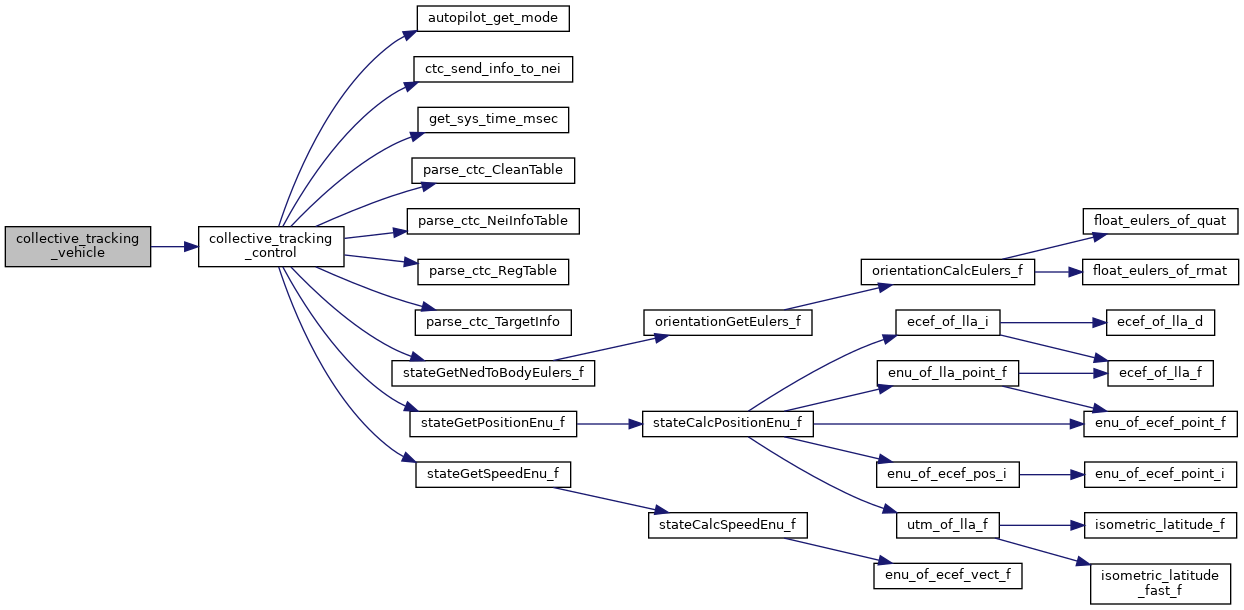
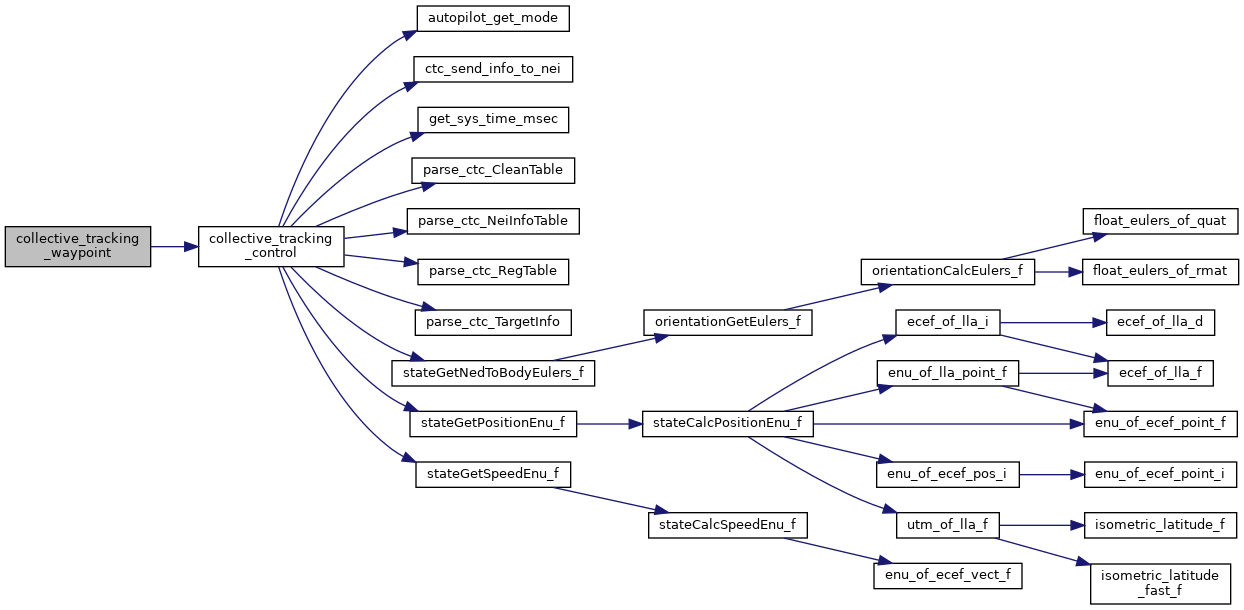
References AP_MODE_AUTO2, autopilot_get_mode(), before, ctc_control, ctc_first_time, ctc_gogo, CTC_MAX_AC, ctc_send_info_to_nei(), DefaultChannel, DefaultDevice, get_sys_time_msec(), h_ctl_roll_max_setpoint, h_ctl_roll_setpoint, last_info, last_transmision, lateral_mode, LATERAL_MODE_ROLL, moving_target_px, moving_target_py, moving_target_vx, moving_target_vy, msg, p, parse_ctc_CleanTable(), parse_ctc_NeiInfoTable(), parse_ctc_RegTable(), parse_ctc_TargetInfo(), starting_time, stateGetNedToBodyEulers_f(), stateGetPositionEnu_f(), stateGetSpeedEnu_f(), tableNei, FloatEulers::theta, timeout, EnuCoor_f::x, and EnuCoor_f::y.
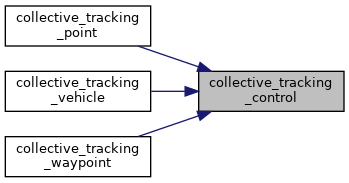
Referenced by collective_tracking_point(), collective_tracking_vehicle(), and collective_tracking_waypoint().
| bool collective_tracking_point | ( | float | x, |
| float | y ) |
Definition at line 132 of file ctc.c.
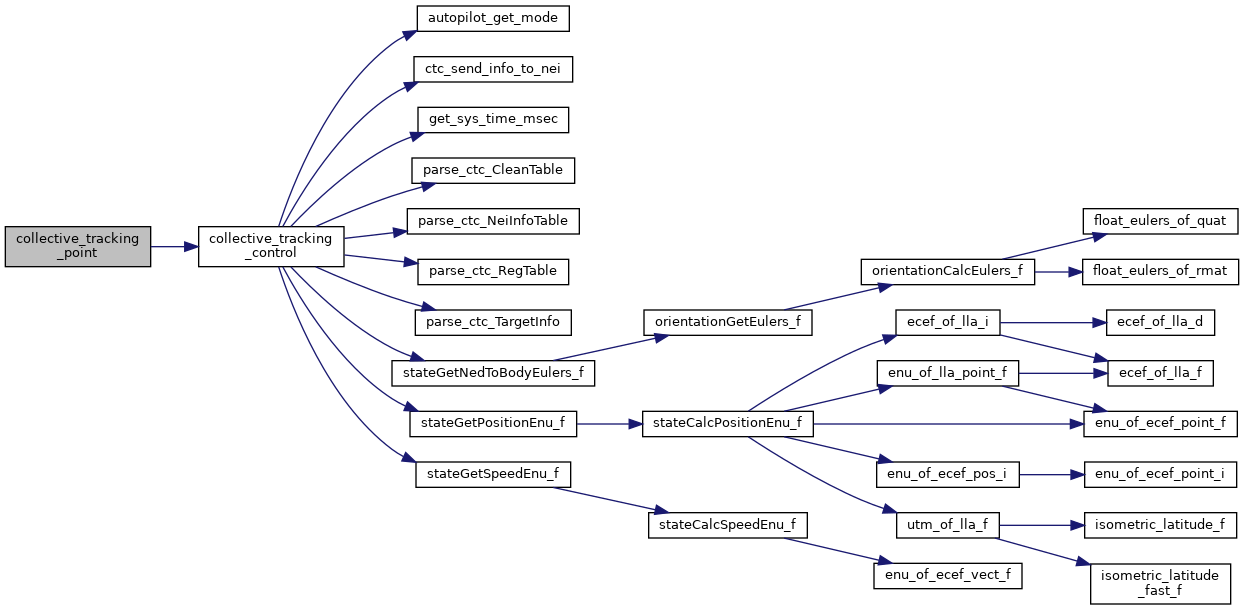
References collective_tracking_control(), and ctc_control.
| bool collective_tracking_vehicle | ( | void | ) |
Definition at line 108 of file ctc.c.
References collective_tracking_control(), ctc_control, moving_target_px, moving_target_py, moving_target_vx, and moving_target_vy.
| bool collective_tracking_waypoint | ( | uint8_t | wp | ) |
Definition at line 120 of file ctc.c.
References collective_tracking_control(), ctc_control, and waypoints.
| void ctc_init | ( | void | ) |
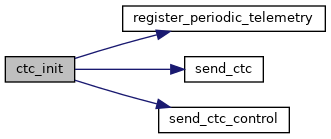
Definition at line 96 of file ctc.c.
References CTC_MAX_AC, DefaultPeriodic, register_periodic_telemetry(), send_ctc(), send_ctc_control(), and tableNei.
|
static |
Definition at line 39 of file ctc.c.
References CTC_MAX_AC, dev, and tableNei.
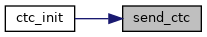
Referenced by ctc_init().
|
static |
Definition at line 44 of file ctc.c.
References ctc_control, and dev.
Referenced by ctc_init().
| uint32_t before = 0 |
Definition at line 83 of file ctc.c.
Referenced by collective_tracking_control().
| ctc_con ctc_control |
Definition at line 76 of file ctc.c.
Referenced by collective_tracking_control(), collective_tracking_point(), collective_tracking_vehicle(), collective_tracking_waypoint(), and send_ctc_control().
| bool ctc_first_time = true |
Definition at line 93 of file ctc.c.
Referenced by collective_tracking_control().
| bool ctc_gogo = false |
Definition at line 92 of file ctc.c.
Referenced by collective_tracking_control().
| uint32_t last_info[CTC_MAX_AC] |
Definition at line 81 of file ctc.c.
Referenced by collective_tracking_control().
| uint32_t last_transmision = 0 |
Definition at line 82 of file ctc.c.
Referenced by collective_tracking_control(), and distributed_circular().
| float moving_target_px = 0 |
Definition at line 87 of file ctc.c.
Referenced by collective_tracking_control(), and collective_tracking_vehicle().
| float moving_target_py = 0 |
Definition at line 88 of file ctc.c.
Referenced by collective_tracking_control(), and collective_tracking_vehicle().
| float moving_target_vx = 0 |
Definition at line 89 of file ctc.c.
Referenced by collective_tracking_control(), and collective_tracking_vehicle().
| float moving_target_vy = 0 |
Definition at line 90 of file ctc.c.
Referenced by collective_tracking_control(), and collective_tracking_vehicle().
| uint32_t starting_time |
Definition at line 94 of file ctc.c.
Referenced by collective_tracking_control().
| int16_t tableNei[CTC_MAX_AC][6] |
Definition at line 80 of file ctc.c.
Referenced by collective_tracking_control(), ctc_init(), ctc_target_init(), ctc_target_send_info_to_nei(), parse_ctc_target_CleanTable(), parse_ctc_target_RegTable(), and send_ctc().
 1.15.0