|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "std.h"Go to the source code of this file.
Data Structures | |
| struct | bayesian_map |
| struct | world_grid |
Macros | |
| #define | N_COL_GRID 100 |
| #define | N_ROW_GRID 100 |
| #define | GRID_BLOCK_SIZE 4 |
Functions | |
| void | init_grid (uint8_t pa, uint8_t pb) |
| void | init_grid_4 (uint8_t wp1, uint8_t wp2, uint8_t wp3, uint8_t wp4) |
| void | obtain_cell_xy (float px, float py, int *cell_x, int *cell_y) |
| void | fill_cell (float px, float py) |
| void | fill_bayesian_cell (float px, float py) |
| void | fill_free_cells (float lidar, float angle) |
| void | decay_map (void) |
| void | update_line_bayes (int x0, int y0, int x1, int y1) |
| void | update_cell (int x, int y, int new_value) |
| void | compute_cell_bayes (int x, int y, bool is_occupied) |
| void | check_probs (void) |
Variables | |
| world_grid | obstacle_grid |
| uint8_t | grid_block_size |
| struct bayesian_map |
Definition at line 44 of file rover_obstacles.h.
| Data Fields | ||
|---|---|---|
| uint8_t | decay | |
| float | free | |
| int8_t | LT | |
| float | occ | |
| float | threshold | |
| struct world_grid |
Definition at line 53 of file rover_obstacles.h.
| Data Fields | ||
|---|---|---|
| float | dx | |
| float | dy | |
| float | home[2] | |
| int | is_ready | |
| bayesian_map | map | |
| uint16_t | now_row | |
| int8_t | world[N_ROW_GRID][N_COL_GRID] | |
| float | xmax | |
| float | xmin | |
| float | ymax | |
| float | ymin | |
| #define GRID_BLOCK_SIZE 4 |
Definition at line 69 of file rover_obstacles.h.
| #define N_COL_GRID 100 |
Definition at line 34 of file rover_obstacles.h.
Referenced by compute_cell_bayes(), decay_map(), fill_free_cells(), init_grid(), init_grid_4(), and send_obstacle_grid().
| #define N_ROW_GRID 100 |
Definition at line 38 of file rover_obstacles.h.
Referenced by compute_cell_bayes(), decay_map(), fill_free_cells(), init_grid(), init_grid_4(), and send_obstacle_grid().
|
extern |
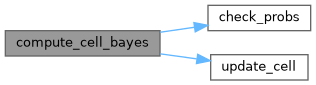
Definition at line 344 of file rover_obstacles.c.
References LFREE, LOCC, LT, obstacle_grid, PFREE, POCC, PT, and SCALE.
Referenced by compute_cell_bayes().
|
extern |
Definition at line 325 of file rover_obstacles.c.
References check_probs(), L_MAX, L_MIN, LFREE, LOCC, N_COL_GRID, N_ROW_GRID, obstacle_grid, update_cell(), EnuCoor_f::x, and EnuCoor_f::y.
Referenced by fill_bayesian_cell(), fill_free_cells(), and update_line_bayes().
|
extern |
Definition at line 256 of file rover_obstacles.c.
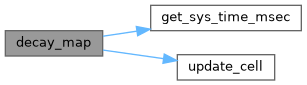
References DECAY_INTERVAL, get_sys_time_msec(), last_s, N_COL_GRID, N_ROW_GRID, obstacle_grid, update_cell(), EnuCoor_f::x, and EnuCoor_f::y.
|
extern |
Definition at line 203 of file rover_obstacles.c.
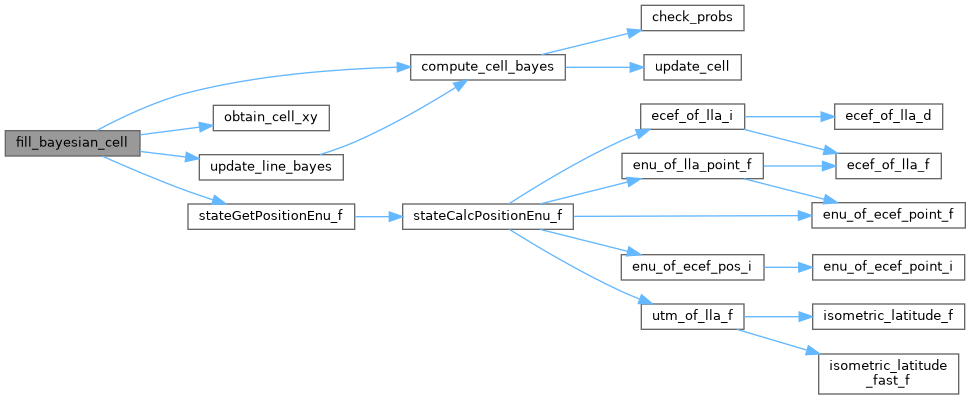
References compute_cell_bayes(), obstacle_grid, obtain_cell_xy(), rover_pos, stateGetPositionEnu_f(), and update_line_bayes().
Referenced by ins_update_lidar().
|
extern |
Definition at line 194 of file rover_obstacles.c.
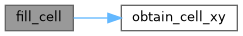
References obstacle_grid, and obtain_cell_xy().
|
extern |
Definition at line 222 of file rover_obstacles.c.
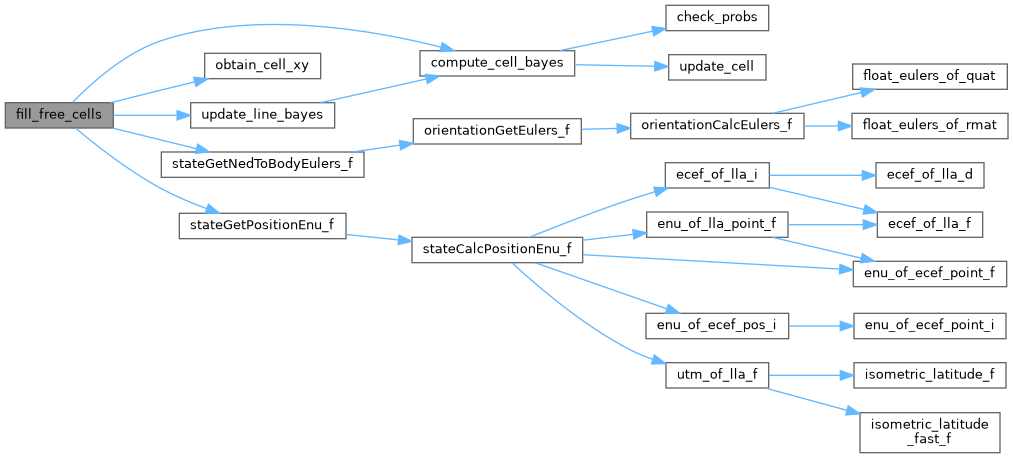
References compute_cell_bayes(), max_distance, N_COL_GRID, N_ROW_GRID, obstacle_grid, obtain_cell_xy(), FloatEulers::psi, rover_pos, stateGetNedToBodyEulers_f(), stateGetPositionEnu_f(), and update_line_bayes().
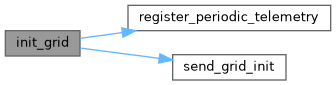
Definition at line 109 of file rover_obstacles.c.
References DefaultPeriodic, L0, N_COL_GRID, N_ROW_GRID, obstacle_grid, register_periodic_telemetry(), send_grid_init(), WaypointX, and WaypointY.
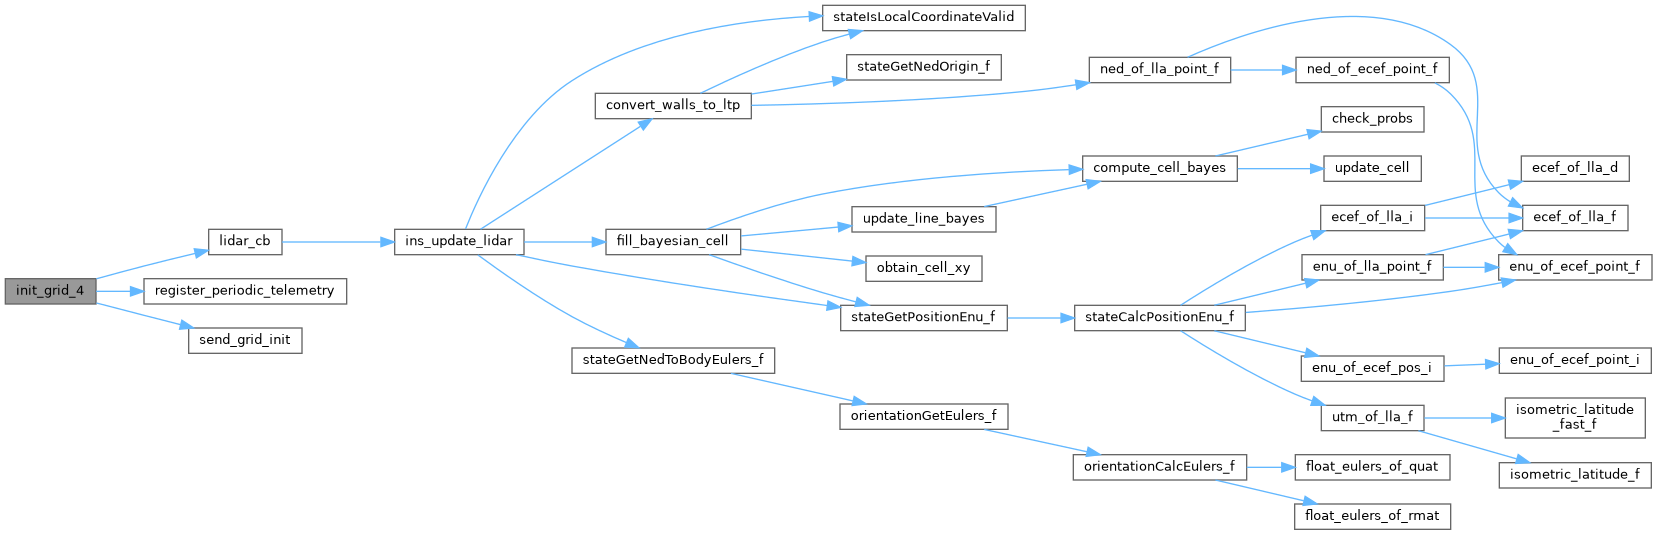
Definition at line 136 of file rover_obstacles.c.
References DECAY, DefaultChannel, DefaultDevice, DefaultPeriodic, lidar_cb(), lidar_ev, N_COL_GRID, N_ROW_GRID, obstacle_grid, OBSTACLES_RECEIVE_ID, P_FREE, P_OCC, P_T, register_periodic_telemetry(), send_grid_init(), WaypointX, and WaypointY.
|
extern |
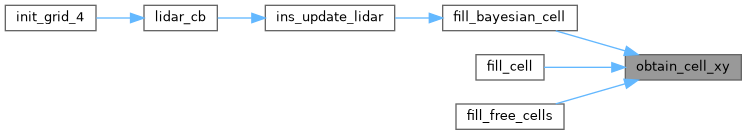
Definition at line 182 of file rover_obstacles.c.
References obstacle_grid.
Referenced by fill_bayesian_cell(), fill_cell(), and fill_free_cells().
|
extern |
Definition at line 306 of file rover_obstacles.c.
References DefaultChannel, DefaultDevice, LT, obstacle_grid, EnuCoor_f::x, and EnuCoor_f::y.
Referenced by compute_cell_bayes(), and decay_map().
|
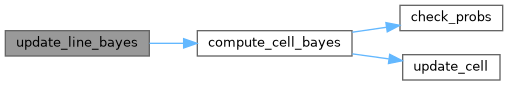
extern |
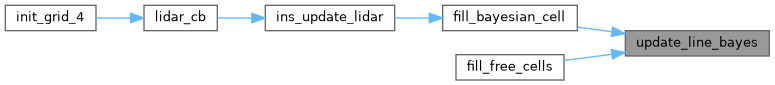
Definition at line 289 of file rover_obstacles.c.
References compute_cell_bayes().
Referenced by fill_bayesian_cell(), and fill_free_cells().
|
extern |
Definition at line 76 of file rover_obstacles.c.
|
extern |
Definition at line 75 of file rover_obstacles.c.
Referenced by check_probs(), compute_cell_bayes(), decay_map(), fill_bayesian_cell(), fill_cell(), fill_free_cells(), init_grid(), init_grid_4(), obtain_cell_xy(), send_grid_init(), send_obstacle_grid(), and update_cell().
 1.15.0