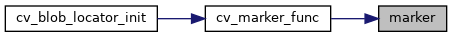|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Find a IMAV pattern. More...
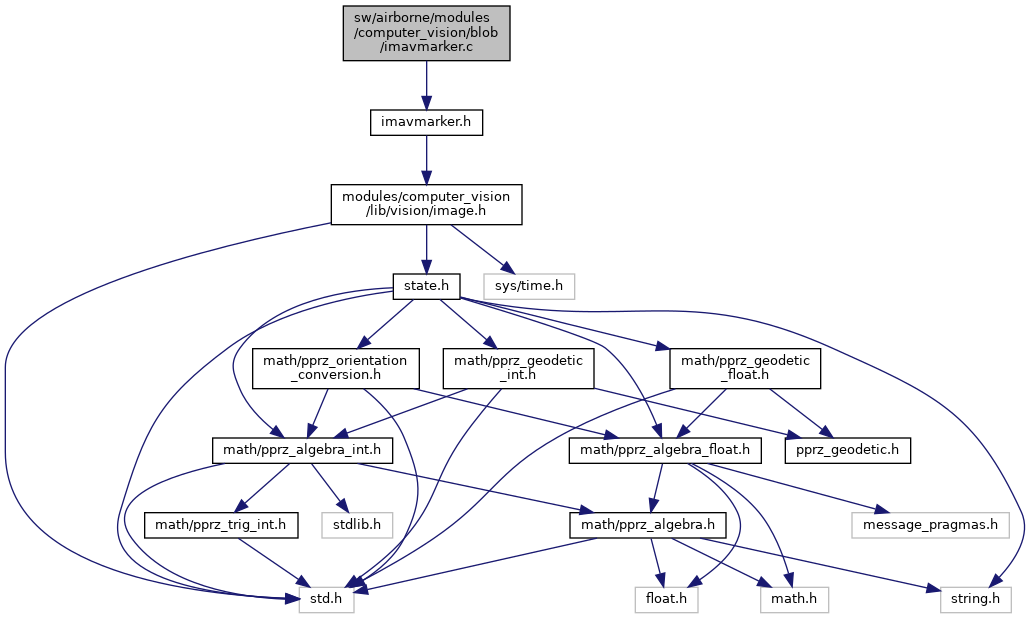
#include "imavmarker.h"Go to the source code of this file.
Macros | |
| #define | Img(X, Y) |
| Find the marker location. | |
| #define | Out(X, Y) |
Functions | |
| int | AbsDiff (int A, int B) |
| struct marker_deviation_t | marker (struct image_t *input, uint8_t M) |
Find a IMAV pattern.
Definition in file imavmarker.c.
| #define Img | ( | X, | |
| Y ) |
Find the marker location.
| [in] | *input | The input image to filter |
| [in] | M | The distance between the pixel of interest and farthest neighbor pixel [pixel] |
Definition at line 39 of file imavmarker.c.
Referenced by marker().
| #define Out | ( | X, | |
| Y ) |
Definition at line 40 of file imavmarker.c.
Referenced by marker().
|
inline |
Definition at line 43 of file imavmarker.c.
Referenced by marker().
| struct marker_deviation_t marker | ( | struct image_t * | input, |
| uint8_t | M ) |
Definition at line 51 of file imavmarker.c.
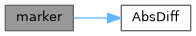
References AbsDiff(), Img, marker_deviation_t::inlier, marker(), Out, marker_deviation_t::x, and marker_deviation_t::y.
Referenced by cv_marker_func(), and marker().
 1.15.0