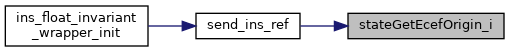|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Macros | |
| #define | POS_ECEF_I 0 |
| #define | POS_NED_I 1 |
| #define | POS_ENU_I 2 |
| #define | POS_LLA_I 3 |
| #define | POS_UTM_I 4 |
| #define | POS_ECEF_F 5 |
| #define | POS_NED_F 6 |
| #define | POS_ENU_F 7 |
| #define | POS_LLA_F 8 |
| #define | POS_UTM_F 9 |
| #define | POS_LOCAL_COORD ((1<<POS_NED_I)|(1<<POS_NED_F)|(1<<POS_ENU_I)|(1<<POS_ENU_F)) |
| #define | POS_GLOBAL_COORD ((1<<POS_ECEF_I)|(1<<POS_ECEF_F)|(1<<POS_LLA_I)|(1<<POS_LLA_F)|(1<<POS_UTM_I)|(1<<POS_UTM_F)) |
Functions | |
| struct LlaCoor_i | stateGetLlaOrigin_i (void) |
| Get the LLA position of the frame origin (int). | |
| struct LlaCoor_f | stateGetLlaOrigin_f (void) |
| Get the LLA position of the frame origin (float). | |
| struct EcefCoor_i | stateGetEcefOrigin_i (void) |
| Get the ECEF position of the frame origin (int). | |
| struct EcefCoor_f | stateGetEcefOrigin_f (void) |
| Get the ECEF position of the frame origin (float). | |
| int32_t | stateGetHmslOrigin_i (void) |
| Get the HMSL of the frame origin (int). | |
| float | stateGetHmslOrigin_f (void) |
| Get the HMSL of the frame origin (float). | |
| void | stateCalcPositionEcef_i (void) |
| void | stateCalcPositionNed_i (void) |
| void | stateCalcPositionEnu_i (void) |
| void | stateCalcPositionLla_i (void) |
| Calculate LLA (int) from any other available representation. | |
| void | stateCalcPositionUtm_f (void) |
| void | stateCalcPositionEcef_f (void) |
| void | stateCalcPositionNed_f (void) |
| void | stateCalcPositionEnu_f (void) |
| void | stateCalcPositionLla_f (void) |
| static void | stateSetLocalOrigin_i (uint16_t id, struct LtpDef_i *ltp_def) |
| Set the local (flat earth) coordinate frame origin (int). | |
| static void | stateSetLocalUtmOrigin_f (uint16_t id, struct UtmCoor_f *utm_def) |
| Set the local (flat earth) coordinate frame origin from UTM (float). | |
| static struct LtpDef_i * | stateGetNedOrigin_i (void) |
| Get the coordinate NED frame origin (int). | |
| static struct LtpDef_f * | stateGetNedOrigin_f (void) |
| Get the coordinate NED frame origin (float). | |
| static struct UtmCoor_f * | stateGetUtmOrigin_f (void) |
| Get the coordinate UTM frame origin (int). | |
| static bool | stateIsLocalCoordinateValid (void) |
| Test if local coordinates are valid. | |
| static bool | stateIsGlobalCoordinateValid (void) |
| Test if global coordinates are valid. | |
| static void | stateSetPositionEcef_i (uint16_t id, struct EcefCoor_i *ecef_pos) |
| Set position from ECEF coordinates (int). | |
| static void | stateSetPositionNed_i (uint16_t id, struct NedCoor_i *ned_pos) |
| Set position from local NED coordinates (int). | |
| static void | stateSetPositionEnu_i (uint16_t id, struct EnuCoor_i *enu_pos) |
| Set position from local ENU coordinates (int). | |
| static void | stateSetPositionLla_i (uint16_t id, struct LlaCoor_i *lla_pos) |
| Set position from LLA coordinates (int). | |
| static void | stateSetPosition_i (uint16_t id, struct EcefCoor_i *ecef_pos, struct NedCoor_i *ned_pos, struct EnuCoor_i *enu_pos, struct LlaCoor_i *lla_pos) |
| Set multiple position coordinates (int). | |
| static void | stateSetPositionUtm_f (uint16_t id, struct UtmCoor_f *utm_pos) |
| Set position from UTM coordinates (float). | |
| static void | stateSetPositionEcef_f (uint16_t id, struct EcefCoor_f *ecef_pos) |
| Set position from ECEF coordinates (float). | |
| static void | stateSetPositionNed_f (uint16_t id, struct NedCoor_f *ned_pos) |
| Set position from local NED coordinates (float). | |
| static void | stateSetPositionEnu_f (uint16_t id, struct EnuCoor_f *enu_pos) |
| Set position from local ENU coordinates (float). | |
| static void | stateSetPositionLla_f (uint16_t id, struct LlaCoor_f *lla_pos) |
| Set position from LLA coordinates (float). | |
| static void | stateSetPosition_f (uint16_t id, struct EcefCoor_f *ecef_pos, struct NedCoor_f *ned_pos, struct EnuCoor_f *enu_pos, struct LlaCoor_f *lla_pos, struct UtmCoor_f *utm_pos) |
| Set multiple position coordinates (float). | |
| static struct EcefCoor_i * | stateGetPositionEcef_i (void) |
| Get position in ECEF coordinates (int). | |
| static struct NedCoor_i * | stateGetPositionNed_i (void) |
| Get position in local NED coordinates (int). | |
| static struct EnuCoor_i * | stateGetPositionEnu_i (void) |
| Get position in local ENU coordinates (int). | |
| static struct LlaCoor_i * | stateGetPositionLla_i (void) |
| Get position in LLA coordinates (int). | |
| static struct UtmCoor_f * | stateGetPositionUtm_f (void) |
| Get position in UTM coordinates (float). | |
| static struct EcefCoor_f * | stateGetPositionEcef_f (void) |
| Get position in ECEF coordinates (float). | |
| static struct NedCoor_f * | stateGetPositionNed_f (void) |
| Get position in local NED coordinates (float). | |
| static struct EnuCoor_f * | stateGetPositionEnu_f (void) |
| Get position in local ENU coordinates (float). | |
| static struct LlaCoor_f * | stateGetPositionLla_f (void) |
| Get position in LLA coordinates (float). | |
Variables | |
| uint16_t | State::origin_input_filter |
| Holds the input filter id for state origin. | |
| uint16_t | State::pos_status |
| Holds the status bits for all position representations. | |
| uint16_t | State::pos_input_filter |
| Holds the input filter id for position. | |
| struct EcefCoor_i | State::ecef_pos_i |
| Position in EarthCenteredEarthFixed coordinates. | |
| struct LlaCoor_i | State::lla_pos_i |
| Position in Latitude, Longitude and Altitude. | |
| struct LtpDef_i | State::ned_origin_i |
| Definition of the local (flat earth) coordinate system. | |
| bool | State::ned_initialized_i |
| true if local int coordinate frame is initialsed | |
| struct NedCoor_i | State::ned_pos_i |
| Position in North East Down coordinates. | |
| struct EnuCoor_i | State::enu_pos_i |
| Position in East North Up coordinates. | |
| struct UtmCoor_f | State::utm_pos_f |
| Position in UTM coordinates. | |
| float | State::alt_agl_f |
| Altitude above ground level. | |
| struct LlaCoor_f | State::lla_pos_f |
| Position in Latitude, Longitude and Altitude. | |
| struct EcefCoor_f | State::ecef_pos_f |
| Position in EarthCenteredEarthFixed coordinates. | |
| struct LtpDef_f | State::ned_origin_f |
| Definition of the local (flat earth) coordinate system. | |
| bool | State::ned_initialized_f |
| True if local float coordinate frame is initialsed. | |
| struct UtmCoor_f | State::utm_origin_f |
| Definition of the origin of Utm coordinate system. | |
| bool | State::utm_initialized_f |
| True if utm origin (float) coordinate frame is initialsed. | |
| struct NedCoor_f | State::ned_pos_f |
| Position in North East Down coordinates. | |
| struct EnuCoor_f | State::enu_pos_f |
| Position in East North Up coordinates. | |
| #define POS_ECEF_F 5 |
Definition at line 76 of file state.h.
Referenced by stateCalcPositionEcef_f(), stateCalcPositionEcef_i(), stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateGetPositionEcef_f(), stateSetPosition_f(), and stateSetPositionEcef_f().
| #define POS_ECEF_I 0 |
Definition at line 71 of file state.h.
Referenced by stateCalcPositionEcef_f(), stateCalcPositionEcef_i(), stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateGetPositionEcef_i(), stateSetPosition_i(), and stateSetPositionEcef_i().
| #define POS_ENU_F 7 |
Definition at line 78 of file state.h.
Referenced by stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionEnu_f(), stateSetPosition_f(), and stateSetPositionEnu_f().
| #define POS_ENU_I 2 |
Definition at line 73 of file state.h.
Referenced by stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionEnu_i(), stateSetPosition_i(), and stateSetPositionEnu_i().
| #define POS_GLOBAL_COORD ((1<<POS_ECEF_I)|(1<<POS_ECEF_F)|(1<<POS_LLA_I)|(1<<POS_LLA_F)|(1<<POS_UTM_I)|(1<<POS_UTM_F)) |
Definition at line 82 of file state.h.
Referenced by stateIsGlobalCoordinateValid().
| #define POS_LLA_F 8 |
Definition at line 79 of file state.h.
Referenced by stateCalcPositionEcef_f(), stateCalcPositionEcef_i(), stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionLla_f(), stateSetPosition_f(), and stateSetPositionLla_f().
| #define POS_LLA_I 3 |
Definition at line 74 of file state.h.
Referenced by stateCalcPositionEcef_f(), stateCalcPositionEcef_i(), stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionLla_i(), stateSetPosition_i(), and stateSetPositionLla_i().
Definition at line 81 of file state.h.
Referenced by stateIsLocalCoordinateValid(), stateSetLocalOrigin_i(), and stateSetLocalUtmOrigin_f().
| #define POS_NED_F 6 |
Definition at line 77 of file state.h.
Referenced by stateCalcPositionEcef_f(), stateCalcPositionEcef_i(), stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionNed_f(), stateSetPosition_f(), and stateSetPositionNed_f().
| #define POS_NED_I 1 |
Definition at line 72 of file state.h.
Referenced by stateCalcPositionEcef_f(), stateCalcPositionEcef_i(), stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionNed_i(), stateSetPosition_i(), and stateSetPositionNed_i().
| #define POS_UTM_F 9 |
Definition at line 80 of file state.h.
Referenced by stateCalcPositionEnu_f(), stateCalcPositionEnu_i(), stateCalcPositionLla_f(), stateCalcPositionLla_i(), stateCalcPositionNed_f(), stateCalcPositionNed_i(), stateCalcPositionUtm_f(), stateGetPositionUtm_f(), stateSetPosition_f(), and stateSetPositionUtm_f().
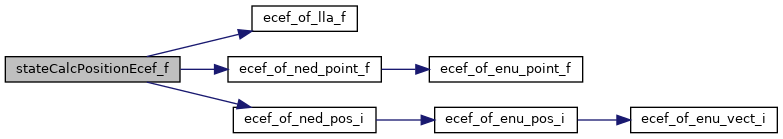
| void stateCalcPositionEcef_f | ( | void | ) |
Definition at line 557 of file state.c.
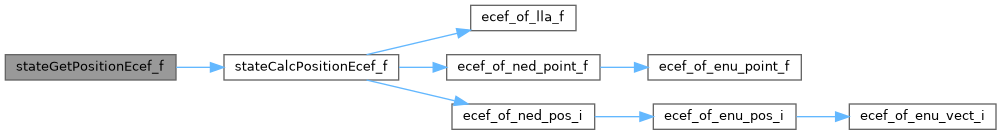
References ECEF_FLOAT_OF_BFP, ecef_of_lla_f(), ecef_of_ned_point_f(), ecef_of_ned_pos_i(), LLA_FLOAT_OF_BFP, POS_ECEF_F, POS_ECEF_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, and state.
Referenced by stateGetPositionEcef_f().
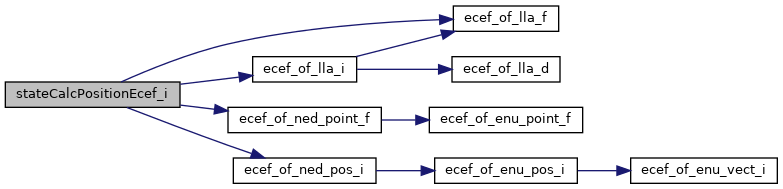
| void stateCalcPositionEcef_i | ( | void | ) |
Definition at line 223 of file state.c.
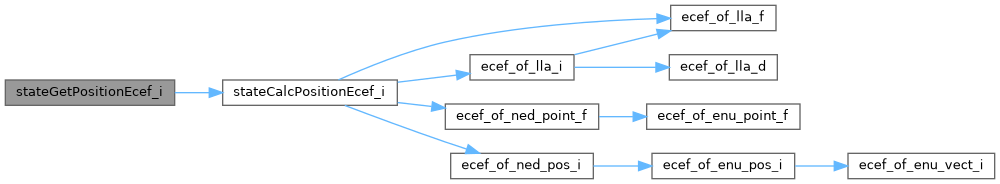
References ECEF_BFP_OF_REAL, ecef_of_lla_f(), ecef_of_lla_i(), ecef_of_ned_point_f(), ecef_of_ned_pos_i(), POS_ECEF_F, POS_ECEF_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, and state.
Referenced by stateGetPositionEcef_i().
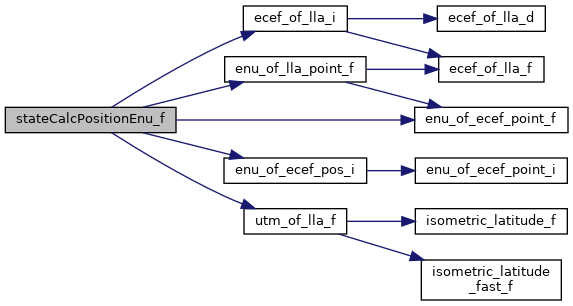
| void stateCalcPositionEnu_f | ( | void | ) |
Definition at line 655 of file state.c.
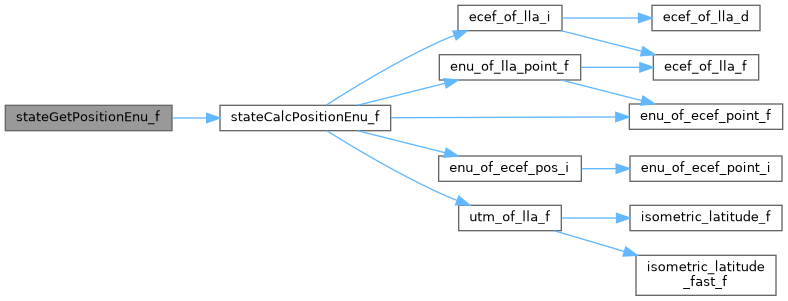
References ecef_of_lla_i(), ENU_FLOAT_OF_BFP, enu_of_ecef_point_f(), enu_of_ecef_pos_i(), enu_of_lla_point_f(), ENU_OF_UTM_DIFF, LLA_FLOAT_OF_BFP, NED_FLOAT_OF_BFP, POS_ECEF_F, POS_ECEF_I, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, utm_of_lla_f(), and VECT3_ENU_OF_NED.
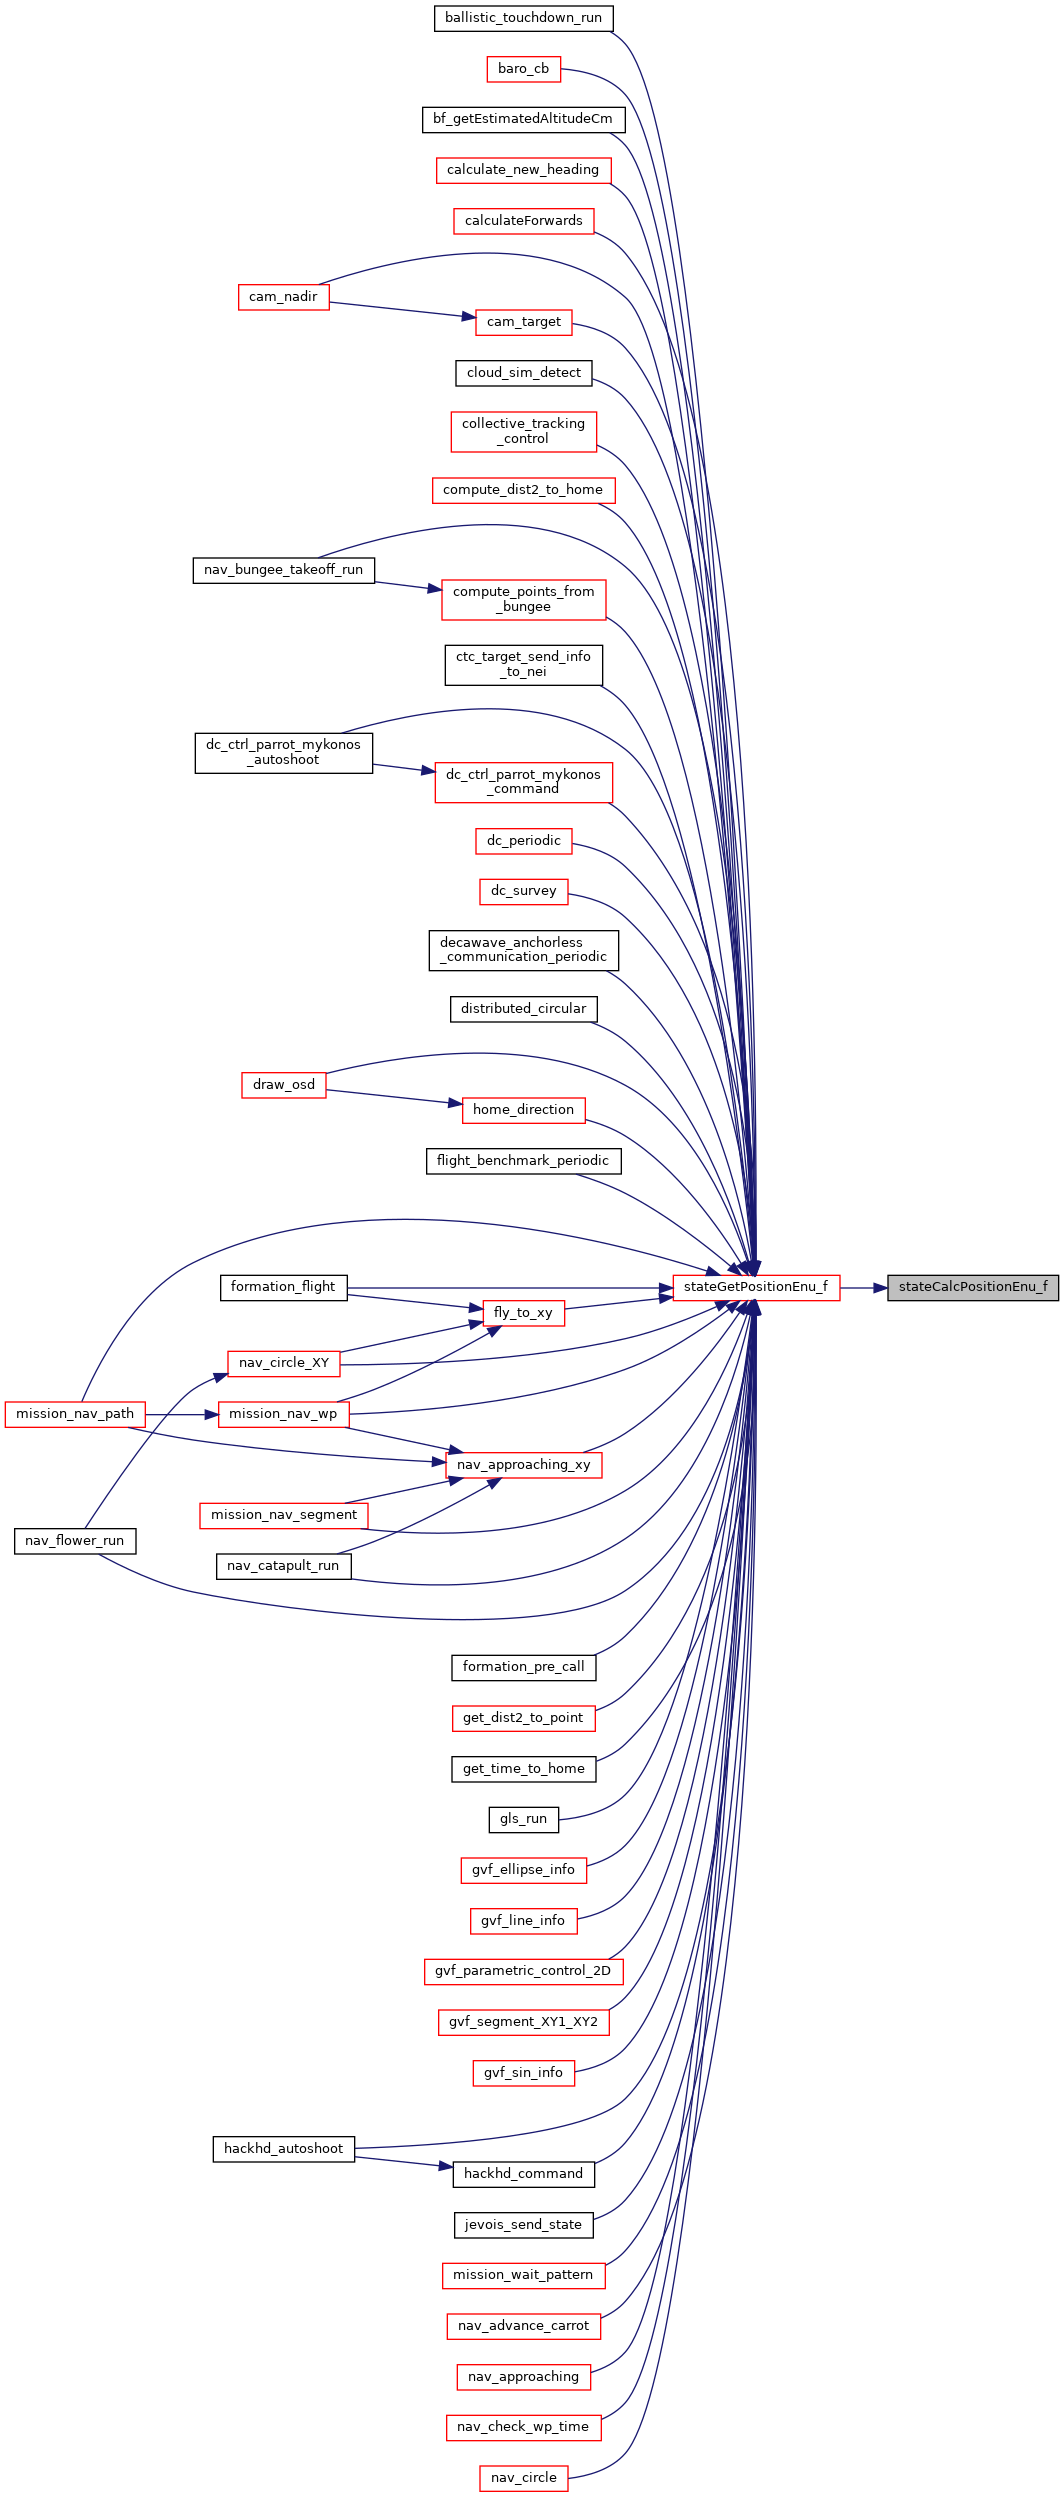
Referenced by stateGetPositionEnu_f().
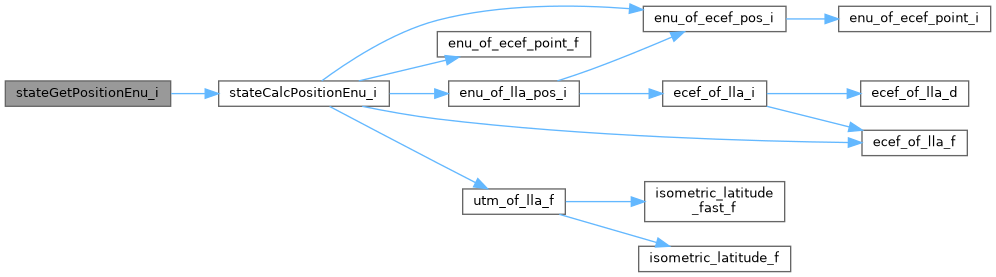
| void stateCalcPositionEnu_i | ( | void | ) |
Definition at line 335 of file state.c.
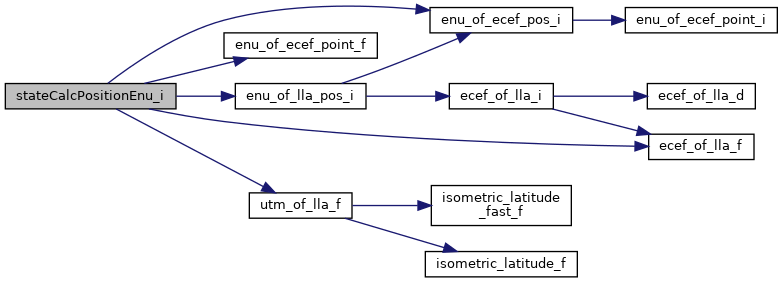
References ecef_of_lla_f(), ENU_BFP_OF_REAL, enu_of_ecef_point_f(), enu_of_ecef_pos_i(), enu_of_lla_pos_i(), ENU_OF_UTM_DIFF, INT32_VECT3_ENU_OF_NED, LLA_FLOAT_OF_BFP, NED_BFP_OF_REAL, POS_ECEF_F, POS_ECEF_I, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, and utm_of_lla_f().
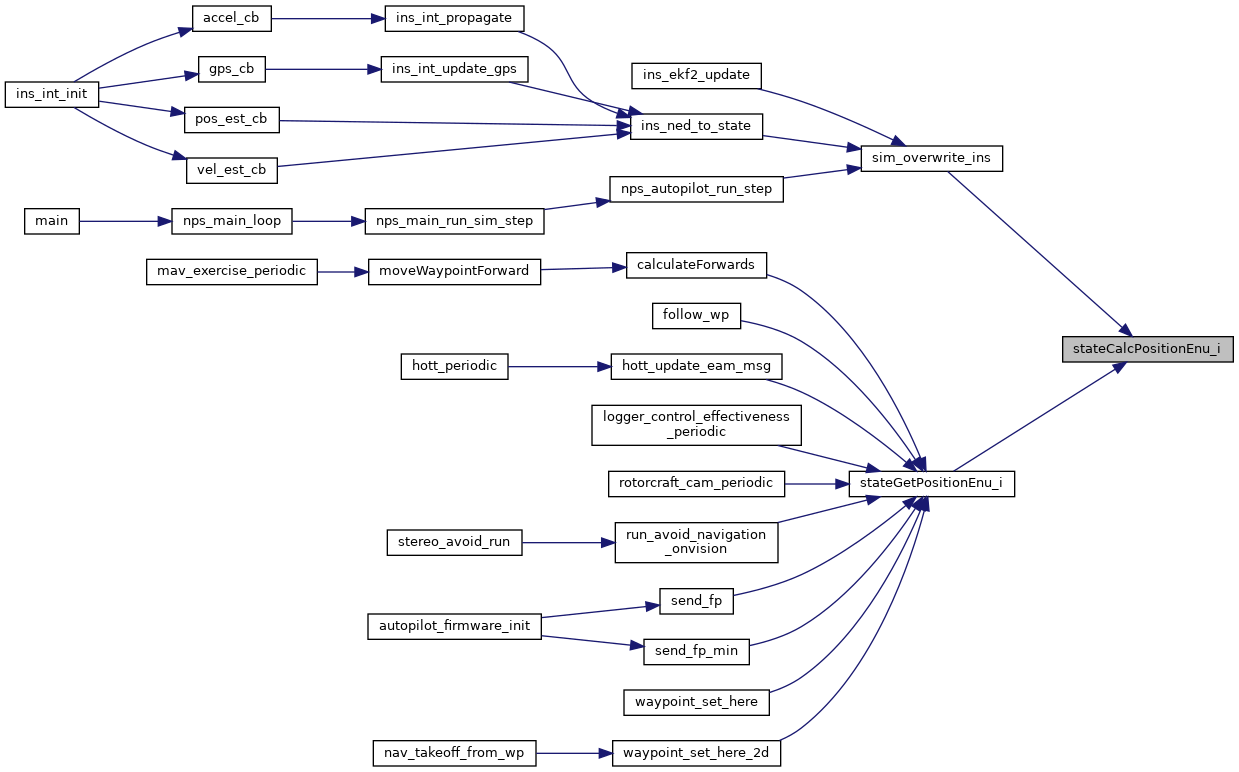
Referenced by sim_overwrite_ins(), and stateGetPositionEnu_i().
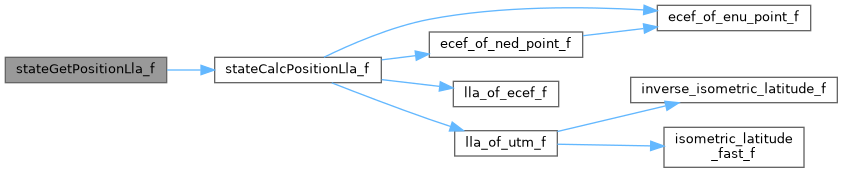
| void stateCalcPositionLla_f | ( | void | ) |
Definition at line 728 of file state.c.
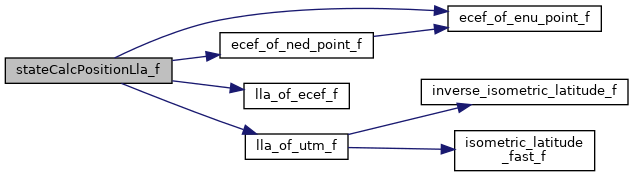
References ECEF_FLOAT_OF_BFP, ecef_of_enu_point_f(), ecef_of_ned_point_f(), ENU_FLOAT_OF_BFP, LLA_FLOAT_OF_BFP, lla_of_ecef_f(), lla_of_utm_f(), NED_FLOAT_OF_BFP, POS_ECEF_F, POS_ECEF_I, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, UTM_OF_ENU_ADD, and UTM_OF_NED_ADD.
Referenced by stateGetPositionLla_f().
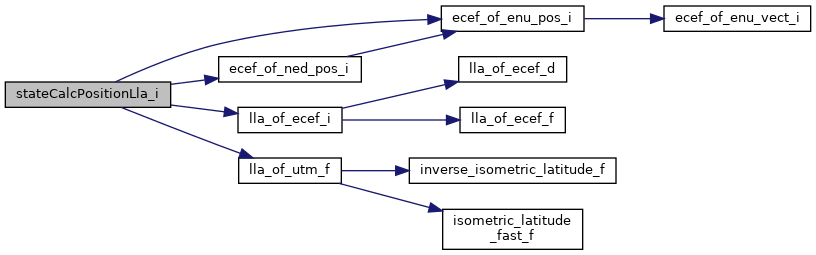
| void stateCalcPositionLla_i | ( | void | ) |
Calculate LLA (int) from any other available representation.
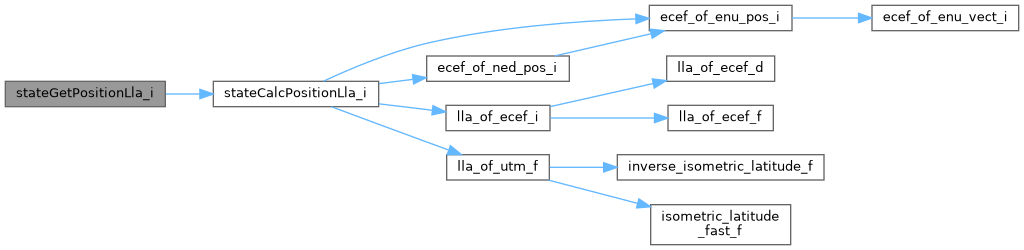
Note that since LLA in float has bad precision this is the last choice. So we mostly first convert to ECEF and then use lla_of_ecef_i which provides higher precision but is currently using the double function internally. When using UTM coordinates, NED/ENU are abused as "local" UTM.
Definition at line 422 of file state.c.
References ECEF_BFP_OF_REAL, ecef_of_enu_pos_i(), ecef_of_ned_pos_i(), ENU_BFP_OF_REAL, ENU_FLOAT_OF_BFP, LLA_BFP_OF_REAL, lla_of_ecef_i(), lla_of_utm_f(), NED_BFP_OF_REAL, NED_FLOAT_OF_BFP, POS_ECEF_F, POS_ECEF_I, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, UTM_OF_ENU_ADD, and UTM_OF_NED_ADD.
Referenced by stateGetPositionLla_i().
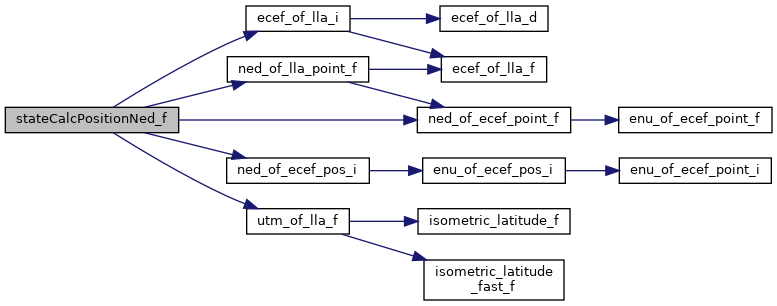
| void stateCalcPositionNed_f | ( | void | ) |
Definition at line 588 of file state.c.
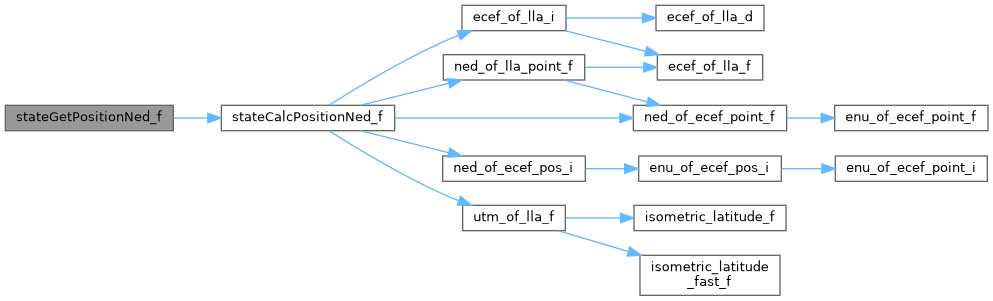
References ecef_of_lla_i(), ENU_FLOAT_OF_BFP, LLA_FLOAT_OF_BFP, NED_FLOAT_OF_BFP, ned_of_ecef_point_f(), ned_of_ecef_pos_i(), ned_of_lla_point_f(), NED_OF_UTM_DIFF, POS_ECEF_F, POS_ECEF_I, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, utm_of_lla_f(), and VECT3_NED_OF_ENU.
Referenced by stateGetPositionNed_f().
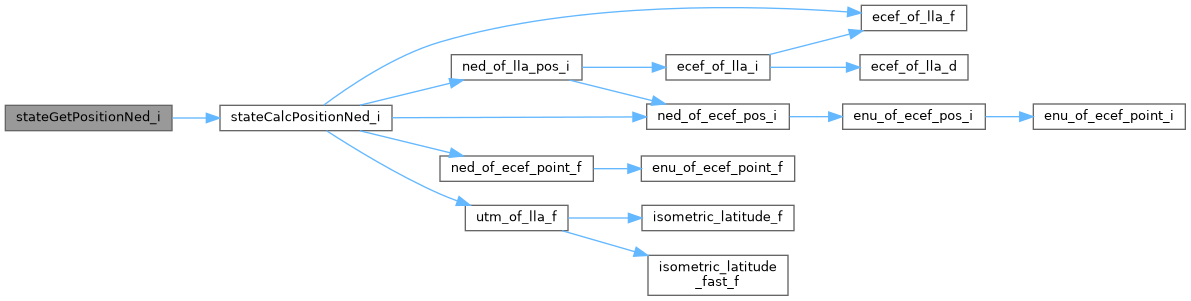
| void stateCalcPositionNed_i | ( | void | ) |
Definition at line 255 of file state.c.
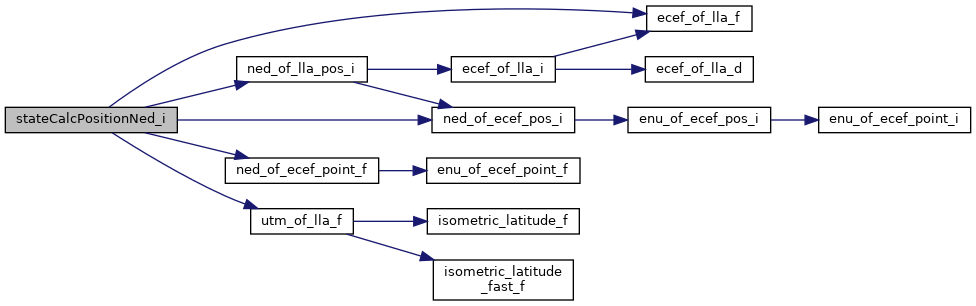
References ecef_of_lla_f(), ENU_BFP_OF_REAL, INT32_VECT3_NED_OF_ENU, LLA_FLOAT_OF_BFP, NED_BFP_OF_REAL, ned_of_ecef_point_f(), ned_of_ecef_pos_i(), ned_of_lla_pos_i(), NED_OF_UTM_DIFF, POS_ECEF_F, POS_ECEF_I, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, and utm_of_lla_f().
Referenced by stateGetPositionNed_i().
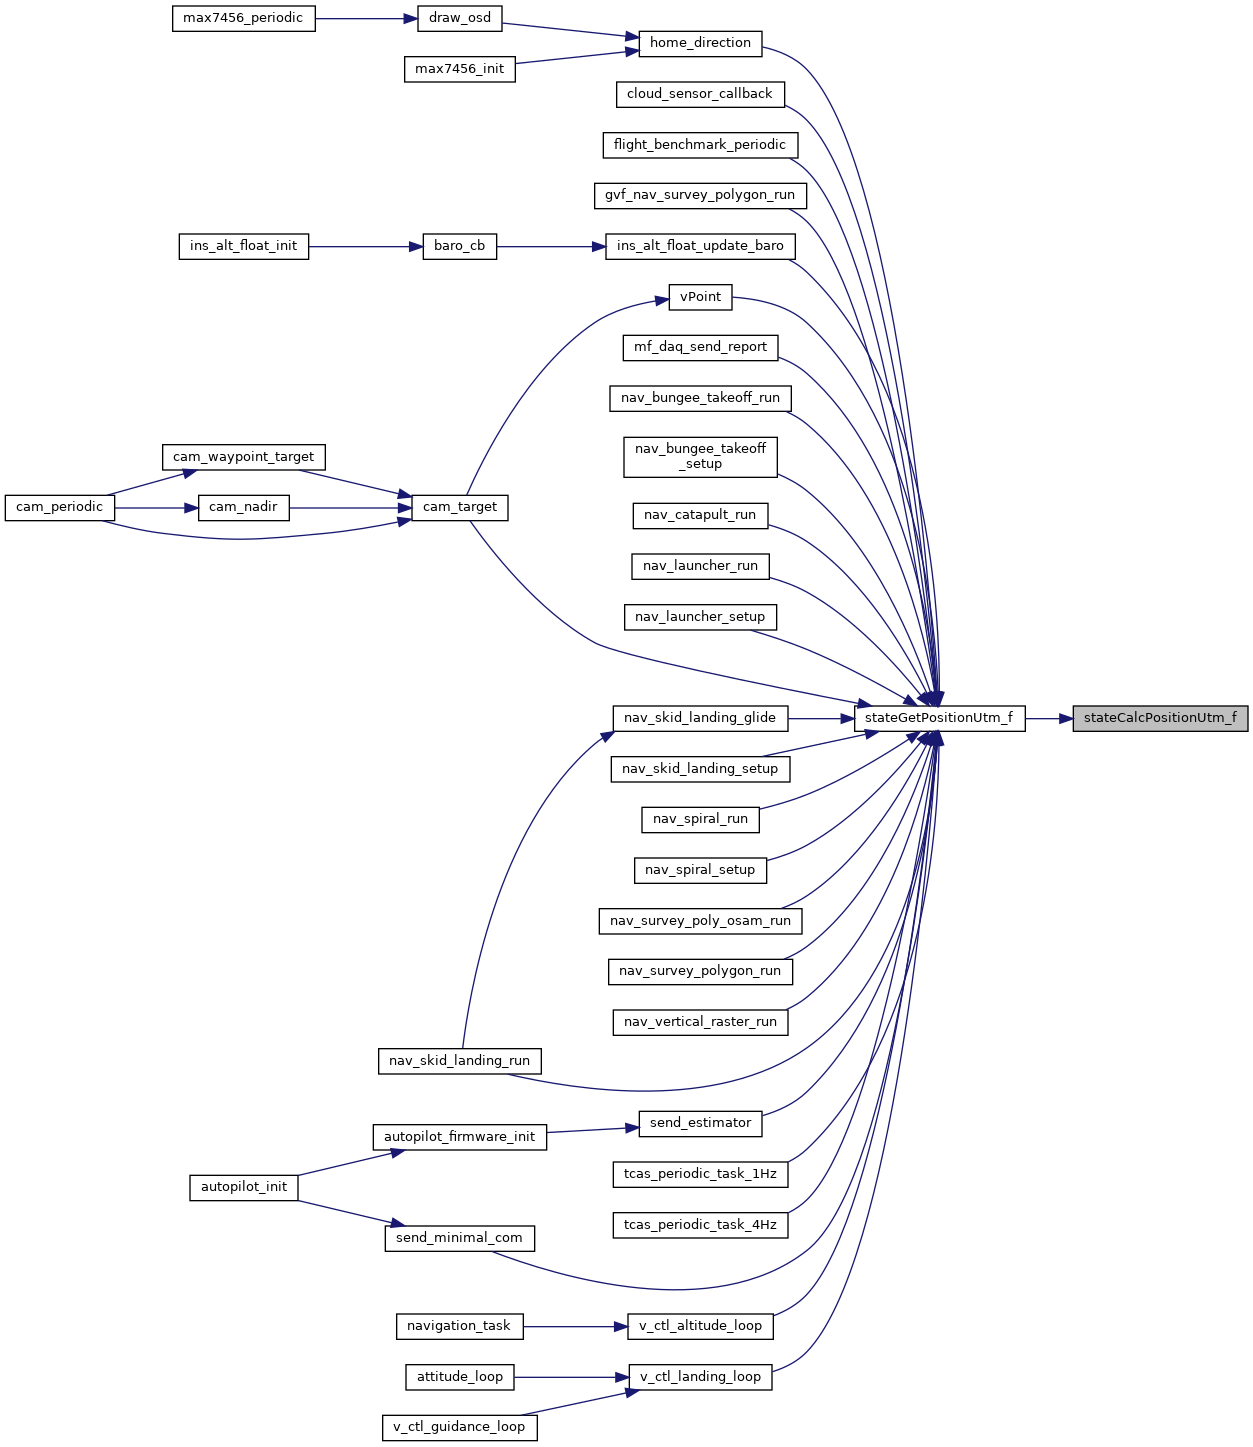
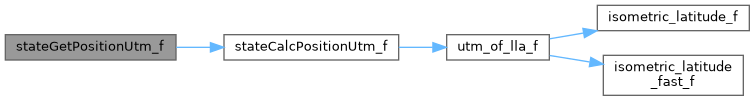
| void stateCalcPositionUtm_f | ( | void | ) |
Definition at line 520 of file state.c.
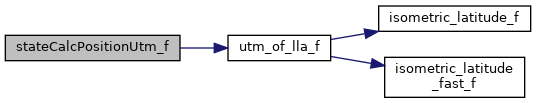
References ENU_FLOAT_OF_BFP, LLA_FLOAT_OF_BFP, NED_FLOAT_OF_BFP, POS_ENU_F, POS_ENU_I, POS_LLA_F, POS_LLA_I, POS_NED_F, POS_NED_I, POS_UTM_F, state, UTM_OF_ENU_ADD, utm_of_lla_f(), and UTM_OF_NED_ADD.
Referenced by stateGetPositionUtm_f().
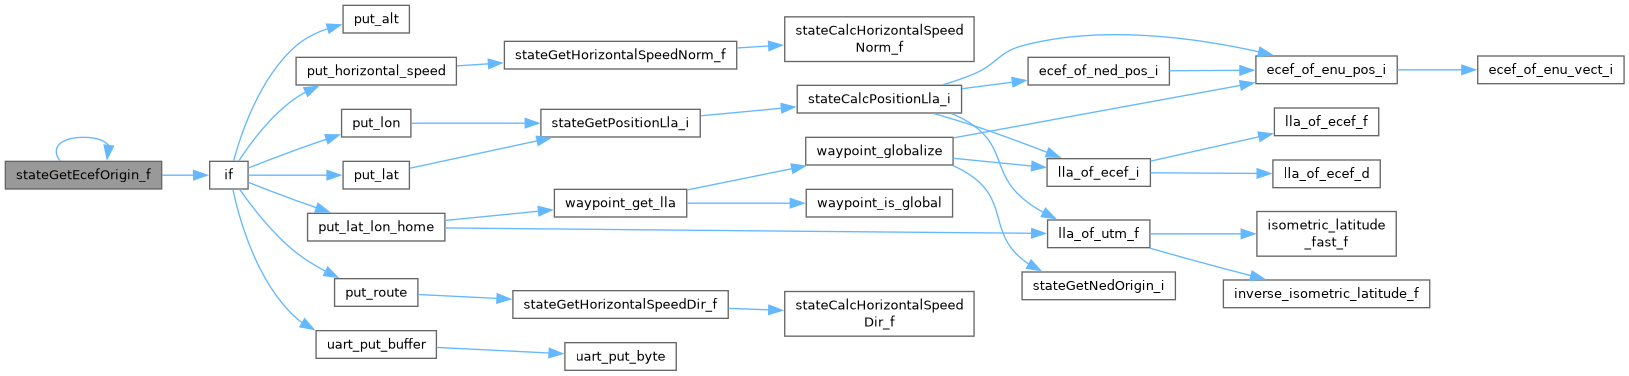
| struct EcefCoor_f stateGetEcefOrigin_f | ( | void | ) |
Get the ECEF position of the frame origin (float).
Definition at line 181 of file state.c.
References if(), state, and stateGetEcefOrigin_f().
Referenced by stateGetEcefOrigin_f().
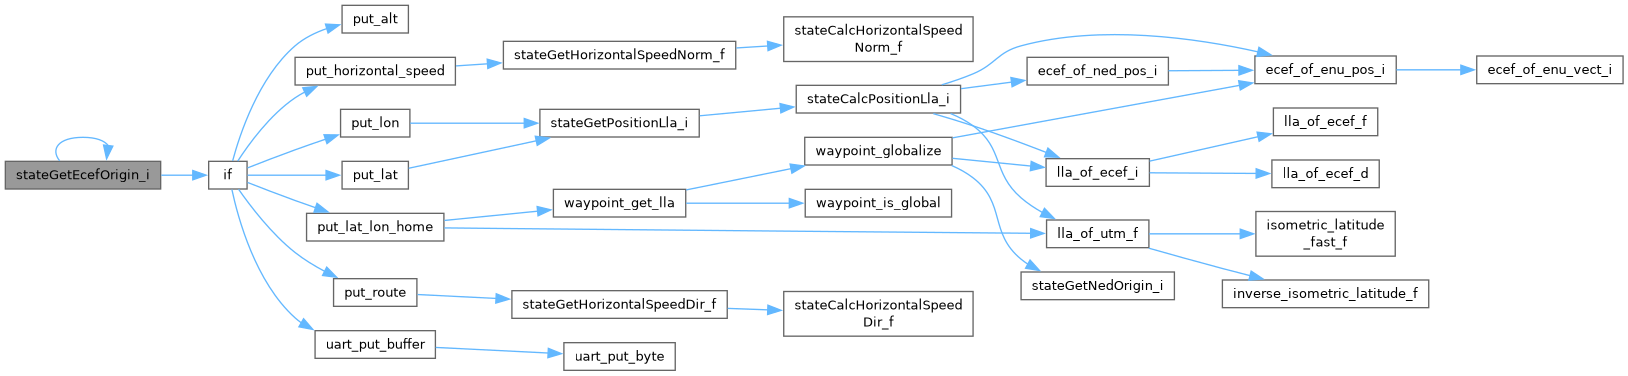
| struct EcefCoor_i stateGetEcefOrigin_i | ( | void | ) |
Get the ECEF position of the frame origin (int).
Definition at line 166 of file state.c.
References if(), state, and stateGetEcefOrigin_i().
Referenced by send_ins_ref(), and stateGetEcefOrigin_i().
| float stateGetHmslOrigin_f | ( | void | ) |
Get the HMSL of the frame origin (float).
Definition at line 210 of file state.c.
References M_OF_MM, and state.
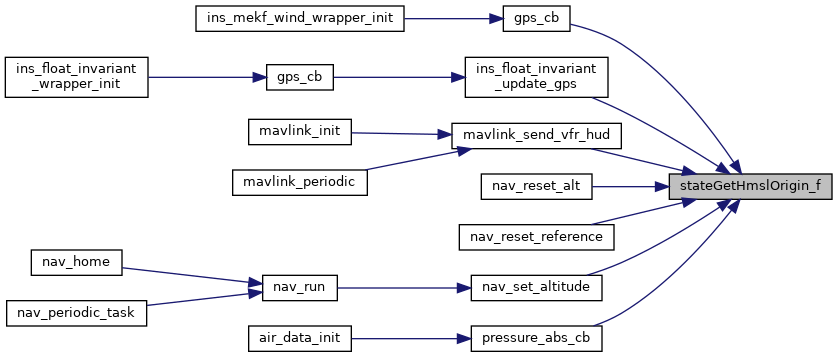
Referenced by air_data_set_pressure(), gps_cb(), ins_float_invariant_update_gps(), mavlink_send_vfr_hud(), nav_reset_alt(), nav_reset_reference(), nav_set_altitude(), and recover_gps_data().
| int32_t stateGetHmslOrigin_i | ( | void | ) |
Get the HMSL of the frame origin (int).
Definition at line 196 of file state.c.
References MM_OF_M, and state.
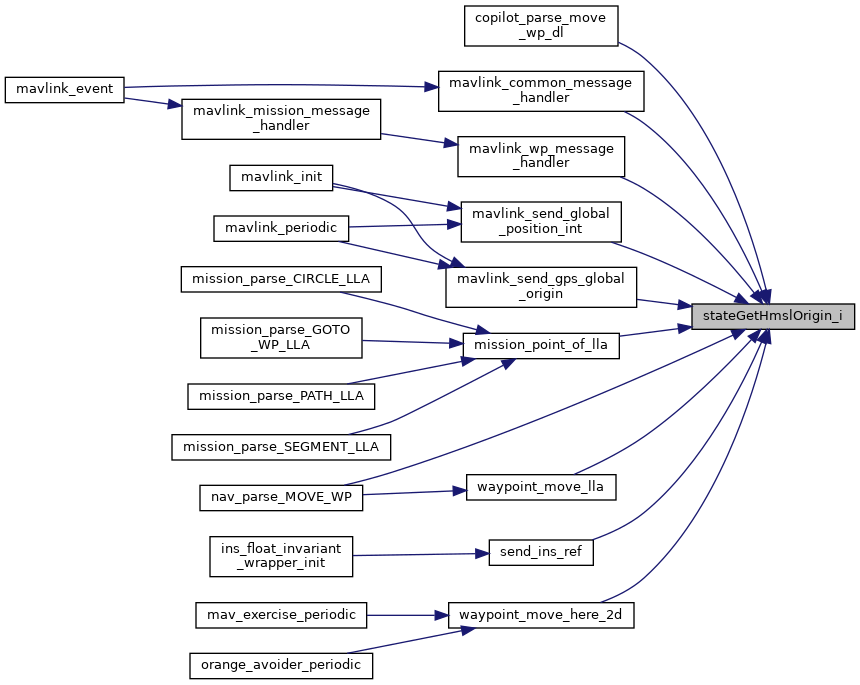
Referenced by copilot_parse_move_wp_dl(), mavlink_common_message_handler(), mavlink_send_global_position_int(), mavlink_send_gps_global_origin(), mavlink_wp_message_handler(), mission_point_of_lla(), nav_parse_MOVE_WP(), send_ins_ref(), waypoint_move_here_2d(), and waypoint_move_lla().
| struct LlaCoor_f stateGetLlaOrigin_f | ( | void | ) |
Get the LLA position of the frame origin (float).
Definition at line 149 of file state.c.
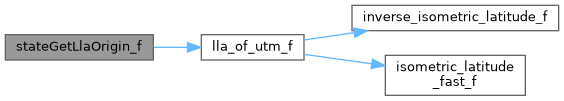
References if(), state, and stateGetLlaOrigin_f().
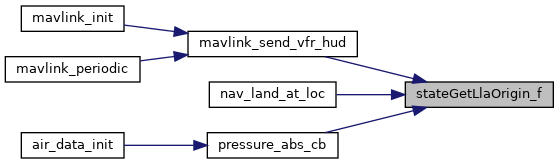
Referenced by air_data_set_pressure(), mavlink_send_vfr_hud(), nav_land_at_loc(), and stateGetLlaOrigin_f().
| struct LlaCoor_i stateGetLlaOrigin_i | ( | void | ) |
Get the LLA position of the frame origin (int).
Definition at line 130 of file state.c.
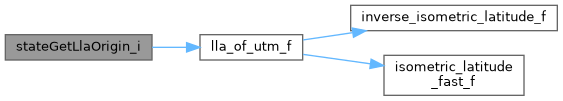
References if(), state, and stateGetLlaOrigin_i().
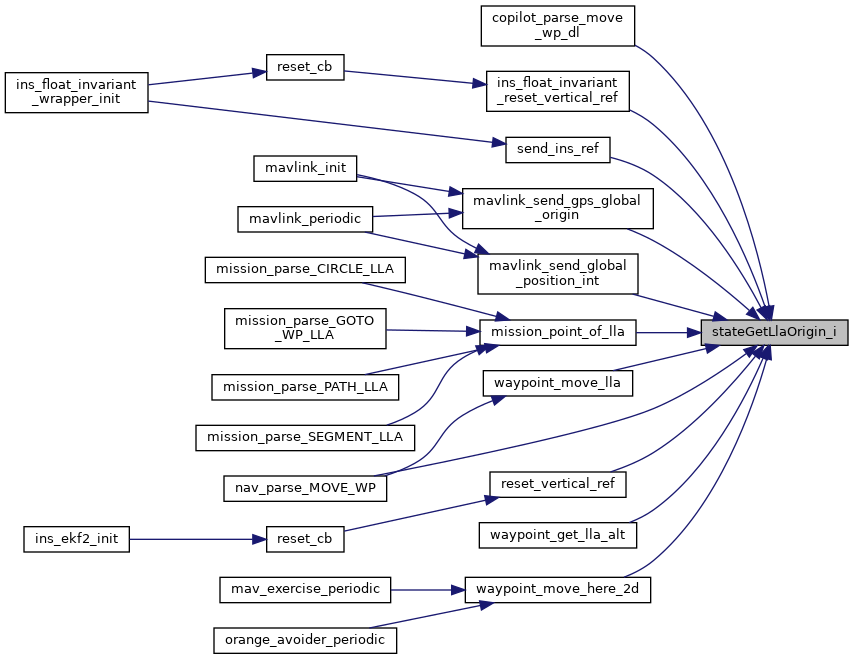
Referenced by copilot_parse_move_wp_dl(), ins_float_invariant_reset_vertical_ref(), mavlink_send_global_position_int(), mavlink_send_gps_global_origin(), mission_point_of_lla(), nav_parse_MOVE_WP(), reset_vertical_ref(), reset_vertical_ref(), reset_vertical_ref(), send_ins_ref(), stateGetLlaOrigin_i(), waypoint_get_lla_alt(), waypoint_move_here_2d(), and waypoint_move_lla().
|
inlinestatic |
Get the coordinate NED frame origin (float).
Definition at line 577 of file state.h.
References state.
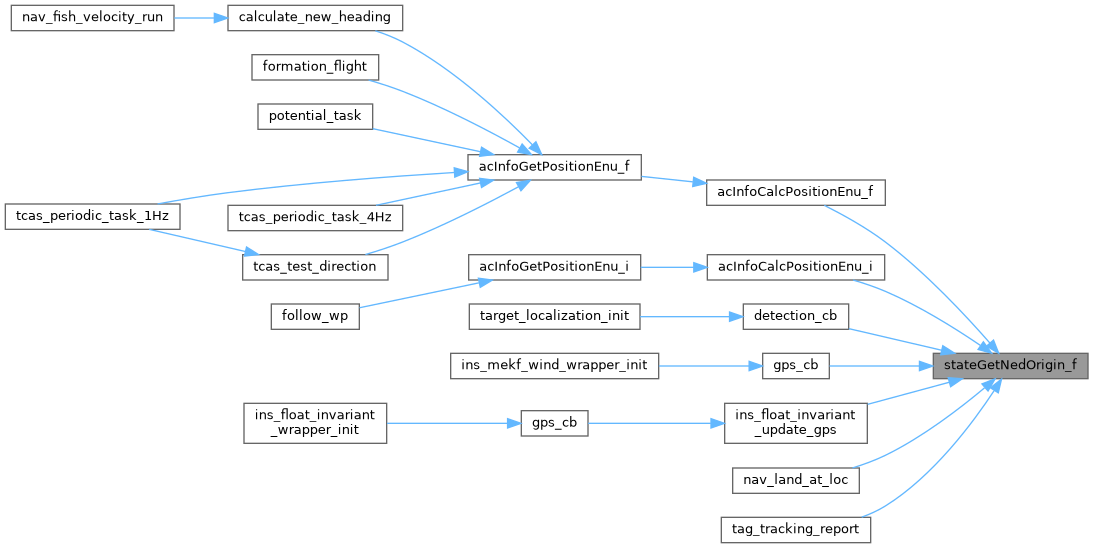
Referenced by acInfoCalcPositionEnu_f(), acInfoCalcPositionEnu_i(), convert_walls_to_ltp(), detection_cb(), gps_cb(), ins_float_invariant_update_gps(), nav_land_at_loc(), nav_poles_setup_lla(), and tag_tracking_report().
|
inlinestatic |
Get the coordinate NED frame origin (int).
Definition at line 567 of file state.h.
References state.
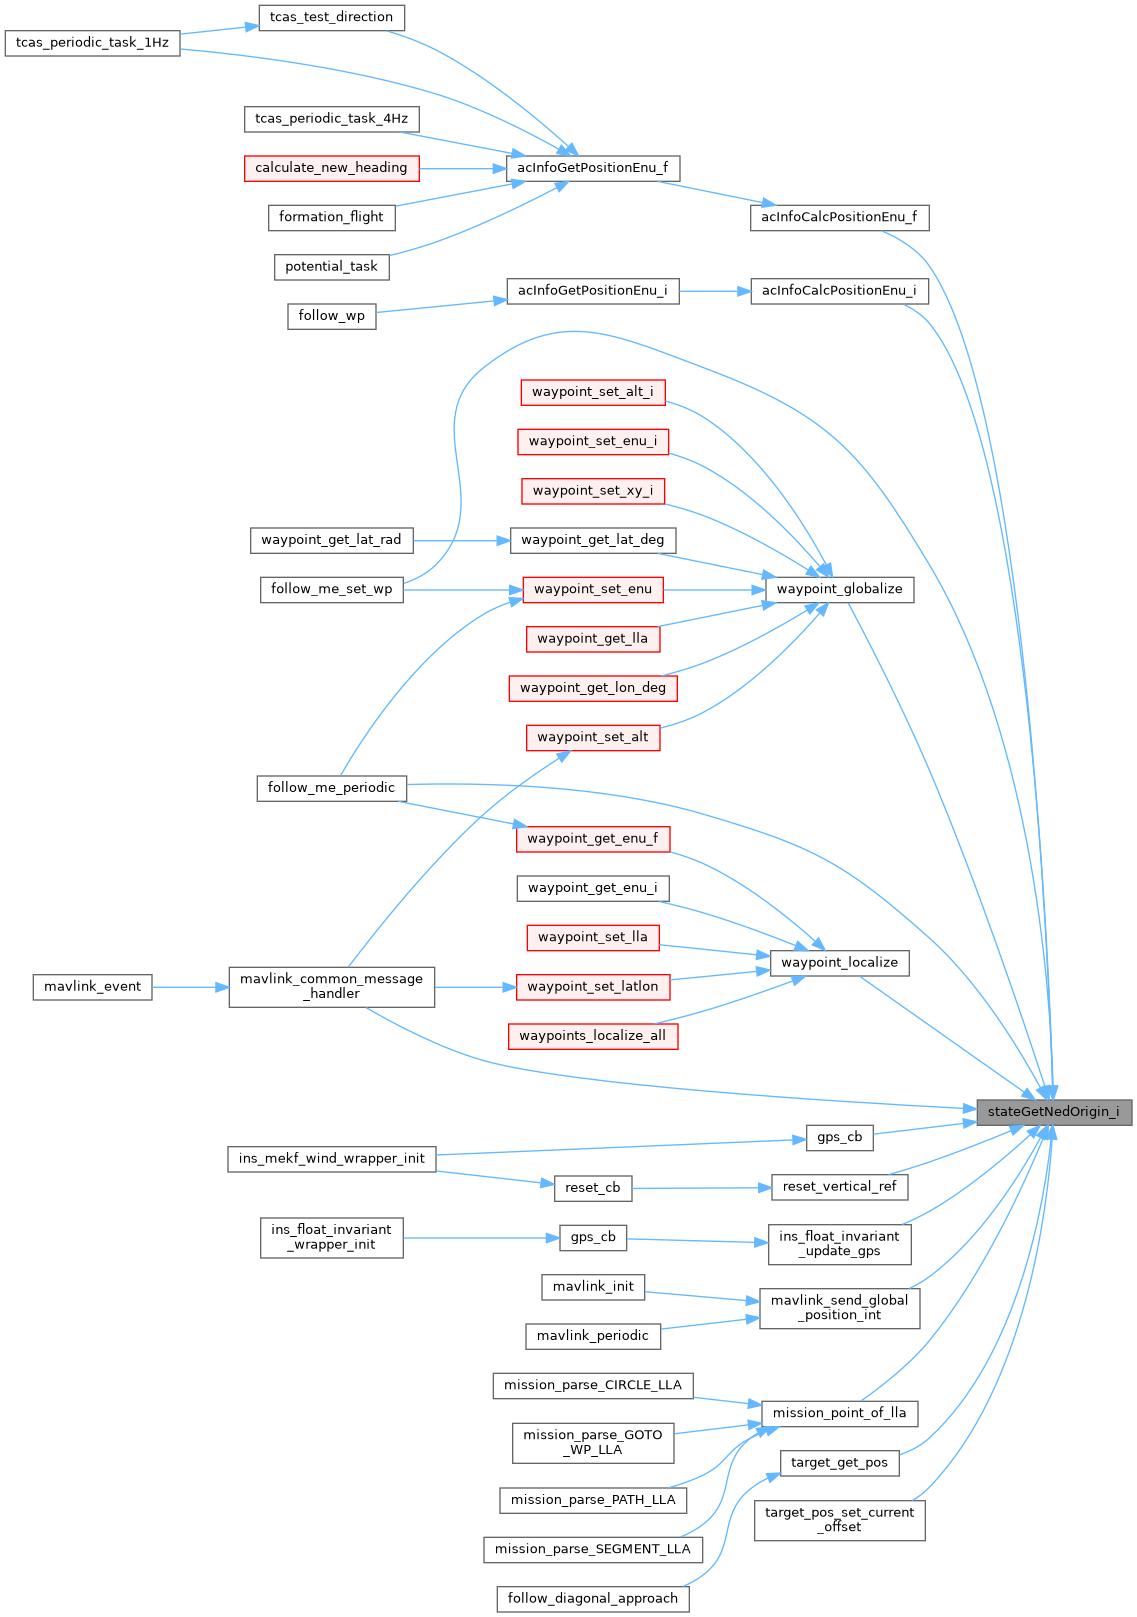
Referenced by acInfoCalcPositionEnu_f(), acInfoCalcPositionEnu_i(), follow_me_periodic(), follow_me_set_wp(), gps_cb(), ins_float_invariant_update_gps(), mavlink_common_message_handler(), mavlink_send_global_position_int(), mission_point_of_lla(), reset_vertical_ref(), sim_overwrite_lidar(), target_get_pos(), target_pos_set_current_offset(), waypoint_globalize(), and waypoint_localize().
|
inlinestatic |
Get position in ECEF coordinates (float).
Definition at line 841 of file state.h.
References POS_ECEF_F, state, and stateCalcPositionEcef_f().
|
inlinestatic |
Get position in ECEF coordinates (int).
Definition at line 796 of file state.h.
References POS_ECEF_I, state, and stateCalcPositionEcef_i().
Referenced by ins_vectornav_propagate().
|
inlinestatic |
Get position in local ENU coordinates (float).
Definition at line 859 of file state.h.
References POS_ENU_F, state, and stateCalcPositionEnu_f().
Referenced by airspeed_consistency_periodic(), ballistic_touchdown_run(), baro_cb(), bf_getEstimatedAltitudeCm(), calculate_new_heading(), calculateForwards(), cam_gimbal_nadir(), cam_gimbal_waypoint_target(), check_parachute_arming(), cloud_sim_detect(), collective_tracking_control(), compute_dist2_to_home(), compute_points_from_bungee(), ctc_target_send_info_to_nei(), dc_ctrl_parrot_mykonos_autoshoot(), dc_ctrl_parrot_mykonos_command(), dc_periodic(), dc_survey(), decawave_anchorless_communication_periodic(), distributed_circular(), draw_osd(), fill_bayesian_cell(), fill_free_cells(), flight_benchmark_periodic(), fly_to_xy(), formation_flight(), formation_pre_call(), get_dist2_to_point(), get_time_to_home(), gls_run(), gvf_ellipse_info(), gvf_line_info(), gvf_low_level_getState(), gvf_parametric_control_2D(), gvf_sin_info(), hackhd_autoshoot(), hackhd_command(), heading_towards_waypoint(), home_direction(), ins_update_lidar(), jevois_send_state(), mission_nav_path(), mission_nav_path(), mission_nav_segment(), mission_nav_segment(), mission_nav_wp(), mission_nav_wp(), nav_advance_carrot(), nav_approaching(), nav_approaching(), nav_approaching_xy(), nav_bungee_takeoff_run(), nav_catapult_run(), nav_check_wp_time(), nav_check_wp_time(), nav_circle(), nav_circle(), nav_circle_XY(), nav_flower_run(), nav_flower_setup(), nav_glide_points(), nav_gvf_ik_segment_XY1_XY2(), nav_gvf_segment_XY1_XY2(), nav_hybrid_approaching(), nav_hybrid_circle(), nav_hybrid_goto(), nav_hybrid_route(), nav_init_stage(), nav_lace_run(), nav_lace_setup(), nav_land_here(), nav_land_here(), nav_land_run(), nav_launcher_run(), nav_launcher_setup(), nav_line_osam_run(), nav_rosette_run(), nav_rosette_setup(), nav_route(), nav_route(), nav_route_xy(), nav_set_heading_towards(), nav_skid_landing_glide(), nav_spiral_3D_run(), nav_spiral_run(), nav_spiral_setup(), nav_survey_disc_run(), nav_survey_disc_setup(), nav_survey_hybrid_run(), nav_survey_poly_osam_run(), nav_survey_poly_run(), nav_survey_rectangle(), nav_survey_rectangle_init(), nav_survey_rectangle_rotorcraft_run(), nav_survey_rectangle_rotorcraft_setup(), nav_takeoff_from_here(), nav_takeoff_from_loc(), nav_takeoff_from_wp(), nav_takeoff_run(), nav_takeoff_run(), nav_trinity_run(), nav_trinity_setup(), out_of_segment_area(), potential_task(), process_data(), range_msg_callback(), recover_gps_data(), reset_all_vars(), rover_guidance_run(), rover_guidance_steering_setpoints(), scout_detector_sim(), send_acinfo_lla(), sim_overwrite_lidar(), snav_init(), snav_on_time(), sonar_adc_periodic(), sonar_i2c_periodic(), sonar_pwm_read(), sonar_vl53l1x_read(), stereo_avoid_run(), tcas_periodic_task_1Hz(), tcas_test_direction(), tfmini_i2c_periodic(), and vertical_ctrl_module_run().
|
inlinestatic |
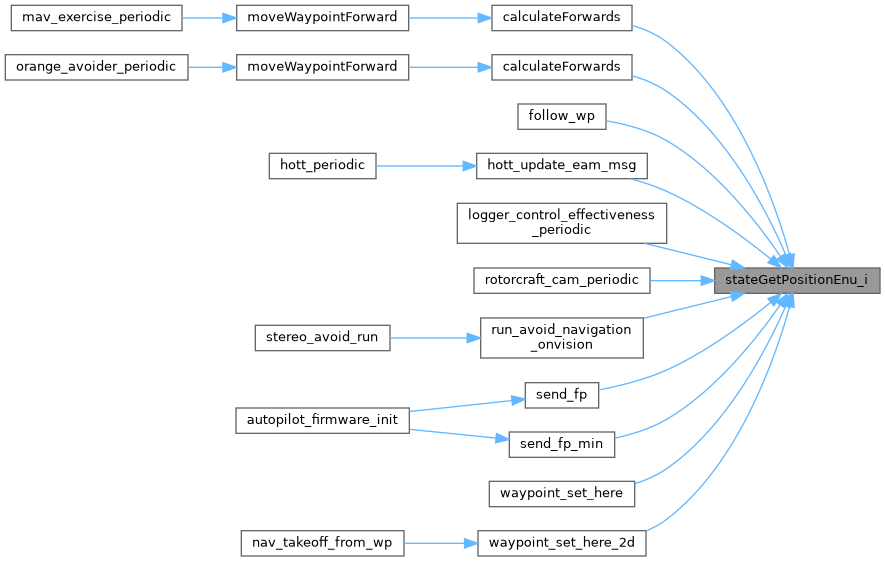
Get position in local ENU coordinates (int).
Definition at line 814 of file state.h.
References POS_ENU_I, state, and stateCalcPositionEnu_i().
Referenced by calculateForwards(), calculateForwards(), follow_wp(), hott_update_eam_msg(), logger_control_effectiveness_periodic(), rotorcraft_cam_periodic(), run_avoid_navigation_onvision(), send_fp(), send_fp_min(), waypoint_set_here(), and waypoint_set_here_2d().
|
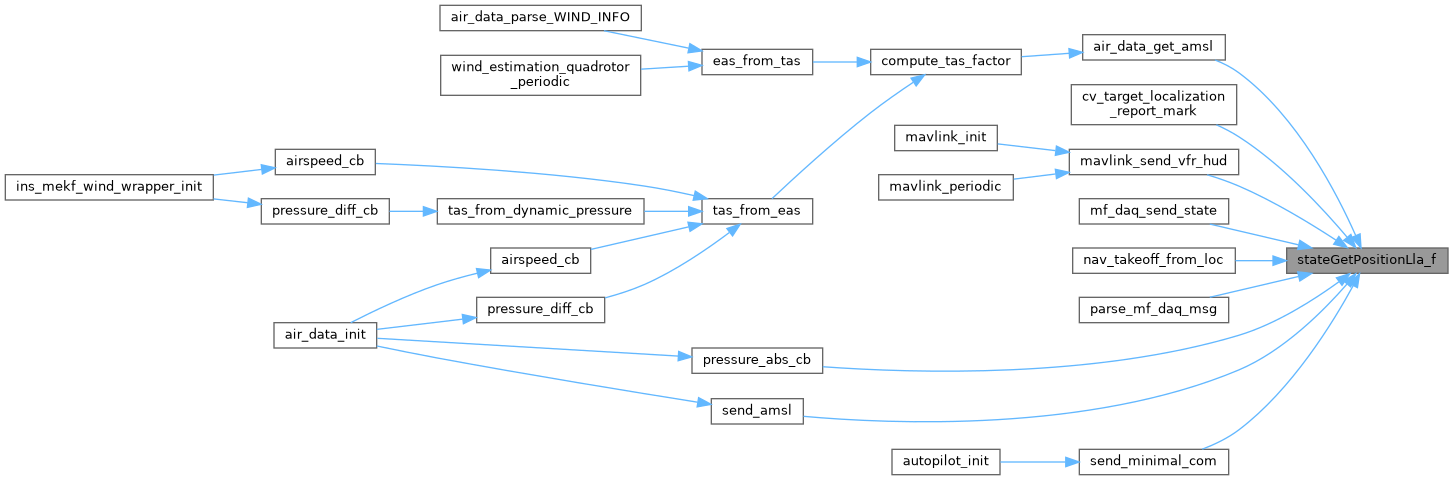
inlinestatic |
Get position in LLA coordinates (float).
Definition at line 868 of file state.h.
References POS_LLA_F, state, and stateCalcPositionLla_f().
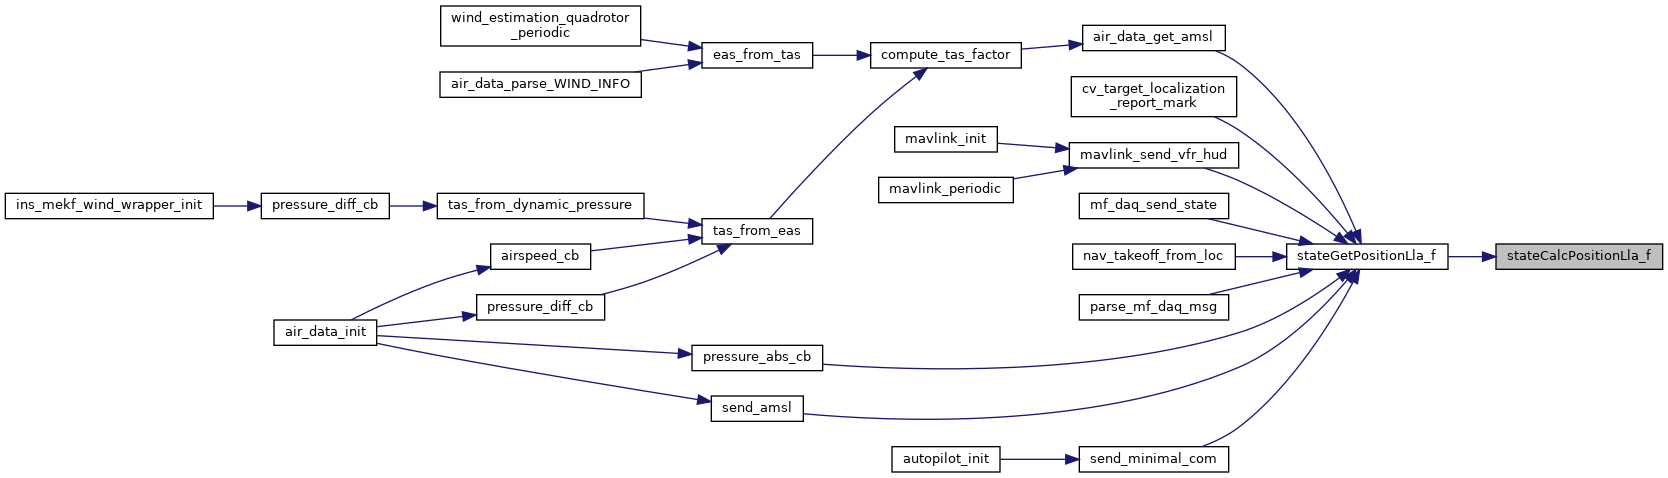
Referenced by air_data_get_amsl(), air_data_set_pressure(), cv_target_localization_report_mark(), mavlink_send_vfr_hud(), mf_daq_send_state(), nav_takeoff_from_loc(), parse_mf_daq_msg(), recover_gps_data(), send_acinfo_lla(), send_amsl(), and send_minimal_com().
|
inlinestatic |
Get position in LLA coordinates (int).
Definition at line 823 of file state.h.
References POS_LLA_I, state, and stateCalcPositionLla_i().
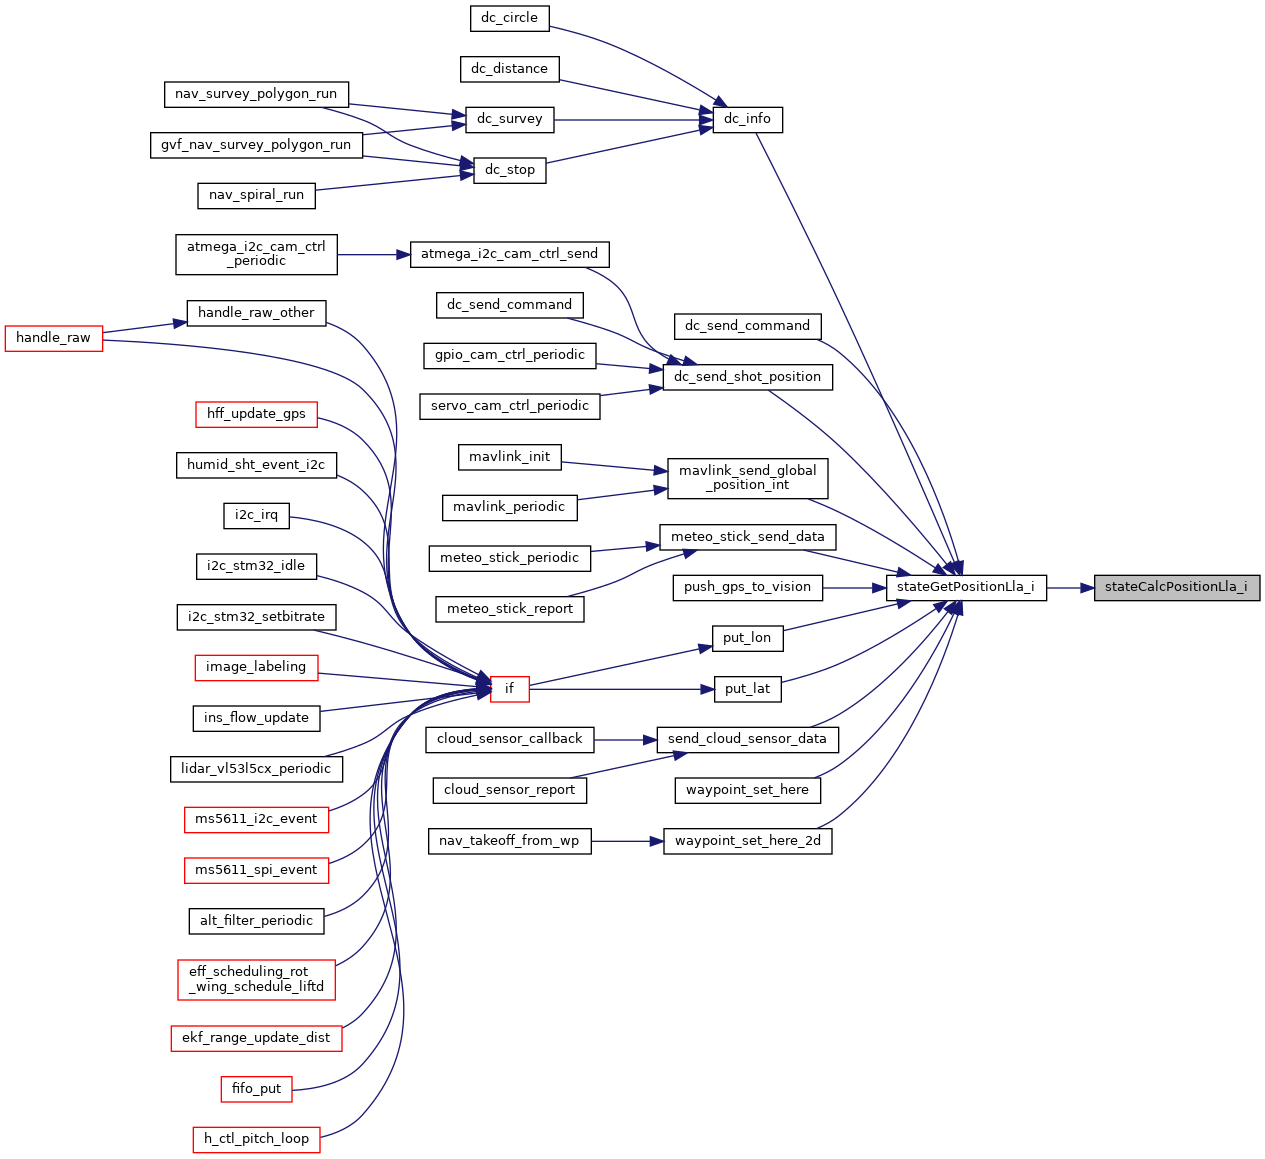
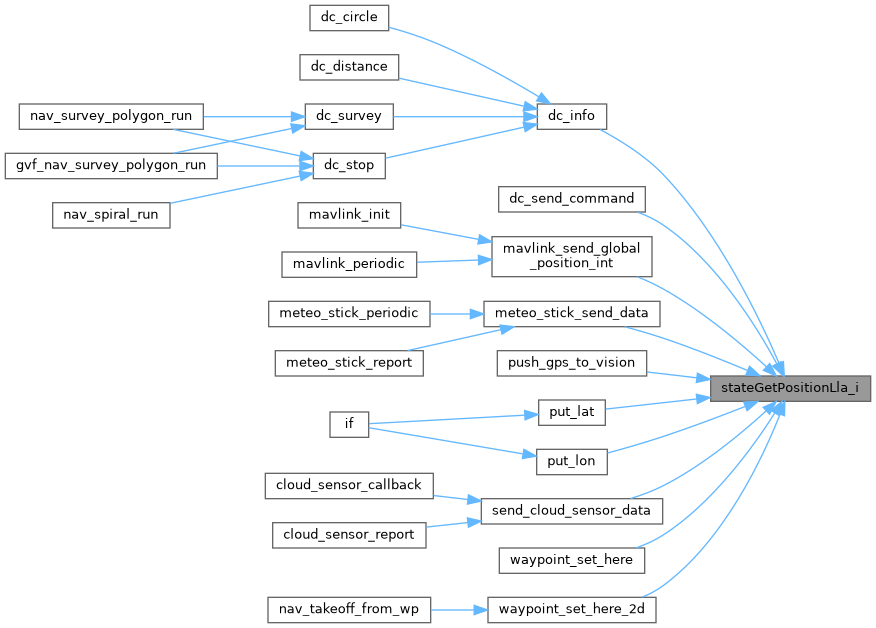
Referenced by dc_info(), dc_send_command(), mavlink_send_global_position_int(), meteo_stick_send_data(), push_gps_to_vision(), put_lat(), put_lon(), send_acinfo_lla(), send_cloud_sensor_data(), waypoint_set_here(), and waypoint_set_here_2d().
|
inlinestatic |
Get position in local NED coordinates (float).
Definition at line 850 of file state.h.
References POS_NED_F, state, and stateCalcPositionNed_f().
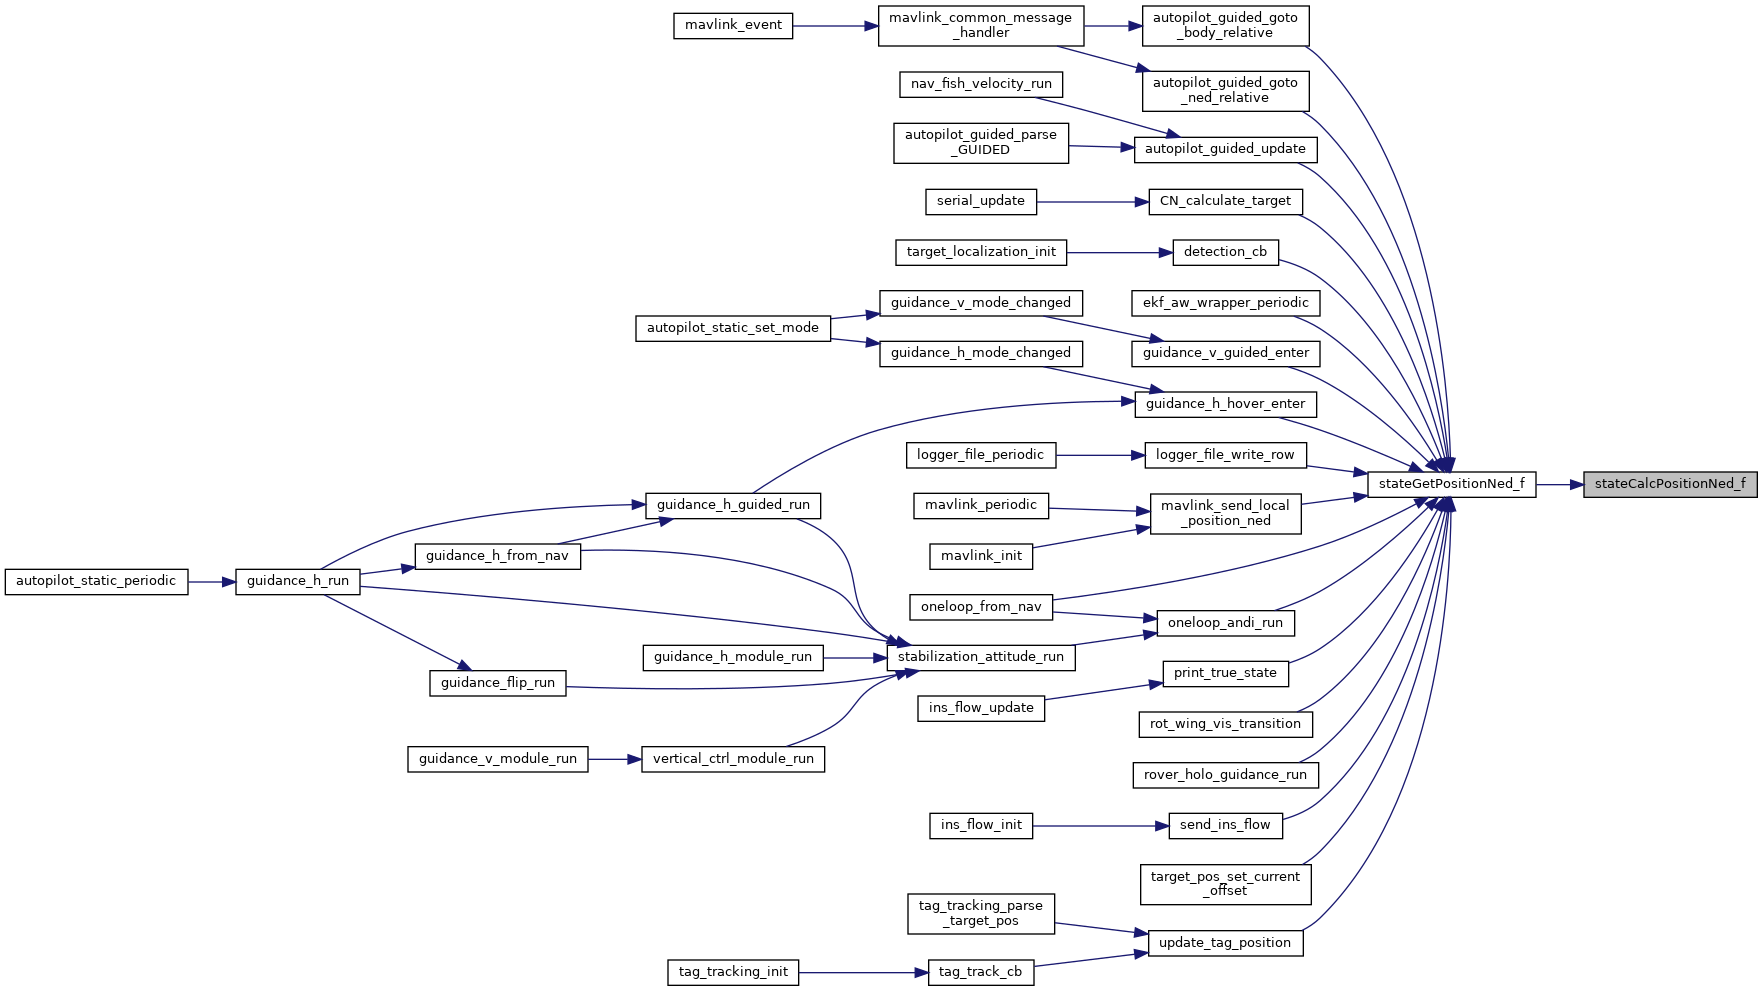
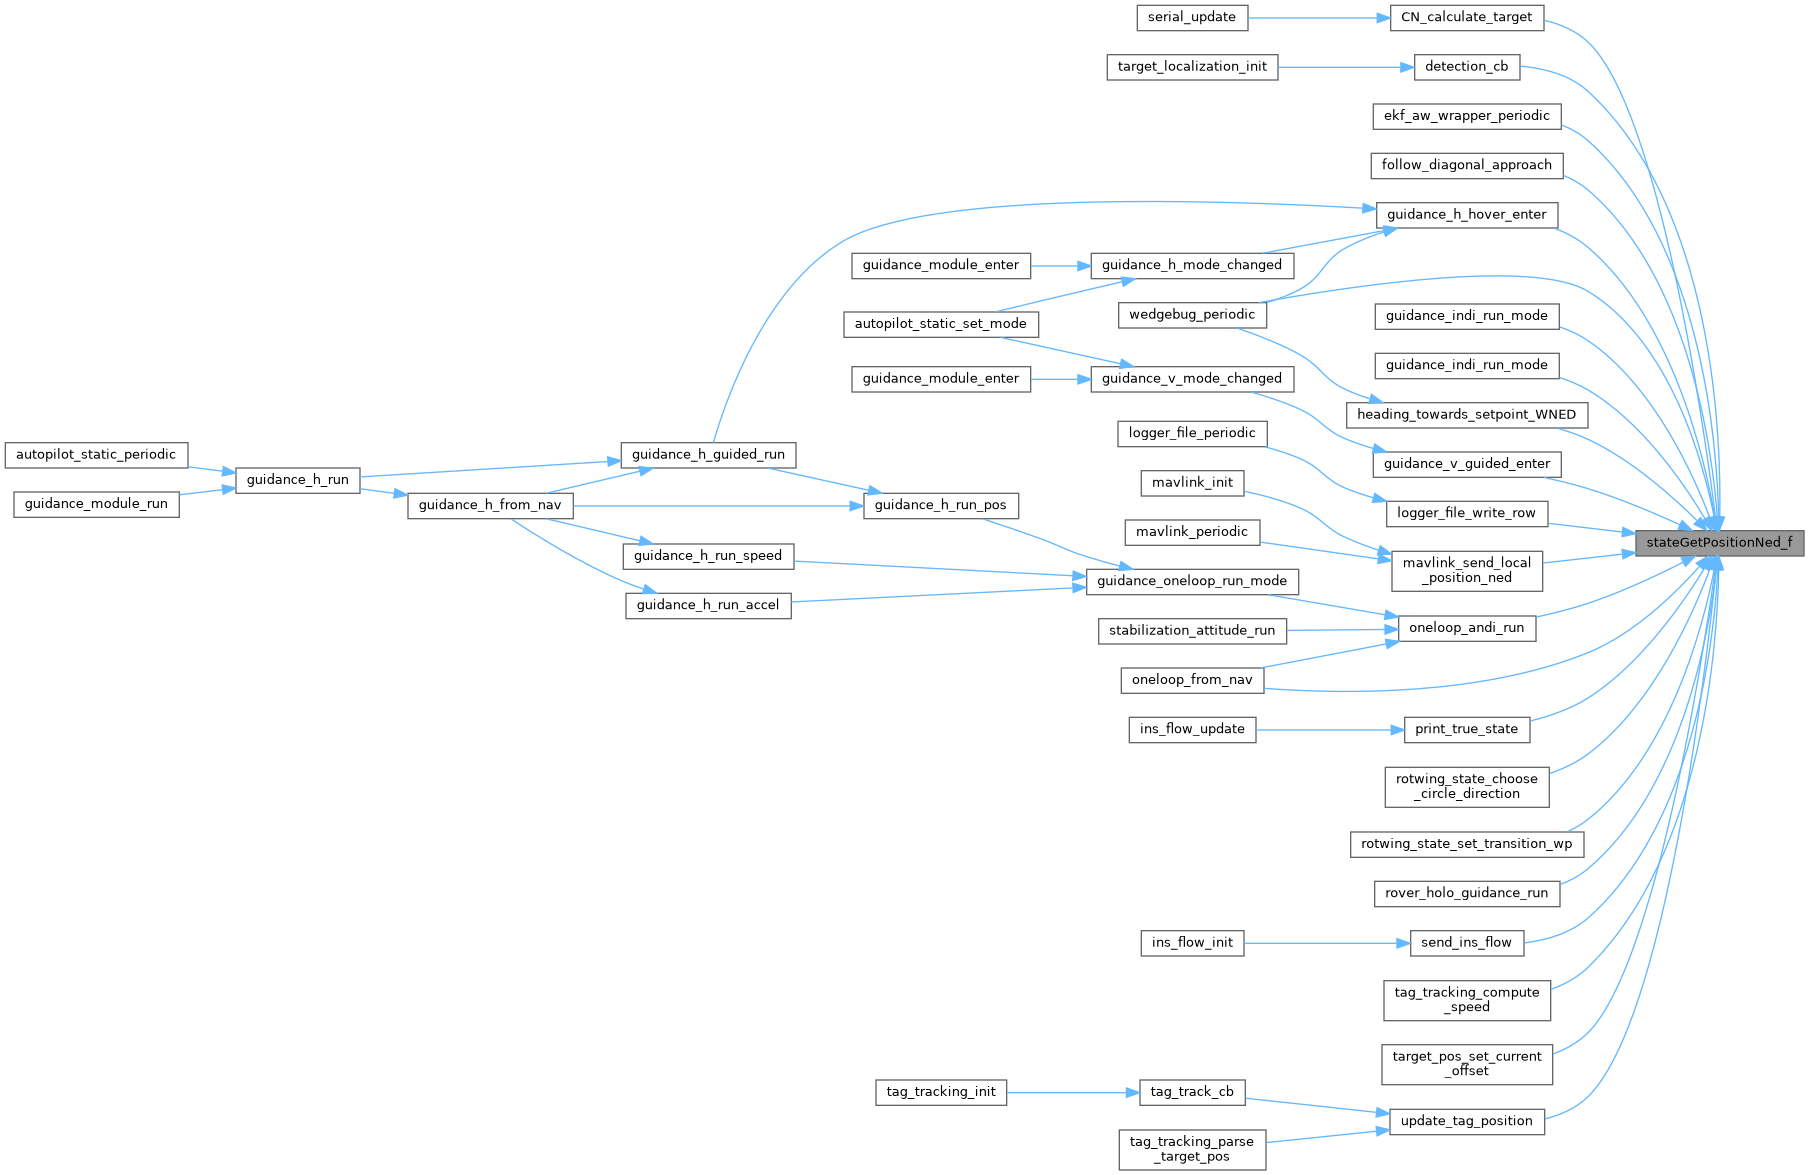
Referenced by cam_gimbal_target(), CN_calculate_target(), detection_cb(), ekf_aw_wrapper_periodic(), follow_diagonal_approach(), guidance_h_hover_enter(), guidance_indi_controller(), guidance_indi_controller(), guidance_indi_controller(), guidance_v_guided_enter(), heading_towards_setpoint_WNED(), logger_file_write_row(), mavlink_send_local_position_ned(), oneloop_andi_run(), oneloop_from_nav(), oneloop_nB_run(), print_true_state(), rotwing_state_choose_circle_direction(), rover_holo_guidance_run(), scout_detector_sim(), scout_detector_uavcan_cb(), send_ins_flow(), tag_tracking_compute_speed(), target_pos_set_current_offset(), update_tag_position(), and wedgebug_periodic().
|
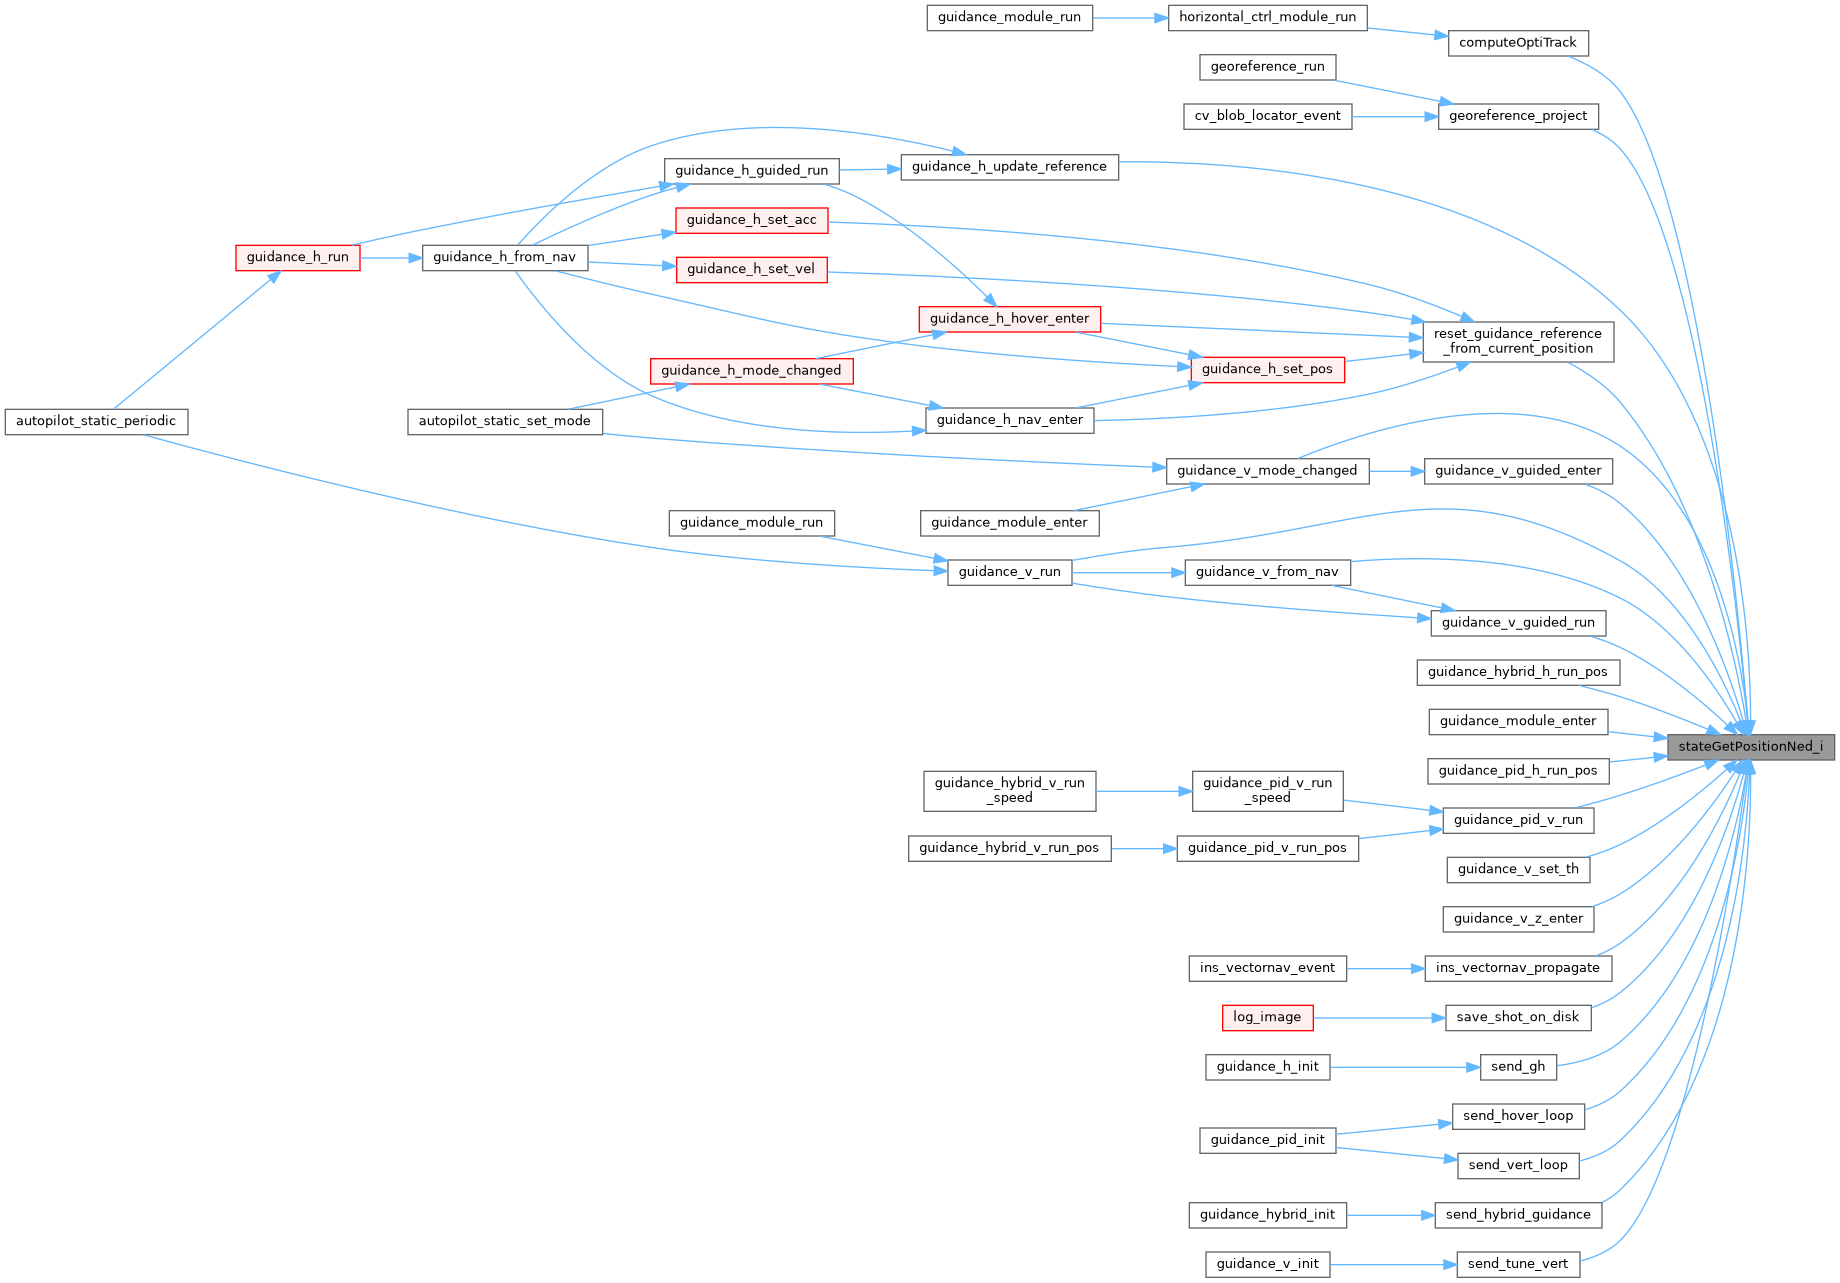
inlinestatic |
Get position in local NED coordinates (int).
Definition at line 805 of file state.h.
References POS_NED_I, state, and stateCalcPositionNed_i().
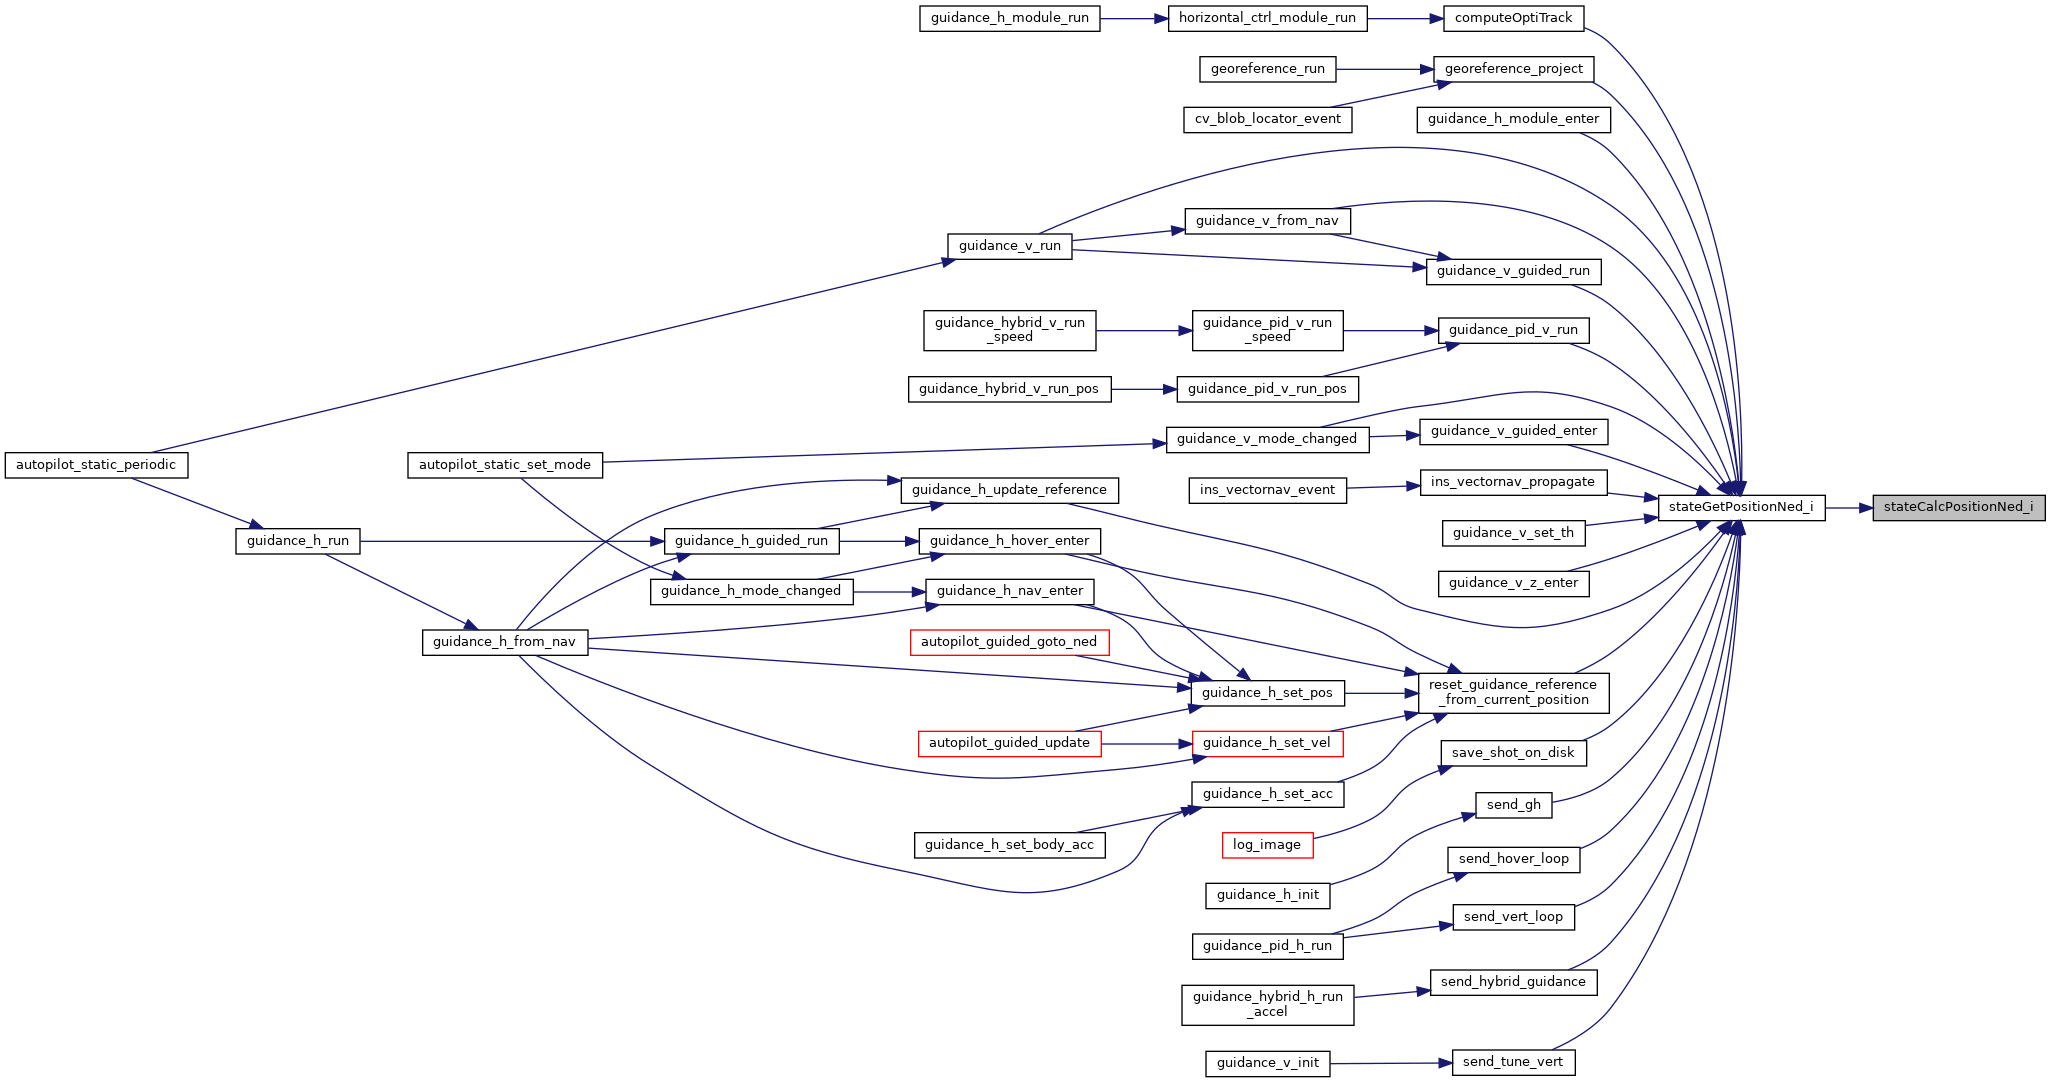
Referenced by computeOptiTrack(), georeference_project(), guidance_h_update_reference(), guidance_hybrid_h_run_pos(), guidance_module_enter(), guidance_pid_h_run_pos(), guidance_pid_v_run(), guidance_v_from_nav(), guidance_v_guided_enter(), guidance_v_guided_run(), guidance_v_mode_changed(), guidance_v_run(), guidance_v_set_th(), guidance_v_z_enter(), ins_vectornav_propagate(), reset_guidance_reference_from_current_position(), send_gh(), send_hover_loop(), send_hybrid_guidance(), send_tune_vert(), and send_vert_loop().
|
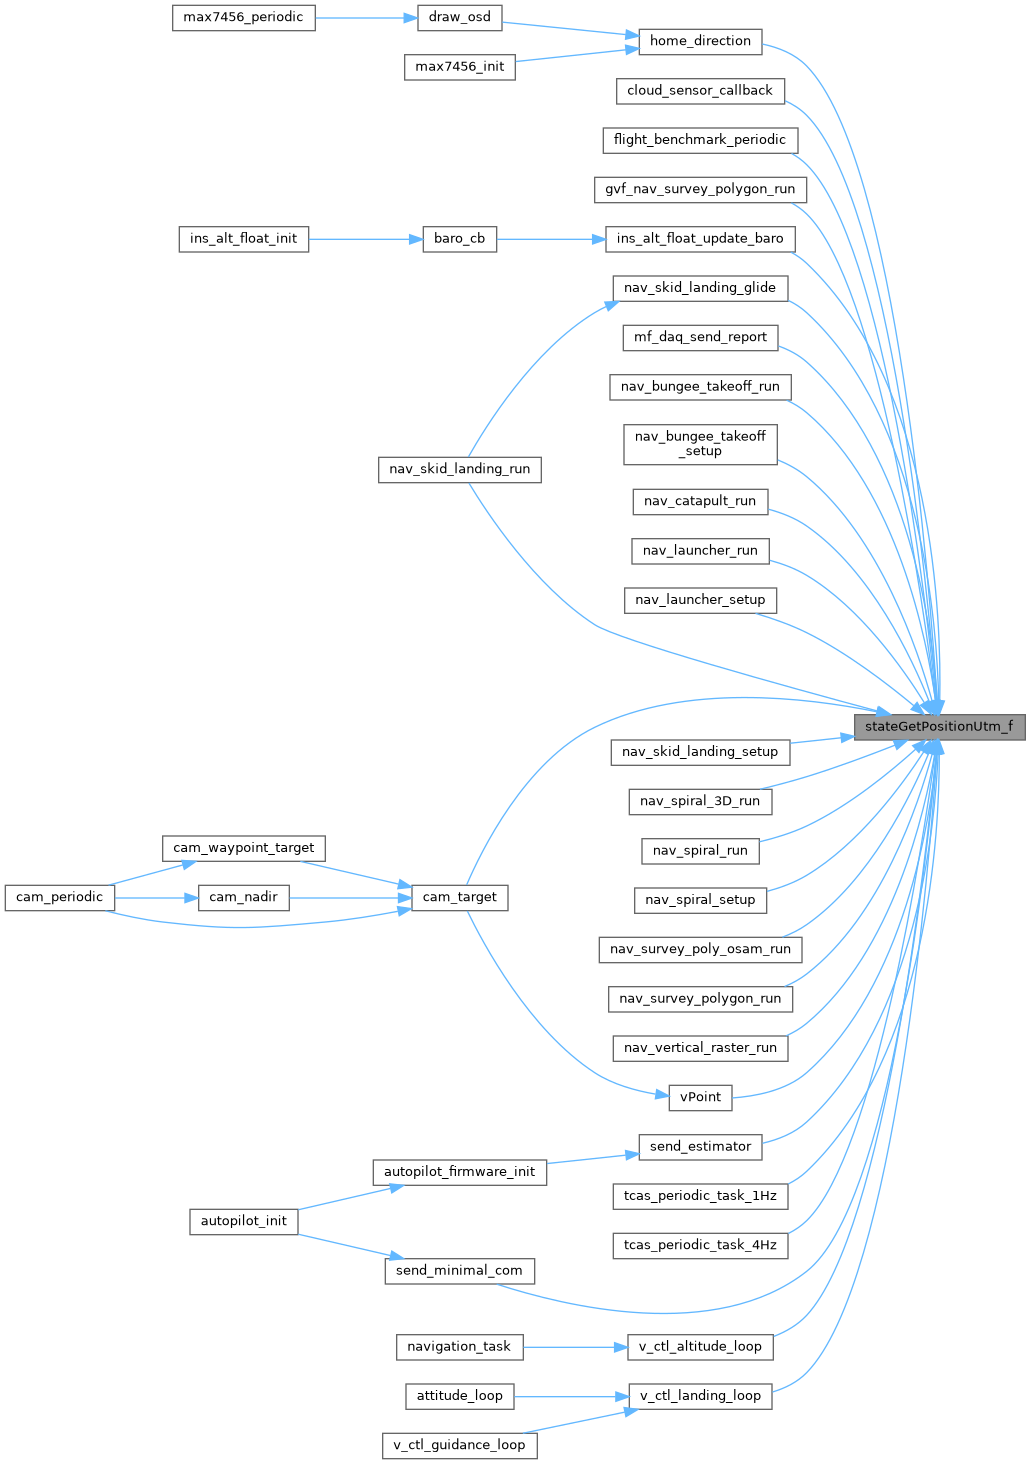
inlinestatic |
Get position in UTM coordinates (float).
Definition at line 832 of file state.h.
References POS_UTM_F, state, and stateCalcPositionUtm_f().
Referenced by cloud_sensor_callback(), flight_benchmark_periodic(), home_direction(), ins_alt_float_update_baro(), mf_daq_send_report(), nav_bungee_takeoff_run(), nav_bungee_takeoff_setup(), nav_catapult_run(), nav_gvf_survey_polygon_run(), nav_launcher_run(), nav_launcher_setup(), nav_skid_landing_glide(), nav_skid_landing_run(), nav_skid_landing_setup(), nav_spiral_3D_run(), nav_spiral_run(), nav_spiral_setup(), nav_survey_poly_osam_run(), nav_survey_polygon_run(), nav_vertical_raster_run(), send_estimator(), send_minimal_com(), tcas_periodic_task_1Hz(), tcas_periodic_task_4Hz(), v_ctl_altitude_loop(), and v_ctl_landing_loop().
|
inlinestatic |
Get the coordinate UTM frame origin (int).
Definition at line 587 of file state.h.
References state.
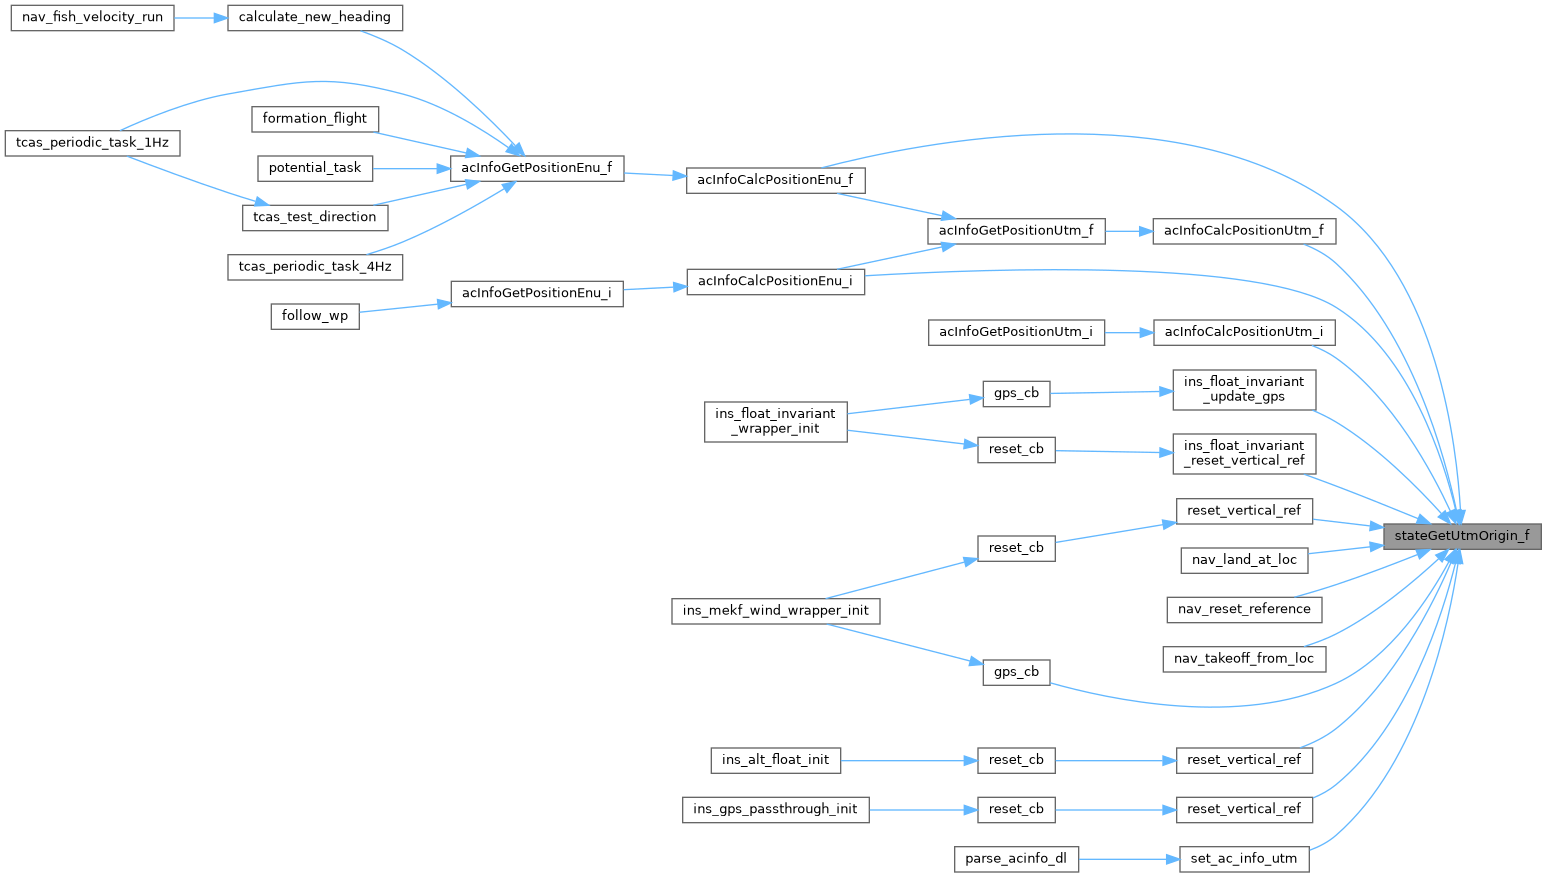
Referenced by acInfoCalcPositionEnu_f(), acInfoCalcPositionEnu_i(), acInfoCalcPositionUtm_f(), acInfoCalcPositionUtm_i(), gps_cb(), ins_float_invariant_reset_vertical_ref(), ins_float_invariant_update_gps(), nav_land_at_loc(), nav_reset_reference(), nav_takeoff_from_loc(), reset_vertical_ref(), reset_vertical_ref(), reset_vertical_ref(), and set_ac_info_utm().
|
inlinestatic |
Test if global coordinates are valid.
Definition at line 631 of file state.h.
References POS_GLOBAL_COORD, state, and stateIsLocalCoordinateValid().
Referenced by air_data_set_pressure().
|
inlinestatic |
Test if local coordinates are valid.
Definition at line 624 of file state.h.
References POS_LOCAL_COORD, and state.
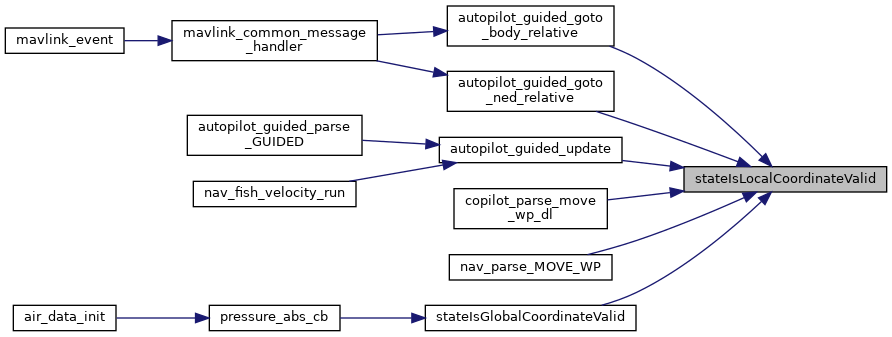
Referenced by convert_walls_to_ltp(), copilot_parse_move_wp_dl(), ins_update_lidar(), nav_parse_MOVE_WP(), sim_overwrite_lidar(), and stateIsGlobalCoordinateValid().
Set the local (flat earth) coordinate frame origin (int).
Definition at line 530 of file state.h.
References ACCEL_NED_F, ACCEL_NED_I, ECEF_FLOAT_OF_BFP, HIGH_RES_RMAT_FLOAT_OF_BFP, LLA_FLOAT_OF_BFP, ltp_def, M_OF_MM, POS_LOCAL_COORD, SPEED_LOCAL_COORD, state, and STATE_CHECK_INPUT_AND_RETURN.
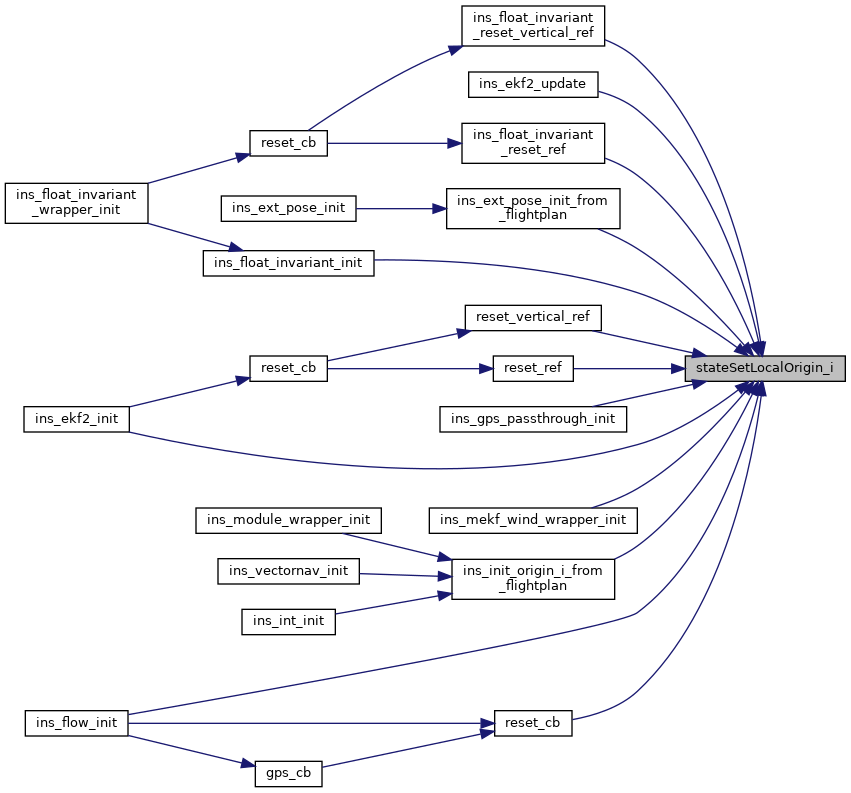
Referenced by ins_ekf2_init(), ins_ekf2_update(), ins_ext_pose_init_from_flightplan(), ins_float_invariant_init(), ins_float_invariant_reset_ref(), ins_float_invariant_reset_vertical_ref(), ins_flow_init(), ins_gps_passthrough_init(), ins_init_origin_i_from_flightplan(), ins_mekf_wind_wrapper_init(), reset_cb(), reset_cb(), reset_ref(), reset_ref(), reset_ref(), reset_ref(), reset_vertical_ref(), reset_vertical_ref(), reset_vertical_ref(), and reset_vertical_ref().
Set the local (flat earth) coordinate frame origin from UTM (float).
Definition at line 552 of file state.h.
References ACCEL_NED_F, ACCEL_NED_I, POS_LOCAL_COORD, SPEED_LOCAL_COORD, state, and STATE_CHECK_INPUT_AND_RETURN.
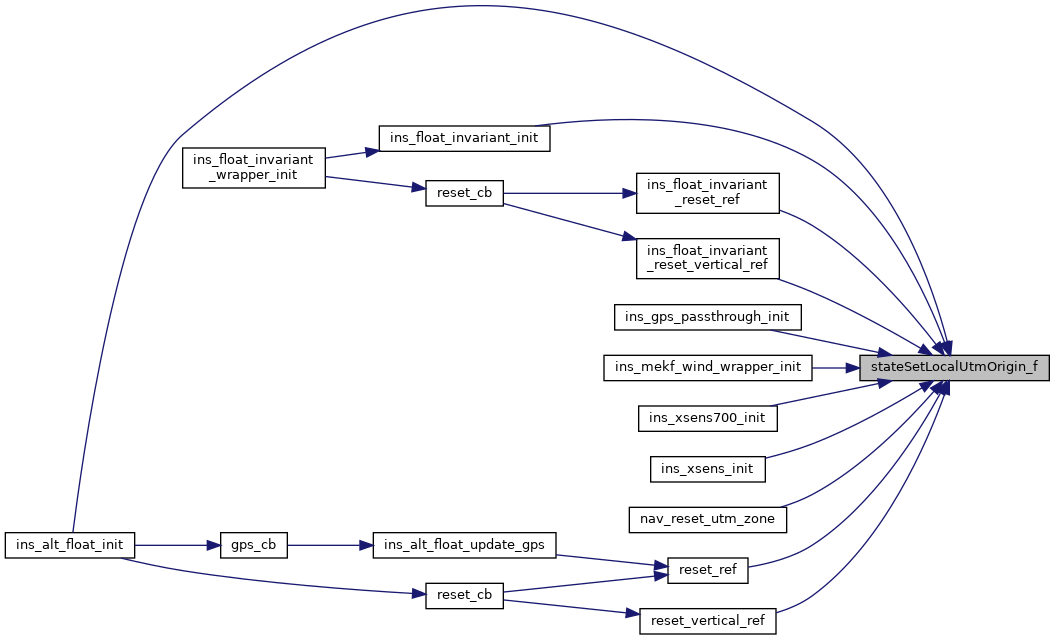
Referenced by ins_alt_float_init(), ins_float_invariant_init(), ins_float_invariant_reset_ref(), ins_float_invariant_reset_vertical_ref(), ins_gps_passthrough_init(), ins_mekf_wind_wrapper_init(), ins_xsens700_init(), ins_xsens_init(), nav_reset_utm_zone(), reset_ref(), reset_ref(), reset_ref(), reset_vertical_ref(), reset_vertical_ref(), and reset_vertical_ref().
|
inlinestatic |
Set multiple position coordinates (float).
Definition at line 759 of file state.h.
References LLA_COPY, POS_ECEF_F, POS_ENU_F, POS_LLA_F, POS_NED_F, POS_UTM_F, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
|
inlinestatic |
Set multiple position coordinates (int).
Definition at line 679 of file state.h.
References LLA_COPY, POS_ECEF_I, POS_ENU_I, POS_LLA_I, POS_NED_I, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
|
inlinestatic |
Set position from ECEF coordinates (float).
Definition at line 719 of file state.h.
References POS_ECEF_F, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
|
inlinestatic |
Set position from ECEF coordinates (int).
Definition at line 639 of file state.h.
References POS_ECEF_I, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
Set position from local ENU coordinates (float).
Definition at line 739 of file state.h.
References POS_ENU_F, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
Set position from local ENU coordinates (int).
Definition at line 659 of file state.h.
References POS_ENU_I, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
Set position from LLA coordinates (float).
Definition at line 749 of file state.h.
References LLA_COPY, POS_LLA_F, state, and STATE_CHECK_INPUT_AND_RETURN.
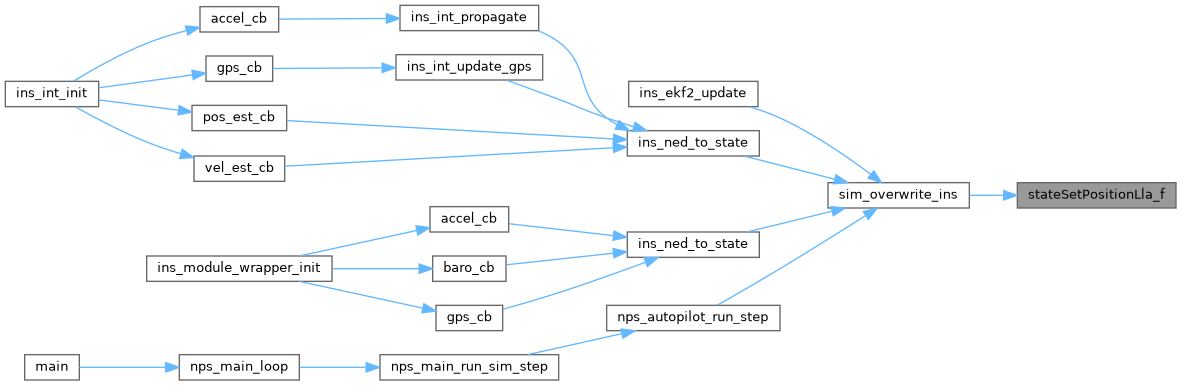
Referenced by sim_overwrite_ins().
Set position from LLA coordinates (int).
Definition at line 669 of file state.h.
References LLA_COPY, POS_LLA_I, state, and STATE_CHECK_INPUT_AND_RETURN.
Referenced by ins_vectornav_propagate().
Set position from local NED coordinates (float).
Definition at line 729 of file state.h.
References POS_NED_F, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
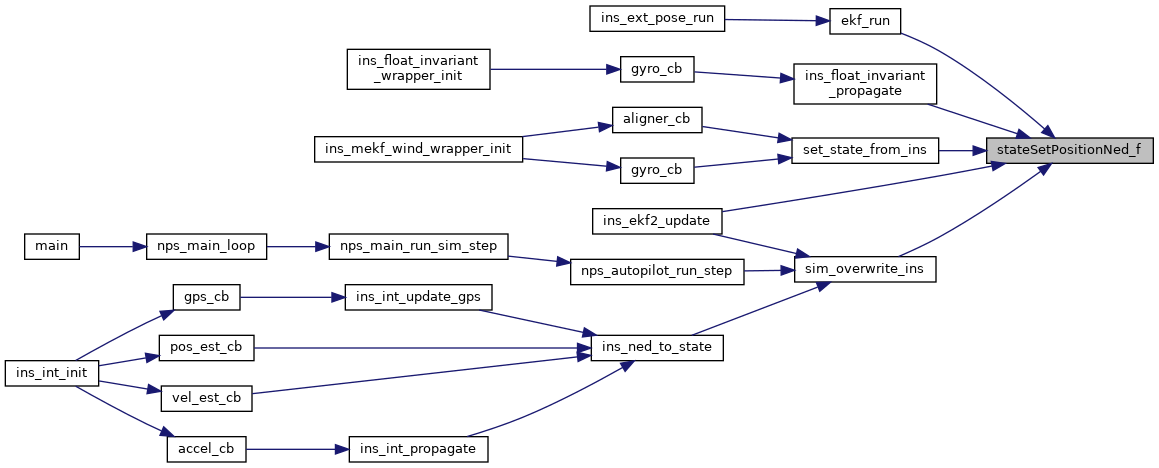
Referenced by ekf_run(), ins_ekf2_update(), ins_float_invariant_propagate(), set_state_from_ins(), and sim_overwrite_ins().
Set position from local NED coordinates (int).
Definition at line 649 of file state.h.
References POS_NED_I, state, STATE_CHECK_INPUT_AND_RETURN, and VECT3_COPY.
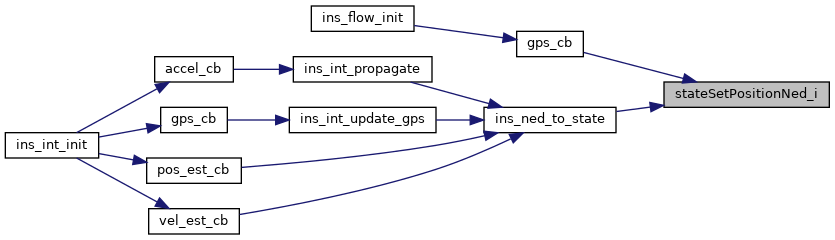
Referenced by gps_cb(), gps_cb(), ins_ned_to_state(), and ins_ned_to_state().
Set position from UTM coordinates (float).
Definition at line 709 of file state.h.
References POS_UTM_F, state, and STATE_CHECK_INPUT_AND_RETURN.
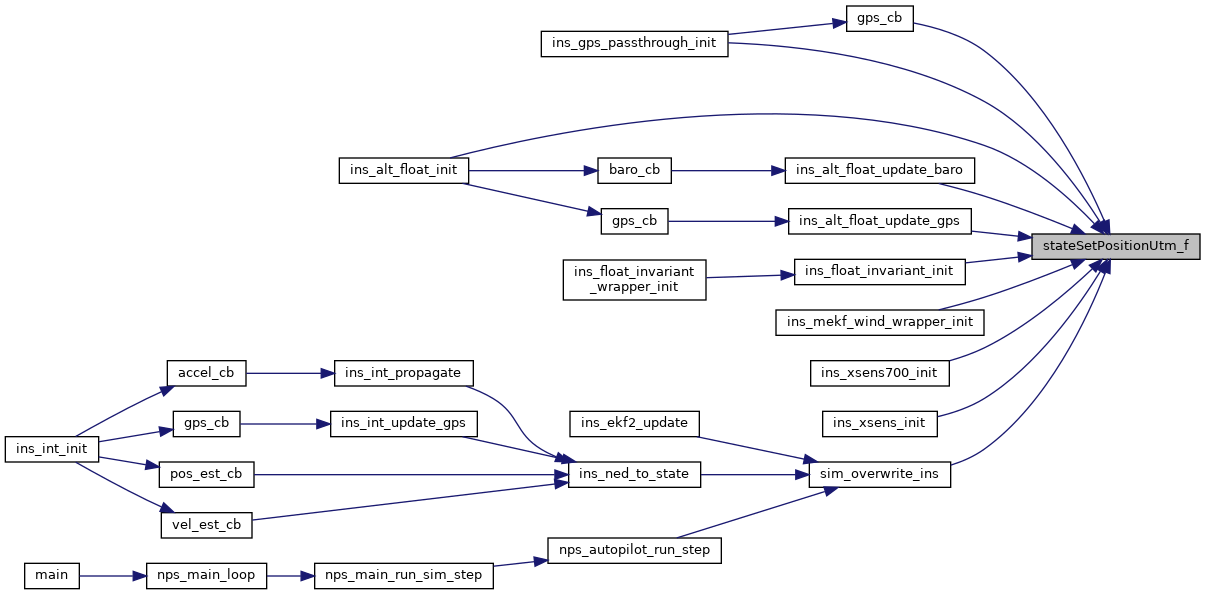
Referenced by gps_cb(), gps_cb(), gps_cb(), ins_alt_float_init(), ins_alt_float_update_baro(), ins_alt_float_update_gps(), ins_float_invariant_init(), ins_gps_passthrough_init(), ins_mekf_wind_wrapper_init(), ins_xsens700_init(), and ins_xsens_init().
| float State::alt_agl_f |
| struct EcefCoor_f State::ecef_pos_f |
| struct EcefCoor_i State::ecef_pos_i |
| struct EnuCoor_f State::enu_pos_f |
| struct EnuCoor_i State::enu_pos_i |
| struct LlaCoor_f State::lla_pos_f |
| struct LlaCoor_i State::lla_pos_i |
| bool State::ned_initialized_f |
| bool State::ned_initialized_i |
| struct LtpDef_f State::ned_origin_f |
Definition of the local (flat earth) coordinate system.
Defines the origin of the local NorthEastDown coordinate system in ECEF (EarthCenteredEarthFixed) and LLA (LatitudeLongitudeAlt) coordinates and the roation matrix from ECEF to local frame. (float version)
| struct LtpDef_i State::ned_origin_i |
| struct NedCoor_f State::ned_pos_f |
| struct NedCoor_i State::ned_pos_i |
| uint16_t State::origin_input_filter |
| uint16_t State::pos_input_filter |
| uint16_t State::pos_status |
| bool State::utm_initialized_f |
| struct UtmCoor_f State::utm_origin_f |
 1.15.0