|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Go to the source code of this file.
Data Structures | |
| struct | ekfAwParameters |
| struct | ekfHealth |
Macros | |
| #define | ekf_aw_update_Q_accel(_v) |
| #define | ekf_aw_update_Q_gyro(_v) |
| #define | ekf_aw_update_Q_mu(_v) |
| #define | ekf_aw_update_Q_k(_v) |
| #define | ekf_aw_update_R_V_gnd(_v) |
| #define | ekf_aw_update_R_accel_filt_x(_v) |
| #define | ekf_aw_update_R_accel_filt_y(_v) |
| #define | ekf_aw_update_R_accel_filt_z(_v) |
| #define | ekf_aw_update_R_V_pitot(_v) |
Functions | |
| void | ekf_aw_init (void) |
| void | ekf_aw_reset (void) |
| void | ekf_aw_propagate (struct FloatVect3 *acc, struct FloatRates *gyro, struct FloatEulers *euler, float *pusher_RPM, float *hover_RPM_array, float *skew, float *elevator_angle, struct FloatVect3 *V_gnd, struct FloatVect3 *acc_filt, float *V_pitot, float dt) |
| struct NedCoor_f | ekf_aw_get_speed_body (void) |
| struct NedCoor_f | ekf_aw_get_wind_ned (void) |
| struct NedCoor_f | ekf_aw_get_offset (void) |
| struct FloatVect3 | ekf_aw_get_innov_V_gnd (void) |
| struct FloatVect3 | ekf_aw_get_innov_accel_filt (void) |
| float | ekf_aw_get_innov_V_pitot (void) |
| void | ekf_aw_get_meas_cov (float meas_cov[7]) |
| void | ekf_aw_get_state_cov (float state_cov[9]) |
| void | ekf_aw_get_process_cov (float process_cov[9]) |
| void | ekf_aw_get_fuselage_force (float force[3]) |
| void | ekf_aw_get_wing_force (float force[3]) |
| void | ekf_aw_get_elevator_force (float force[3]) |
| void | ekf_aw_get_hover_force (float force[3]) |
| void | ekf_aw_get_pusher_force (float force[3]) |
| struct ekfAwParameters * | ekf_aw_get_param_handle (void) |
| void | ekf_aw_set_speed_body (struct NedCoor_f *s) |
| void | ekf_aw_set_wind (struct NedCoor_f *s) |
| void | ekf_aw_set_offset (struct NedCoor_f *s) |
| struct ekfHealth | ekf_aw_get_health (void) |
| void | ekf_aw_update_params (void) |
| void | ekf_aw_reset_health (void) |
Variables | |
| struct ekfAwParameters | ekf_aw_params |
| struct ekfAwParameters |
| struct ekfHealth |
| #define ekf_aw_update_Q_accel | ( | _v | ) |
| #define ekf_aw_update_Q_gyro | ( | _v | ) |
| #define ekf_aw_update_Q_k | ( | _v | ) |
| #define ekf_aw_update_Q_mu | ( | _v | ) |
| #define ekf_aw_update_R_accel_filt_x | ( | _v | ) |
| #define ekf_aw_update_R_accel_filt_y | ( | _v | ) |
| #define ekf_aw_update_R_accel_filt_z | ( | _v | ) |
| #define ekf_aw_update_R_V_gnd | ( | _v | ) |
| #define ekf_aw_update_R_V_pitot | ( | _v | ) |
|
extern |
Definition at line 1392 of file ekf_aw.cpp.
References eawp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1374 of file ekf_aw.cpp.
References eawp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1295 of file ekf_aw.cpp.
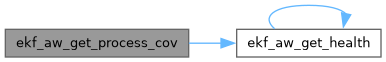
References eawp, and ekf_aw_get_health().
Referenced by ekf_aw_get_health(), ekf_aw_get_process_cov(), and ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1401 of file ekf_aw.cpp.
References eawp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1313 of file ekf_aw.cpp.
References eawp, and ekf_aw_get_innov_accel_filt().
Referenced by ekf_aw_get_innov_accel_filt(), and ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1304 of file ekf_aw.cpp.
References eawp, and ekf_aw_get_innov_V_gnd().
Referenced by ekf_aw_get_innov_V_gnd(), and ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1323 of file ekf_aw.cpp.
References eawp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1329 of file ekf_aw.cpp.
References eawp, and EKF_AW_R_SIZE.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1285 of file ekf_aw.cpp.
References eawp, and ekf_aw_get_offset().
Referenced by ekf_aw_get_offset(), and ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1419 of file ekf_aw.cpp.
References ekf_aw_params.
Referenced by ekf_aw_wrapper_init().
|
extern |
|
extern |
Definition at line 1410 of file ekf_aw.cpp.
References eawp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1265 of file ekf_aw.cpp.
References eawp, ekf_aw_get_speed_body(), and s.
Referenced by ekf_aw_get_speed_body(), and ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1344 of file ekf_aw.cpp.
References eawp, and EKF_AW_COV_SIZE.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1275 of file ekf_aw.cpp.
References eawp, and ekf_aw_get_wind_ned().
Referenced by ekf_aw_get_wind_ned(), and ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1383 of file ekf_aw.cpp.
References eawp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
< accel process noise
< gyro process noise
< wind process noise
< offset process noise
< speed measurement noise
< filtered accel measurement noise
< airspeed measurement noise
Definition at line 457 of file ekf_aw.cpp.
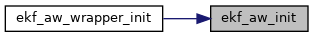
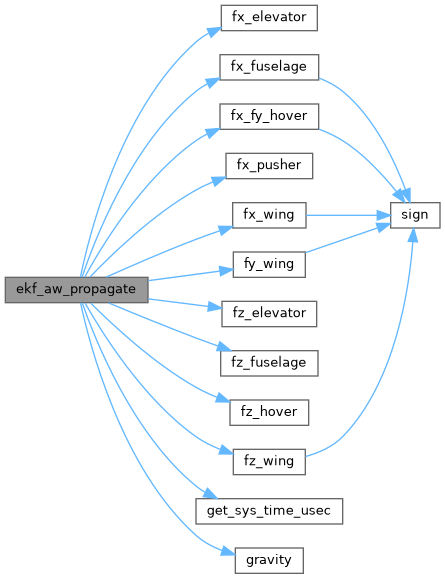
References eawp, EKF_AW_K1_FX_DRAG, EKF_AW_K1_FX_ELEV, EKF_AW_K1_FX_FUSELAGE, EKF_AW_K1_FX_HOVER, EKF_AW_K1_FX_PUSH, EKF_AW_K1_FX_WING, EKF_AW_K1_FY_WING, EKF_AW_K1_FZ_ELEV, EKF_AW_K1_FZ_FUSELAGE, EKF_AW_K1_FZ_HOVER, EKF_AW_K1_FZ_WING, EKF_AW_K2_FX_DRAG, EKF_AW_K2_FX_ELEV, EKF_AW_K2_FX_FUSELAGE, EKF_AW_K2_FX_HOVER, EKF_AW_K2_FX_PUSH, EKF_AW_K2_FX_WING, EKF_AW_K2_FY_WING, EKF_AW_K2_FZ_ELEV, EKF_AW_K2_FZ_FUSELAGE, EKF_AW_K2_FZ_HOVER, EKF_AW_K2_FZ_WING, EKF_AW_K3_FX_ELEV, EKF_AW_K3_FX_FUSELAGE, EKF_AW_K3_FX_HOVER, EKF_AW_K3_FX_PUSH, EKF_AW_K3_FX_WING, EKF_AW_K3_FY_WING, EKF_AW_K3_FZ_FUSELAGE, EKF_AW_K3_FZ_HOVER, EKF_AW_K3_FZ_WING, EKF_AW_K4_FX_FUSELAGE, EKF_AW_K4_FX_WING, EKF_AW_K4_FY_WING, EKF_AW_K4_FZ_FUSELAGE, EKF_AW_K4_FZ_HOVER, EKF_AW_K4_FZ_WING, EKF_AW_K5_FX_WING, EKF_AW_K5_FY_WING, EKF_AW_K5_FZ_HOVER, EKF_AW_K_FY_BETA, EKF_AW_K_FY_V, ekf_aw_params, EKF_AW_PROPAGATE_OFFSET, EKF_AW_Q_ACCEL, EKF_AW_Q_GYRO, EKF_AW_Q_MU, EKF_AW_Q_OFFSET, EKF_AW_R_ACCEL_FILT_X, EKF_AW_R_ACCEL_FILT_Y, EKF_AW_R_ACCEL_FILT_Z, EKF_AW_R_V_GND, EKF_AW_R_V_PITOT, EKF_AW_USE_MODEL_BASED_X, EKF_AW_USE_MODEL_BASED_Y, EKF_AW_USE_MODEL_BASED_Z, EKF_AW_USE_PITOT, EKF_AW_VEHICLE_MASS, and init_ekf_aw_state().
Referenced by ekf_aw_wrapper_init().
|
extern |
Definition at line 591 of file ekf_aw.cpp.
References deg2rad, E, eawp, EKF_AW_AOA_MAX_ANGLE, EKF_AW_AOA_MIN_ANGLE, EKF_AW_AX_SCHED_END_DEG, EKF_AW_AX_SCHED_GAIN, EKF_AW_AX_SCHED_START_DEG, EKF_AW_AZ_QUICK_CONV_ACCEL_GAIN, EKF_AW_AZ_QUICK_CONV_MU_GAIN, EKF_AW_AZ_SCHED_END_DEG, EKF_AW_AZ_SCHED_GAIN, EKF_AW_AZ_SCHED_START_DEG, EKF_AW_COV_SIZE, EKF_AW_DEBUG, EKF_AW_ELEV_MAX_ANGLE, EKF_AW_ELEV_MIN_ANGLE, ekf_aw_params, EKF_AW_Q_mu_x_index, EKF_AW_Q_mu_y_index, EKF_AW_R_a_x_filt_index, EKF_AW_R_a_y_filt_index, EKF_AW_R_a_z_filt_index, EKF_AW_R_SIZE, EKF_AW_SKEW_POLY_0, EKF_AW_SKEW_POLY_1, EKF_AW_SKEW_POLY_2, EKF_AW_WING_INSTALLED, fx_elevator(), fx_fuselage(), fx_fy_hover(), fx_pusher(), fx_wing(), fy_wing(), fz_elevator(), fz_fuselage(), fz_hover(), fz_wing(), get_sys_time_usec(), gravity(), K, FloatRates::p, p, FloatEulers::phi, FloatEulers::psi, FloatRates::q, FloatRates::r, FloatEulers::theta, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 584 of file ekf_aw.cpp.
References init_ekf_aw_state().
|
extern |
Definition at line 1447 of file ekf_aw.cpp.
References eawp.
|
extern |
Definition at line 1440 of file ekf_aw.cpp.
|
extern |
Definition at line 1426 of file ekf_aw.cpp.
Referenced by ekf_aw_wrapper_periodic().
|
extern |
Definition at line 1433 of file ekf_aw.cpp.
|
extern |
Definition at line 552 of file ekf_aw.cpp.
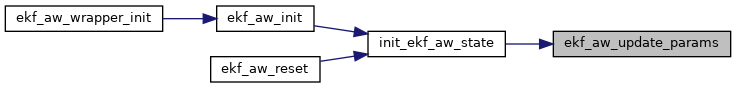
References eawp, ekf_aw_params, EKF_AW_Q_accel_x_index, EKF_AW_Q_accel_y_index, EKF_AW_Q_accel_z_index, EKF_AW_Q_gyro_x_index, EKF_AW_Q_gyro_y_index, EKF_AW_Q_gyro_z_index, EKF_AW_Q_k_x_index, EKF_AW_Q_k_y_index, EKF_AW_Q_k_z_index, EKF_AW_Q_mu_x_index, EKF_AW_Q_mu_y_index, EKF_AW_Q_mu_z_index, EKF_AW_R_a_x_filt_index, EKF_AW_R_a_y_filt_index, EKF_AW_R_a_z_filt_index, EKF_AW_R_V_gnd_x_index, EKF_AW_R_V_gnd_y_index, EKF_AW_R_V_gnd_z_index, and EKF_AW_R_V_pitot_index.
Referenced by init_ekf_aw_state().
|
extern |
Definition at line 377 of file ekf_aw.cpp.
Referenced by ekf_aw_get_param_handle(), ekf_aw_init(), ekf_aw_propagate(), ekf_aw_update_params(), fx_elevator(), fx_fuselage(), fx_fy_hover(), fx_pusher(), fx_wing(), fy_wing(), fz_elevator(), fz_fuselage(), fz_hover(), and fz_wing().
 1.15.0