|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Go to the source code of this file.
Data Structures | |
| struct | Anchor |
| Anchor structure. More... | |
Functions | |
| int | trilateration_init (struct Anchor *anchors) |
| Init internal trilateration structures. | |
| int | trilateration_compute (struct Anchor *anchors, struct EnuCoor_f *pos) |
| Compute trilateration based on the latest measurments. | |
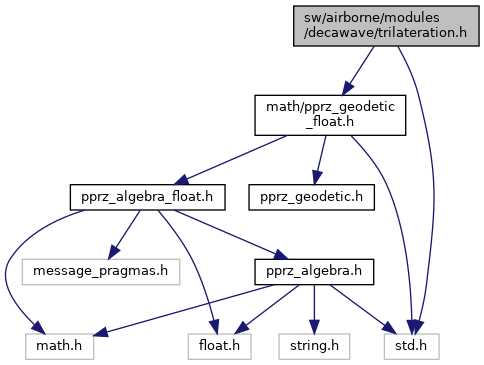
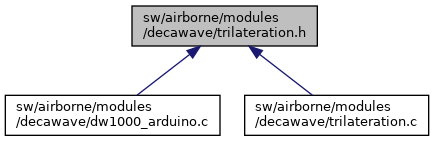
Definition in file trilateration.h.
| struct Anchor |
Anchor structure.
Definition at line 34 of file trilateration.h.
| Data Fields | ||
|---|---|---|
| float | distance | last measured distance |
| uint16_t | id | anchor ID |
| struct EnuCoor_f | pos | position of the anchor |
| float | time | time of the last received data |
| bool | updated | new data available |
Compute trilateration based on the latest measurments.
| [in] | anchors | array of anchors with updated distance measurements |
| [out] | pos | computed position |
Definition at line 87 of file trilateration.c.
References D, d2, Anchor::distance, Ex, Ey, Ez, init_failed, J, P, EnuCoor_f::x, EnuCoor_f::y, and EnuCoor_f::z.
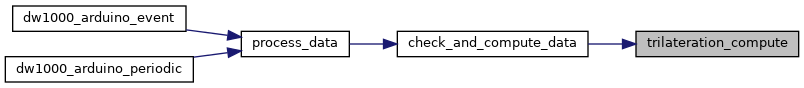
Referenced by check_and_compute_data().
|
extern |
Init internal trilateration structures.
| [in] | anchors | array of anchors with their location |
Definition at line 39 of file trilateration.c.
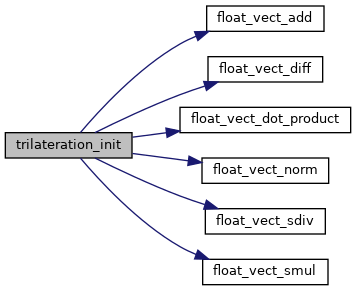
References D, Ex, Ey, Ez, float_vect_add(), float_vect_diff(), float_vect_dot_product(), float_vect_norm(), float_vect_sdiv(), float_vect_smul(), init_failed, J, P, Anchor::pos, EnuCoor_f::x, EnuCoor_f::y, and EnuCoor_f::z.
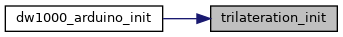
Referenced by uwb_positioning_init().
 1.15.0