|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Log data required to compute control effectiveness. More...
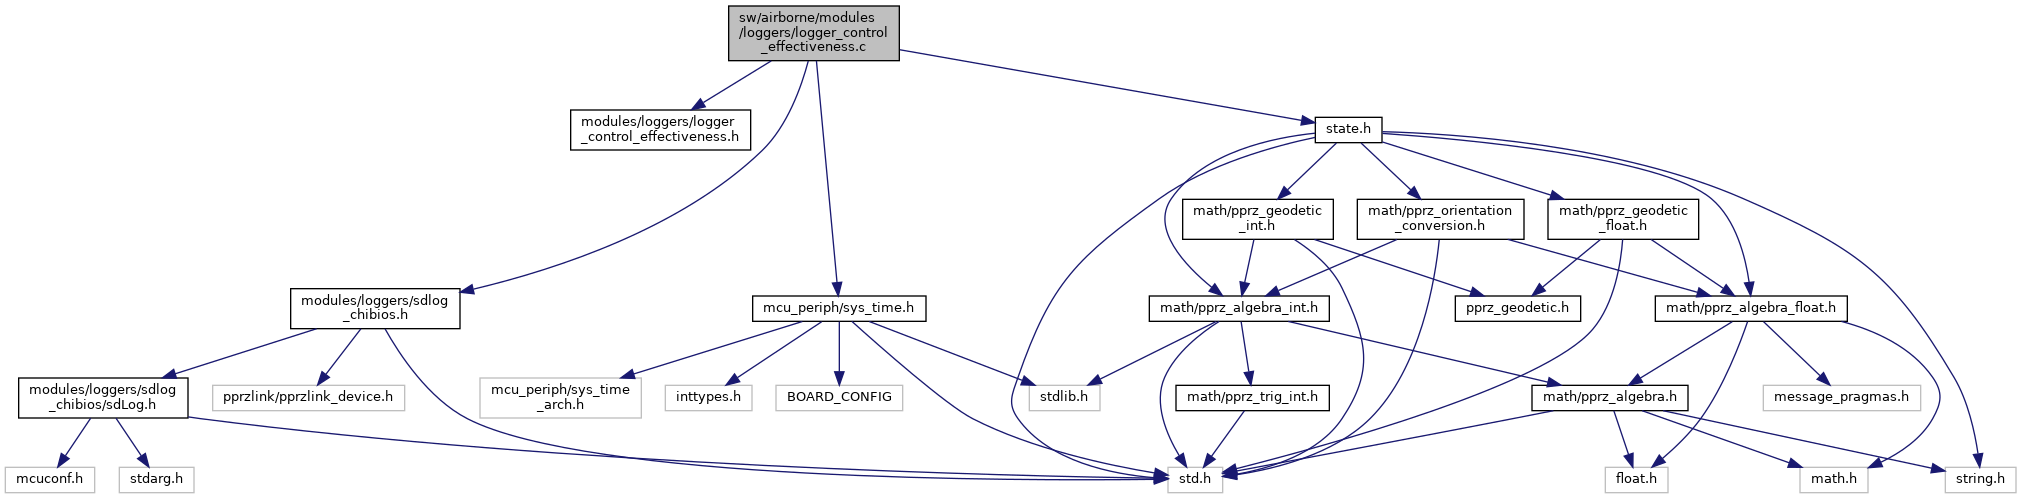
#include "modules/loggers/logger_control_effectiveness.h"#include "modules/loggers/logger_utils.h"#include "mcu_periph/sys_time.h"#include "state.h"Go to the source code of this file.
Macros | |
| #define | LogFormatHeader "%.5f,%d,%d,%d,%d,%d,%d" |
| #define | LogFormatVect3 ",%d,%d,%d" |
| #define | LogFormatI32 ",%d" |
| #define | LOGGER_CONTROL_EFFECTIVENESS_FILE_PATH /data/ftp/internal_000/control_eff |
| #define | LOGGER_CONTROL_EFFECTIVENESS_COMMANDS TRUE |
| #define | LOGGER_CONTROL_EFFECTIVENESS_ACTUATORS FALSE |
| #define | LOGGER_CONTROL_EFFECTIVENESS_POS FALSE |
| #define | LOGGER_CONTROL_EFFECTIVENESS_SPEED FALSE |
| #define | LOGGER_CONTROL_EFFECTIVENESS_AIRSPEED FALSE |
| #define | LOGGER_CONTROL_EFFECTIVENESS_RPM FALSE |
Functions | |
| void | logger_control_effectiveness_init (void) |
| Init module. | |
| void | logger_control_effectiveness_start (void) |
| Write the log header line according to the enabled parts. | |
| void | logger_control_effectiveness_stop (void) |
| void | logger_control_effectiveness_periodic (void) |
| Log the values to file. | |
Variables | |
| static FILE * | pprzLogFile = NULL |
Log data required to compute control effectiveness.
Definition in file logger_control_effectiveness.c.
| #define LogFormatHeader "%.5f,%d,%d,%d,%d,%d,%d" |
Definition at line 37 of file logger_control_effectiveness.c.
Referenced by logger_control_effectiveness_periodic().
| #define LogFormatI32 ",%d" |
Definition at line 39 of file logger_control_effectiveness.c.
Referenced by logger_control_effectiveness_periodic().
| #define LogFormatVect3 ",%d,%d,%d" |
Definition at line 38 of file logger_control_effectiveness.c.
Referenced by logger_control_effectiveness_periodic().
| #define LOGGER_CONTROL_EFFECTIVENESS_ACTUATORS FALSE |
Definition at line 56 of file logger_control_effectiveness.c.
| #define LOGGER_CONTROL_EFFECTIVENESS_AIRSPEED FALSE |
Definition at line 68 of file logger_control_effectiveness.c.
| #define LOGGER_CONTROL_EFFECTIVENESS_COMMANDS TRUE |
Definition at line 52 of file logger_control_effectiveness.c.
| #define LOGGER_CONTROL_EFFECTIVENESS_FILE_PATH /data/ftp/internal_000/control_eff |
Definition at line 44 of file logger_control_effectiveness.c.
Referenced by logger_control_effectiveness_start().
| #define LOGGER_CONTROL_EFFECTIVENESS_POS FALSE |
Definition at line 60 of file logger_control_effectiveness.c.
| #define LOGGER_CONTROL_EFFECTIVENESS_RPM FALSE |
Definition at line 72 of file logger_control_effectiveness.c.
| #define LOGGER_CONTROL_EFFECTIVENESS_SPEED FALSE |
Definition at line 64 of file logger_control_effectiveness.c.
| void logger_control_effectiveness_init | ( | void | ) |
Init module.
Definition at line 102 of file logger_control_effectiveness.c.
References ABI_BROADCAST.
| void logger_control_effectiveness_periodic | ( | void | ) |
Log the values to file.
Definition at line 152 of file logger_control_effectiveness.c.
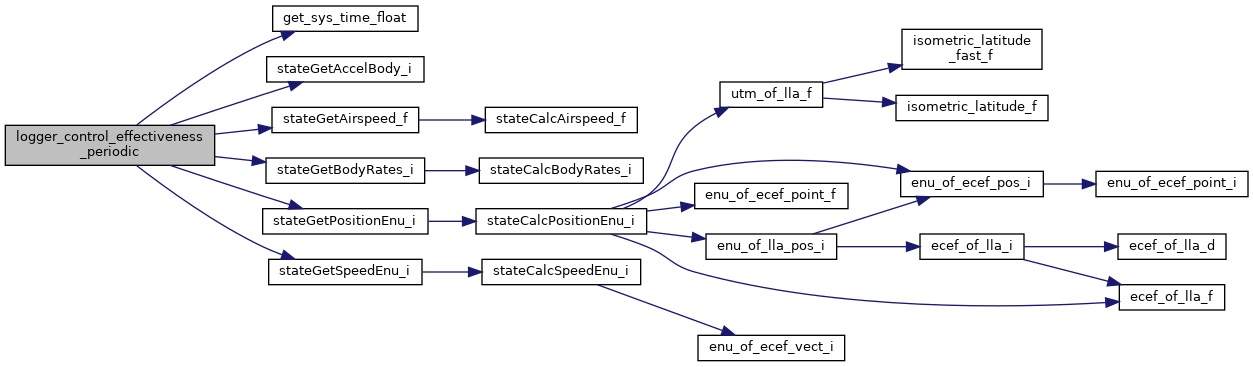
References commands, get_sys_time_float(), LogFileIsOpen, LogFormatHeader, LogFormatI32, LogFormatVect3, LogWrite, Int32Rates::p, pprzLogFile, Int32Rates::q, Int32Rates::r, stateGetAccelBody_i(), stateGetAirspeed_f(), stateGetBodyRates_i(), stateGetPositionEnu_i(), stateGetSpeedEnu_i(), EnuCoor_i::x, Int32Vect3::x, EnuCoor_i::y, Int32Vect3::y, EnuCoor_i::z, and Int32Vect3::z.
| void logger_control_effectiveness_start | ( | void | ) |
Write the log header line according to the enabled parts.
Definition at line 110 of file logger_control_effectiveness.c.
References LogFileIsOpen, LOGGER_CONTROL_EFFECTIVENESS_FILE_PATH, LogOpen, LogWrite, and pprzLogFile.
| void logger_control_effectiveness_stop | ( | void | ) |
Definition at line 144 of file logger_control_effectiveness.c.
References LogClose, LogFileIsOpen, and pprzLogFile.
|
static |
Definition at line 40 of file logger_control_effectiveness.c.
Referenced by airspeed_cb(), airspeed_ets_read_event(), aoa_pwm_update(), baro_apogee_event(), gps_cb(), gps_ubx_parse(), gyro_cb(), humid_sht_periodic(), incidence_cb(), ins_float_invariant_propagate(), ins_mekf_wind_wrapper_init(), logger_control_effectiveness_periodic(), logger_control_effectiveness_start(), logger_control_effectiveness_stop(), logger_log_msg_up(), mag_cb(), mf_daq_send_report(), mf_ptu_periodic(), parse_acinfo_dl(), pressure_diff_cb(), process_data(), sdlog_chibios_finish(), sdlog_chibios_init(), send_acinfo_lla(), temod_event(), thd_startlog(), traffic_info_log_start(), traffic_info_log_stop(), uwb_positioning_periodic(), wind_estimator_init(), and wind_estimator_step().
 1.15.0