|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Public Member Functions | |
| __init__ (self, dt=0.02, GUI=True, debug=False, urdf="robobee.urdf") | |
| apply_force_and_moments (self, rpm) | |
| step (self, commands) | |
| step_debug (self, commands) | |
| get_observation (self) | |
| reset (self) | |
Data Fields | |
| dt = dt | |
| physicsClient = p.connect(p.GUI) | |
| planeId = p.loadURDF("plane.urdf") | |
| textureId = p.loadTexture("checker_grid.jpg") | |
| list | vehicle_start_pos = [0, 0, 0.2] |
| vehicle_start_orientation = p.getQuaternionFromEuler([0, 0, 0]) | |
| vehicle = p.loadURDF(vehicule_urdf, self.vehicle_start_pos, self.vehicle_start_orientation) | |
| float | KF = 0.001 |
| vel = np.zeros(3) | |
| tuple | accel = np.zeros(3) |
| ang_vel = np.zeros(3) | |
| tuple | ang_accel = np.zeros(3) |
| dict | observation = {} |
| roll_Id = p.addUserDebugParameter("roll_cmd", -0.01, 0.01, 0) | |
| pitch_Id = p.addUserDebugParameter("pitch_cmd", -0.01, 0.01, 0) | |
| yaw_Id = p.addUserDebugParameter("yaw_cmd", -0.01, 0.01, 0) | |
Definition at line 12 of file simple_quad_sim.py.
| simple_quad_sim.BulletFDM.__init__ | ( | self, | |
| dt = 0.02, | |||
| GUI = True, | |||
| debug = False, | |||
| urdf = "robobee.urdf" ) |
Definition at line 13 of file simple_quad_sim.py.
| simple_quad_sim.BulletFDM.apply_force_and_moments | ( | self, | |
| rpm ) |
rpm = [ quadrotor prop rpms ]
Definition at line 68 of file simple_quad_sim.py.
References KF, physicsClient, and vehicle.
Referenced by step().
| simple_quad_sim.BulletFDM.get_observation | ( | self | ) |
Definition at line 139 of file simple_quad_sim.py.
References AhrsMadgwick.accel, AttRefEulerFloat.accel, AttRefEulerInt.accel, AttRefQuatFloat.accel, AttRefQuatInt.accel, ekfAwInputs.accel, ExtU.accel, FIFODataHighRes.accel, GuidanceHRef.accel, HorizontalGuidanceReference.accel, HorizontalGuidanceSetpoint.accel, ImuHitl.accel, ImuNps.accel, inv_command.accel, inv_measures.accel, MekfWindInputs.accel, MekfWindState.accel, NpsSensors.accel, QuatSecondOrderLowPass.accel, RotorcraftNavigation.accel, accel, VNData.accel, Xsens.accel, ang_accel, ang_vel, air_data_sensor_t.dt, discrete_ekf.dt, discrete_ekf_no_north.dt, DshotPackets.dt, EKFRange.dt, GuidanceHRef.dt, QuatSecondOrderLowPass.dt, dt, SimpleKinematicKalman.dt, ukf_params_tag.dt, observation, vehicle, dragspeed_t.vel, LinState.vel, OneloopGuidanceRef.vel, OneloopGuidanceState.vel, OpticalFlowLanding.vel, vel, and Xsens.vel.
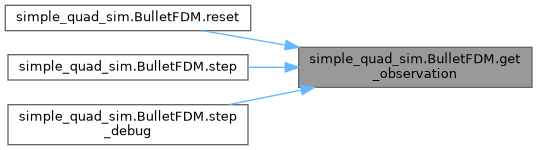
Referenced by reset(), step(), and step_debug().
| simple_quad_sim.BulletFDM.reset | ( | self | ) |
Definition at line 163 of file simple_quad_sim.py.
References get_observation(), vehicle, vehicle_start_orientation, and vehicle_start_pos.
| simple_quad_sim.BulletFDM.step | ( | self, | |
| commands ) |
Definition at line 98 of file simple_quad_sim.py.
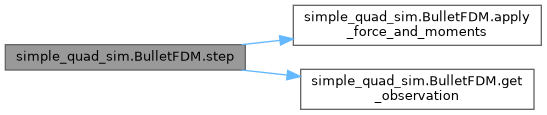
References apply_force_and_moments(), get_observation(), and physicsClient.
| simple_quad_sim.BulletFDM.step_debug | ( | self, | |
| commands ) |
Definition at line 115 of file simple_quad_sim.py.
References get_observation(), physicsClient, pitch_Id, roll_Id, vehicle, and yaw_Id.
| tuple simple_quad_sim.BulletFDM.accel = np.zeros(3) |
Definition at line 53 of file simple_quad_sim.py.
Referenced by get_observation().
| tuple simple_quad_sim.BulletFDM.ang_accel = np.zeros(3) |
Definition at line 56 of file simple_quad_sim.py.
Referenced by get_observation().
| simple_quad_sim.BulletFDM.ang_vel = np.zeros(3) |
Definition at line 55 of file simple_quad_sim.py.
Referenced by get_observation().
| simple_quad_sim.BulletFDM.dt = dt |
Definition at line 22 of file simple_quad_sim.py.
Referenced by get_observation().
| float simple_quad_sim.BulletFDM.KF = 0.001 |
Definition at line 50 of file simple_quad_sim.py.
Referenced by apply_force_and_moments().
| dict simple_quad_sim.BulletFDM.observation = {} |
Definition at line 59 of file simple_quad_sim.py.
Referenced by get_observation().
| simple_quad_sim.BulletFDM.physicsClient = p.connect(p.GUI) |
Definition at line 24 of file simple_quad_sim.py.
Referenced by apply_force_and_moments(), step(), and step_debug().
| simple_quad_sim.BulletFDM.pitch_Id = p.addUserDebugParameter("pitch_cmd", -0.01, 0.01, 0) |
Definition at line 65 of file simple_quad_sim.py.
Referenced by step_debug().
| simple_quad_sim.BulletFDM.planeId = p.loadURDF("plane.urdf") |
Definition at line 32 of file simple_quad_sim.py.
| simple_quad_sim.BulletFDM.roll_Id = p.addUserDebugParameter("roll_cmd", -0.01, 0.01, 0) |
Definition at line 64 of file simple_quad_sim.py.
Referenced by step_debug().
| simple_quad_sim.BulletFDM.textureId = p.loadTexture("checker_grid.jpg") |
Definition at line 33 of file simple_quad_sim.py.
| simple_quad_sim.BulletFDM.vehicle = p.loadURDF(vehicule_urdf, self.vehicle_start_pos, self.vehicle_start_orientation) |
Definition at line 39 of file simple_quad_sim.py.
Referenced by apply_force_and_moments(), get_observation(), reset(), and step_debug().
| simple_quad_sim.BulletFDM.vehicle_start_orientation = p.getQuaternionFromEuler([0, 0, 0]) |
Definition at line 36 of file simple_quad_sim.py.
Referenced by reset().
| simple_quad_sim.BulletFDM.vehicle_start_pos = [0, 0, 0.2] |
Definition at line 35 of file simple_quad_sim.py.
Referenced by reset().
| simple_quad_sim.BulletFDM.vel = np.zeros(3) |
Definition at line 52 of file simple_quad_sim.py.
Referenced by get_observation().
| simple_quad_sim.BulletFDM.yaw_Id = p.addUserDebugParameter("yaw_cmd", -0.01, 0.01, 0) |
Definition at line 66 of file simple_quad_sim.py.
Referenced by step_debug().
 1.15.0