|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
A dummy guidance mode to run the oneloop_nB controller. More...
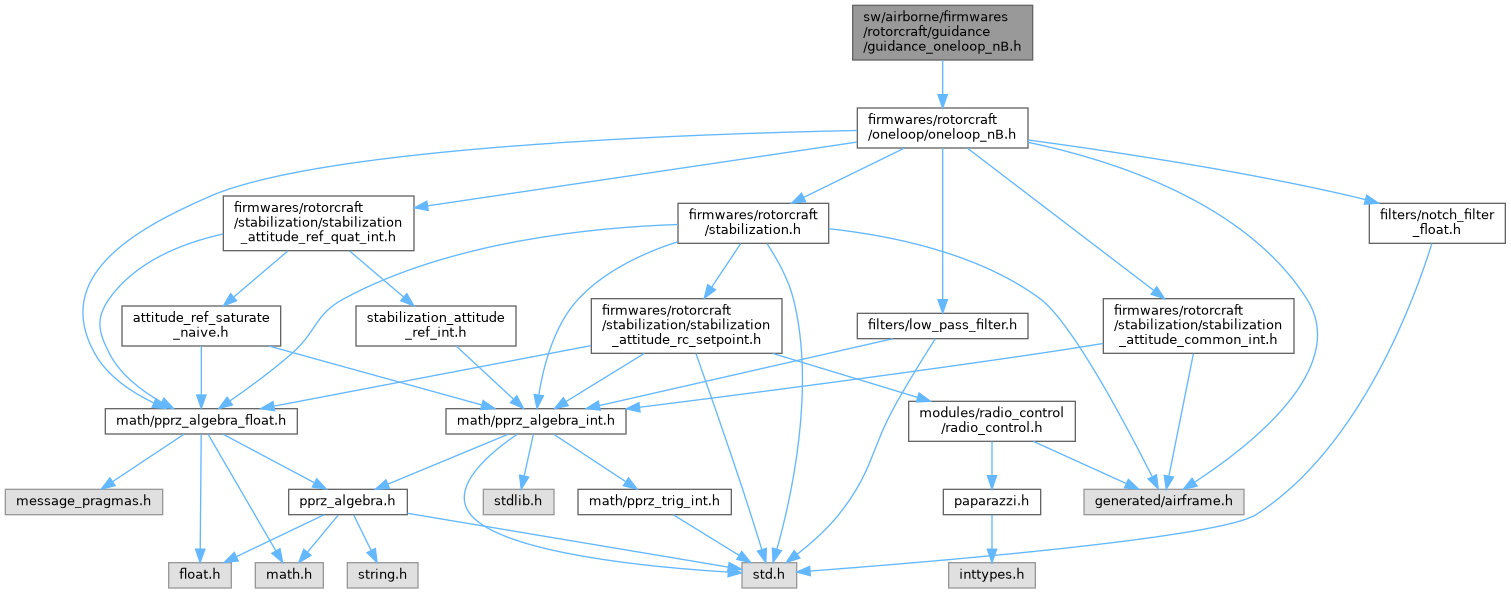
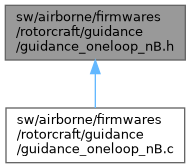
#include "firmwares/rotorcraft/oneloop/oneloop_nB.h" Include dependency graph for guidance_oneloop_nB.h: This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Functions | |
| struct StabilizationSetpoint | guidance_oneloop_nB_run_mode (bool in_flight, struct HorizontalGuidance *gh, struct VerticalGuidance *gv, enum GuidanceOneloop_HMode h_mode, enum GuidanceOneloop_VMode v_mode) |
A dummy guidance mode to run the oneloop_nB controller.
Definition in file guidance_oneloop_nB.h.
| Enumerator | |
|---|---|
| GUIDANCE_ONELOOP_NB_H_POS | |
| GUIDANCE_ONELOOP_NB_H_SPEED | |
| GUIDANCE_ONELOOP_NB_H_ACCEL | |
Definition at line 33 of file guidance_oneloop_nB.h.
| Enumerator | |
|---|---|
| GUIDANCE_ONELOOP_NB_V_POS | |
| GUIDANCE_ONELOOP_NB_V_SPEED | |
| GUIDANCE_ONELOOP_NB_V_ACCEL | |
Definition at line 39 of file guidance_oneloop_nB.h.
|
extern |
Definition at line 84 of file guidance_oneloop_nB.c.
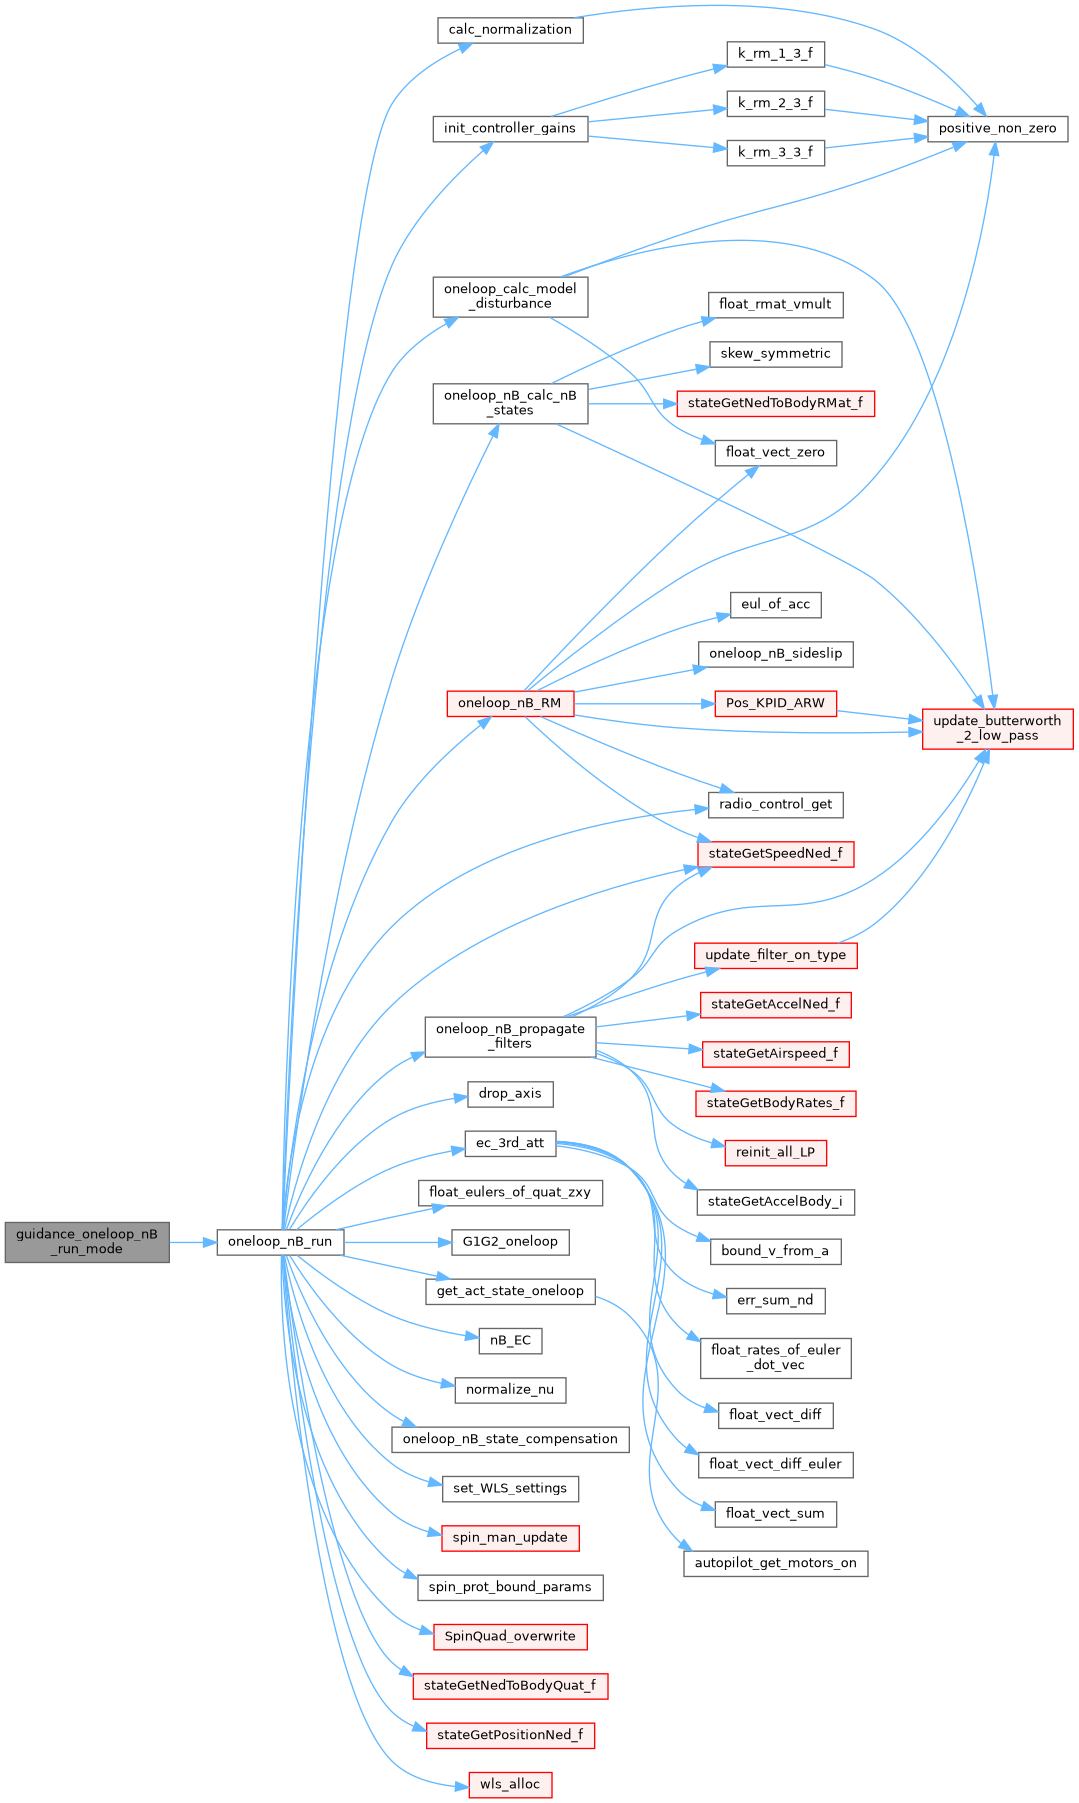
References ACCEL_FLOAT_OF_BFP, foo, GUIDANCE_ONELOOP_NB_H_POS, GUIDANCE_ONELOOP_NB_H_SPEED, GUIDANCE_ONELOOP_NB_V_POS, GUIDANCE_ONELOOP_NB_V_SPEED, OneloopGeneral::half_loop, oneloop_nB, oneloop_nB_run(), POS_FLOAT_OF_BFP, StabilizationSetpoint::sp, SPEED_FLOAT_OF_BFP, and FloatVect3::x.
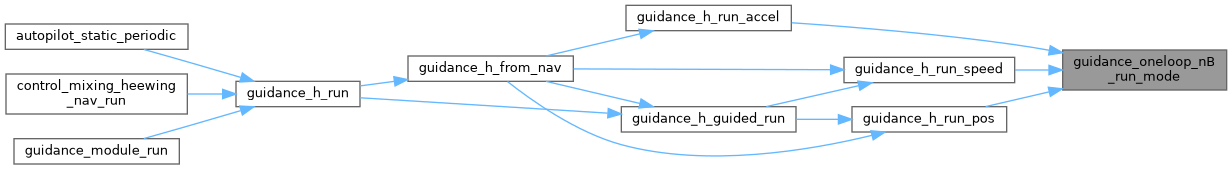
Referenced by guidance_h_run_accel(), guidance_h_run_pos(), and guidance_h_run_speed().
Here is the call graph for this function: Here is the caller graph for this function: 1.9.8