PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Release

5 January 2015 · Felix Ruess

Paparazzi V5.4 Release
Penguin_logoThe Paparazzi Development Team is pleased to announce the release of a brand new version of Paparazzi; v5.4, giving you the option to enjoy lots of new features and improvements, happy new year!

If you’re curious to know what has been added and improved you can, go here for an overview. For your enjoyment and to view what all those changes look like, click here.

If you are already using paparazzi with Git, to enjoy all improvements you can switch to this new version via:
Read article →

28 August 2014 · Felix Ruess

Paparazzi V5.2 Release

Penguin_logoPaparazzi Development Team is pleased to announce the release of the Paparazzi v5.2 stable version with lots of new features and bugfixes.

See the CHANGELOG for an overview of new features and bugfixes. See the Release Upgrades page for hints on configuration changes that may be required if you are moving to v5.2 from v5.0.

If you are already using paparazzi with Git, you can switch to this new branch with

git remote update && git checkout v5.2.

Read article →

21 February 2011 · Piotr Esden-Tempski

Aspirin IMU Release

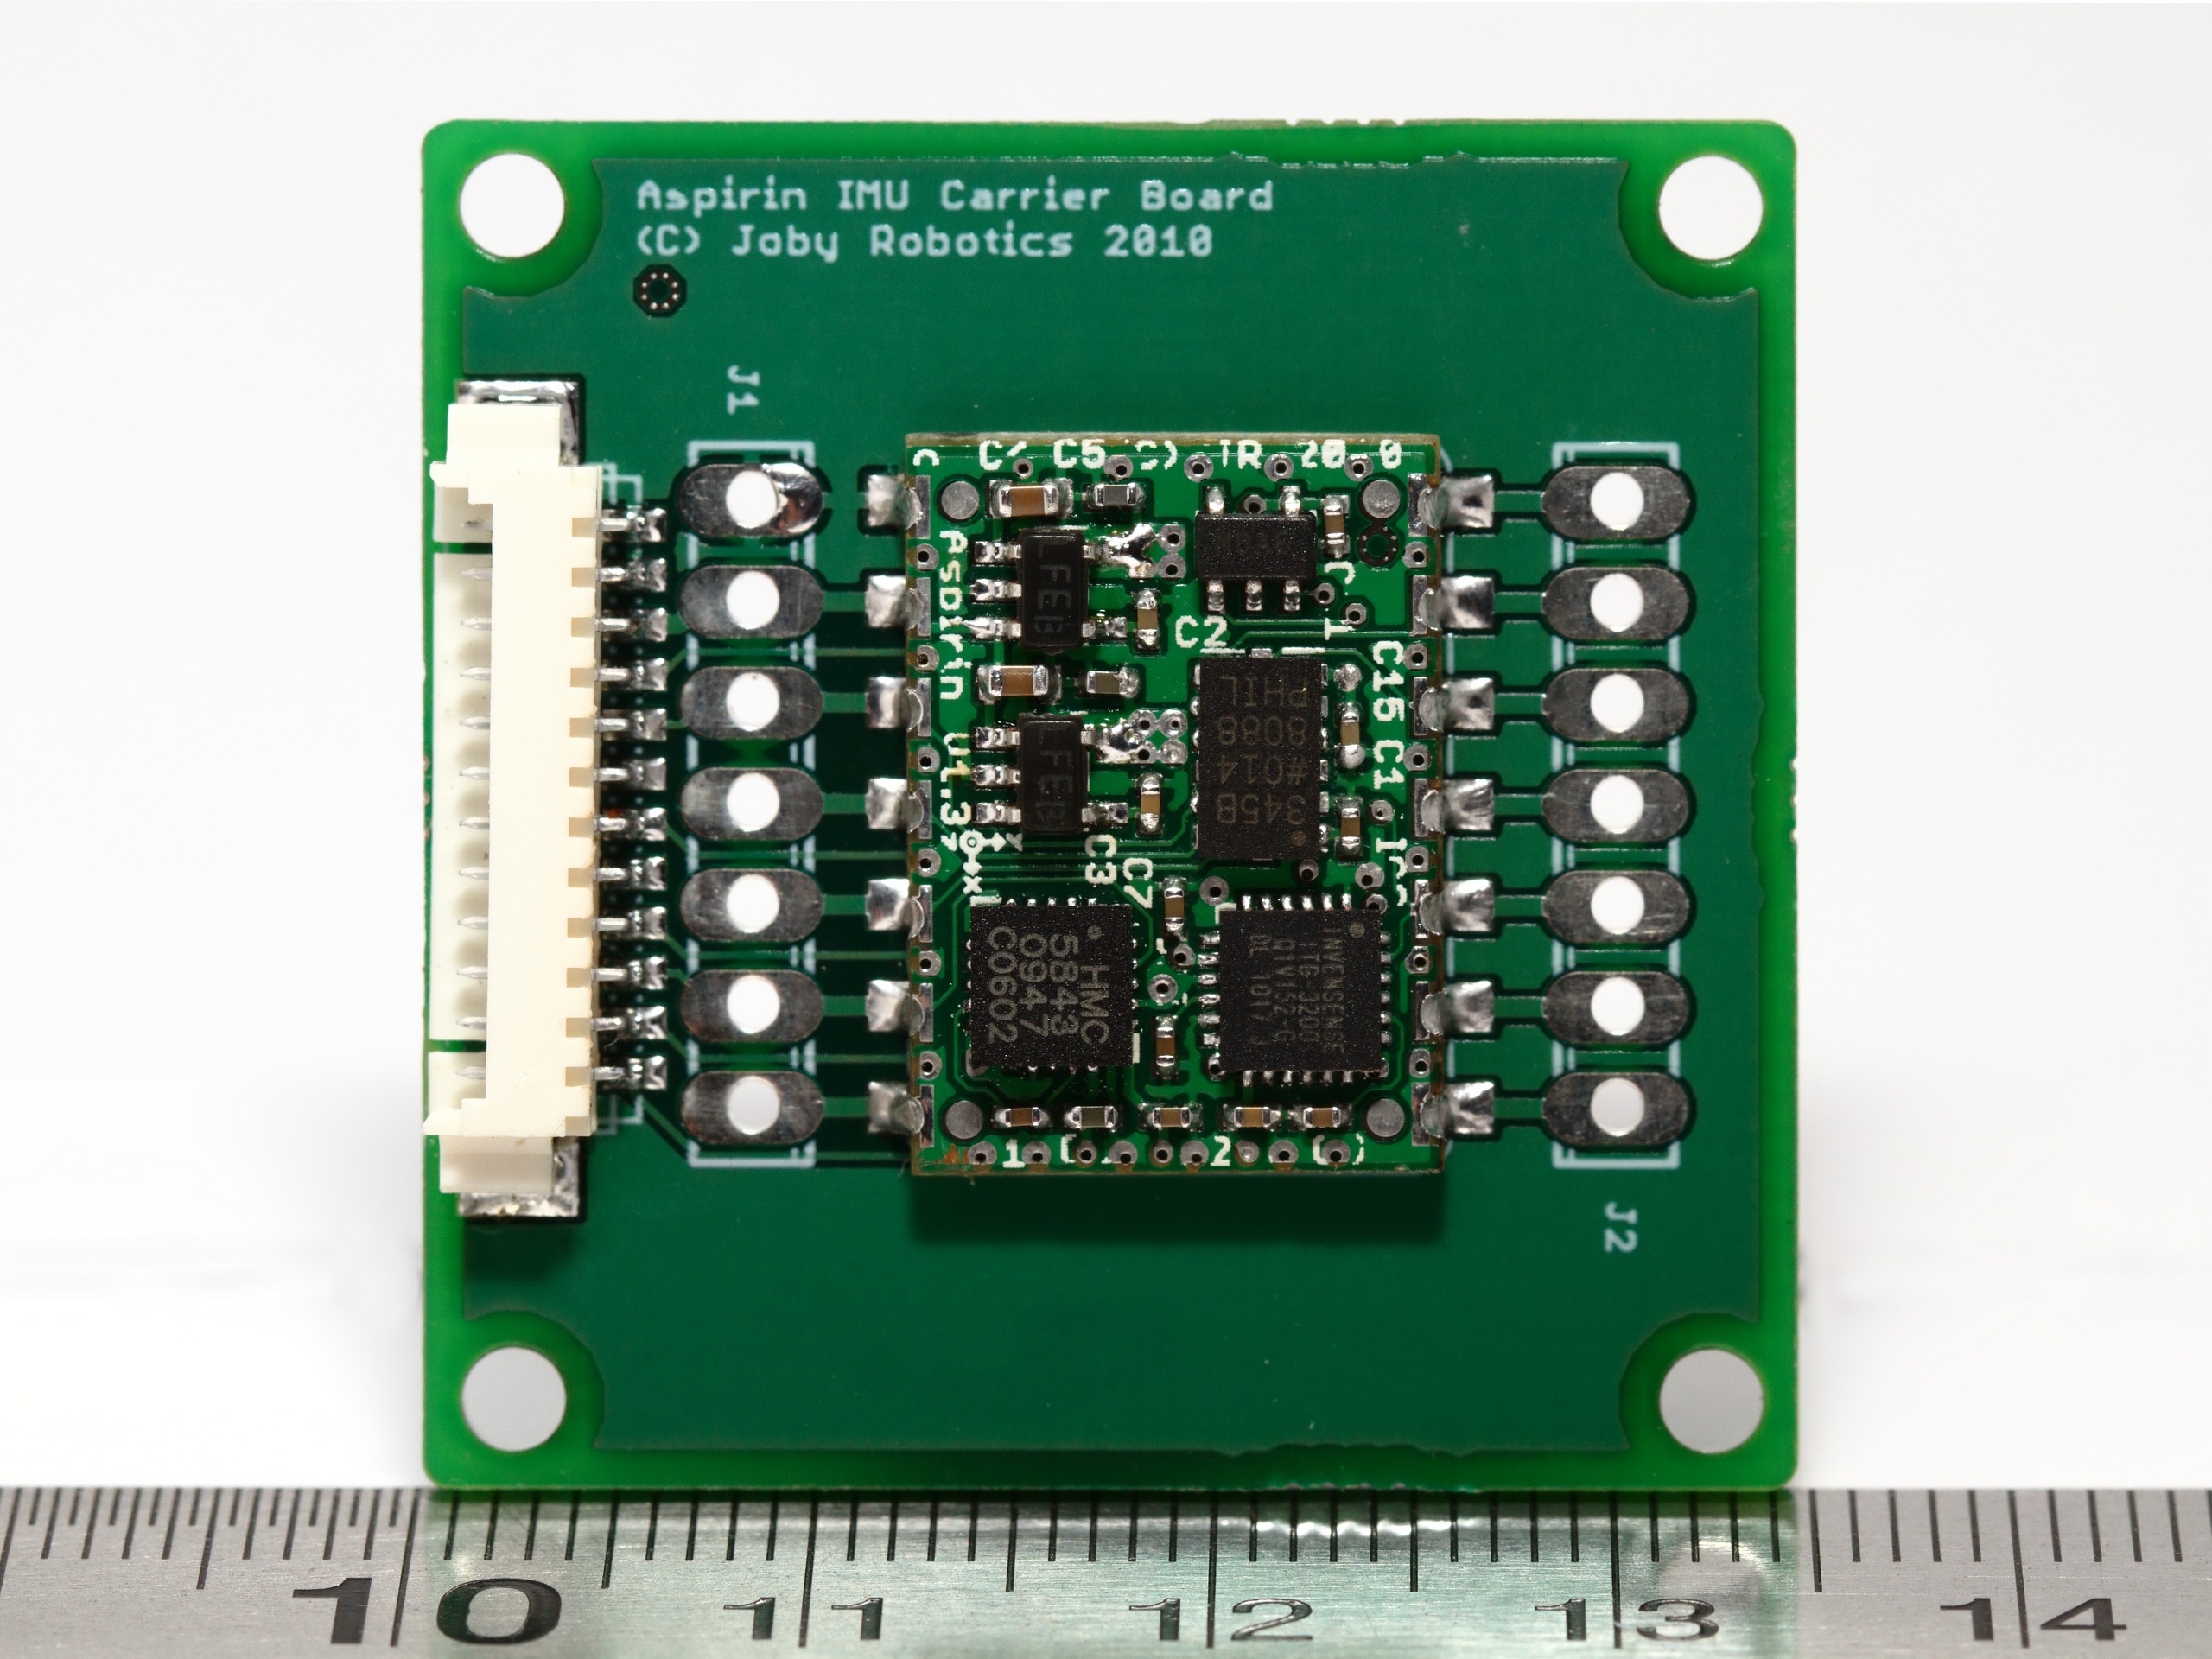
Aspirin IMU on Booz Compatible Carrier BoardToday we are pleased to announce the public release of our next generation IMU, Aspirin! After a lengthy research, development, and testing period we are now happy with the hardware and the software drivers for this unique IMU. It is incredibly small and light, three digital sensors packed onto a single 19x14mm PCB. The footprint allows you to integrate it into your own designs too. We are also making it available via a carrier board for drop in use on Lisa/L.

Read article →