PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Fixed Wing

4 December 2015 · Gautier Hattenberger

Multi-UAV flights for simultaneous meteorological measurements

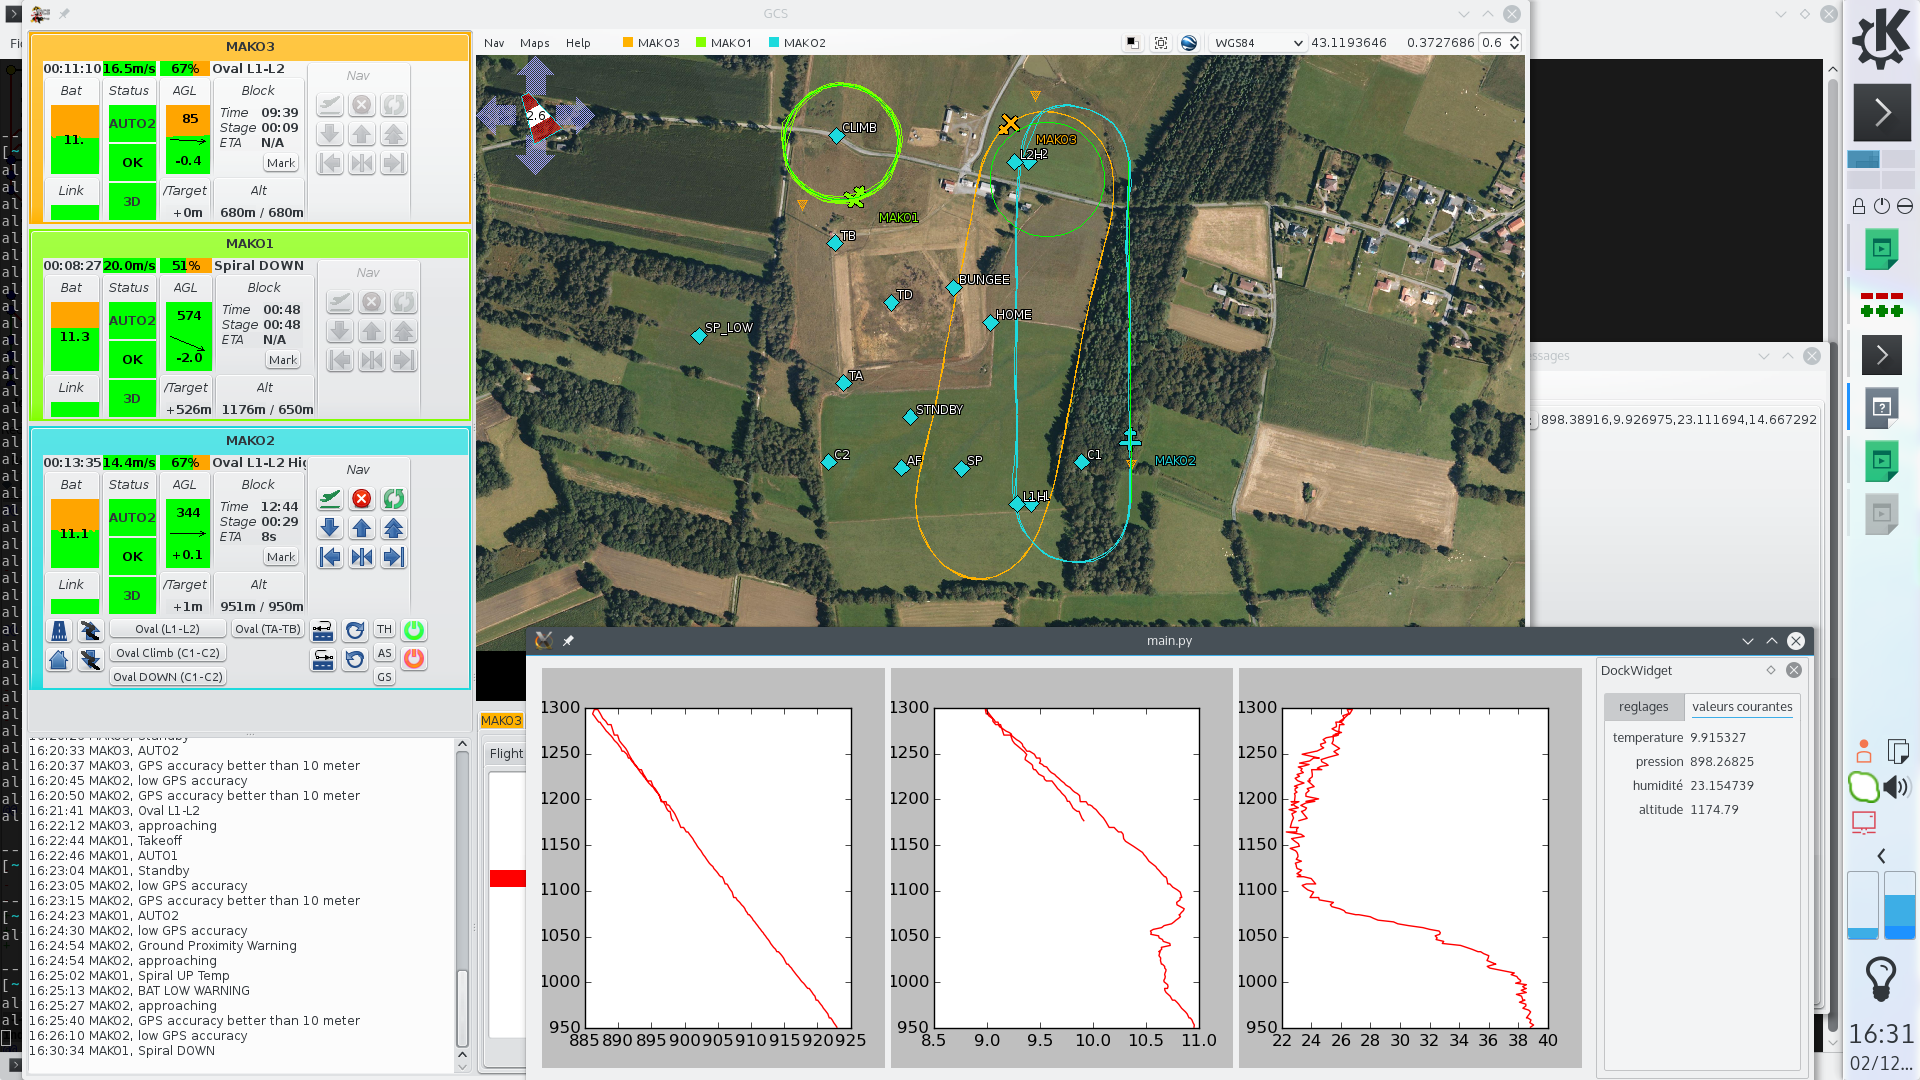
ENAC UAV Lab team and Meteo-France (CNRS-GAME and ENM) teams have spent several days at the Atmospheric Research Center of Lannemezan (in the south of France) in order to perform experiments for simultaneous meteorological measurements through multi-UAV flight.

This was part of a research project called VOLTIGE aimed at studying the formation of cloud and fog events. One of the planes is measuring the turbulence near the ground, a second plane is flying above the cloud or the fog with a radiation sensor and the last one is making a vertical profile of temperature, pressure and humidity up to 1500 meters AGL.GCS screenshot multi-uav
Read article →

22 June 2011 · Piotr Esden-Tempski

Lisa/M for developers

Hello everyone,

After many months of hard work we have finally reached a version of Lisa/M that is ready for a wider range of developers. Although there are still some things missing that would allow a beginning user to use it with ease, we decided it is better to provide it to all of the other brilliant non core developers and users. You can find out more about it in the Paparazzi Wiki. A big thanks go to OpenUAS for his great help with the documentation.

Read article →

14 December 2010 · Piotr Esden-Tempski

Lisa/M next generation entry level Paparazzi Autopilot

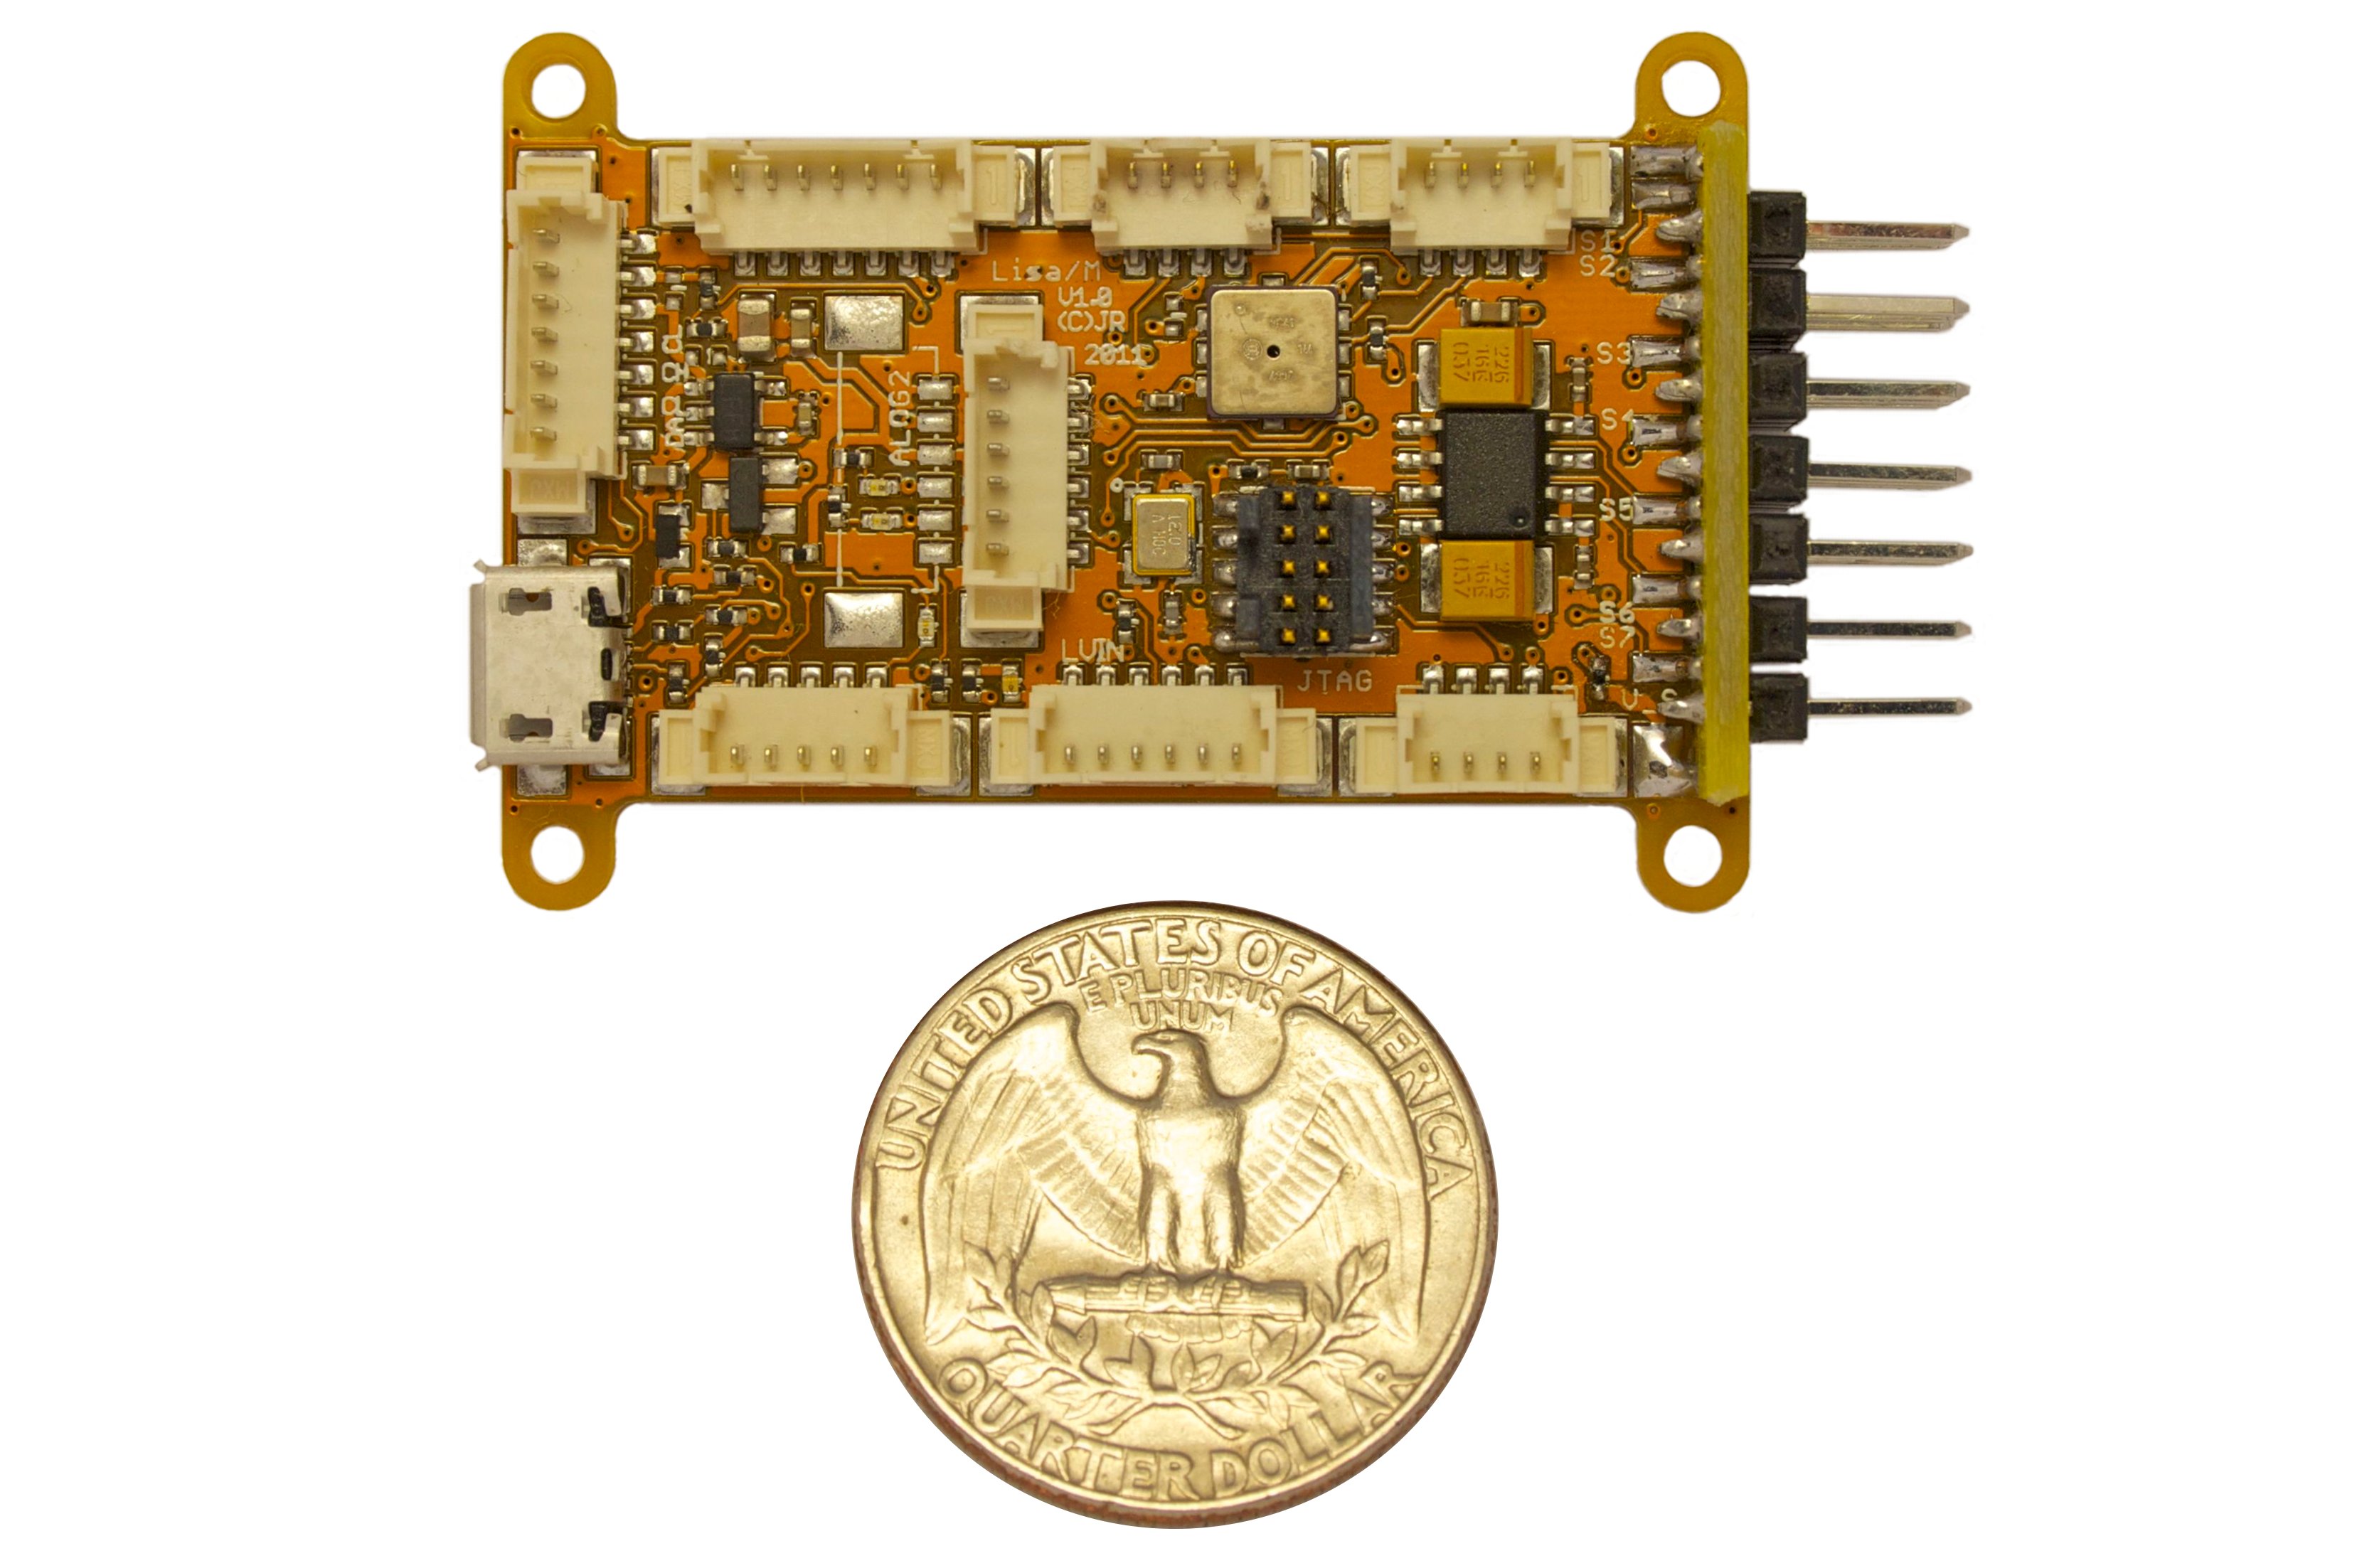
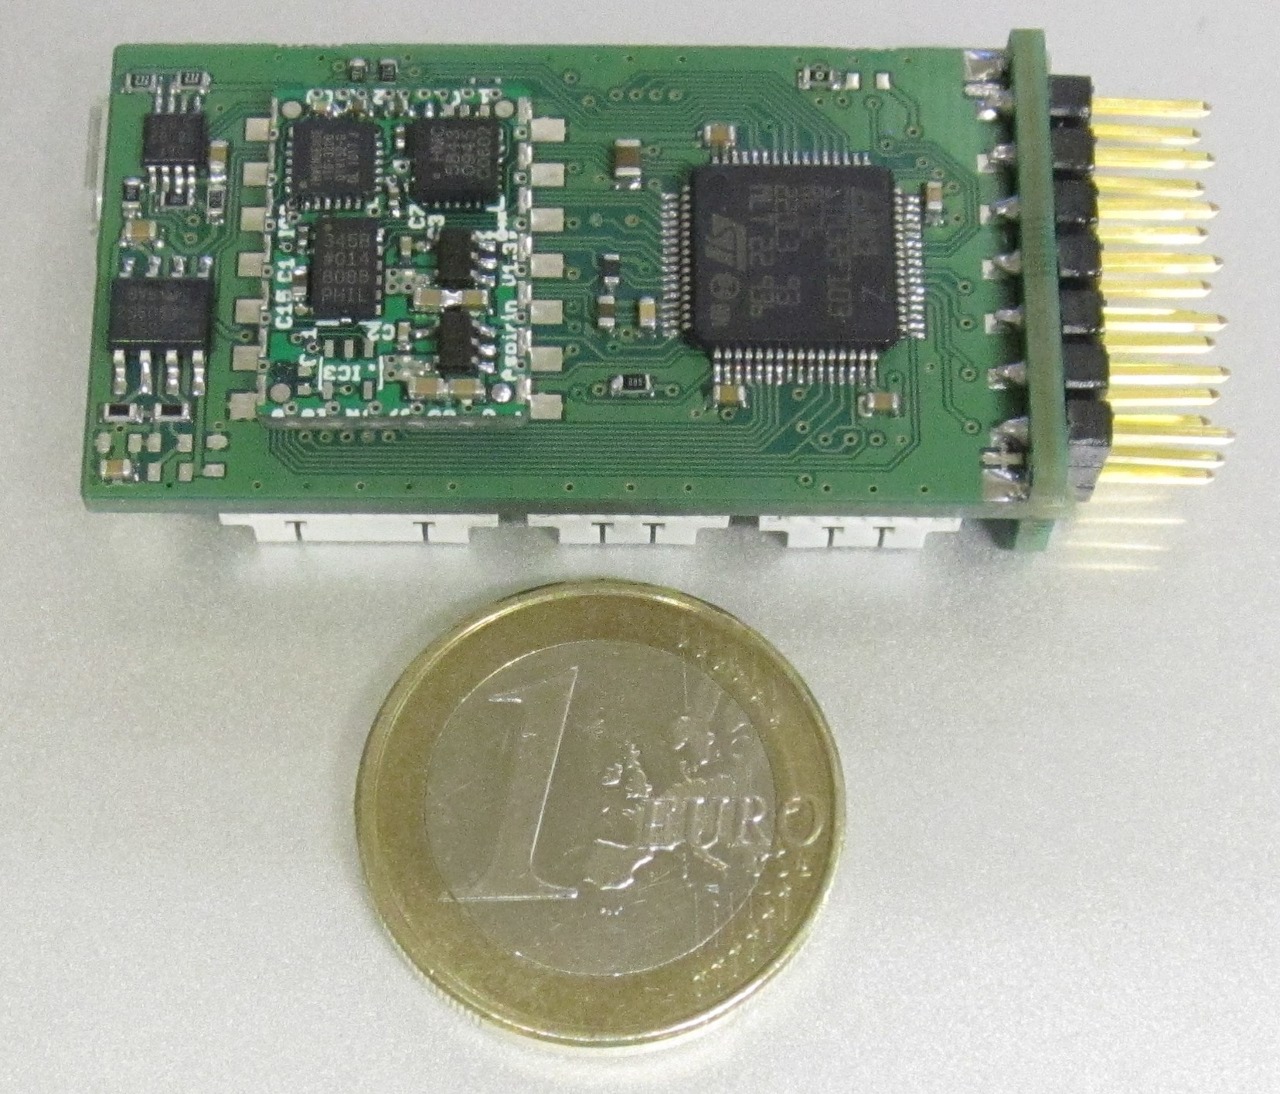
Lisa/M Bottom Lisa/M Bottom

As promised, we want to talk about projects we are currently working on. One of them is Lisa/M.

Lisa/M will be the medium sized Autopilot based on the STM32 Cortex-M3 microcontroller. It is part of the Lisa series of Autopilots. It is very small (50mm x 25mm), about the size of an RC receiver. We want it to be as affordable as possible so that more people can join the autonomous aircraft revolution. The final cost still needs to be determined, as we are not done with the development yet.

Read article →

9 December 2010 · Felix Ruess

Adaptive Control in Paparazzi

Paparazzi features adaptive control loops that can cope with substantial “changes” of the airframe in flight. May it be a motor dropout, partial loss of control surfaces or dropping a heavy payload. As videos usually say more than words, here are two that demonstrate this.

The first video shows Paparazzi’s adaptive control loops (written by Pascal Brisset and Gautier Hattenberger at ENAC) for fixedwing aircraft keeping a Multiplex Twinstar on track, despite dropping a portion of the right wing and aileron and then switching the right motor off.

Read article →

6 December 2010 · Eric Parsonage

Lisa STM32 Paparazzi Autopilot Overview Part 1.

Many Paparazzi followers will be familiar with the popular TINY and TWOG fixed wing autopilot boards that have allowed so many UAV pilots their first taste of autonomous flight. A few will even have had the pleasure of using the Booz multicopter autopilot board. All three of these designs are based on the Phillips LPC2148 microcontroller, which has proven to be a solid performer in this role. Antoine Drouin, the genius behind the Booz board, has once again outdone himself with a completely new series of autopilot boards based on the STM32 ARM Cortex-M3 microcontroller, which has the umbrella name Lisa. The first available is the Lisa/L and it is this board that will be explored in coming articles.

Read article →