PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Posts

17 June 2013 · Felix Ruess

Paparazzi V5.0 Release
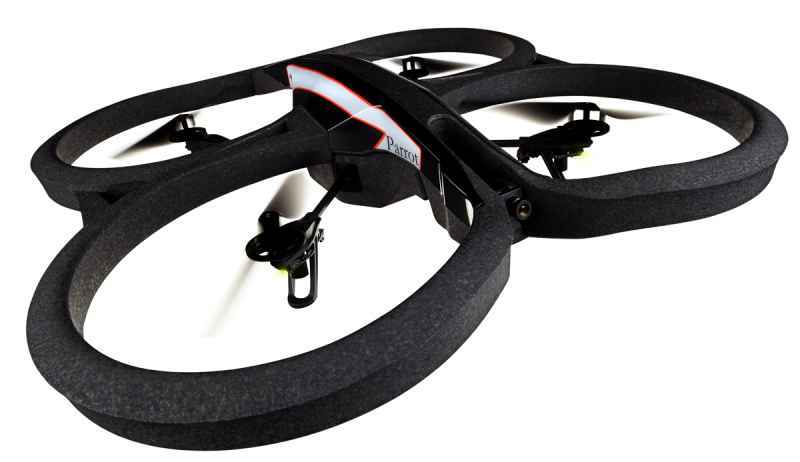
Penguin_logoFor the opening of the Paris Air Show at Le Bourget, the Paparazzi Development Team is pleased to announce the release of the Paparazzi v5.0 stable version, including the support of the Parrot AR.Drone2. See this page for more instructions.

See the changelog for an overview of new features and bugfixes.

See the Release Upgrades page for hints on configuration changes that may be required if you are moving to v5.0.0 from v4.2.0.
Read article →

22 January 2013 · paparazzi

Autonomous Paparazzi Parrot AR Drone

Parrot_AR_Drone_2_TUDelft_PaparazziAt the TU Delft university of technology student teams made the impossible; possible. Now you can turn your AR Drone v2 into an autonomous drone, controlled by Paparazzi autopilotsoftware. It’s simple, Insert GPS receiver into USB port, build and upload your flight plan via WiFi, and you are done! No hardware modification needed.

Detailed instructions to get your own drone flying with a Paparazzi autopilot brain can be found by following this link

Read article →

12 December 2012 · Felix Ruess

Paparazzi V4.2.0 Release

Penguin_logoJust before the end of the world, discover Paparazzi v4.2.0 stable version.

Based on the last stable branch v4.0, this new release offers several improvements, especially the total energy control developed by TUDelft. See the changelog for an overview of new features and bugfixes.

If you are already using paparazzi with Git, you can switch to this new branch with

git remote update && git checkout v4.2.

For new user, it will be the default branch when getting the source code from Github. You can also download a tarball or Zip file of the v4.2.0_stable source code.

Read article →

26 July 2012 · Felix Ruess

Paparazzi V4.0 Release

Penguin_logoThe Paparazzi Development Team is pleased to announce the release of the Paparazzi v4.0 stable version.

After several months of testing and debugging, the release preparation branch v3.9 has been released as v4.0. See the changelog for an overview of new features and bugfixes.

If you are already using paparazzi with Git, you can switch to this new branch with

git remote update && git checkout v4.0.

For new user, it will be the default branch when getting the source code from Github. You can also download a tarball or Zip file of the v4.0_stable source code.

Read article →

6 July 2012 · paparazzi

ATMOS Hybrid UAV

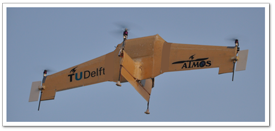
AtmosATMOS, a hybrid airplane-quadrotor developed at the MavLab of TU-Delft, was awarded third place (out of 140) in the UAVForge Competition. There were more than 140 initial contestants and after several selection rounds with only 12 finalists, the paparazzi Lisa/M powered ATMOS was one of the few that could actually make it to the remote target site miles away in an RF unfriendly environment. No team fully completed the baseline objectives which is why no prices were issued. The vertical takeoff and landing, together with long range thanks to the wing and flexibility thanks to open-source paparazzi were key factors in this event [1].

Read article →

6 July 2012 · paparazzi

1st Place at IMAV 2012 for ENAC Paparazzi Team

Blender_at_IMAV2012Blender, the small but deserving quadrotor of the ENAC Paparazzi Team took the 1st place in the “Outdoor autonomy challenge” and 3rd place in the “Outdoor flight dynamics challenge” during the IMAV2012 competition in Braunschweig, Germany. Completing its missions with overflowing enthusiasm thanks to the new NavGo autopilot. NavGo is the latest in the long line of award winning Paparazzi hardware available. See the list of Paparazzi hardware here.

Read article →

9 May 2012 · Felix Ruess

Stable Paparazzi Releases

Git-Logo-2ColorIn order to improve the development workflow and provide stable releases we have changed our git branching model.

The branch “master” is now our development branch.

  • The “dev” branch was renamed to the release preparation branch “v3.9”. Switch to this branch if you want stable code.
  • “master” was reset to the previous “locm3” branch, where development will happen now with libopencm3 for the STM32 architecture.

Please see the RepositoryStructure page for more details.

Read article →

9 April 2012 · paparazzi

Paparazzi in Madagascar

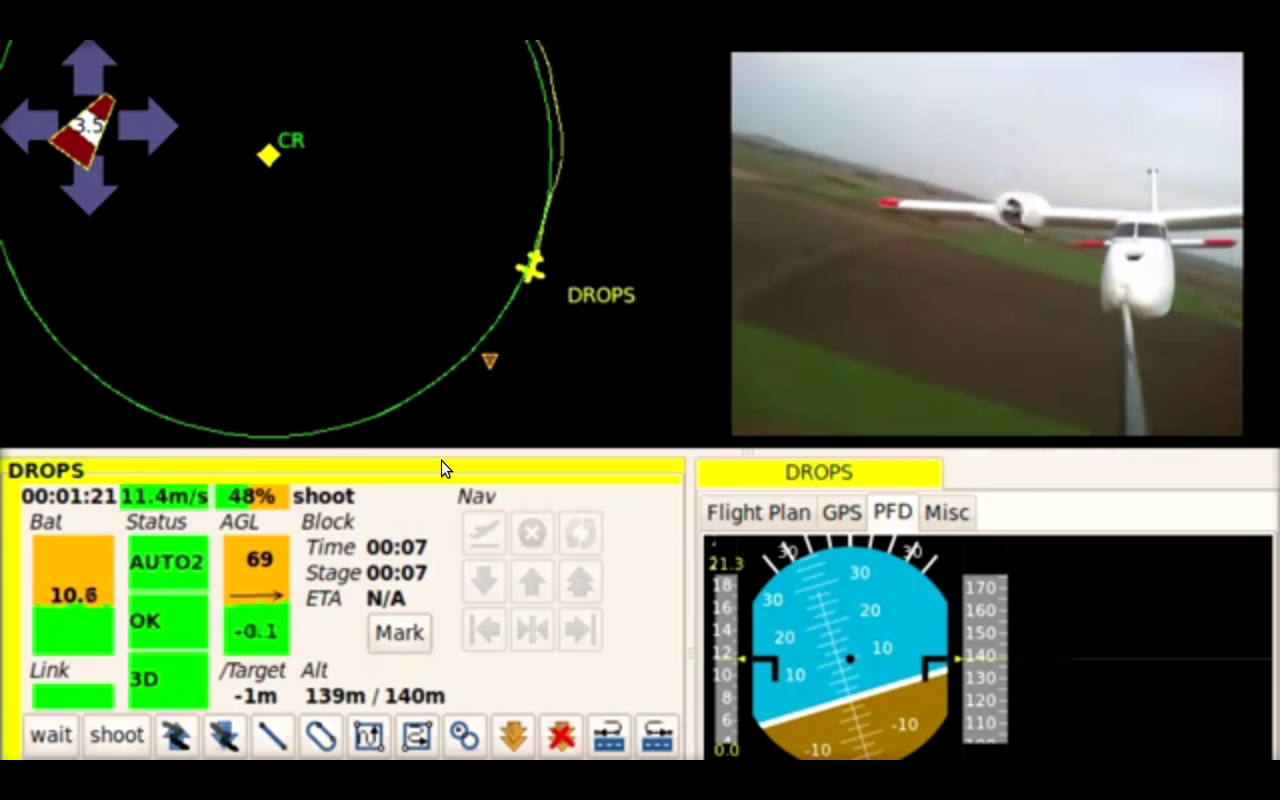
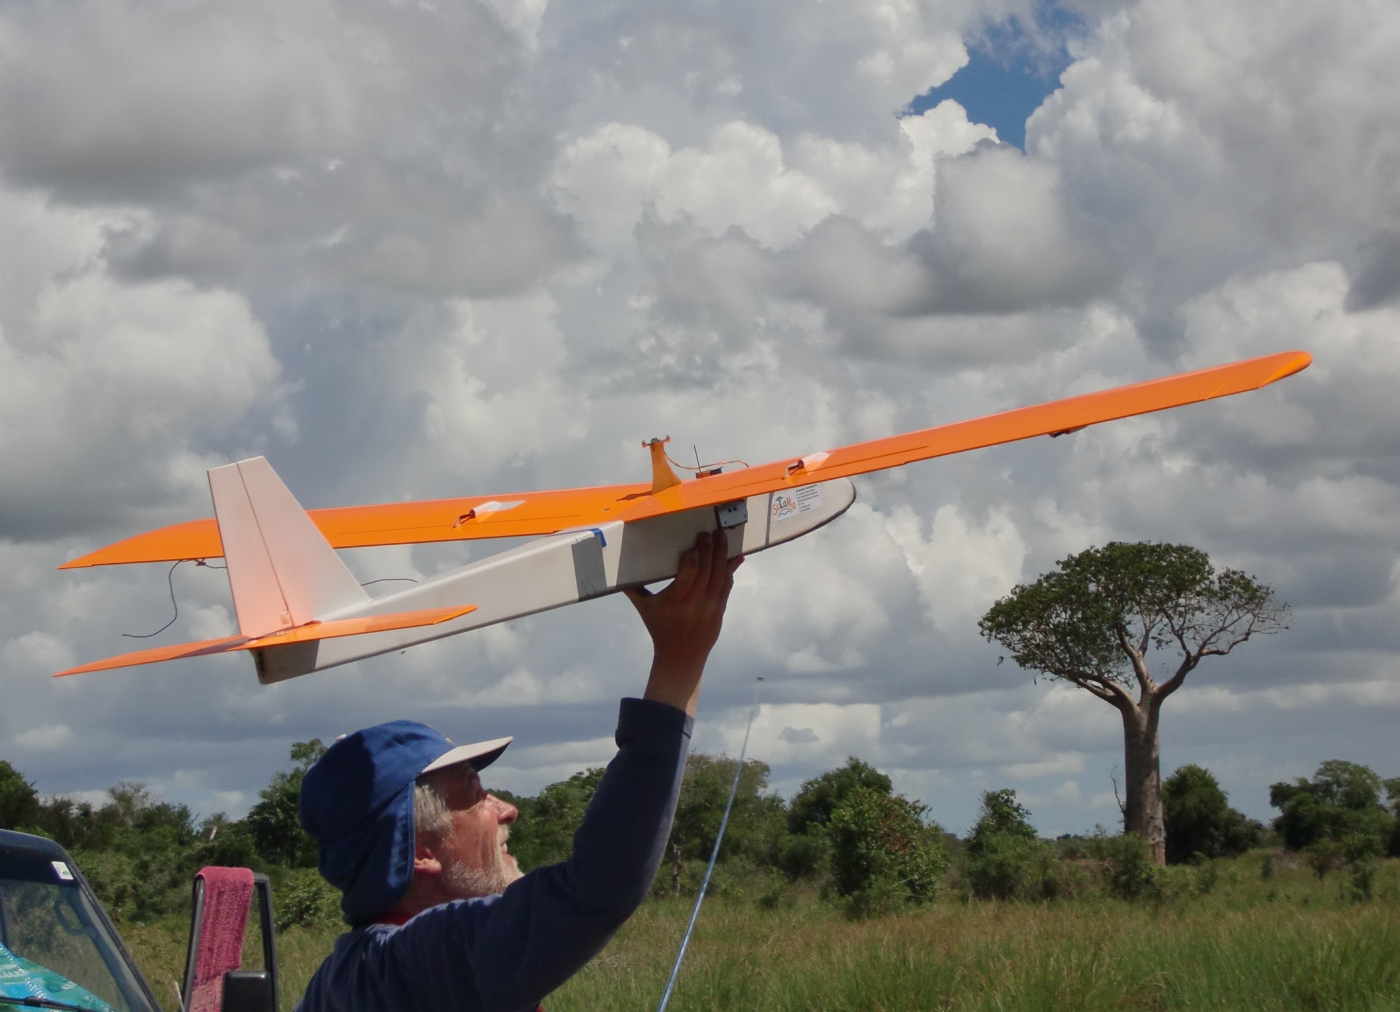
Mini-Horus_Launch_in_MadaIn March 2012, Paparazzi flew in southern Madagascar in the frame of a multi-university project to study and improve the ecosystem in one of the poorest regions of the world (Project). More than 4000 hectares of farm and grassland were photographed in visible and near infrared spectrum. More than 8500 photos were taken. Surely one of the biggest missions for science ever flown with Paparazzi.

Read article →