PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Posts

8 January 2014 · Piotr Esden-Tempski

Paparazzi Wiki Update

Penguin_logoTo make documenting and learning about Paparazzi easier we have updated the Wiki to the latest Mediawiki version (1.22). This new wiki provides a very improved search of the many articles, as well as video embed tags. You can easily embed a YouTube video into your article by writing {{#ev:youtubehd|videoID}}, or a Vimeo video by adding {{#ev:vimeo|videoID}}. The wiki is hosted on a new dedicated Paparazzi UAV server so it should be faster now aswell.

Read article →

20 September 2013 · Piotr Esden-Tempski

IMAV 2013

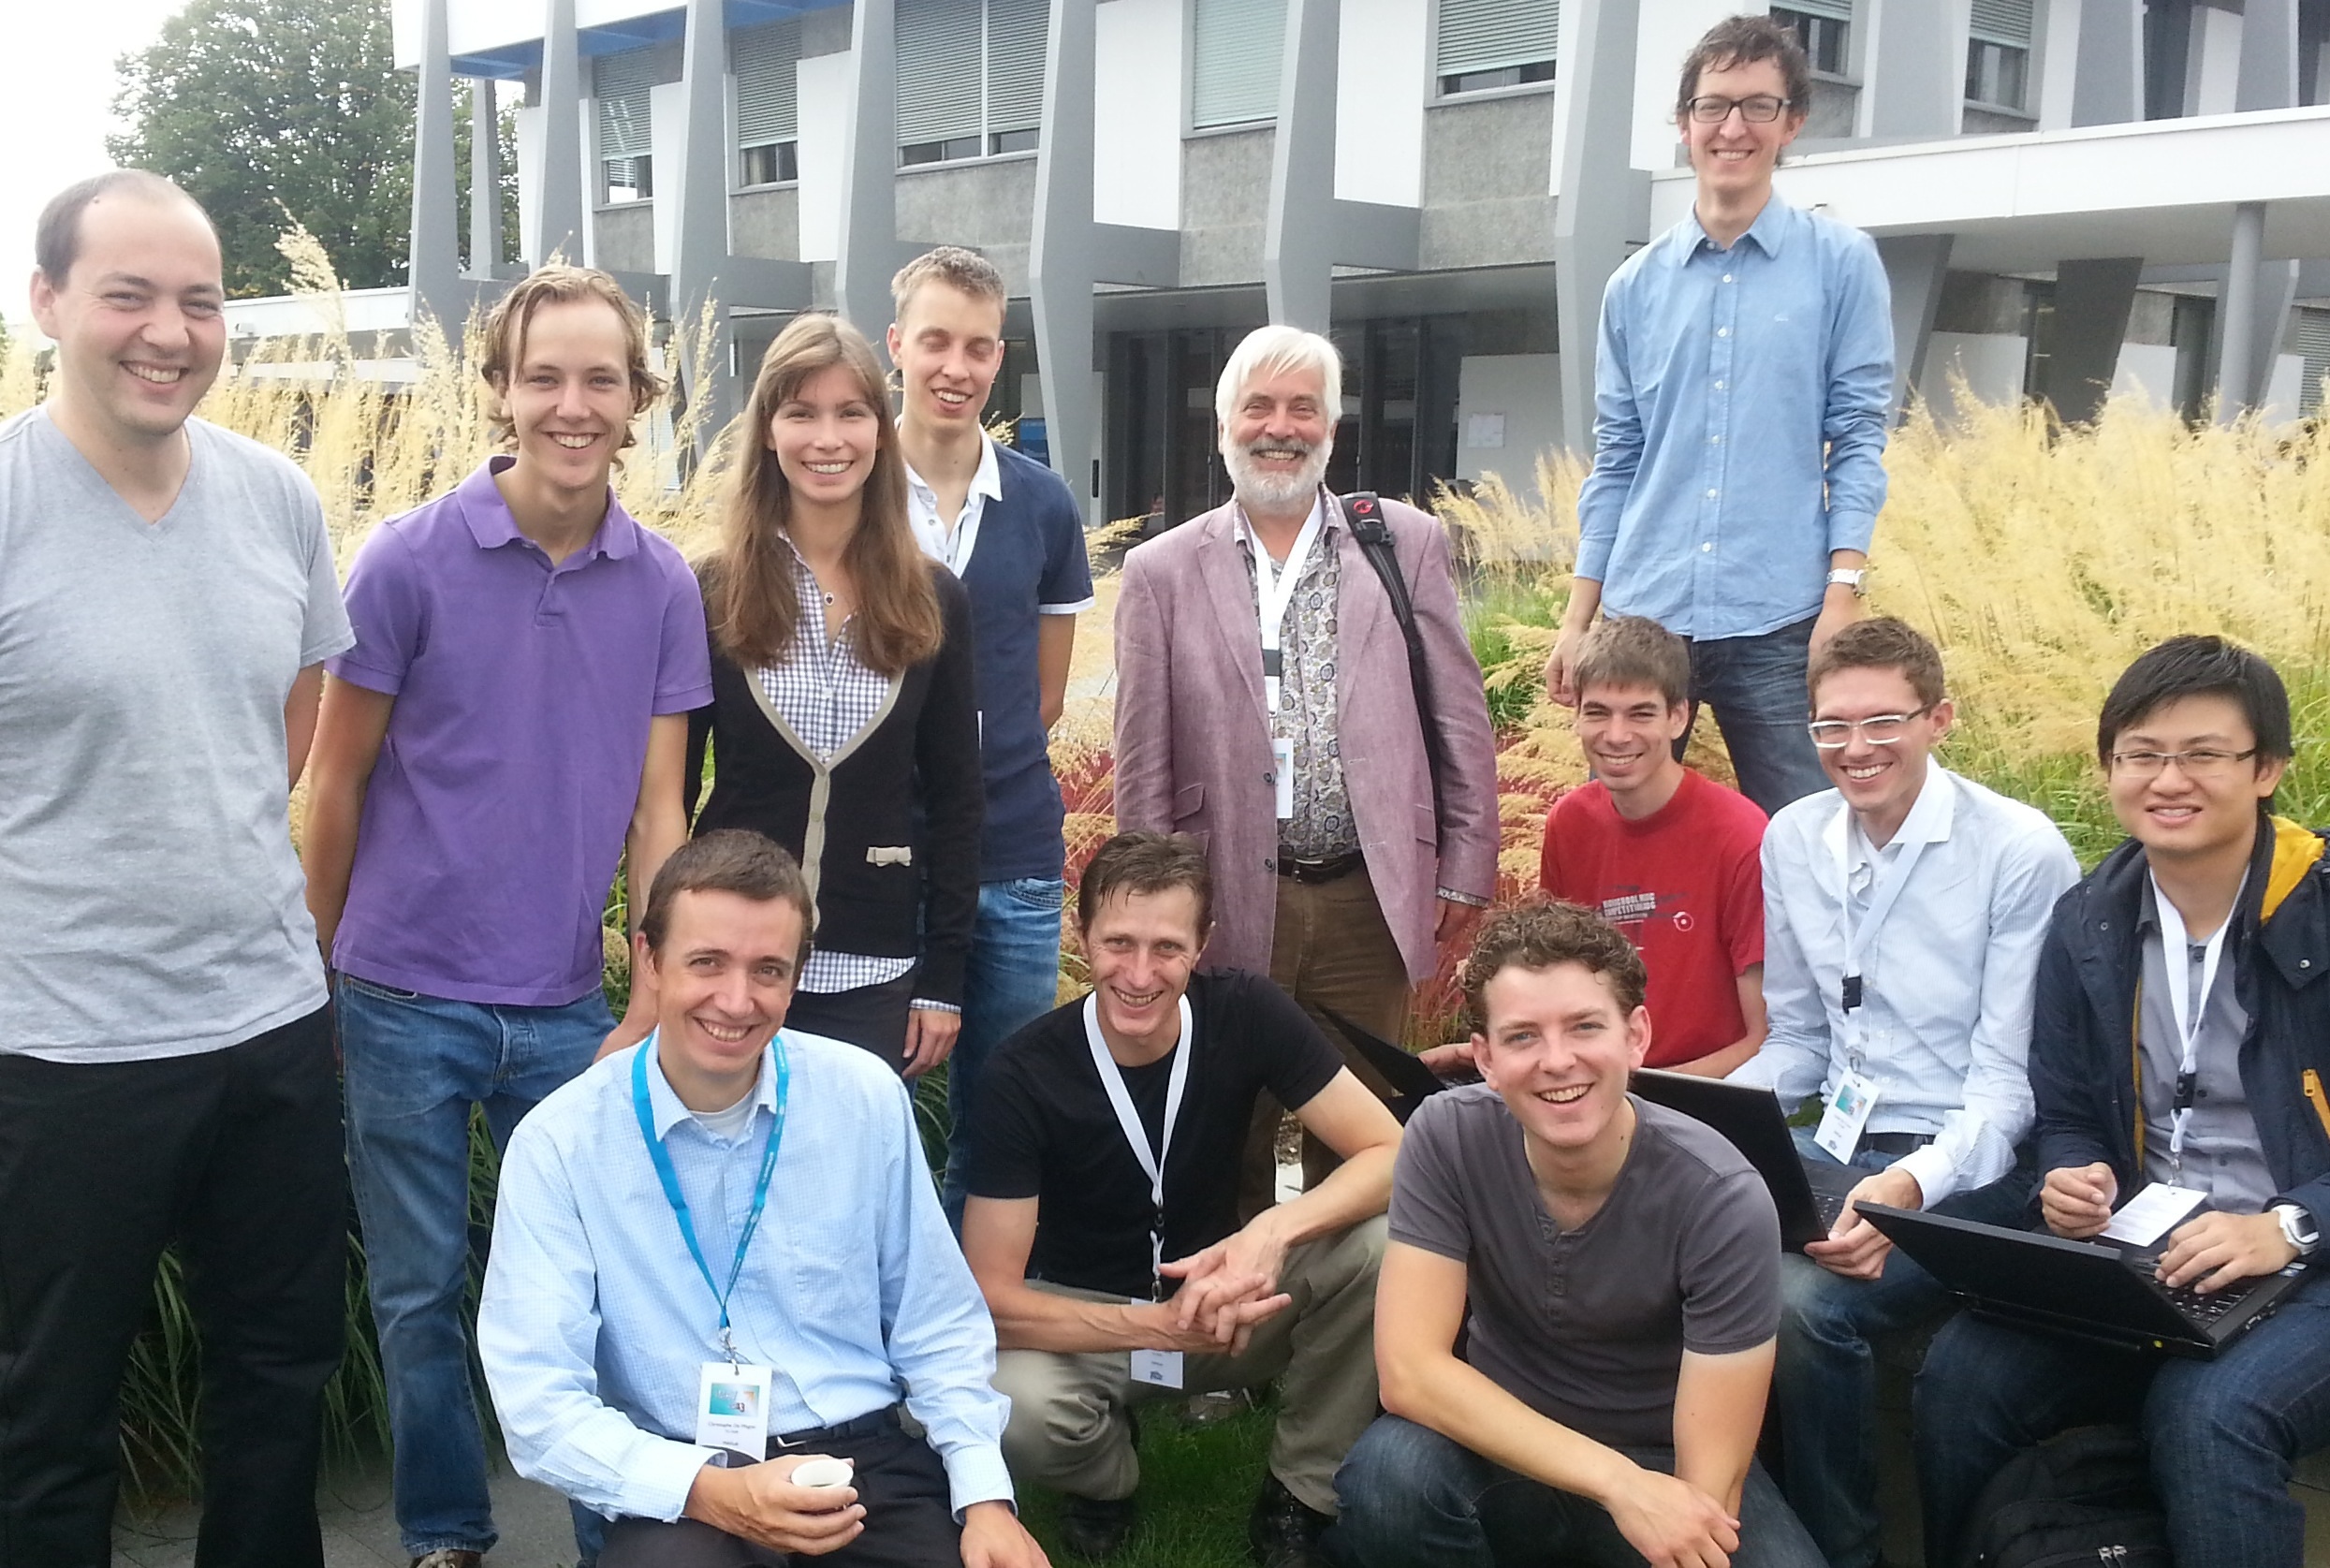
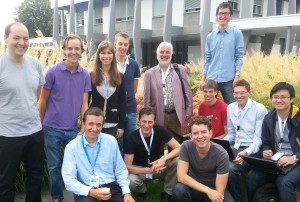
Mavlabimav2013The MavLab team of TU Delft consisted of 12 people coming from aerospace, computer science, embedded programming and artificial intelligence. Thanks to the enormous team efforts in the last months, the team has won prizes in all the categories in which it participated at IMAV 2013 in Toulouse, France:

Outdoor: 1st place

With an autonomous swarm of 12 MAVs operated by a single operator. The MAVs only had to be plugged in and started with their own flight plan, while the operator could monitor their mission status and intervene where necessary. Our participation featured four main innovations: (1) a single operator for 12 MAVs, 3 hybrid UAVs, 7 Parrot AR drones and 2 mini-quadrotors, (2) onboard vision processing on the AR drone with Paparazzi, (3) hybrid UAVs able to fly under any attitude, and (4) the world’s smallest open source autopilot,  Lisa/S (2 grams). The wind conditions were terrible on the outdoor competition day, with 6 Bft, and most teams had their MAVs blown away. Everybody was impressed with how the hybrid UAVs were able to cope nicely with these conditions and were still able to perform a precision landing.
Read article →

26 August 2013 · Piotr Esden-Tempski

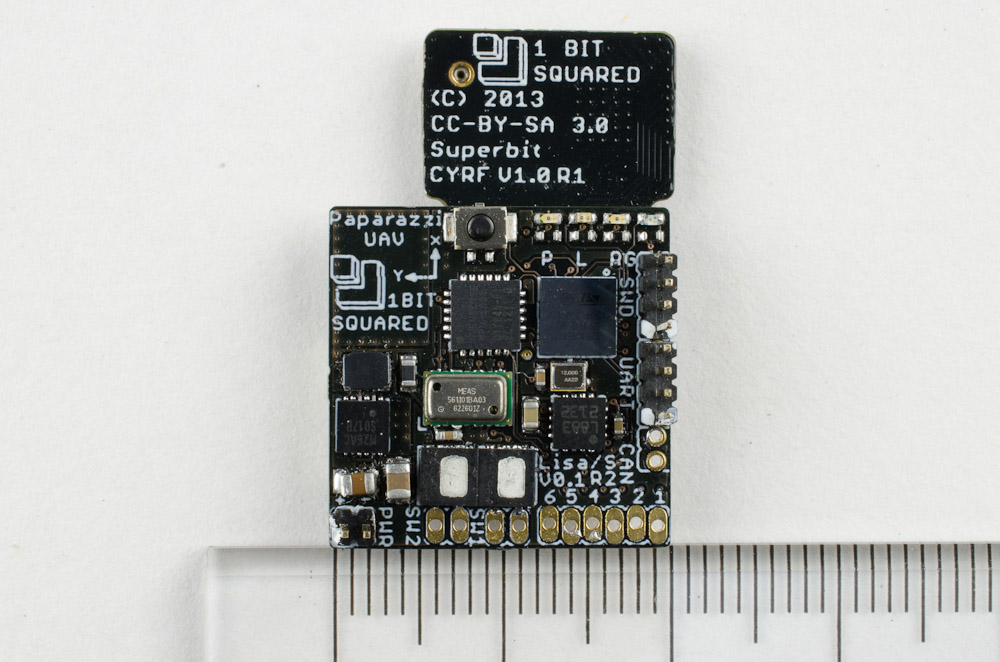
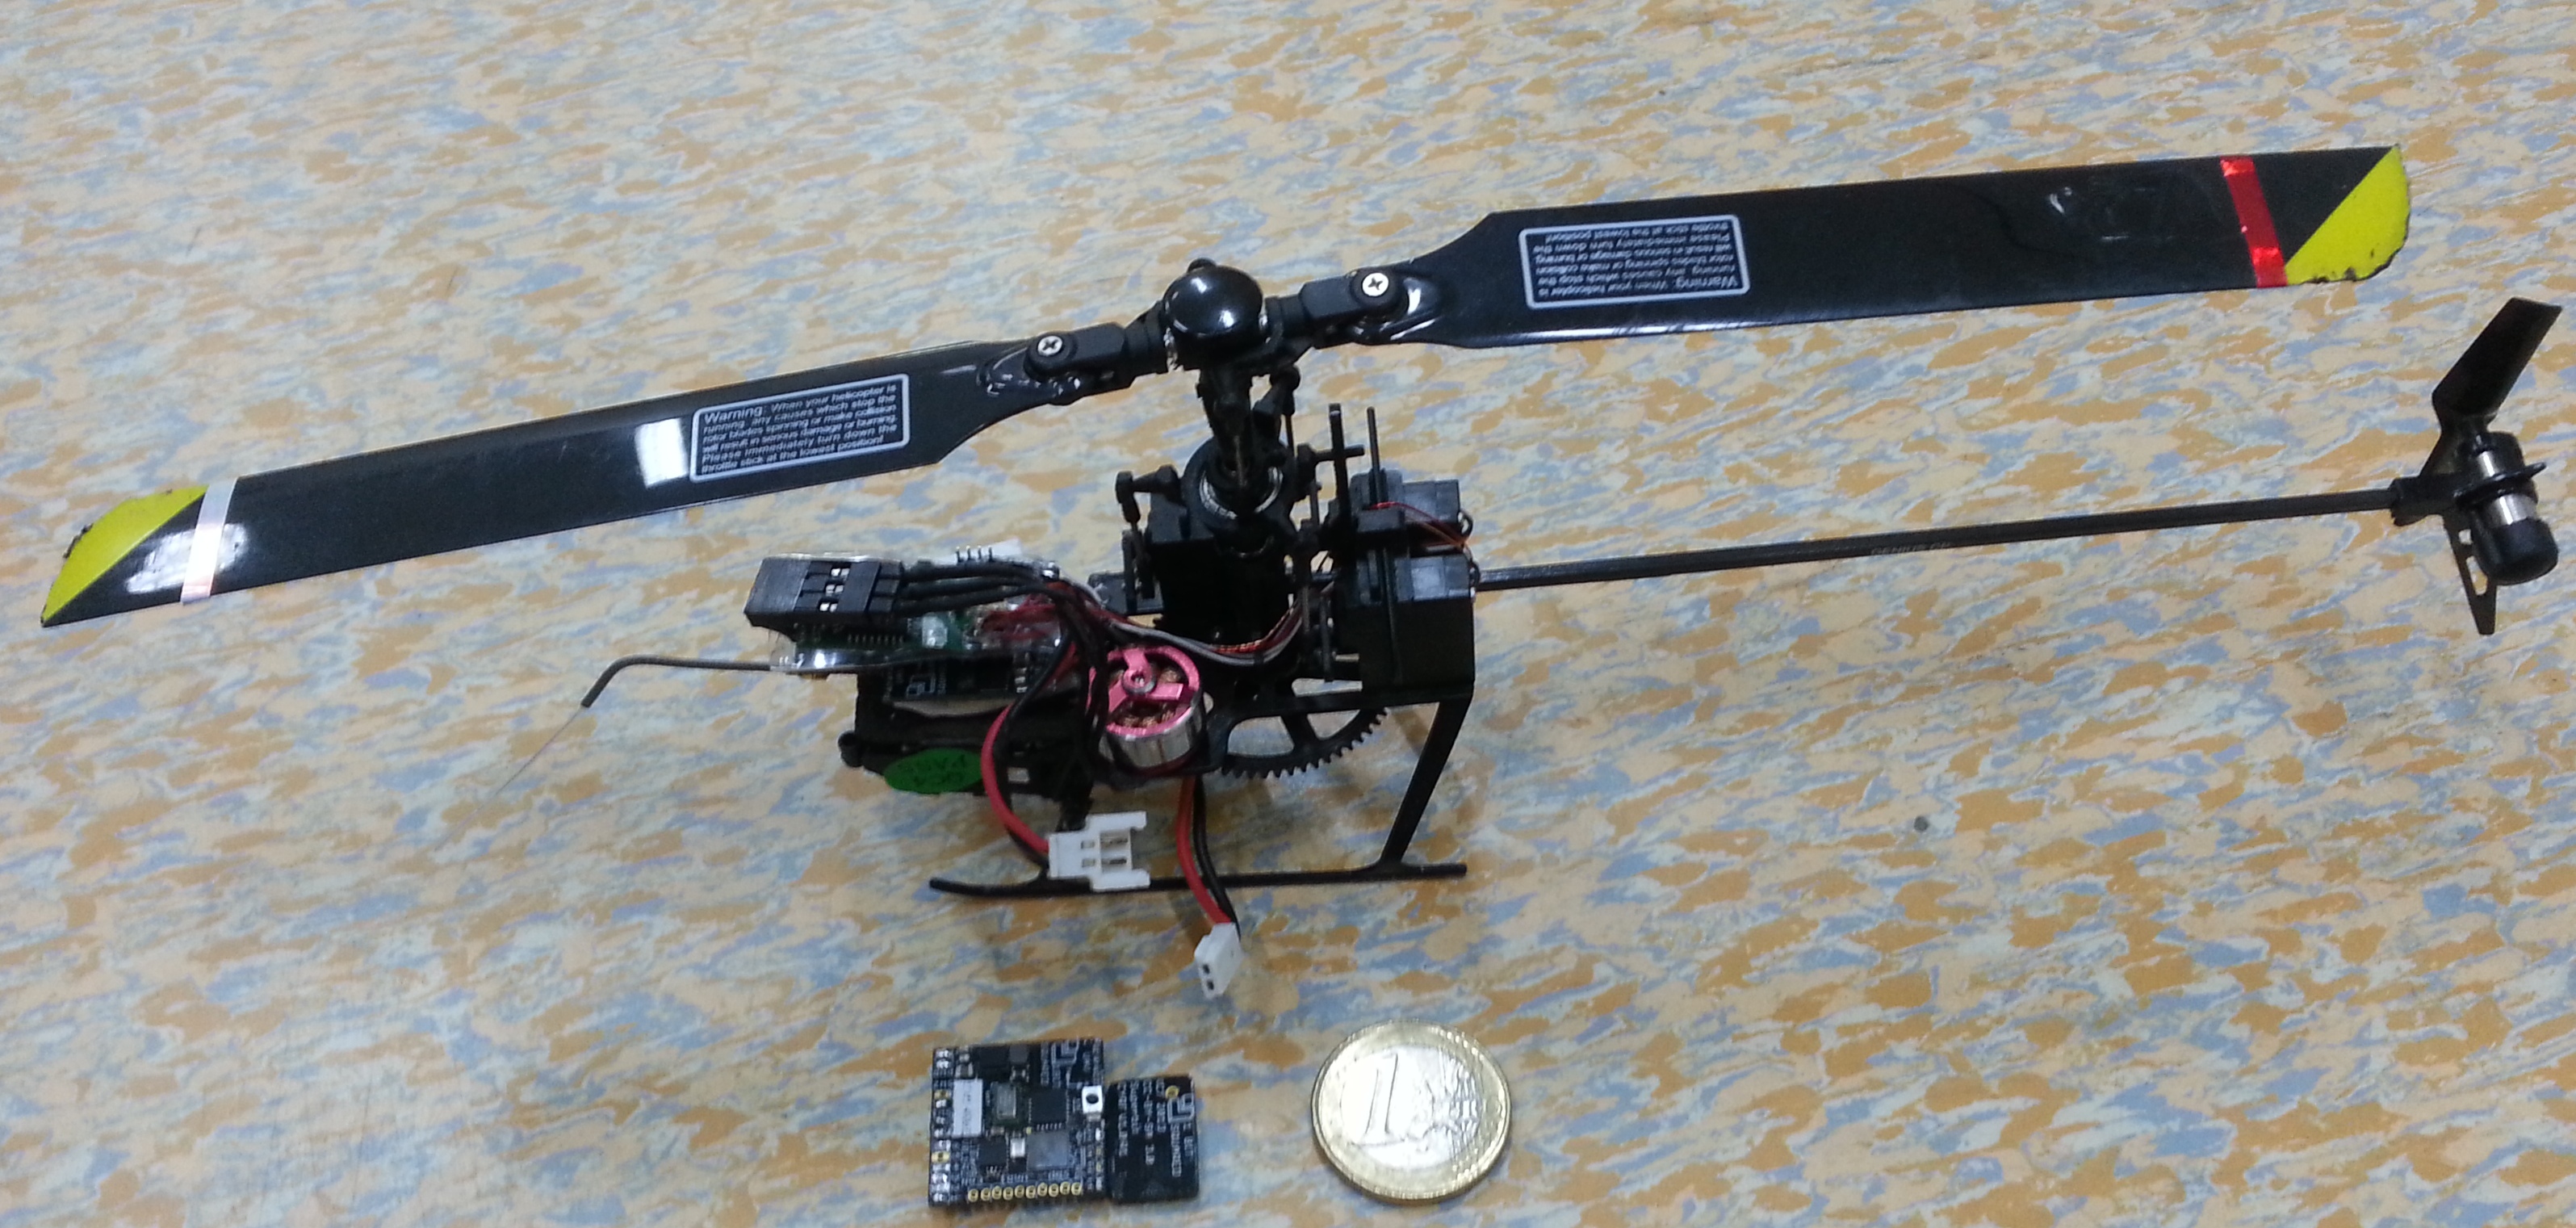
Lisa/S The Worlds Smallest UAV Autopilot

2013-08-22_16.19.04TU Delft researchers in collaboration with 1BitSquared have designed and build the world’s smallest autopilot for micro aircraft.

Researcher Bart Remes and his team of the Micro Aerial Vehicle Laboratory at the TU Delft faculty of Aerospace Engineering in a collaboration with Piotr Esden-Tempski from 1BitSquared have designed, built and tested the world’s smallest open source autopilot for small unmanned aircraft. A smaller – and lighter – autopilot allows these small flying robots to fly longer, fit into narrower spaces or carry more payloads, such as cameras. That makes them more suitable to be used in rescue operations for example. Remes: “Our aim? Make MAVs so small and light that every fireman can fit one in his pocket.”

Read article →

13 August 2013 · paparazzi

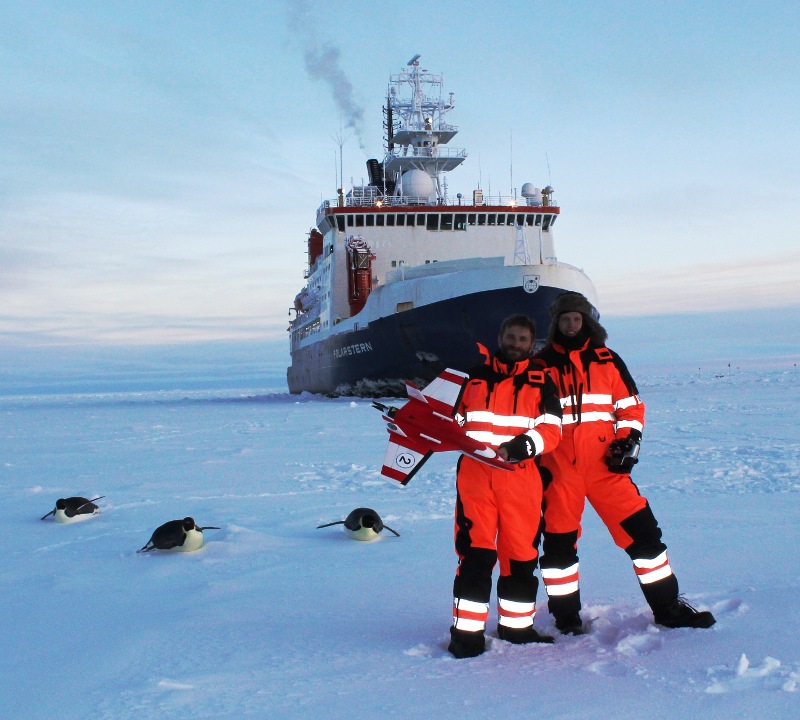
Antarctica Meteo Missions 2013

Weddell_seaOver the last 9 weeks the Paparazzi autopilot has been used for operations with remotely piloted aircraft from the Finnish Meteorological Institute for scientific research on board the R.V. Polarstern in the Weddell Sea/Antarctica. You can see the course and read a short report on the homepage of the Alfred Wegener Institut.

Instructions on how to build your own small unmanned meteorological observer (SUMO) can be found here in the Wiki.

Read article →

10 August 2013 · Piotr Esden-Tempski

Lisa/S V0.1 Design

Lisa/S nano autopilot V0.1 PCB Layout video - 6 months of work in 3 minutes.

Designing new hardware takes time. Laying out a board is only part of the challenge. A lot of work goes into research about the parts and circuits to use. In the following video you can see how the whole engineering effort concludes into the final design of the board. Even though the time lapse shows only 7 hours and 48 minutes of layout work, it was spread over 6 months of engineering effort.

Read article →