PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Posts

22 February 2023 · Gautier Hattenberger

ENAC Team wins at IMAV2022

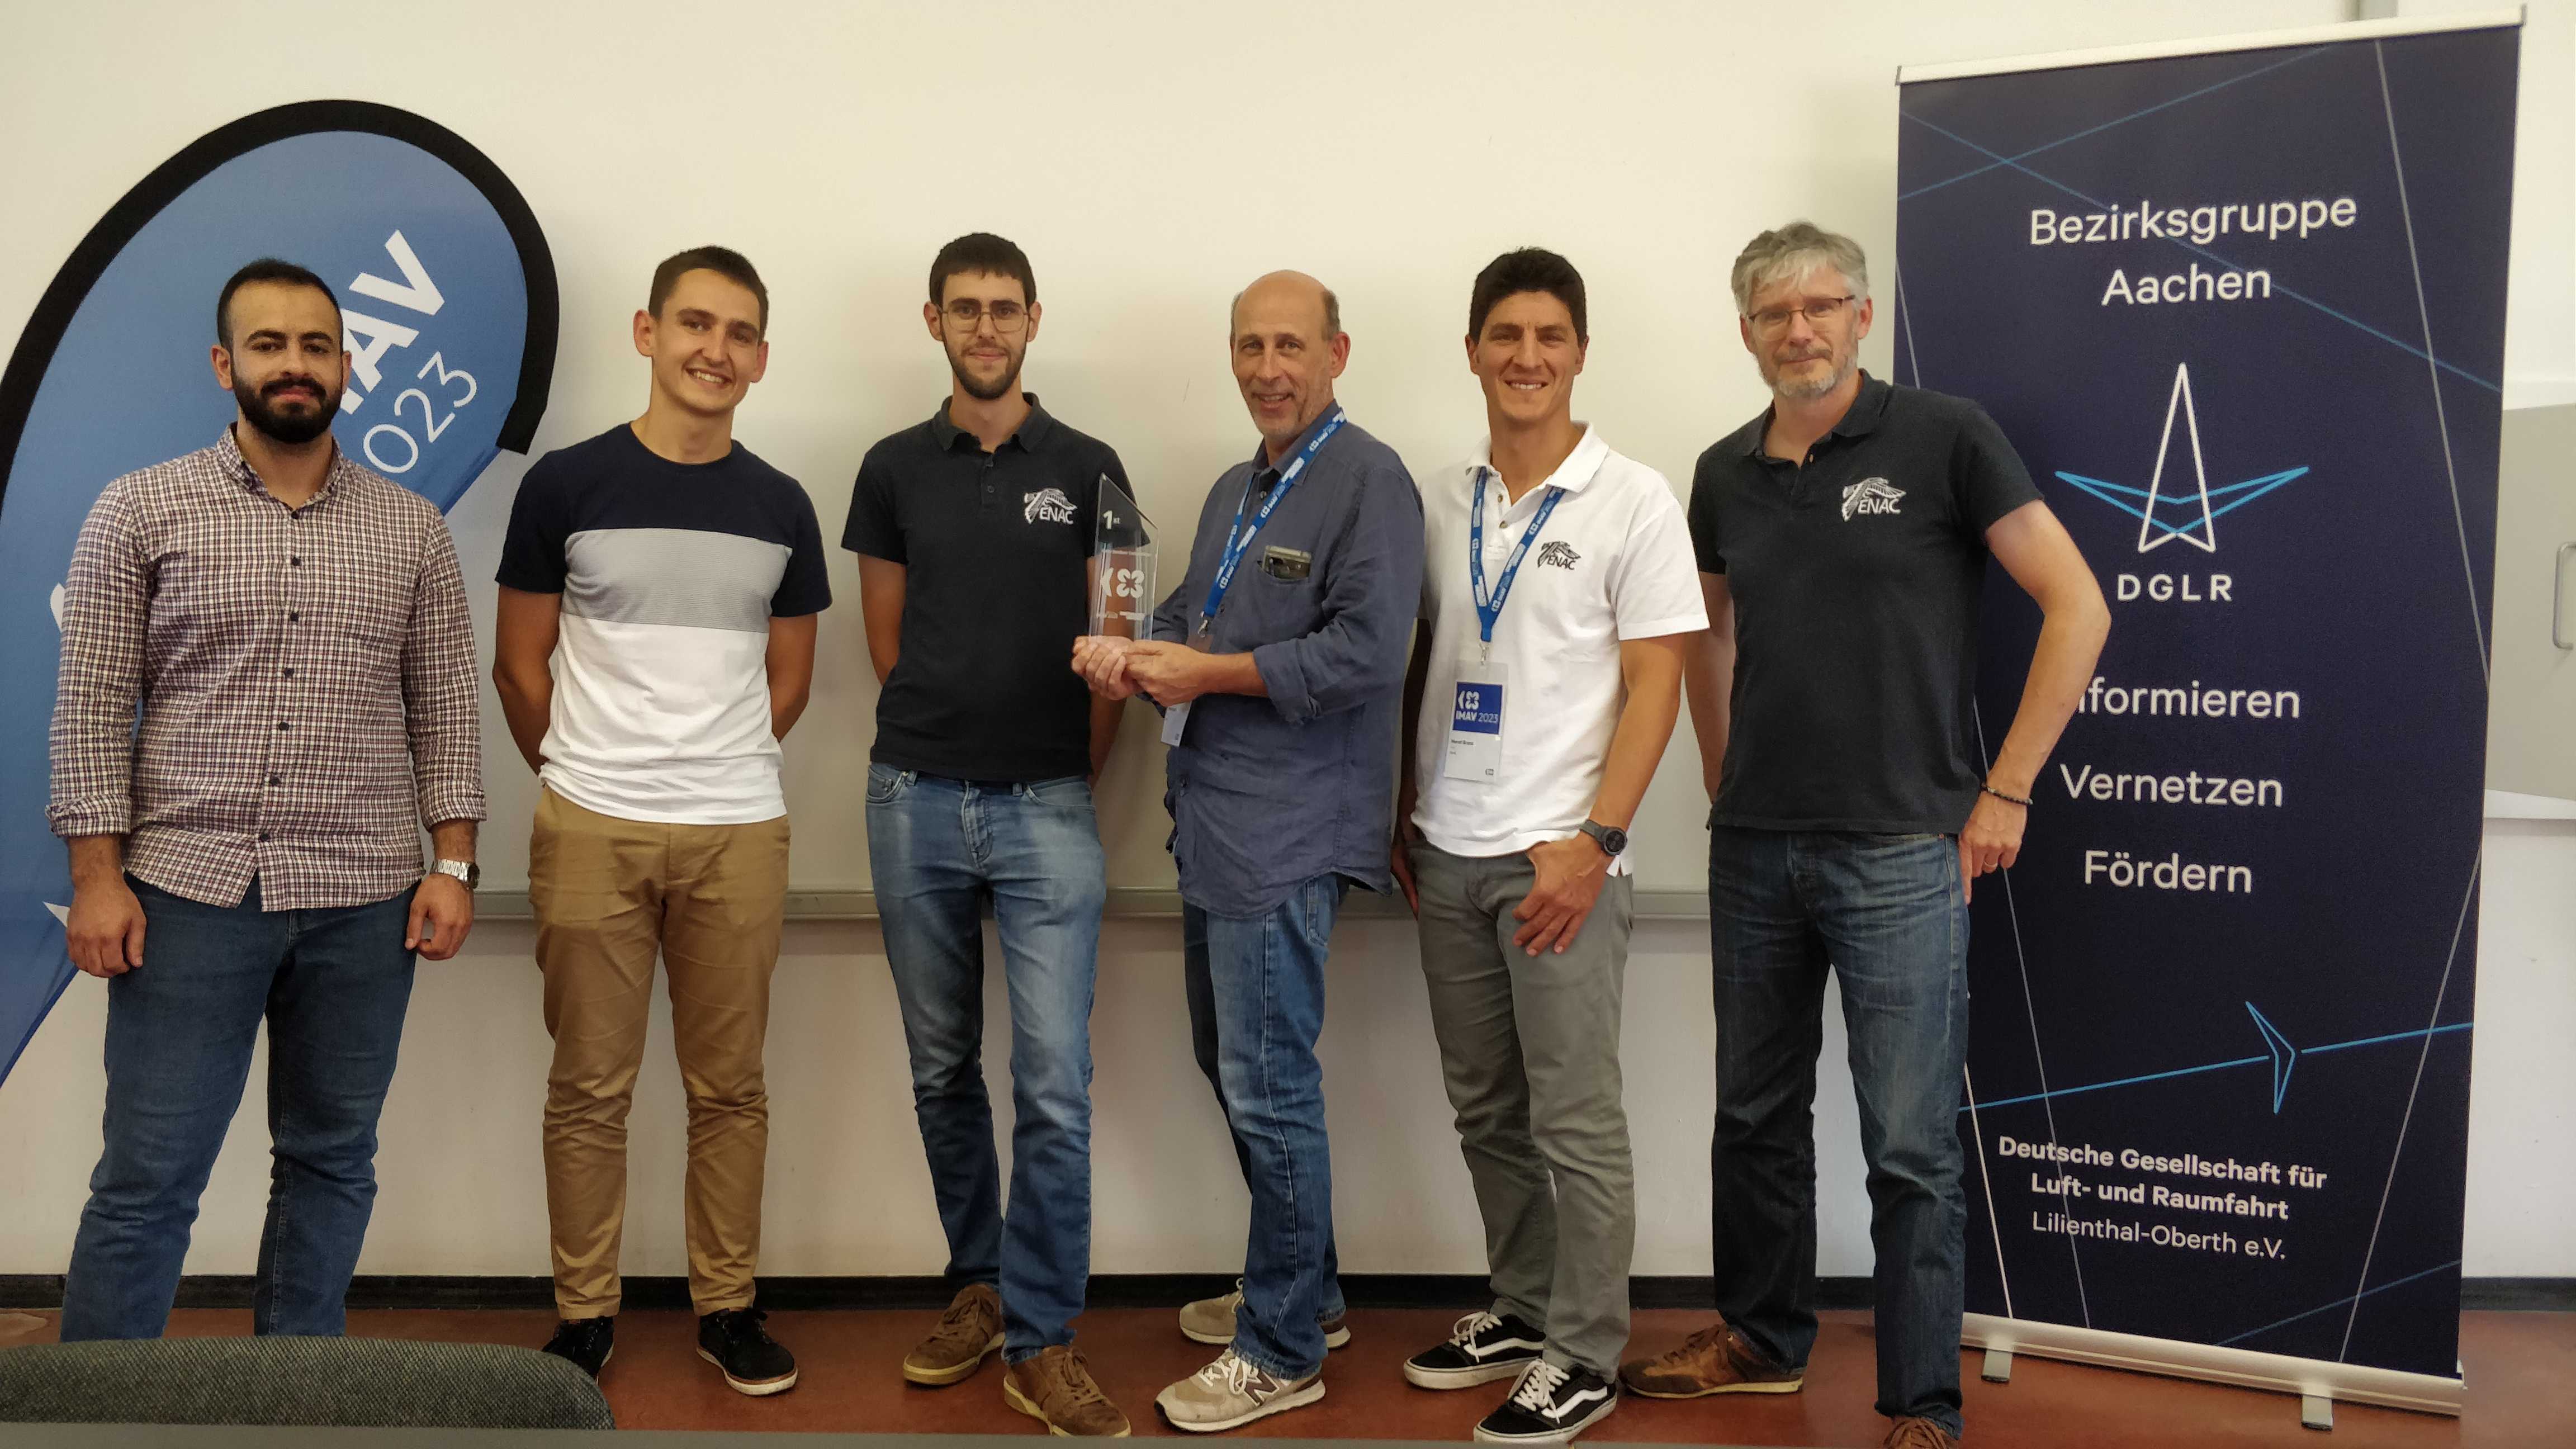
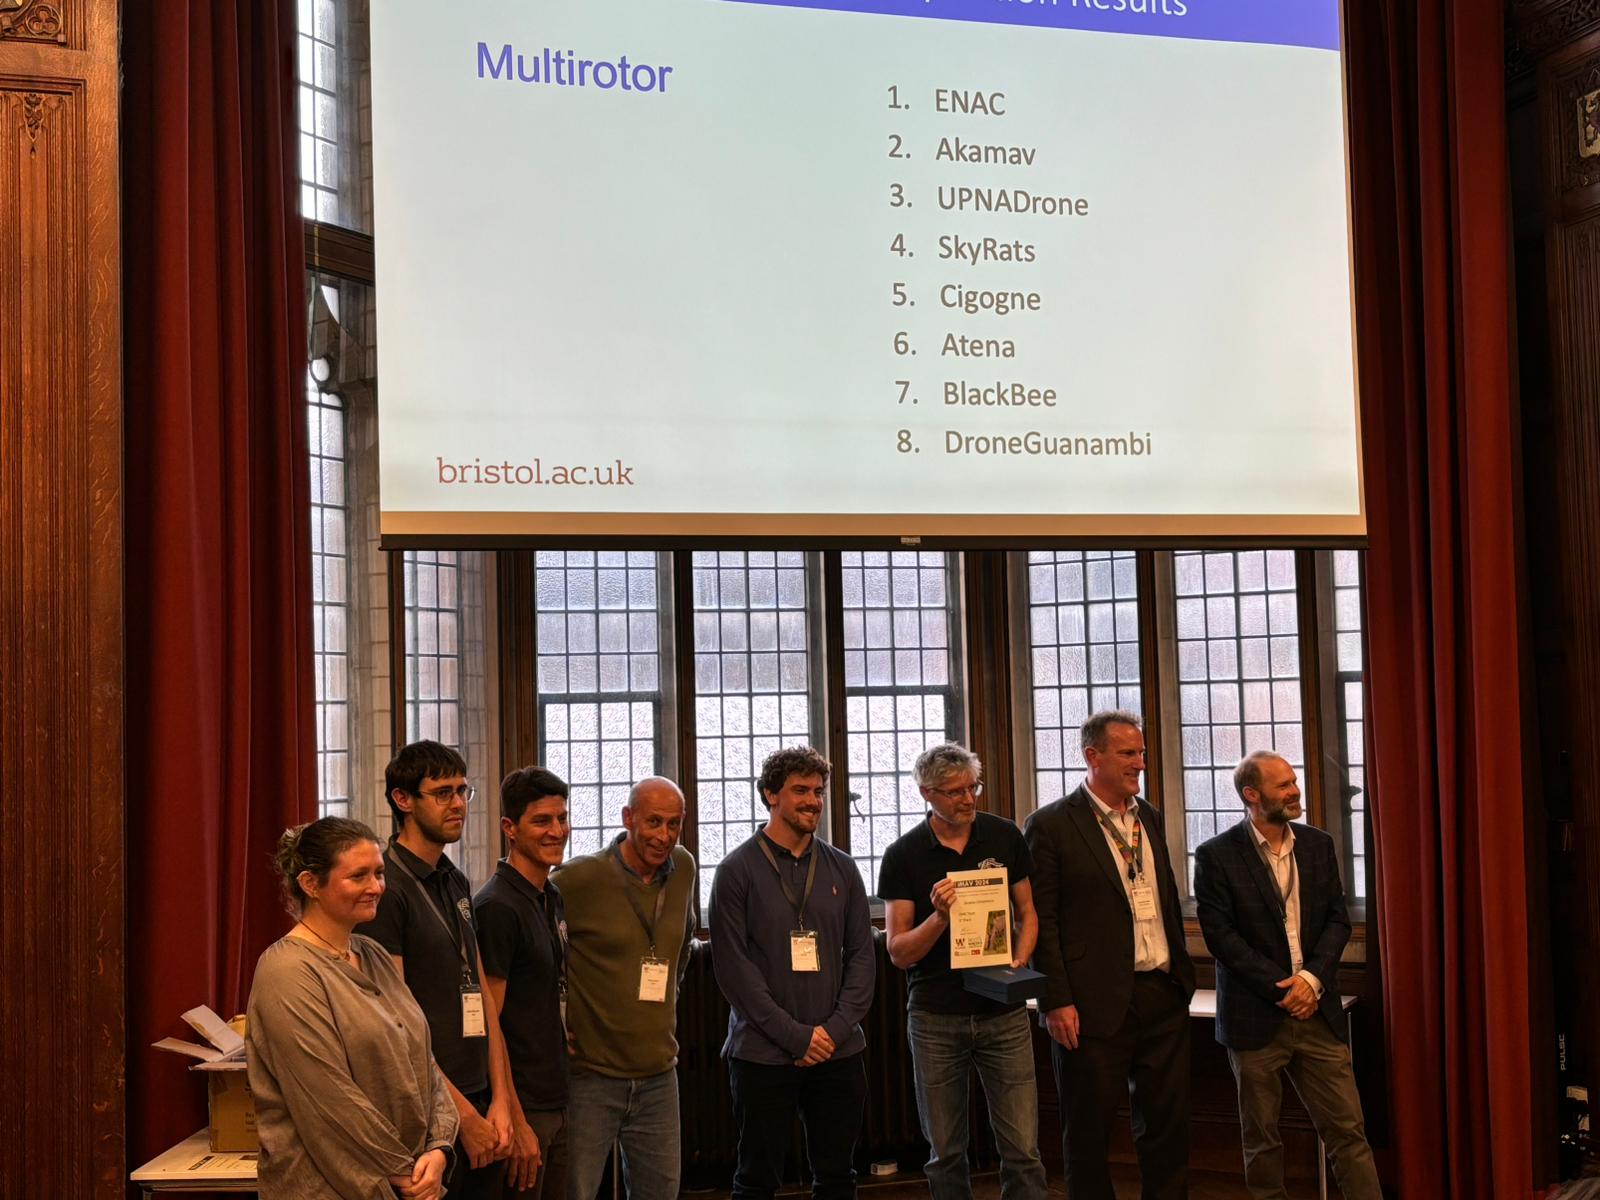
The International Conference and Competition on MAV was organized by TUDelft mid-September 2022. The ENAC took part to the outdoor competition, a package delivery challenge, with several multi-rotors and a hybrid tail-sitter, all powered by Paparazzi.

They won the competition with a quite large amount of points. Nevertheless, all teams performed well with some innovative platforms.

Several papers have been presented to the conference by the ENAC team and the other participants. The proceedings are freely available on the conference website.

Read article →

13 April 2021 · Gautier Hattenberger

Paparazzi v5.18 is out, v6.0 is starting

The latest Paparazzi stable release is out today with many changes and addition since 5.16 one year ago. One of the biggest changes is the complete rewrite of the build system for the aircraft code generation (good old Ocaml stuff), plus the addition of a proper dependency resolution for the modules. It has no big impact for users so far, but in order to move forward, we will most likely break a few things…

Read article →

15 November 2020 · Gautier Hattenberger

Paparazzi at the SPLASH2020-REBASE Conference

The Paparazzi UAV System as a research tool will be presented as an invited talk at the SPLASH2020-REBASE conference (Mon 16 Nov 2020 18:00, Paris time). See the program of the conference for details. The presentation will be available on live and free youtube.

https://2020.splashcon.org/details/splash-2020-rebase/19/Paparazzi-an-open-source-UAV-for-research

UPDATE: the video of the conference is online

Read article →

4 March 2020 · Gautier Hattenberger

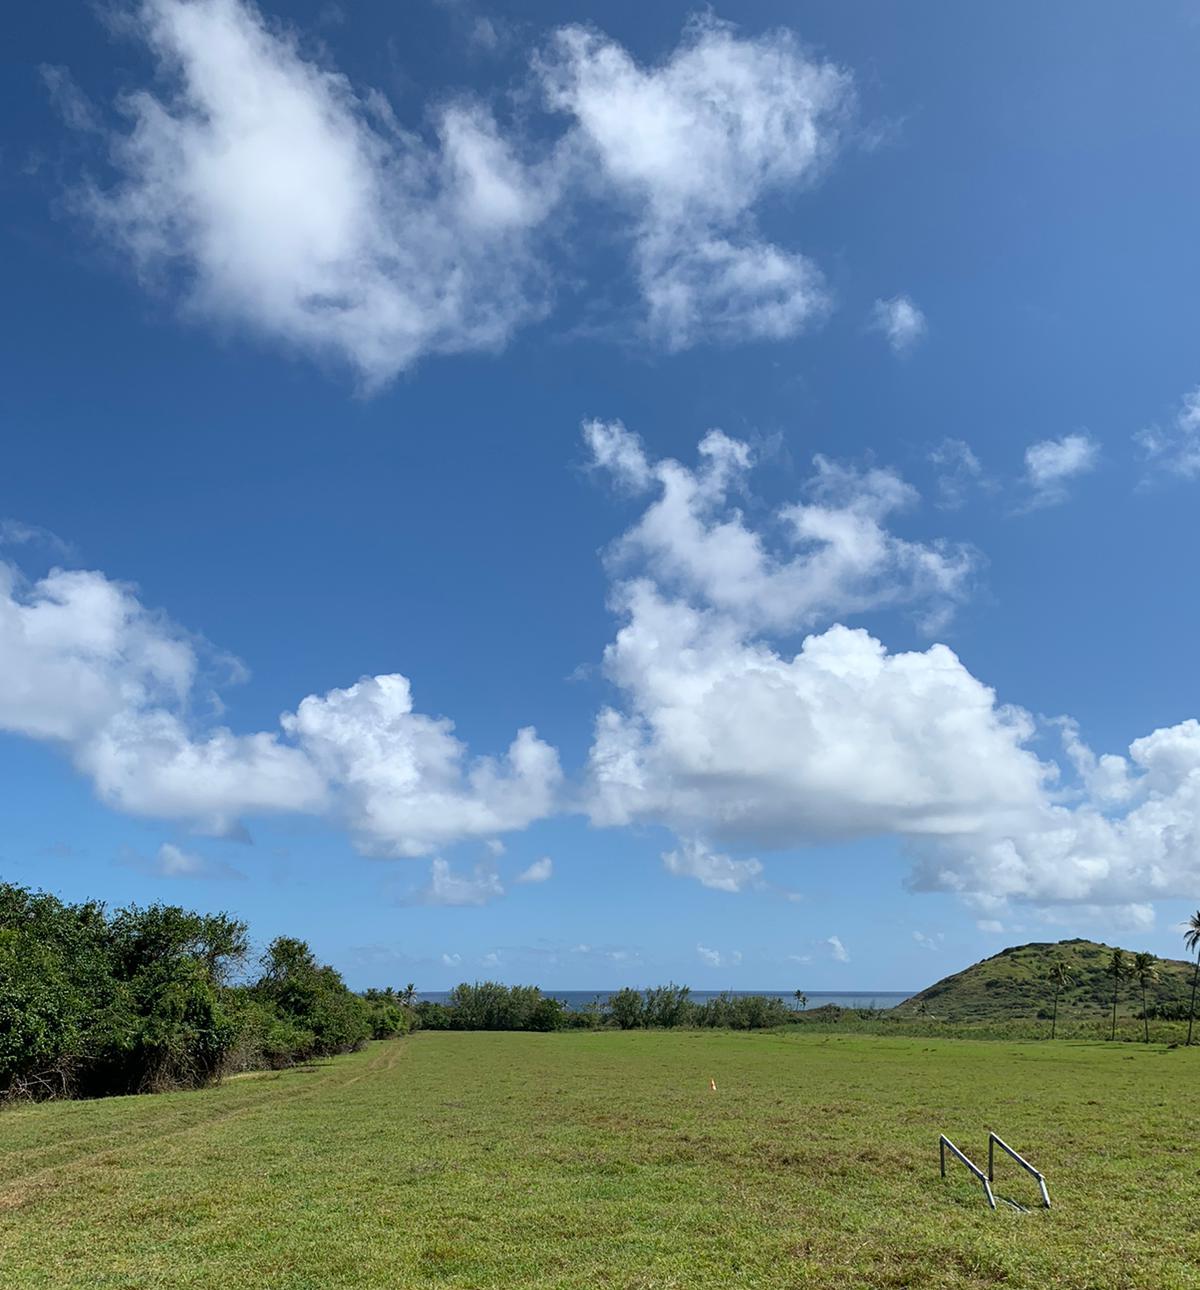
Flight Campaign at Barbados Island

Enac UAV lab have participated to an atmospheric research flight campaign at the Barbados Island for three weeks from end of January 2020. 
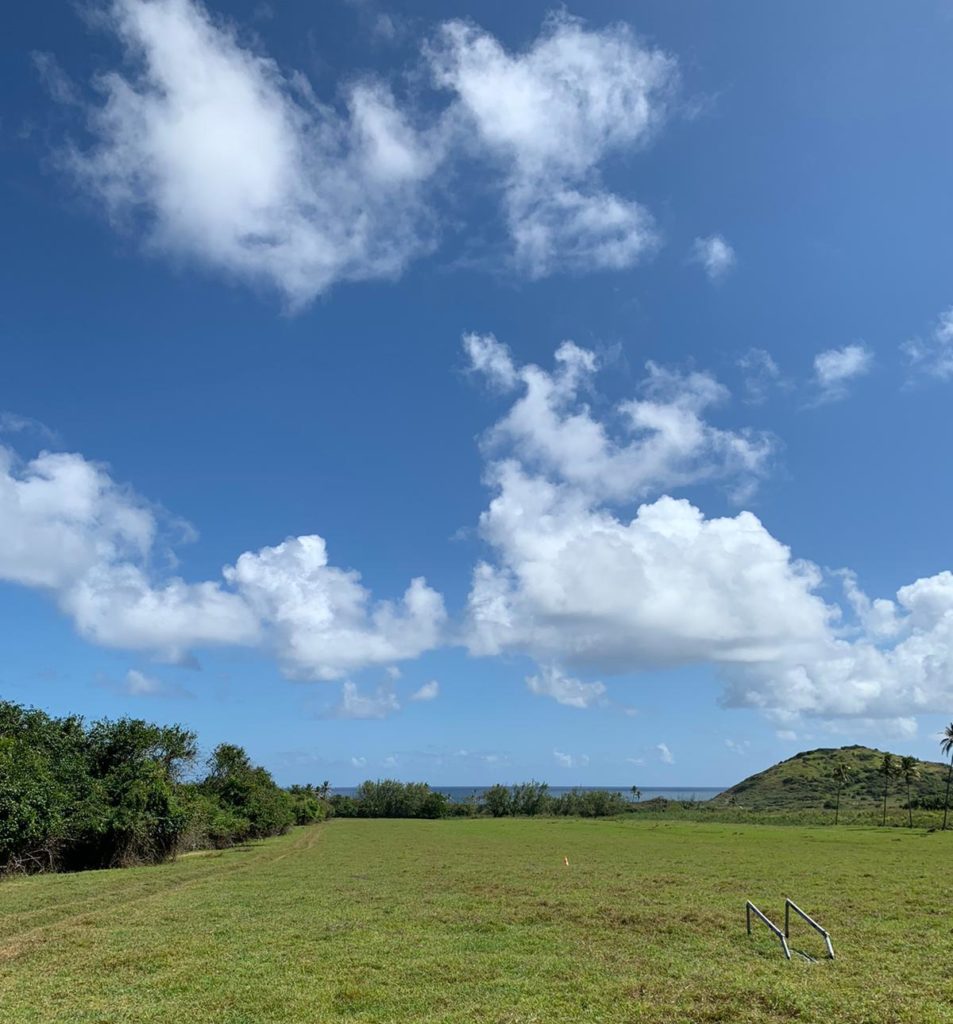
This was part of a project called NEPHELAE in collaboration with the French National Meteorological Research Center from Météo-France and the robotics lab LAAS-CNRS.
NEPHELAE is atmospheric science driven (with a focus on cloud microphysical processes) via robotic technological development (adaptive, model-guided path planning in a UAV fleet). Essentially, by merging the state-of-the-art technology, the observational tools for conducting research in atmospheric science will take a quantum leap forward. At the same time, we are using this novel approach to address decades-old questions on entrainment and the onset of precipitation that have been limited by traditional observing methods.
Read article →

3 February 2020 · Gautier Hattenberger

Crazyflie v2.1 with Paparazzi onboard

The popular Open-Source platform Crazylie v2.1 from Bitcraze is now supported by Paparazzi. Only the main frame, with IMU, barometer as well as the NRF communication is working. A bridge between the Crazyradio and the Ivy bus allows the direct and easy connection of the Crazyflie to the ground station. More sensor decks will be supported in the future.

See the (almost) maiden flight inside the flight arena at Enac:

Thank you to the Bitcraze dev team for their support !

Read article →

10 April 2019 · Gautier Hattenberger

Running Paparazzi on Windows

Since there are many Windows users who like to try paparazzi on this popular OS and Microsoft introduced the possibility of running Ubuntu programs and tools on windows 10, now Paparazzi developer team is pleased to announce the initial release of the Windows10 support of Paparazzi.

The installation process is not so much different from the Linux, but you need some extra steps to install Ubuntu, and some more for using graphical interface and connecting to the aircraft via telemetry. This first release still retains the look and feel of its Linux sibling as currently it uses X Windows for rendering, so you need to install X server in order to have graphical interface.

Read article →

28 November 2018 · Gautier Hattenberger

Paparazzi wins at IMAV2018

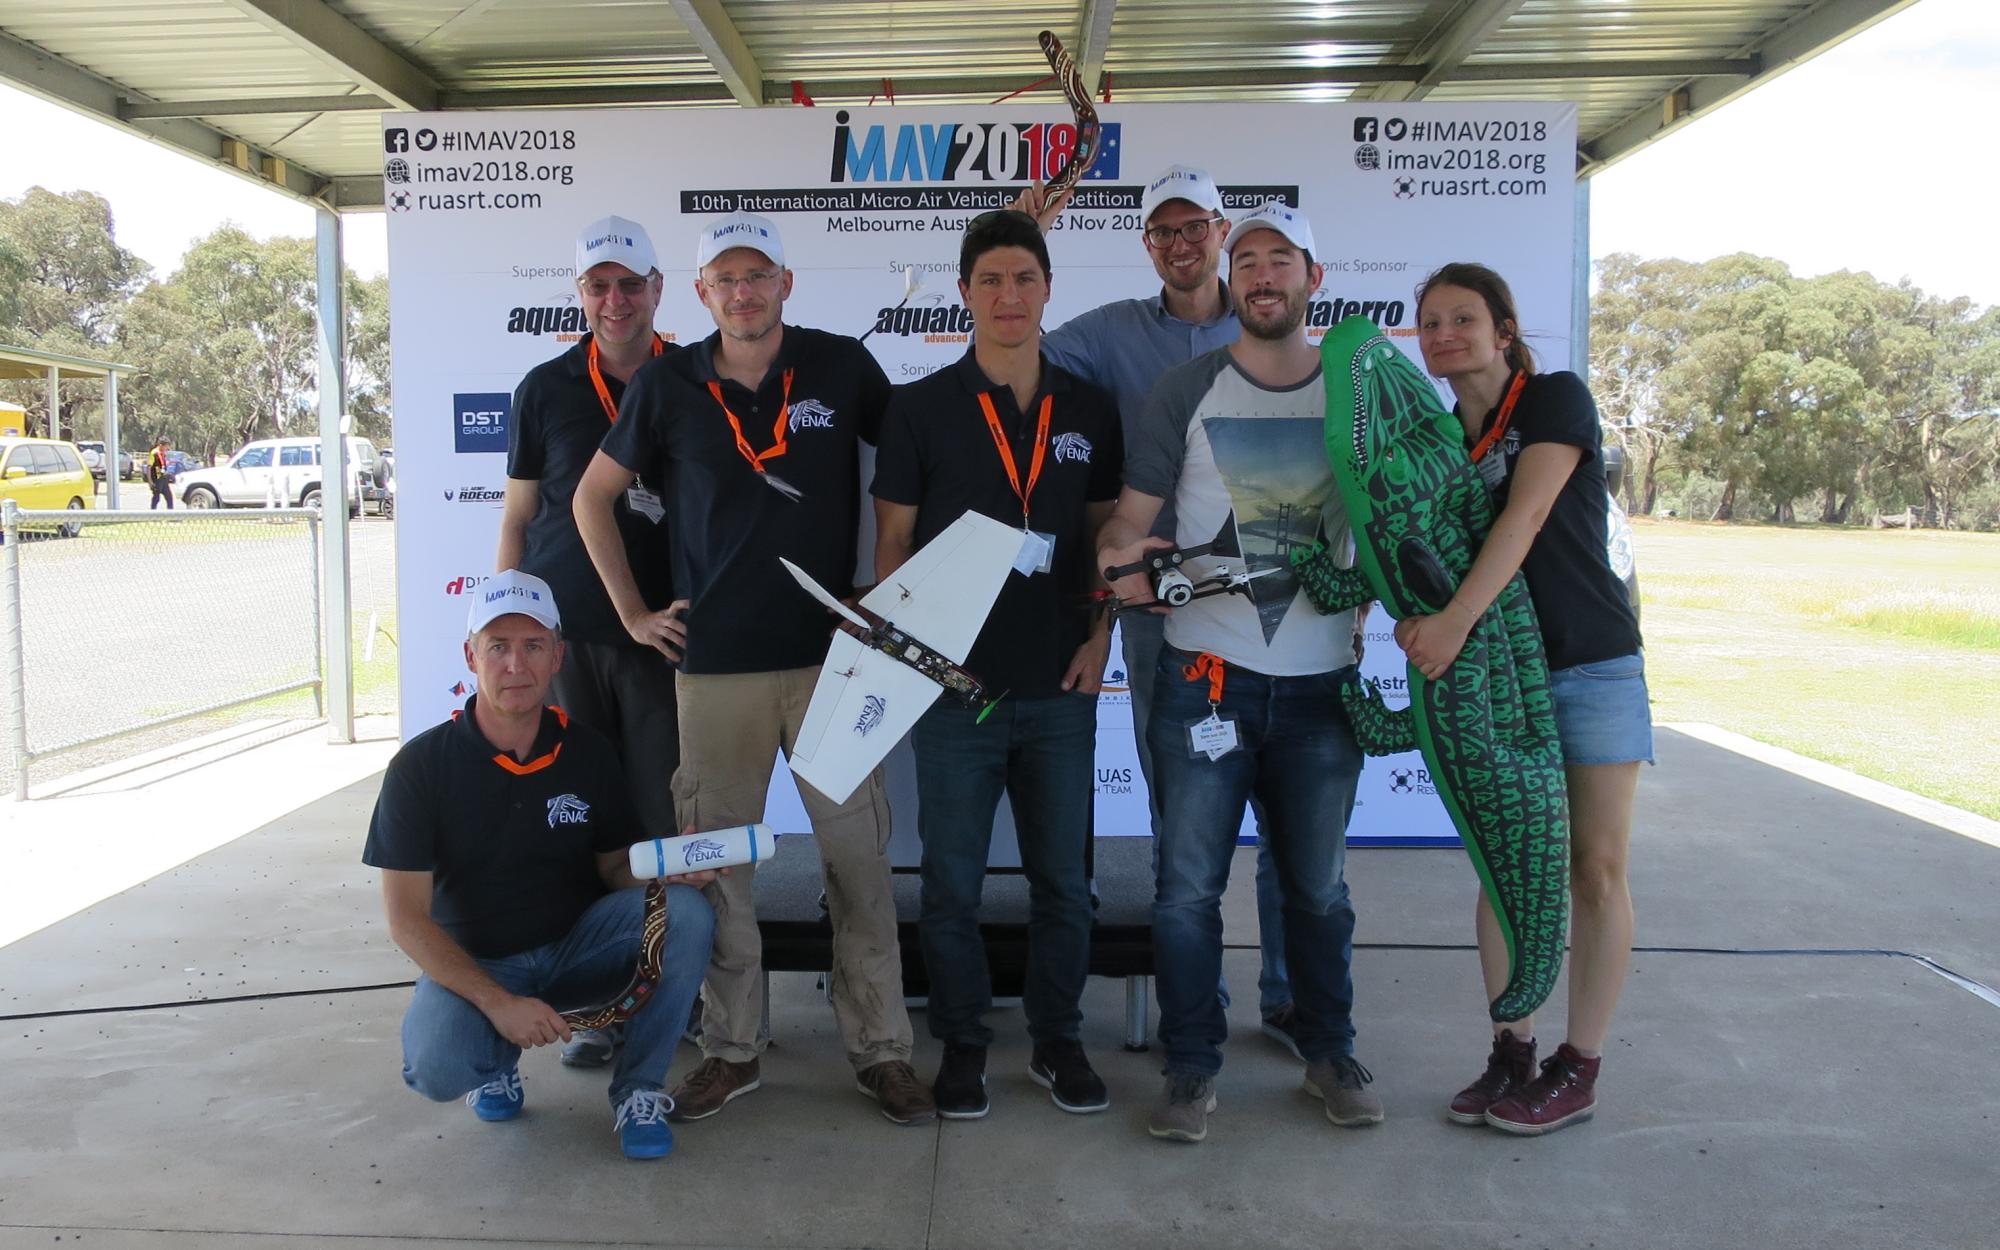
Enac UAV team and TUDelft MAVLAB team took part to the IMAV2018 conference and competition in Australia with great success!

For the first time, the two academic lead developers of the Paparazzi UAV system join efforts to participate to the Outdoor competition and won this event far ahead.

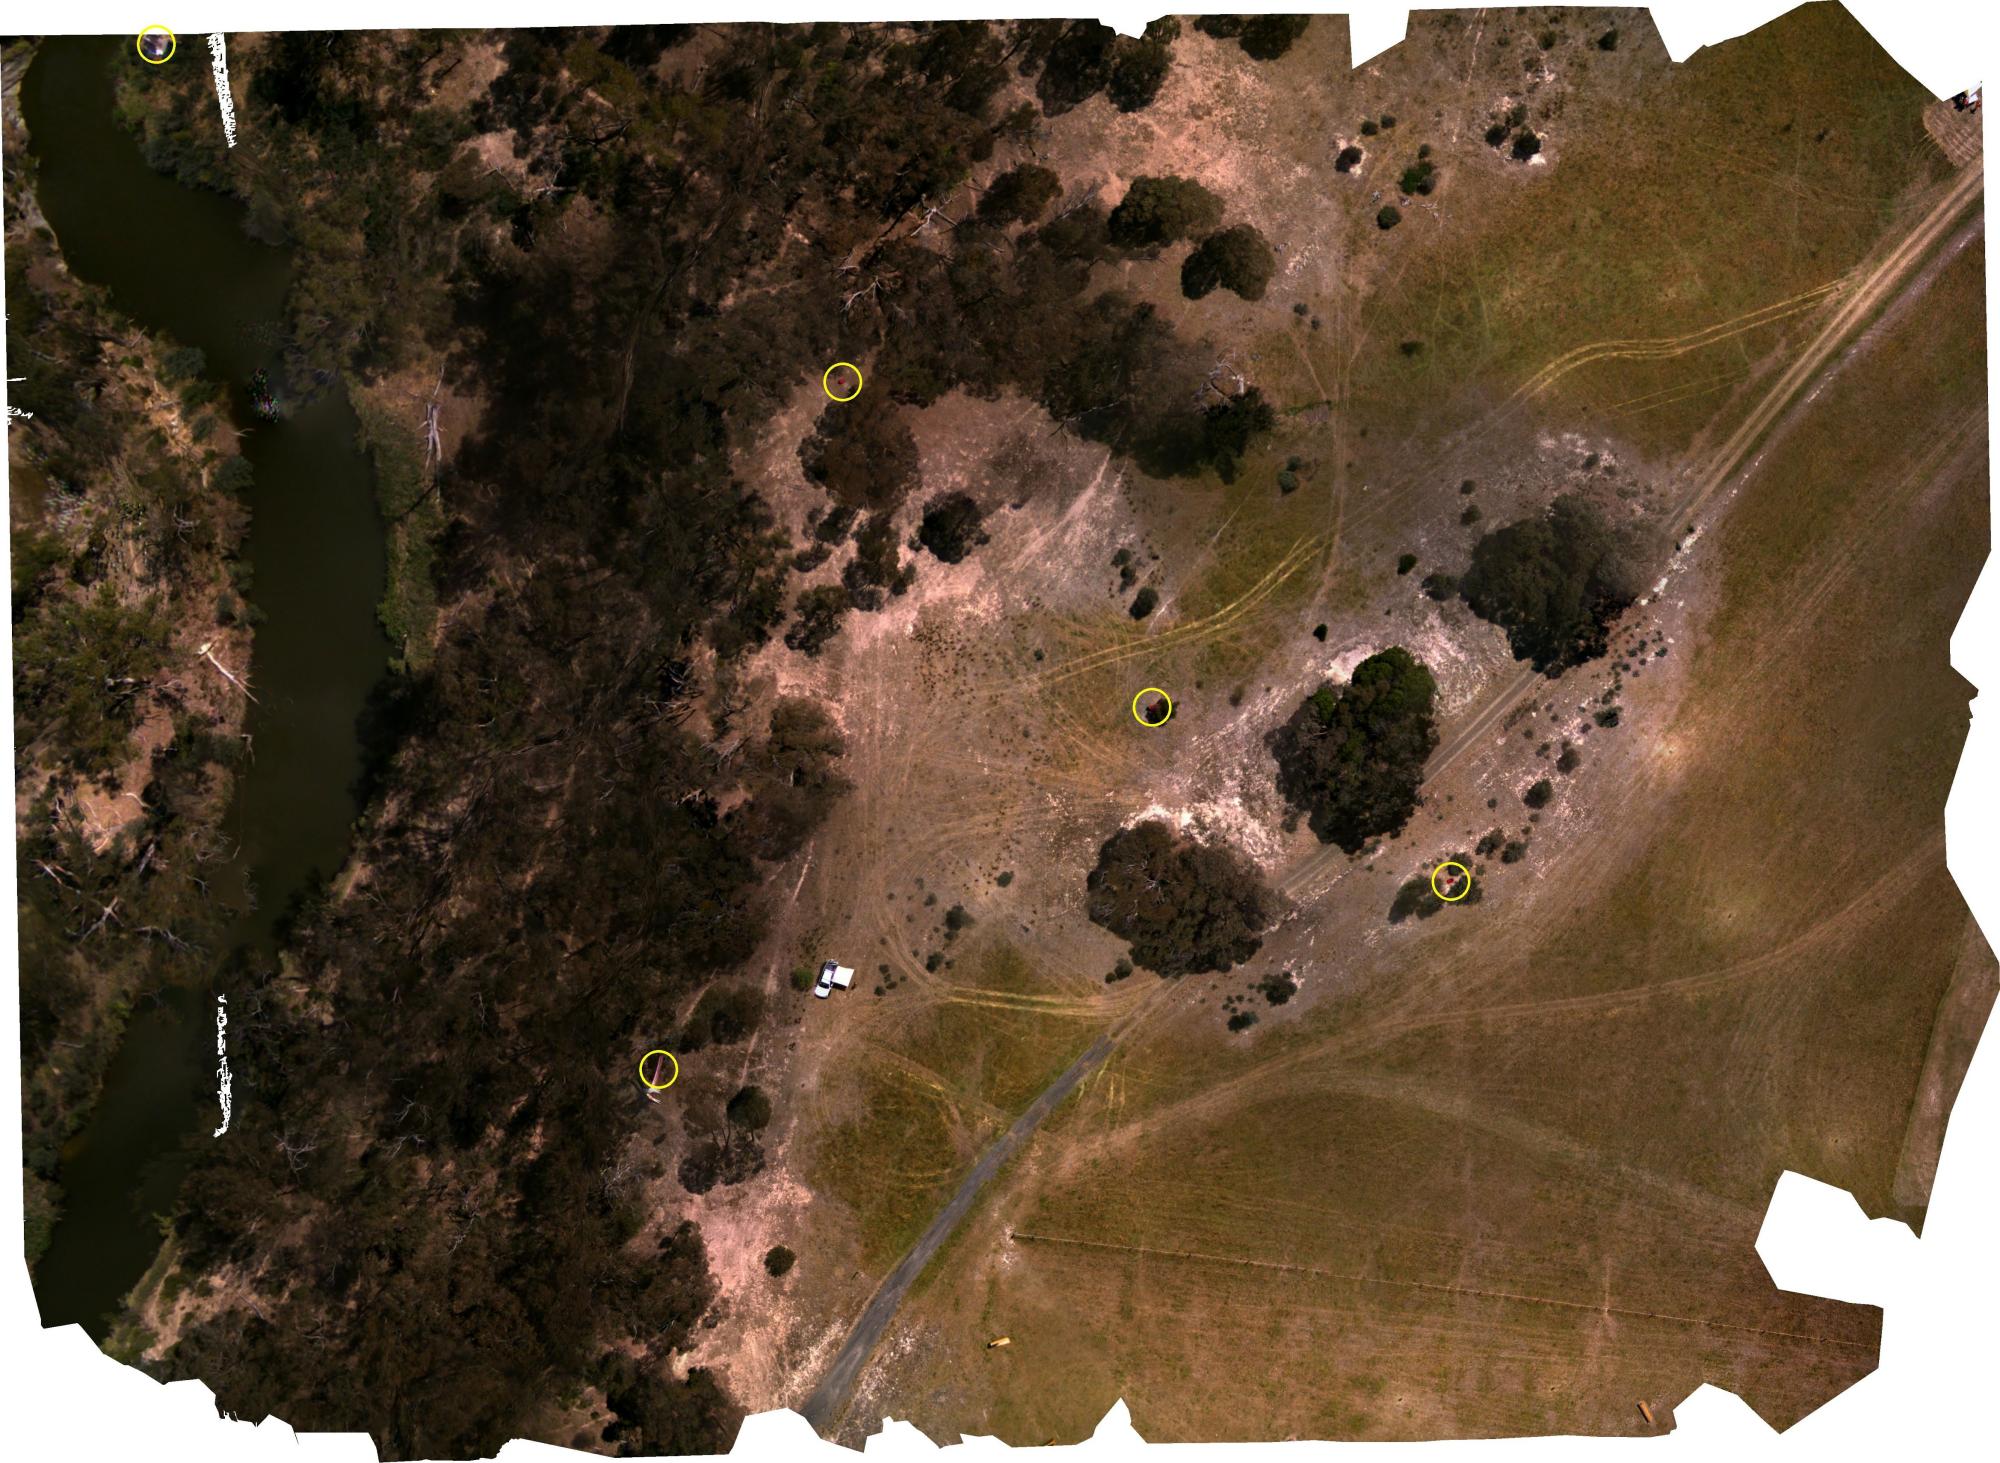
Several tasks have been completed, including a mapping (performed using OpenDroneMap) of the flight area with automatic detection of hazards hidden in the field (with a light fixed wing aircraft) and an autonomous obstacles avoidance navigation near trees (with Bebop2 + SlamDunk from Parrot).

Read article →

21 June 2018 · Gautier Hattenberger

UAV Network Intrusion Detection with Wavelet-based Signature Analysis

This is a first step of a hybrid IDS method based on the analysis of spectral traffic and a robust controller / observer for the estimation of anomalies in UAV networks. This module is currently designed to observe the traffic between the drones and the Paparazzi GCS. It provides a statistic signature of the traffic which can later be used to determine the nature of the traffic. The module is tested in face of a DoS attack and the results are very promising!

Read article →