PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

15 June 2018 · Gautier Hattenberger

Opening ENAC's flying arena

Since the beginning of the year, ENAC (French Civil Aviation University) is equipped with a new facility dedicated to UAVs research and education.

The building includes a flying arena with a size around 10x10x10 meters, several workshops for mechanics, electronic, composite, 3D printing and storage. It also includes a teaching room for automatic control and the student’s robotics club.
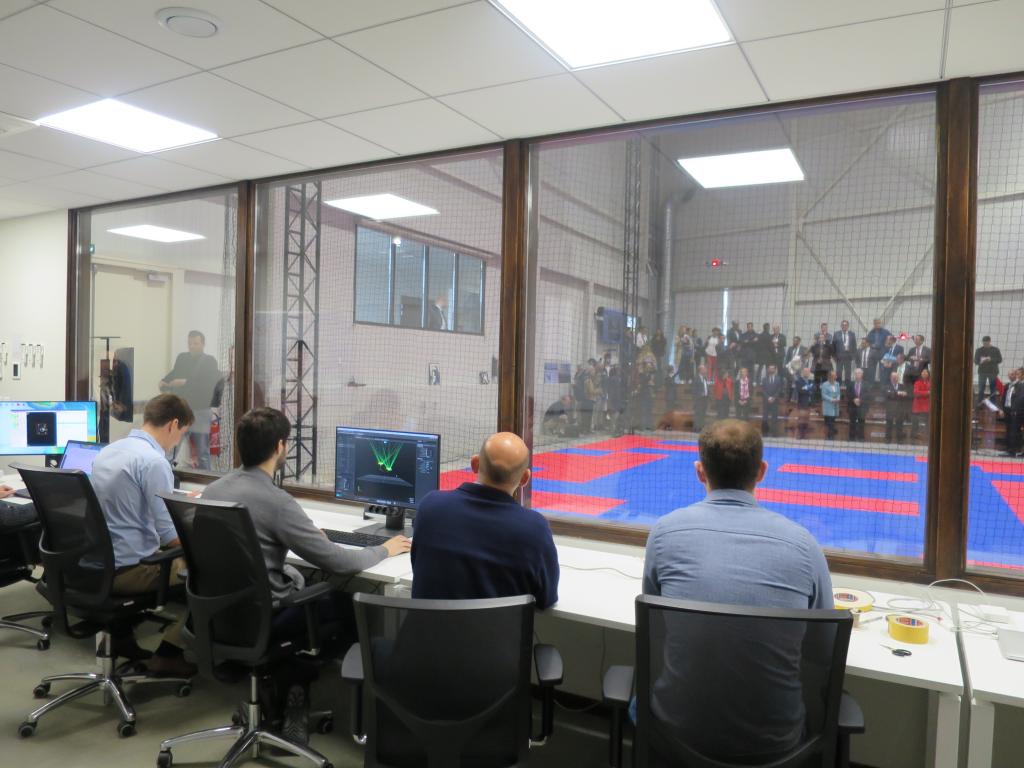
The official opening was the 17th of May in the presence of the French minister of transport. Several demonstrations have been performed, all of them showing the formidable capabilities of Paparazzi: distributed formation flight, hybrid vehicles, on-board image processing, efficient adaptive control and autonomous navigation.
Read article →

26 March 2018 · Michal Podhradsky

Secure Pprzlink released

The Paparazzi team is proud to announce a release of an encrypted version of pprzlink. The new secure Pprzlink uses a strong and fast cipher ChaCha20 with Poly1305 authenticator. For better security and user convenience, a variation of station-to-station key-exchange protocol is implemented, to allow seamless key-exchange between the UAV and the GCS.

Secure Pprzlink is backed by a formally verified cryptographic library HACL*  (yes, the same library that is a part of new Mozilla Firefox).

Read article →

2 December 2017 · Hector Garcia de Marina

Pilot a super rotorcraft!

So far all my results with rotorcraft were in simulation… until now! In this experiment, performed at TU-Delft (thanks Ewoud Smeur!), a team of four rotorcraft behaves as a single unit. The proved stability properties of the whole system allows for applications such as collaborative transportation of objects.

If you want to know the mathematical aspects and why this setup works, then check my thesis.

A wiki entry explaining how you can have the same setup running employing Paparazzi will be available soon!

Read article →

12 August 2017 · Hector Garcia de Marina

Multi-UAV capabilities

Video done at ENAC (Toulouse) showing some capabilities of Paparazzi for controlling multiple fixed-wing aircraft.

We have already a wiki entry explaining how to implement the circular formations.

Read article →

20 March 2017 · Gautier Hattenberger

New Paparazzi autopilot Chimera released

The ENAC UAV lab is proud to release its latest autopilot board.  Named Chimera, it is based on the latest STM32F7 micro-controller and offers a large connectivity.

The design have been made with the ease of use and integration for end-users, especially researchers. With the usual features like IMU and barometer, the Chimera also carries a differential pressure sensor, a SD card slot, a XBee modem slot and a 5V power supply dedicated to external companion processor.

Read article →

12 March 2017 · Hector Garcia de Marina

First flights of the hybrid vehicle Cyfoam with Chimera board

The Cyfoam is a hybrid vehicle developed at ENAC Drone Lab. The aircraft is a foam, with a 3D printed fuselage, version of the composite-made Cyclone.

The vehicle is powered by the new autopilot board Chimera! which executes the control algorithms developed by Ewoud from Delft MAV Lab. We are currently aiming at a total autonomous mode, e.g., auto take off and auto landing.

Read article →

24 February 2017 · Gautier Hattenberger

Flying Parrot's Disco aircraft with Paparazzi

The Disco from Parrot is a fixed-wing aircraft designed for FPV with all the feature already available on their Bebop2, plus some extra things, like airspeed sensor, SBUS input and PWM outputs.

The autopilot itself is all integrated in a box called C.H.U.C.K. and it allows nice and easy flights with the SkyController2 and the Cockpitglasses, connected via Wifi.

Just like the Bebop and ARDrones, it is now possible to fly this drone using Paparazzi. Just connect to the plane, upload your code and you’re ready to go! Here is the video of the maiden flight:

Read article →

21 February 2017 · Hector Garcia de Marina

Circle formations of fixed-wing aircraft

We have recently developed and tested a formation control algorithm for fixed-wing aircraft in Paparazzi at ENAC. The position of an arbitrary number of vehicles can be controlled in a circular path. In fact, we are not restricting ourselves to circles but to any closed orbit, such as ellipses, thanks to the guidance vector field that guides the planes. The algorithm is under more tests, but it should be soon available for the general public. It is quite easy to employ, the user has to declare only the IDs of the planes, the communication topology (neighbors’ relationships) and the desired inter-angles. A detailed explanation will be posted soon in the wiki. In the following video the planes exchange positions every second. Delays, out-of-date positions (GPS delays), packet losses, etc are expected to be (and actually they are) present. It is quite interesting to remark how robust the algorithm is. According to our calculations the impact of such nasty things are not very important (ofc up to a certain point) for the convergence of the algorithm.

Read article →

29 November 2016 · Danika Esden-Tempski

1Bitsy & Black Magic Probe Kickstarter

1Bitsy & Black Magic Probe Kickstarter 1Bitsy & Black Magic Probe Kickstarter

As many of you know a programmer and debugger is a tremendously useful tool for many Paparazzi UAV based autopilots like the Lisa/MX and Lisa/S.

Our friends at 1BitSquared are running a Kickstarter to make a new revision of their Black Magic Probe JTAG SWD debugger and programmer with the addition of the 1Bitsy. 1Bitsy is a development board using the same CPU as Elle0 and Lisa/MX Paparazzi autopilots. It can serve as a good prototyping platform for payload control or for your next autopilot project.

Read article →