PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

11 February 2011 · Eric Parsonage

Paparazzi Mac OSX release
After a very busy holiday period the Paparazzi developer team are pleased to announce the initial release the Mac OSX port of Paparazzi.

Although this release is a couple of weeks later than expected, the team is satisfied that this port will be easy to install and run. This first release still retains the look and feel of its Linux sibling as currently it uses X Windows for rendering. This is due to change, as the graphics library used by Paparazzi (GTK+) is improving its support for the native quartz engine found in Mac OSX. This improved version of GTK+ is due for release at the beginning of March. The team is tracking this and expect a more native look and feel version of Paparazzi to follow this release.

Read article →

13 January 2011 · Piotr Esden-Tempski

Paparazzi at the 27C3

It has been a little quiet here over the Christmas and New Year break. We were busy though. Felix Ruess, Martin Müller and me (Piotr Esden-Tempski) were at the 27th Chaos Communication Congress in Berlin. We presented Paparazzi and received lot’s of interest.

Felix gave an interview about Paparazzi to Projectmovie 2010. It is in German but the makers of the movie are planning to add English subtitles to the movie at some point. :)

Read article →

14 December 2010 · Piotr Esden-Tempski

Lisa/M next generation entry level Paparazzi Autopilot

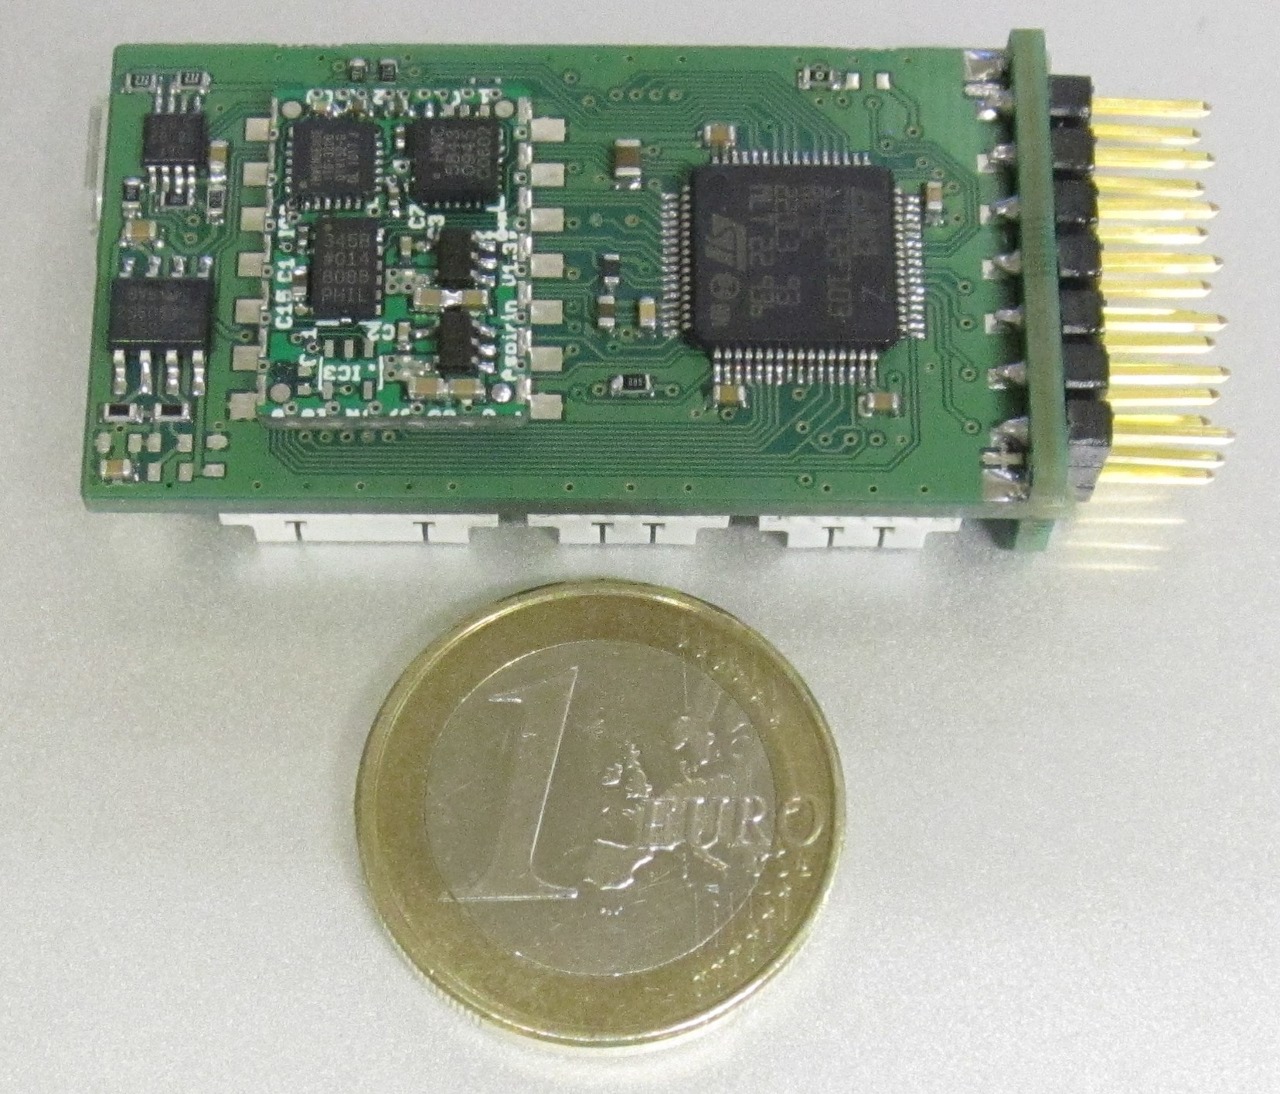
Lisa/M Bottom Lisa/M Bottom

As promised, we want to talk about projects we are currently working on. One of them is Lisa/M.

Lisa/M will be the medium sized Autopilot based on the STM32 Cortex-M3 microcontroller. It is part of the Lisa series of Autopilots. It is very small (50mm x 25mm), about the size of an RC receiver. We want it to be as affordable as possible so that more people can join the autonomous aircraft revolution. The final cost still needs to be determined, as we are not done with the development yet.

Read article →

9 December 2010 · Felix Ruess

Adaptive Control in Paparazzi

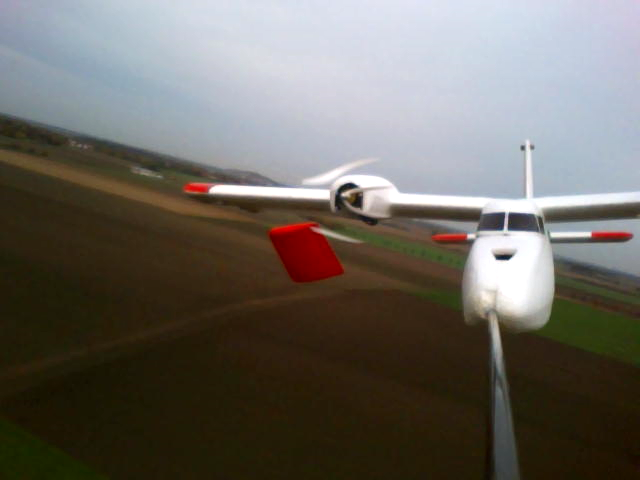
Paparazzi features adaptive control loops that can cope with substantial “changes” of the airframe in flight. May it be a motor dropout, partial loss of control surfaces or dropping a heavy payload. As videos usually say more than words, here are two that demonstrate this.

The first video shows Paparazzi’s adaptive control loops (written by Pascal Brisset and Gautier Hattenberger at ENAC) for fixedwing aircraft keeping a Multiplex Twinstar on track, despite dropping a portion of the right wing and aileron and then switching the right motor off.

Read article →

6 December 2010 · Eric Parsonage

Lisa STM32 Paparazzi Autopilot Overview Part 1.

Many Paparazzi followers will be familiar with the popular TINY and TWOG fixed wing autopilot boards that have allowed so many UAV pilots their first taste of autonomous flight. A few will even have had the pleasure of using the Booz multicopter autopilot board. All three of these designs are based on the Phillips LPC2148 microcontroller, which has proven to be a solid performer in this role. Antoine Drouin, the genius behind the Booz board, has once again outdone himself with a completely new series of autopilot boards based on the STM32 ARM Cortex-M3 microcontroller, which has the umbrella name Lisa. The first available is the Lisa/L and it is this board that will be explored in coming articles.

Read article →

1 December 2010 · Eric Parsonage

Paparazzi support on Mac OSX: Progress report.

This is a brief note to keep everyone updated on progress towards supporting Paparazzi on OSX. Currently Paparazzi is supported only on Linux. With the growing base of Paparazzi developers it has become possible for us to consider supporting multiple operating systems.

Mac OSX was chosen for attention ahead of Windows 7 due to the its similarity to Linux. We hope that the experience gained in supporting this operating system will give an indication of what form a combined build system for all three platforms will take.

Read article →

28 November 2010 · Piotr Esden-Tempski

Welcome to the all new Paparazzi UAV Blog

Hello everyone,

As the Paparazzi community is very active and getting bigger every day, we have decided that it is time to make a blog that reflects the thriving development and keeps everyone up to date. We hope to inform everyone about new features, challenges and plans.

Paparazzi is the only really Open-Source (hardware and software) UAV project in the world with proven capability and stability.

To support that statement we offer the following statistics:

Read article →

26 November 2010 · paparazzi

Adaptive Control

WingdropThere is a video available that shows how Paparazzi’s adaptive control loops keep a Twinstar in the air that drops 30% of its right wing with 50% of the aileron and then also switches the right engine off. Another video shows a Paparazzi quadcopter using adaptive control to stay level after dropping 50% of its total weight.

Read article →

19 November 2010 · Piotr Esden-Tempski

We Moved To GIT

GithubThe paparazzi software repository now has a new happy life on github:

https://github.com/paparazzi/paparazzi

We believe the switch from Subversion to the fast git version control system will make development easier, faster and more fun. It also makes it easier for YOU to contribute. You can easily fork paparazzi on github, commit your bugfixes and new features and send us a pull request.

More info on how to get the paparazzi code from github can be found here.

Read article →

1 August 2010 · Felix Ruess

Code Refactor

OrganizedCodeAfter many years of development, so many new autopilot boards and aircraft types have been added that a sourcecode reorganization was needed. This undertaking is started and will simplify the continuous evolution of the project.

To benefit from these important changes, it only requires you to update your airframe configuration document once. After you have updated, you should not notice the significant reorganization that is going on behind the scenes. This change will benefit your aircrafts flying successfully for the years to come. The required changes are described on Update Your Airframe Configuration.

Read article →