PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Software

9 December 2010 · Felix Ruess

Adaptive Control in Paparazzi

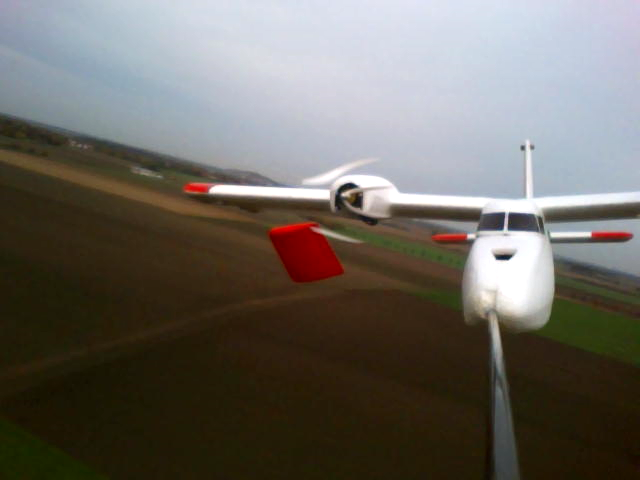
Paparazzi features adaptive control loops that can cope with substantial “changes” of the airframe in flight. May it be a motor dropout, partial loss of control surfaces or dropping a heavy payload. As videos usually say more than words, here are two that demonstrate this.

The first video shows Paparazzi’s adaptive control loops (written by Pascal Brisset and Gautier Hattenberger at ENAC) for fixedwing aircraft keeping a Multiplex Twinstar on track, despite dropping a portion of the right wing and aileron and then switching the right motor off.
Read article →

1 December 2010 · Eric Parsonage

Paparazzi support on Mac OSX: Progress report.

This is a brief note to keep everyone updated on progress towards supporting Paparazzi on OSX. Currently Paparazzi is supported only on Linux. With the growing base of Paparazzi developers it has become possible for us to consider supporting multiple operating systems.

Mac OSX was chosen for attention ahead of Windows 7 due to the its similarity to Linux. We hope that the experience gained in supporting this operating system will give an indication of what form a combined build system for all three platforms will take.

Read article →

26 November 2010 · paparazzi

Adaptive Control

WingdropThere is a video available that shows how Paparazzi’s adaptive control loops keep a Twinstar in the air that drops 30% of its right wing with 50% of the aileron and then also switches the right engine off. Another video shows a Paparazzi quadcopter using adaptive control to stay level after dropping 50% of its total weight.

Read article →

19 November 2010 · Piotr Esden-Tempski

We Moved To GIT

GithubThe paparazzi software repository now has a new happy life on github:

https://github.com/paparazzi/paparazzi

We believe the switch from Subversion to the fast git version control system will make development easier, faster and more fun. It also makes it easier for YOU to contribute. You can easily fork paparazzi on github, commit your bugfixes and new features and send us a pull request.

More info on how to get the paparazzi code from github can be found here.

Read article →

1 August 2010 · Felix Ruess

Code Refactor

OrganizedCodeAfter many years of development, so many new autopilot boards and aircraft types have been added that a sourcecode reorganization was needed. This undertaking is started and will simplify the continuous evolution of the project.

To benefit from these important changes, it only requires you to update your airframe configuration document once. After you have updated, you should not notice the significant reorganization that is going on behind the scenes. This change will benefit your aircrafts flying successfully for the years to come. The required changes are described on Update Your Airframe Configuration.

Read article →

9 February 2009 · paparazzi

PAPARAZZI ON MOBILE

Three ENAC students have released a Graphical control application for Paparazzi on Mobile phones using Java Technologies, connecting via Bluetooth to the ground station. It is divided into 2 programs, one running on the ground station, and the other on the mobile phone. Check the Ipodrom project page for more details.

*Ipodrom is the french acronym for Interface pour contrôler un drone sur un mobile. It is the French UAV control interface on a mobile phone.

Read article →

6 February 2008 · paparazzi

Small and Light GCS

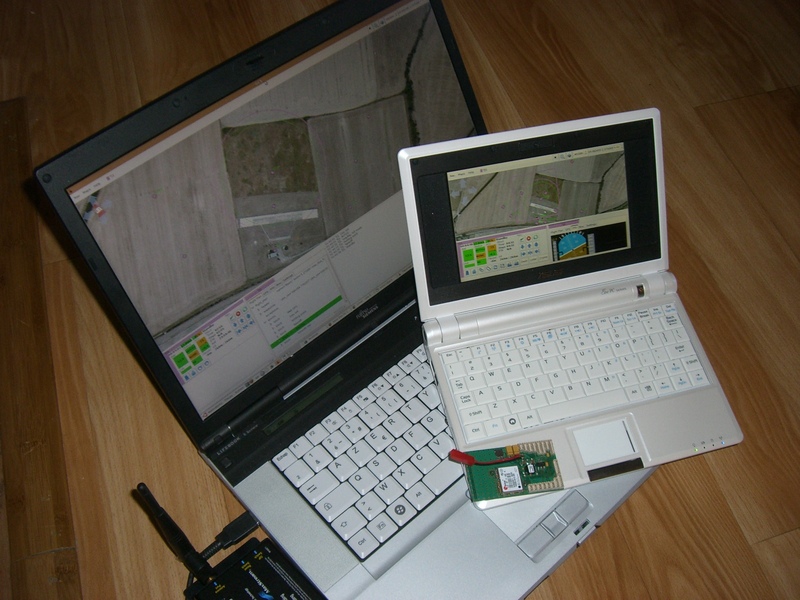
EeePCLooking for a small, light and cheap ground station? Paparazzi runs on the ASUS eeePC out of the box (after installing the Debian Paparazzi packages). Tested on the pre-installed Xandros distribution, on a standard Ubuntu and on the preconfigured eeeXubuntu.

Read article →

5 February 2007 · paparazzi

Antenna Tracker

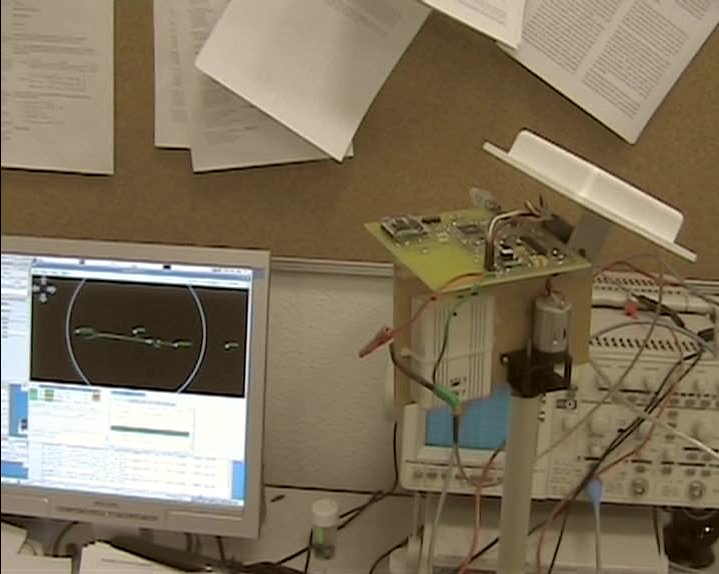
Ant_trackerJeremie Vacher, a student at ENAC, has developed a tracker for antennas. It is functional but still needs a little bit of polishing. Anybody interested?

Read article →

7 December 2006 · paparazzi

7 State Kalman Filter

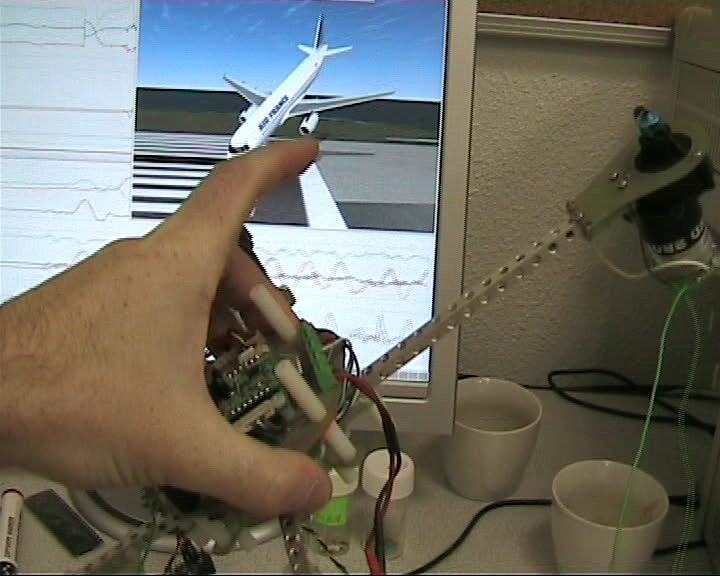
Ahrs2fgAntoine continues to make great progress toward the holy grail of 17 state inertial navigation and releases a video showing the performance of the 7-state Kalman filtered IMU providing the attitude-heading reference system (AHRS) on his quadrotor. Note how much coffee was consumed in preparation for this video. More info on the IMU is available on the sensors page. Also, be sure to admire the schematics and source code!

Read article →