PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Software

10 April 2019 · Gautier Hattenberger

Running Paparazzi on Windows
Since there are many Windows users who like to try paparazzi on this popular OS and Microsoft introduced the possibility of running Ubuntu programs and tools on windows 10, now Paparazzi developer team is pleased to announce the initial release of the Windows10 support of Paparazzi.

The installation process is not so much different from the Linux, but you need some extra steps to install Ubuntu, and some more for using graphical interface and connecting to the aircraft via telemetry. This first release still retains the look and feel of its Linux sibling as currently it uses X Windows for rendering, so you need to install X server in order to have graphical interface.
Read article →

21 June 2018 · Gautier Hattenberger

UAV Network Intrusion Detection with Wavelet-based Signature Analysis

This is a first step of a hybrid IDS method based on the analysis of spectral traffic and a robust controller / observer for the estimation of anomalies in UAV networks. This module is currently designed to observe the traffic between the drones and the Paparazzi GCS. It provides a statistic signature of the traffic which can later be used to determine the nature of the traffic. The module is tested in face of a DoS attack and the results are very promising!

Read article →

26 March 2018 · Michal Podhradsky

Secure Pprzlink released

The Paparazzi team is proud to announce a release of an encrypted version of pprzlink. The new secure Pprzlink uses a strong and fast cipher ChaCha20 with Poly1305 authenticator. For better security and user convenience, a variation of station-to-station key-exchange protocol is implemented, to allow seamless key-exchange between the UAV and the GCS.

Secure Pprzlink is backed by a formally verified cryptographic library HACL*  (yes, the same library that is a part of new Mozilla Firefox).

Read article →

24 February 2017 · Gautier Hattenberger

Flying Parrot's Disco aircraft with Paparazzi

The Disco from Parrot is a fixed-wing aircraft designed for FPV with all the feature already available on their Bebop2, plus some extra things, like airspeed sensor, SBUS input and PWM outputs.

The autopilot itself is all integrated in a box called C.H.U.C.K. and it allows nice and easy flights with the SkyController2 and the Cockpitglasses, connected via Wifi.

Just like the Bebop and ARDrones, it is now possible to fly this drone using Paparazzi. Just connect to the plane, upload your code and you’re ready to go! Here is the video of the maiden flight:

Read article →

20 September 2016 · Rich Burton

DELFTACOPTER - Hybrid Drone on a Mission

DELFTACOPTER, an electric, long range, transitioning autonomous delta-wing helicopter, is on a mission. What mission? In this case, it’s the 2016 Outback Medical Express challenge and the MAVLab Team at TUDelft has high hopes for their hybrid aircraft.

This year’s Outback Medical Express mission requires a UAV to pick up and bring back a blood sample of an ill-fated person called “Outback Joe” located at an inaccessible roughly known location 30 kilometer away remote location with unknown terrain.

Read article →

1 August 2016 · Gautier Hattenberger

Drones vs. Retro-gaming: fly with a Game Boy Classic

Some time ago, I found my old Game Boy at my parents’ house. So the first thing that came to my mind was: can I fly a drone with this ? (and also where is my Mario Bros cartridge).

So I spend some time searching the web to see if I could find some idea to solve my problem. And if it seems that piloting unmanned aircraft with a Game Boy is not so common, you can find everything you need to program it!

Read article →

11 April 2016 · Rich Burton

Flying Robot Commander + PPRZLINK = Improved MultiMAV Management

For those of us that use Paparazzi to fly multiple MAVs, the current GCS does a great job of managing and presenting just the right amount of information for safe flight. That being said, there’s always room for new tools. It’s my pleasure to introduce the Flying Robot Commander, a PPRZLINK enabled web application for managing multiple MAVs.

The Flying Robot Commander(FRC) is a Flask/python based RESTful web application that integrates with Paparazzi UAV via PPRZLINK. That’s right, you can now write python code to access/extend Paparazzi UAV capabilities (NOTE: one of the main complaints about the current Paparazzi GCS is that it’s written in ocaml). In addition to python, PPRZLINK also provides C and ocaml libraries for those that need them.

Read article →

1 March 2016 · Bart Remes

Paparazzi UAV on Pixhawk teaser

Hi all Open-Source enthusiasts,

Today we are happy to announce we’ll be adding an extra autopilot board to there long list of supported autopilots.

The Pixhawk autopilot board will be integrated in our next software release! The video shows the first flight with Paparazzi UAV on a Pixhawk, more videos will follow.

Why choose Paparazzi UAV?

If you are looking for an advanced, modular open-source autopilot which has features others can only dream of, you choose Paparazzi UAV.

Read article →

24 December 2015 · Piotr Esden-Tempski

Paparazzi V5.8 release

Penguin_logoMerry Christmas dear Paparazzians!

We are happy to announce the release of Paparazzi; v5.8, providing you with lots of new features and improvements!

Just to pick out a few:

  • ADS-B support
  • improved use of optic flow for velocity estimation
  • improved mavlink support
  • possibility to reduce RAM and Flash usage by compressing the sine table
  • this allowed us to add basic support for naze32, CC3D and CJMCU boards
  • flip mode for multicopters
  • INDI guidance loop
  • lots of improvements/additions for computer vision modules
  • high speed logging to SD Card via SPI
  • improve support for Bebop and add Bebop2
  • guided mode for rotorcrafts

For a detailed overview refer to the CHANGELOG. :)

Read article →

4 December 2015 · Gautier Hattenberger

Multi-UAV flights for simultaneous meteorological measurements

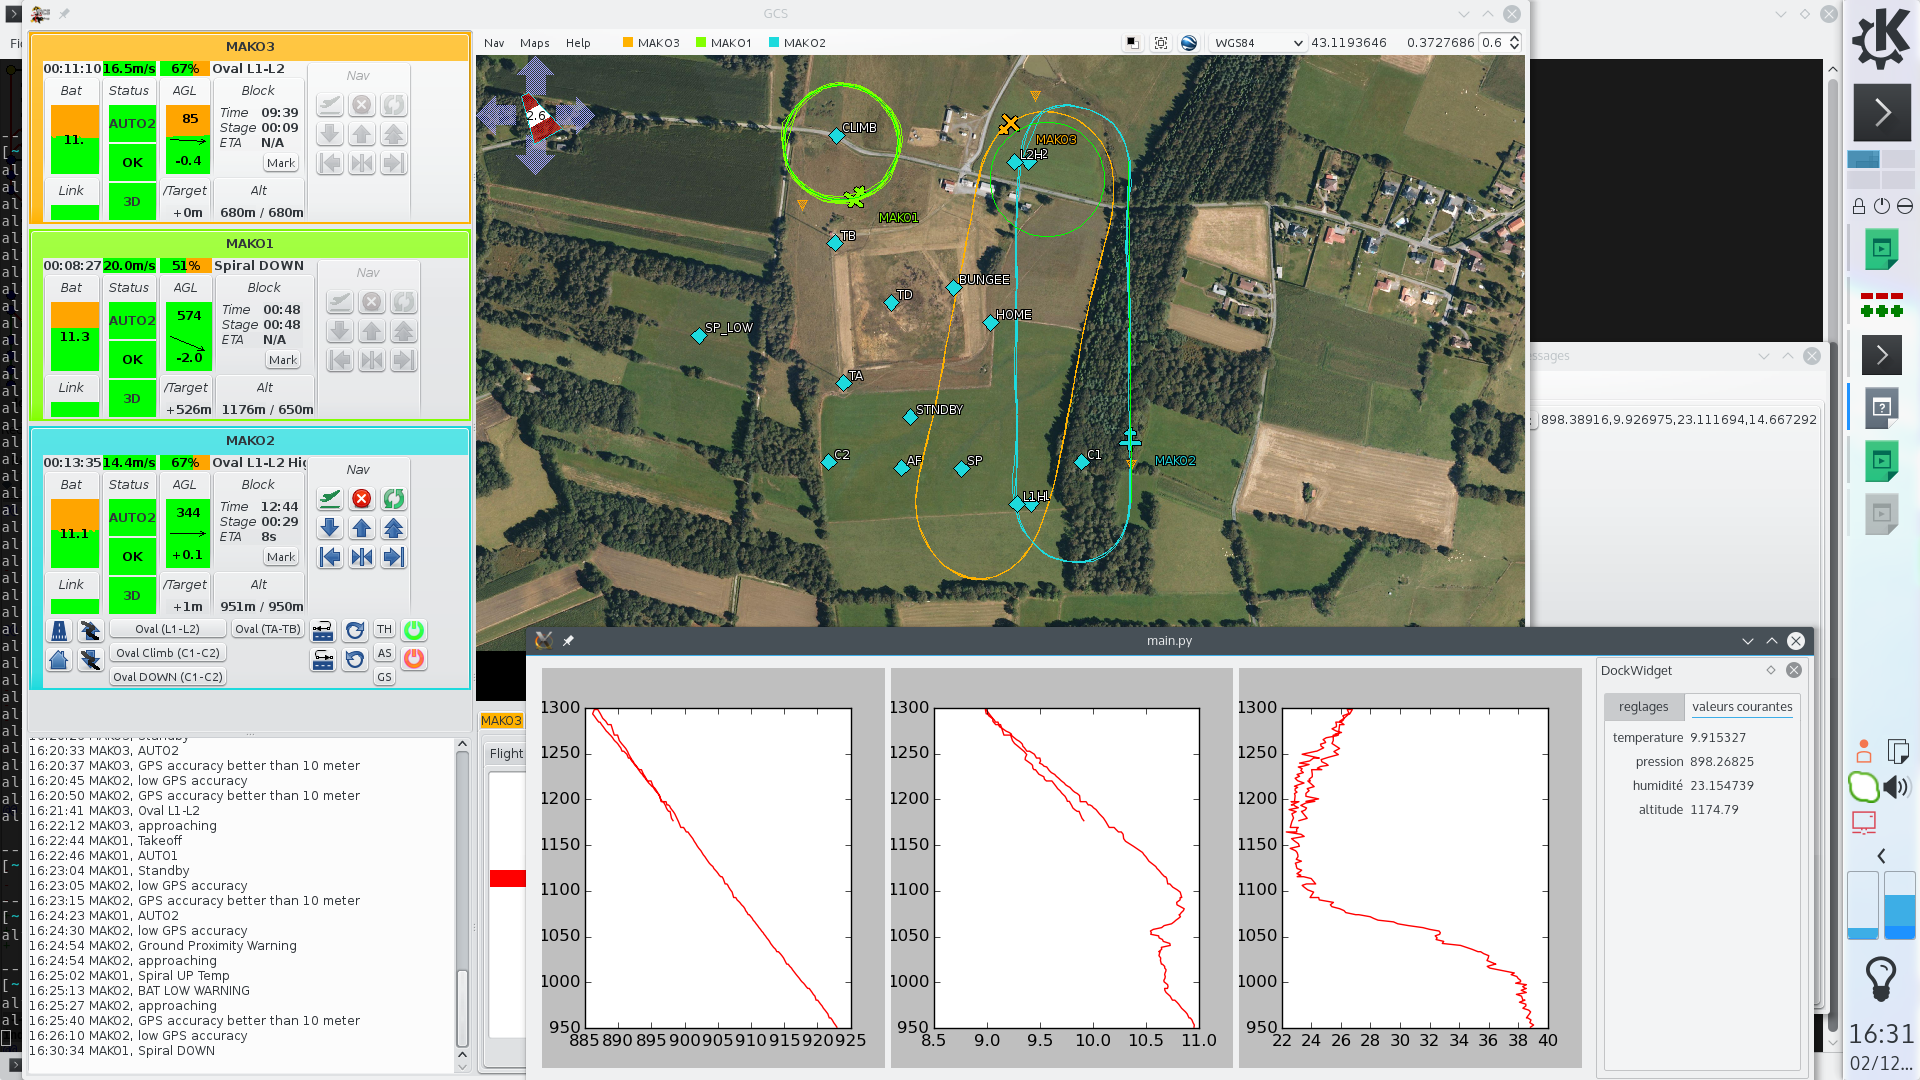
ENAC UAV Lab team and Meteo-France (CNRS-GAME and ENM) teams have spent several days at the Atmospheric Research Center of Lannemezan (in the south of France) in order to perform experiments for simultaneous meteorological measurements through multi-UAV flight.

This was part of a research project called VOLTIGE aimed at studying the formation of cloud and fog events. One of the planes is measuring the turbulence near the ground, a second plane is flying above the cloud or the fog with a radiation sensor and the last one is making a vertical profile of temperature, pressure and humidity up to 1500 meters AGL.GCS screenshot multi-uav

Read article →