PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Release

12 December 2012 · Felix Ruess

Paparazzi V4.2.0 Release
Penguin_logoJust before the end of the world, discover Paparazzi v4.2.0 stable version.

Based on the last stable branch v4.0, this new release offers several improvements, especially the total energy control developed by TUDelft. See the changelog for an overview of new features and bugfixes.

If you are already using paparazzi with Git, you can switch to this new branch with

git remote update && git checkout v4.2.

For new user, it will be the default branch when getting the source code from Github. You can also download a tarball or Zip file of the v4.2.0_stable source code.
Read article →

26 July 2012 · Felix Ruess

Paparazzi V4.0 Release

Penguin_logoThe Paparazzi Development Team is pleased to announce the release of the Paparazzi v4.0 stable version.

After several months of testing and debugging, the release preparation branch v3.9 has been released as v4.0. See the changelog for an overview of new features and bugfixes.

If you are already using paparazzi with Git, you can switch to this new branch with

git remote update && git checkout v4.0.

For new user, it will be the default branch when getting the source code from Github. You can also download a tarball or Zip file of the v4.0_stable source code.

Read article →

9 May 2012 · Felix Ruess

Stable Paparazzi Releases

Git-Logo-2ColorIn order to improve the development workflow and provide stable releases we have changed our git branching model.

The branch “master” is now our development branch.

  • The “dev” branch was renamed to the release preparation branch “v3.9”. Switch to this branch if you want stable code.
  • “master” was reset to the previous “locm3” branch, where development will happen now with libopencm3 for the STM32 architecture.

Please see the RepositoryStructure page for more details.

Read article →

5 October 2011 · paparazzi

UMARIM V1.0

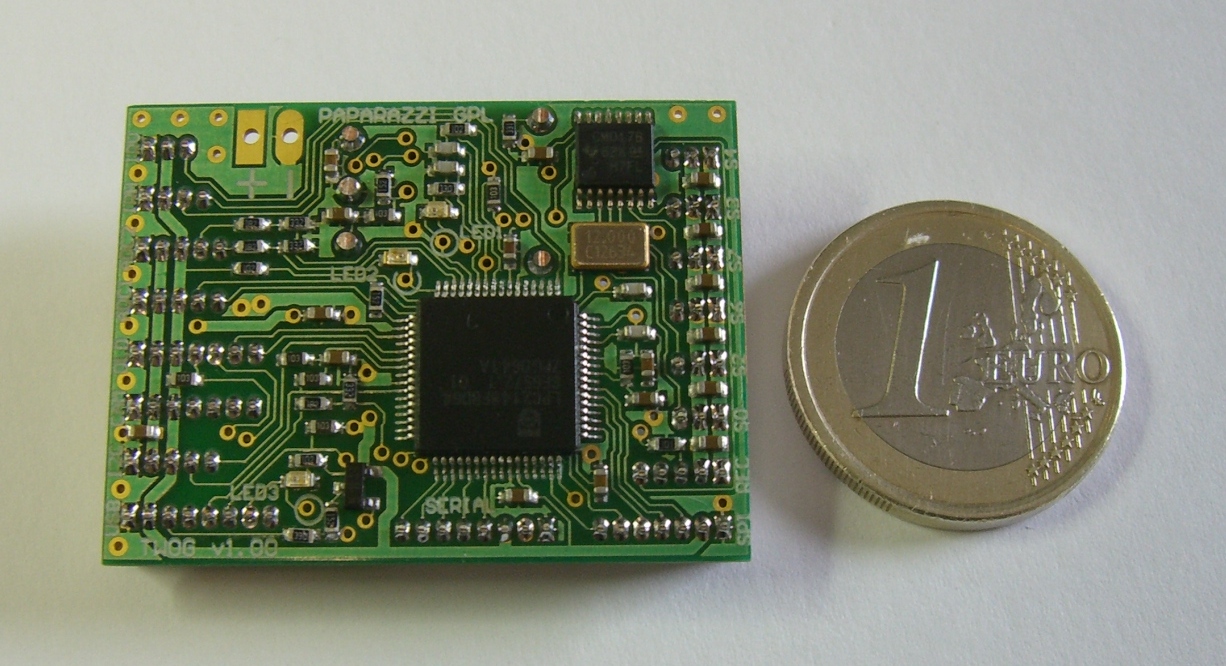
Twog_v1-00_top_side_3ENAC Team Umarim V1.0 autopilot is now released: LPC based, on-board IMU & barometer, narrow fuselage form factor (56x25mm) and lightweight (9gr) are its main features. Add your favorite GPS receiver and it will fit in your thin light UAV prototype. But it will also do the job for a bigger UAV as well. More info here…

Read article →

11 February 2011 · Eric Parsonage

Paparazzi Mac OSX release

After a very busy holiday period the Paparazzi developer team are pleased to announce the initial release the Mac OSX port of Paparazzi.

Although this release is a couple of weeks later than expected, the team is satisfied that this port will be easy to install and run. This first release still retains the look and feel of its Linux sibling as currently it uses X Windows for rendering. This is due to change, as the graphics library used by Paparazzi (GTK+) is improving its support for the native quartz engine found in Mac OSX. This improved version of GTK+ is due for release at the beginning of March. The team is tracking this and expect a more native look and feel version of Paparazzi to follow this release.

Read article →

15 March 2008 · paparazzi

Tiny 2.11 Available

Tiny_v2-1_3D_topA number of vendors are now offering assembled and not-assembled autopilots, sensors and accessories. The software is written, the hardware is built, what are you waiting for? Getting started has never been easier! More details on the Get Hardware page.

Read article →