Paparazzi on the Parrot Bebop
The TU Delft MAVlab team made a great video showing off the ease of use of the Paparazzi UAV system on the new Parrot Bebop platform.
Research and development of open-source UAV systems since 2003
The TU Delft MAVlab team made a great video showing off the ease of use of the Paparazzi UAV system on the new Parrot Bebop platform.
Great BBC interview with Bart Remes, head of the Mavlab at TU Delft. Bart shows off the Lisa/S Nano Quadcopter and comments on the usefulness and safety of sub-miniature UAV.
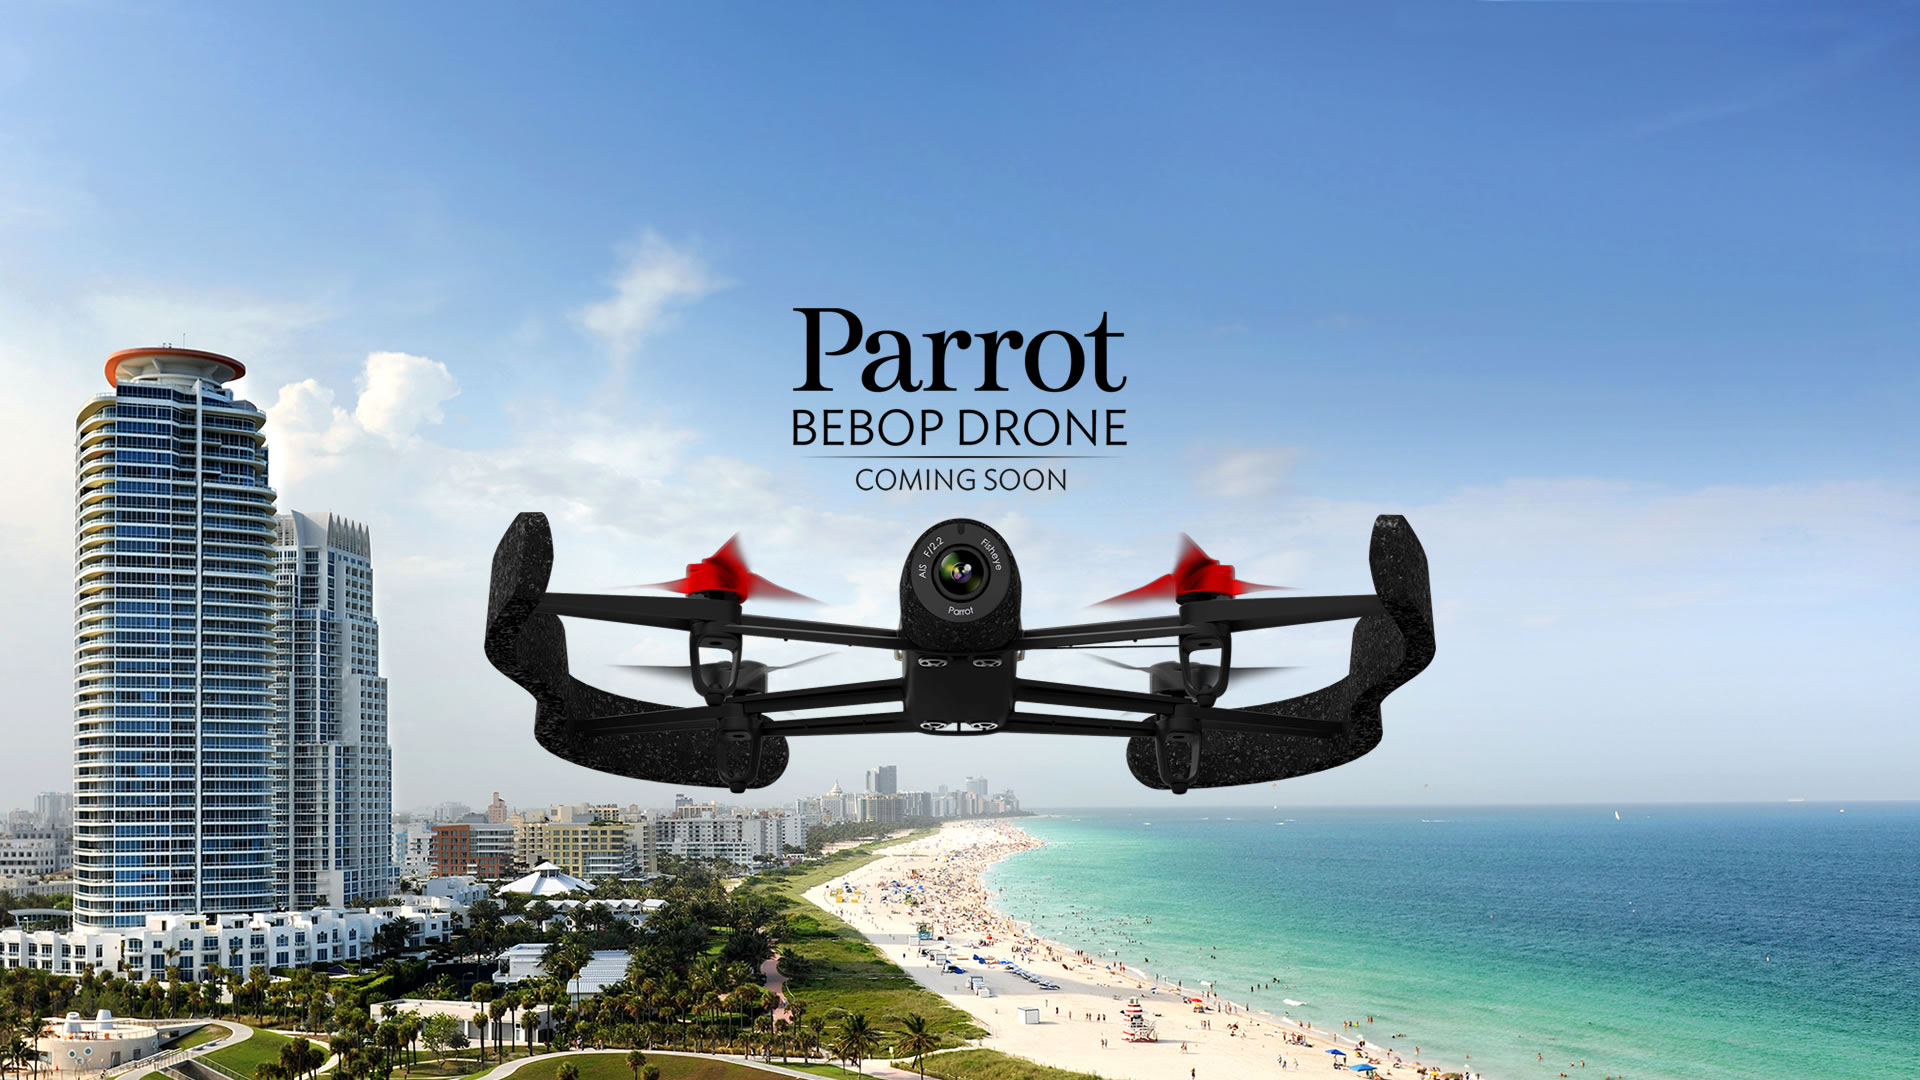 As you know paparazzi is a very modular platform. To show the world how modular we are, we worked hard on implementing paparazzi into the Parrot Bebop. At the Micro Aerial Vehicle Laboratory (MAVLab) of Delft University of Technology faculty Aerospace engineering (TU Delft) we received a pre-production model of the Bebop. We did our best to have paparazzi integrated before the launch of the Bebop. If you want to follow the progress check our (youtube channel).
The TU Delft MAVlab team has created an engaging tutorial showing the step by step assembly of the new Lisa/S Nano Quadcopter. With these instructions you will be flying in no time! :)
The TU Delft MAVlab team have made a series of tutorials for the Parrot ARDrone. Showing off the ease of use of the Paparazzi UAV system on the platform.
Getting started
Autonomous Flight
IMAV 2014 was a great experience this year. If you don’t know what it is, its a micro air vehicle competition and conference that was held in Delft, Netherlands.
During the three days of the conference, there were many very interesting talks and presentations as well as an incredible showcase of research talent during the competition. Here is a playlist of the talks, they can be found on the TU Delft MAVlab YouTube channel.
Paparazzi  UAV and 1BitSquared will be attending this years DefCon 22 in Las Vegas, Nevada. It takes place from August 7th through 10th, 2014.
We will be at the Hak5 vendor booth, with Lisa/S autopilots, Black Magic Probe, Nano Quad kits and more. Please come by and say hi!
Piotr Esden-Tempski of 1Bit Squared is working together with Darren Kitchen of HAK5 on a series about Open Source Drones, explaining what Drones/UAV/UAS are, how to build, operate, program, and calibrate them. This series highlights Paparazzi’s hardware and software systems and their strengths.
Here is the first episode in the series titled, Drones 101- Hak5 episode 1611. In this episode Piotr and Darren build an Open-Source autonomous aerial system.
Drones 101- Hak5 episode 1612. In episode 2, Piotr and Darren discuss drone basics. How they are put together, what are their components, how they operate and what makes them special.
 The 30C3 – 30th Chaos Communication Congress was held in the Congress Center in Hamburg, Germany on December 27th-30th, 2013. We were present there as part of the Paparazzi UAV Assembly.
Piotr Esden-Tempski of 1BitSquared made a presentation on Paparazzi’s History in the main events hall during the congress.
httpvh://www.youtube.com/watch?v=IePG2fzKvF0
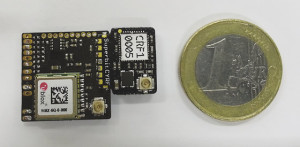 The Paparazzi UAV Lisa/S autopilot has been featured in MICROmanufacturing magazine. We were excited to discover that the Guinness Book listing for the smallest autopilot system is for the Kestrel autopilot. Which is 14 grams heavier and several centimeters bigger than the Lisa/S!