Chaos Communication Camp 2015
 From 13. - 17. August 2015 we are attending the Chaos Communication Camp in Ziegeleipark Mildenberg, Zehdenick, Germany. If you are attending too make sure to visit our Village and say hi.
Research and development of open-source UAV systems since 2003
From 13. - 17. August 2015 we are attending the Chaos Communication Camp in Ziegeleipark Mildenberg, Zehdenick, Germany. If you are attending too make sure to visit our Village and say hi.
A few days ago ENAC UAV Lab uploaded their Paparazzi UAV video collection from 2004-2010. If you are interested in some Open-Source UAV history you should take a look at them.
https://www.youtube.com/playlist?list=PLD885PC3Hy2DhiL_OEH3qMrcOFEh2McGN
It is exciting to see how many things Paparazzi UAV could already do 5 to 10 years ago, as well as how far things have improved and evolved since then.
One of the highlights is a multi UAV flight at IMAV2006. This is 9 years ago. It is great to see how relaxed the safety pilots are. :)
 We will be showing off some of our hardware at the O’Reilly Open Source Convention 2015 (OSCON). The event is happening on July 20–24, 2015 in Portland, Oregon USA.
Piotr Esden-Tempski from 1BitSquared together with Rich Burton from Hooperfly will be bringing some of their Paparazzi UAV based creations to show off. If you are attending OSCON find us in the exhibition hall for the hardware showcase and say “Hi”. We would love to meet some fellow Paparazzians.
Students at the TU Delft MavLab compete with ARDrones running Paparazzi to fly seamlessly around obstacles without injuring the aircraft. The object to autonomously avoid all obstacles. This is a fantastic demonstration of the flexibility of the Paparazzi system and its ability to fly accurately around waypoints.
IMAV 2014 was a great experience this year. If you don’t know what it is, its a micro air vehicle competition and conference that was held in Delft, Netherlands.
During the three days of the conference, there were many very interesting talks and presentations as well as an incredible showcase of research talent during the competition. Here is a playlist of the talks, they can be found on the TU Delft MAVlab YouTube channel.
 The Micro Aerial Vehicle Laboratory (MAVLab) of Delft University of Technology (TU Delft) is proud the present the 2014 International Micro Air Vehicle Conference (IMAV 2014), now offering the possibility of attending the conference by live stream free-of-cost. The live stream will support most platforms showing innovative keynotes of pioneers in the industry as well as the current state-of-the-art presented by many researchers working on MAV’s. The schedule is published on the website of the conference.
Tuesday, August 12th, 2014
Paparazzi  UAV and 1BitSquared will be attending this years DefCon 22 in Las Vegas, Nevada. It takes place from August 7th through 10th, 2014.
We will be at the Hak5 vendor booth, with Lisa/S autopilots, Black Magic Probe, Nano Quad kits and more. Please come by and say hi!
 The 30C3 – 30th Chaos Communication Congress was held in the Congress Center in Hamburg, Germany on December 27th-30th, 2013. We were present there as part of the Paparazzi UAV Assembly.
Piotr Esden-Tempski of 1BitSquared made a presentation on Paparazzi’s History in the main events hall during the congress.
httpvh://www.youtube.com/watch?v=IePG2fzKvF0
Bart Remes of TU-Delft MAVLab speaking at TEDxAmsterdam. The topic, ‘A drone inside everybody’s pocket’. Bart demonstrates the ease of flight with a Paparazzi Lisa/S autopilot powered nano quadrocopter.
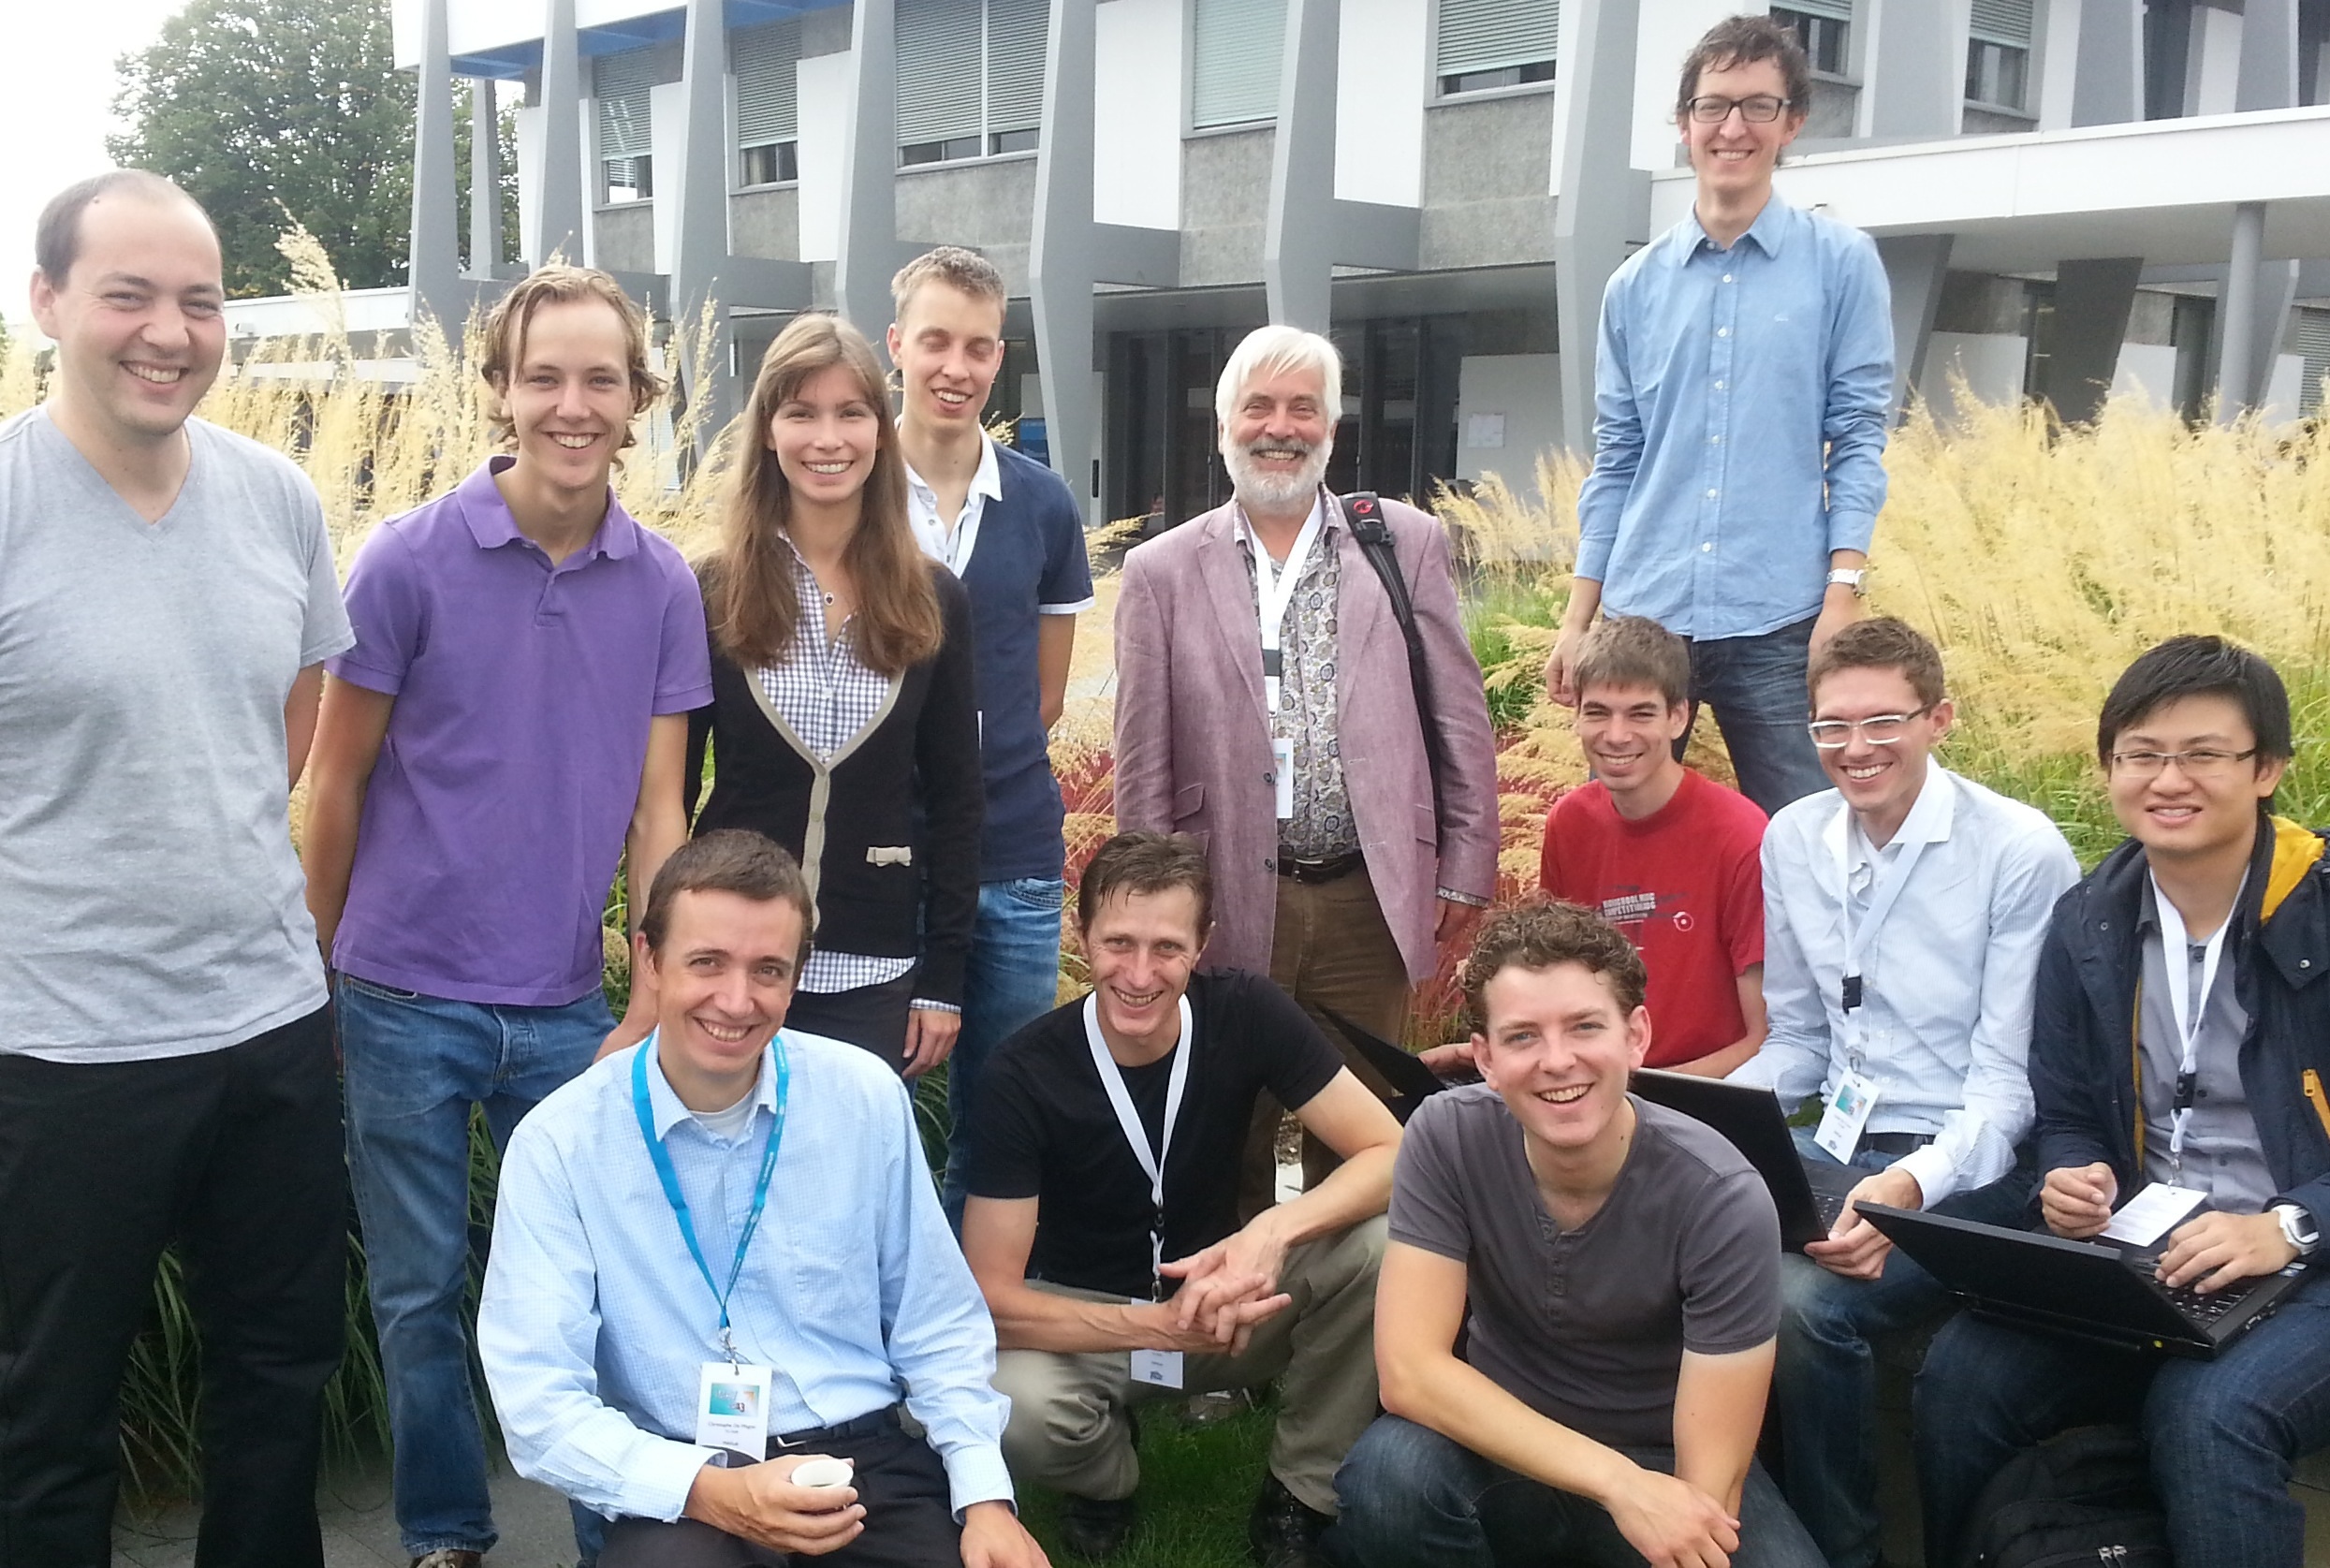 The MavLab team of TU Delft consisted of 12 people coming from aerospace, computer science, embedded programming and artificial intelligence. Thanks to the enormous team efforts in the last months, the team has won prizes in all the categories in which it participated at IMAV 2013 in Toulouse, France:
Outdoor: 1st place
With an autonomous swarm of 12 MAVs operated by a single operator. The MAVs only had to be plugged in and started with their own flight plan, while the operator could monitor their mission status and intervene where necessary. Our participation featured four main innovations: (1) a single operator for 12 MAVs, 3 hybrid UAVs, 7 Parrot AR drones and 2 mini-quadrotors, (2) onboard vision processing on the AR drone with Paparazzi, (3) hybrid UAVs able to fly under any attitude, and (4) the world’s smallest open source autopilot, Lisa/S (2 grams). The wind conditions were terrible on the outdoor competition day, with 6 Bft, and most teams had their MAVs blown away. Everybody was impressed with how the hybrid UAVs were able to cope nicely with these conditions and were still able to perform a precision landing.