PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Events

22 February 2023 · Gautier Hattenberger

ENAC Team wins at IMAV2022

The International Conference and Competition on MAV was organized by TUDelft mid-September 2022. The ENAC took part to the outdoor competition, a package delivery challenge, with several multi-rotors and a hybrid tail-sitter, all powered by Paparazzi.

They won the competition with a quite large amount of points. Nevertheless, all teams performed well with some innovative platforms.

Several papers have been presented to the conference by the ENAC team and the other participants. The proceedings are freely available on the conference website.
Read article →

28 November 2018 · Gautier Hattenberger

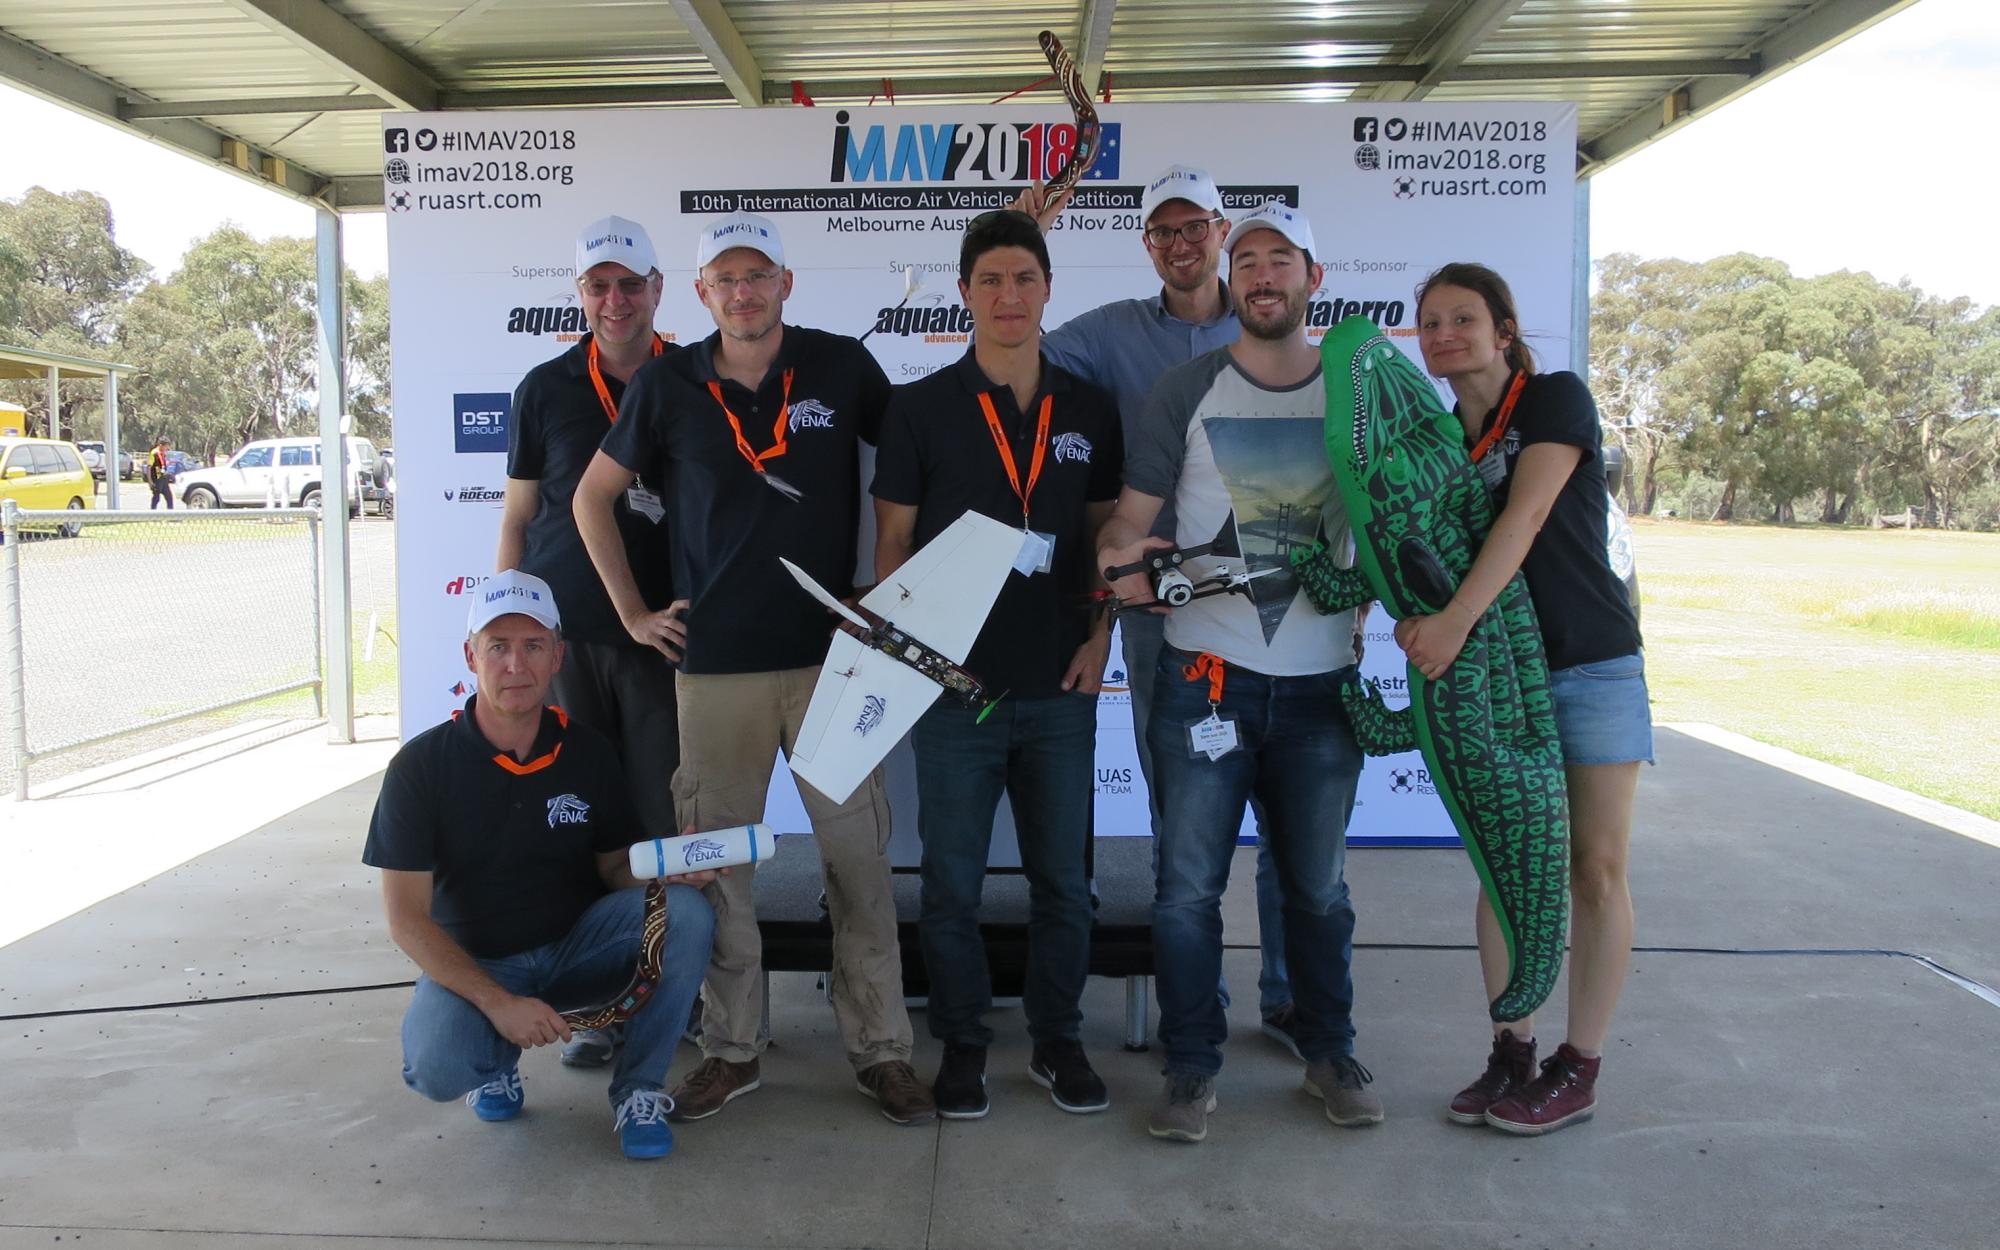
Paparazzi wins at IMAV2018

Enac UAV team and TUDelft MAVLAB team took part to the IMAV2018 conference and competition in Australia with great success!

For the first time, the two academic lead developers of the Paparazzi UAV system join efforts to participate to the Outdoor competition and won this event far ahead.

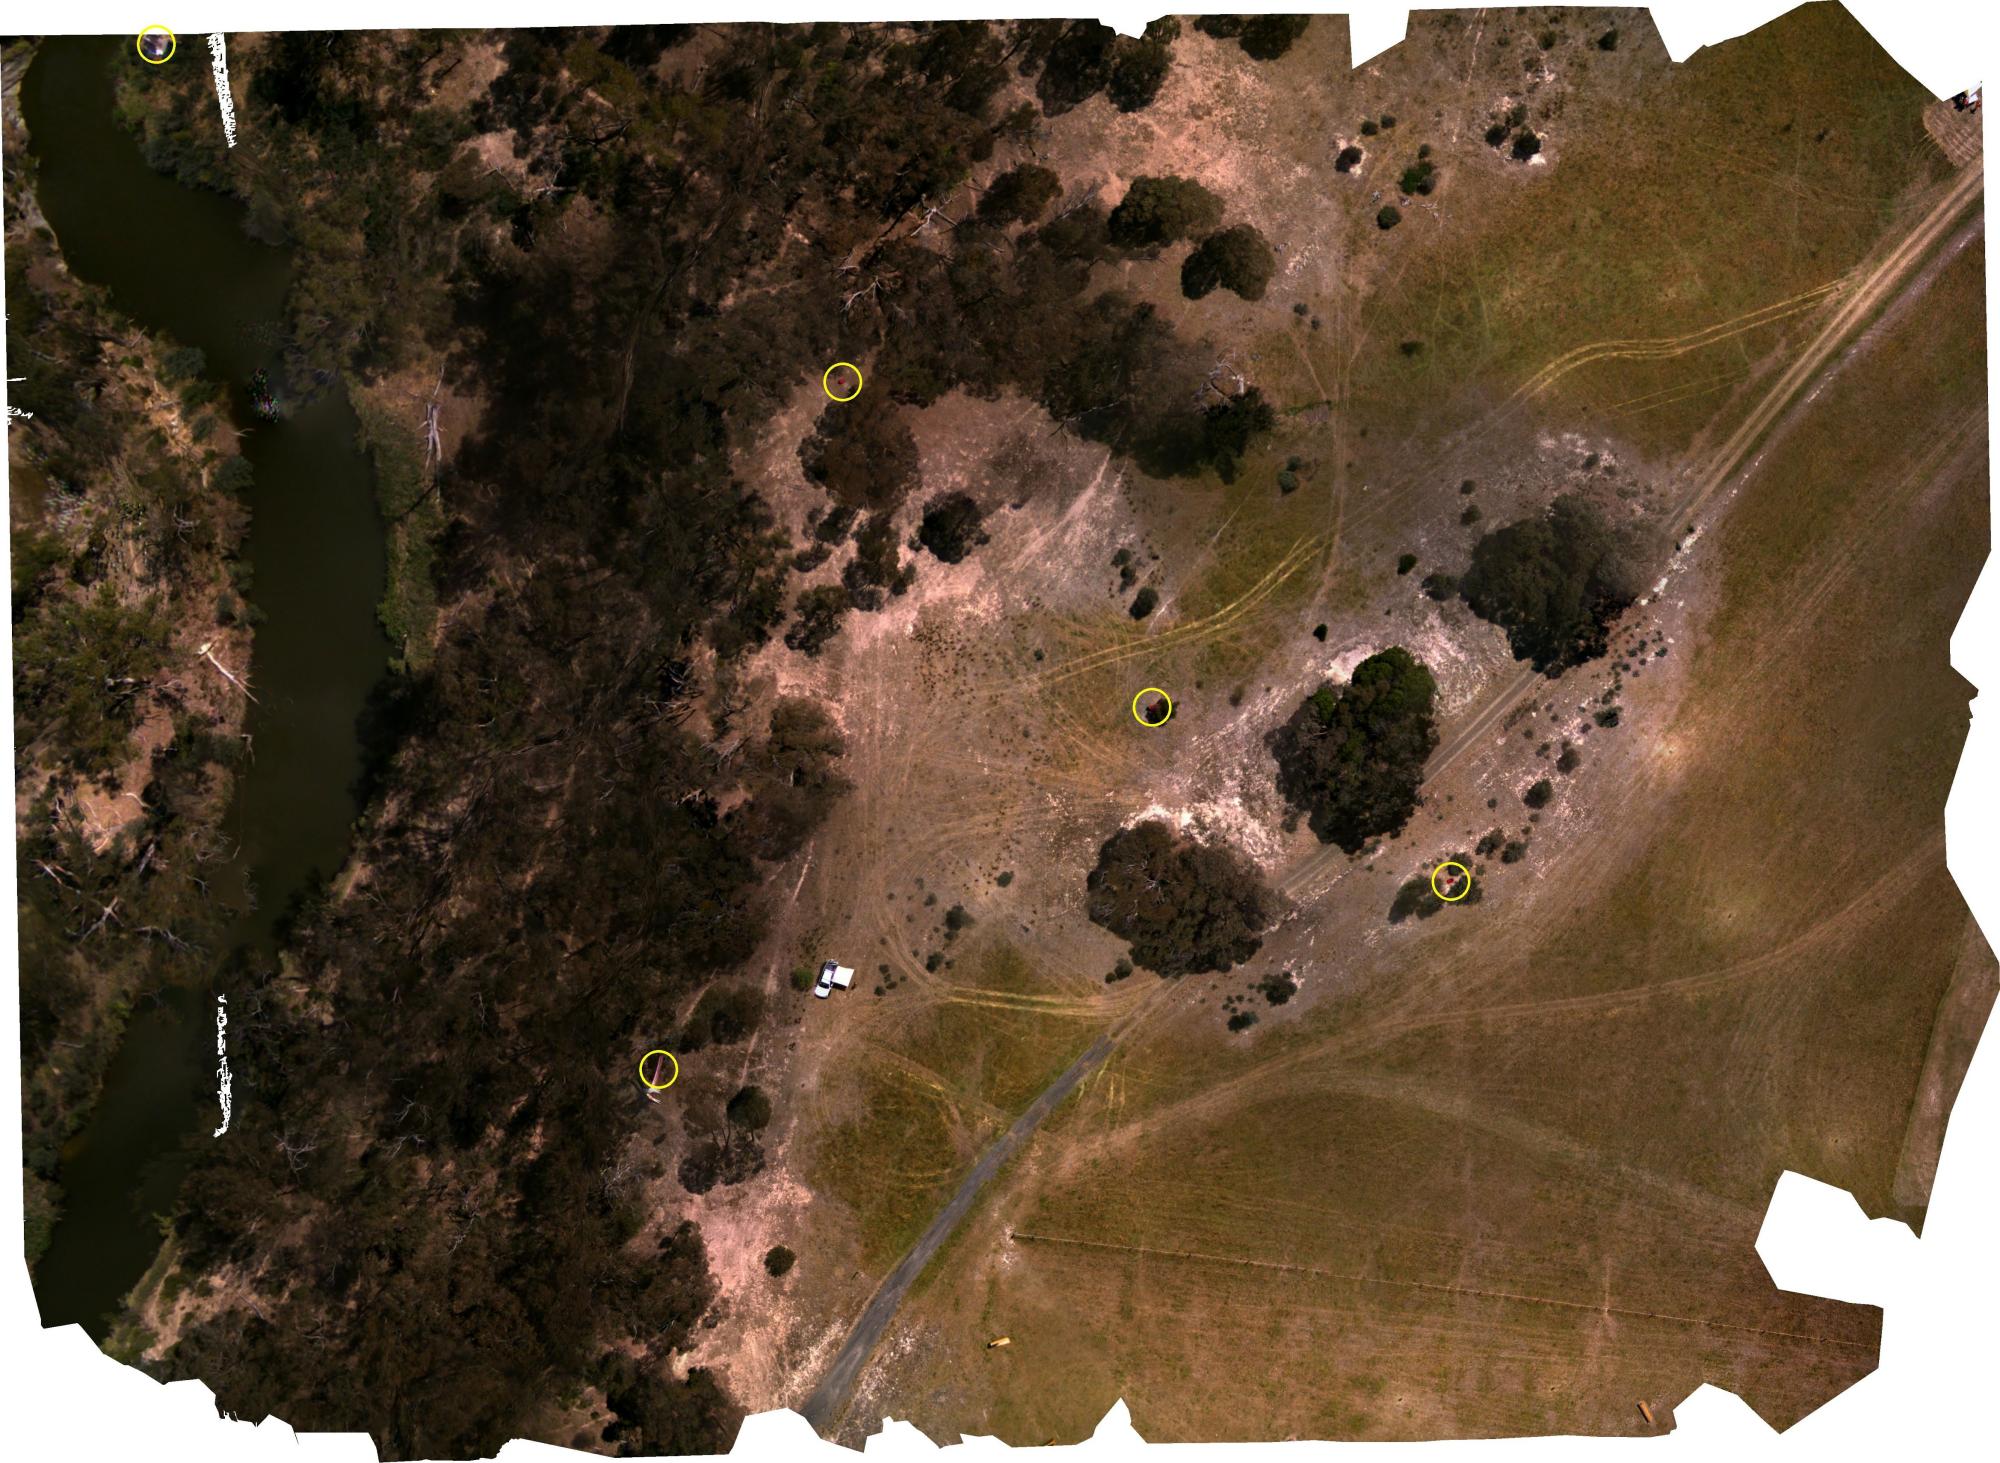
Several tasks have been completed, including a mapping (performed using OpenDroneMap) of the flight area with automatic detection of hazards hidden in the field (with a light fixed wing aircraft) and an autonomous obstacles avoidance navigation near trees (with Bebop2 + SlamDunk from Parrot).

Read article →

15 June 2018 · Gautier Hattenberger

Opening ENAC's flying arena

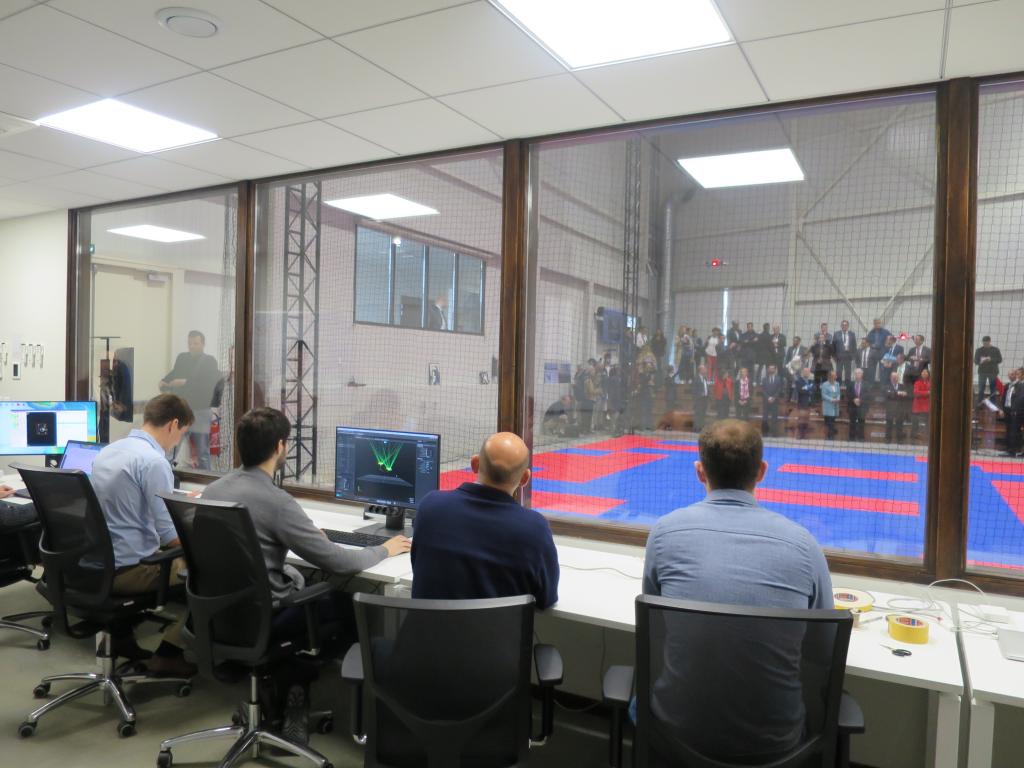
Since the beginning of the year, ENAC (French Civil Aviation University) is equipped with a new facility dedicated to UAVs research and education.

The building includes a flying arena with a size around 10x10x10 meters, several workshops for mechanics, electronic, composite, 3D printing and storage. It also includes a teaching room for automatic control and the student’s robotics club.

The official opening was the 17th of May in the presence of the French minister of transport. Several demonstrations have been performed, all of them showing the formidable capabilities of Paparazzi: distributed formation flight, hybrid vehicles, on-board image processing, efficient adaptive control and autonomous navigation.

Read article →

24 October 2016 · Gautier Hattenberger

IMAV2016

The International Micro-Air Vehicle Conference and Competition was held last week in Beijing, China, organized by the Beijing Institute of Technology and the National University of Singapore.

As usual, the level of the teams involved in the competition is higher year after year and we had a great show. The team from the MAVLAB of TUDelft was participating to both indoor and outdoor session. During the outdoor, they unfortunately couldn’t show their best due to many communication issues, preventing them to fully use their RTK Bebop2 (and also some regressions in Paparazzi code, hum hum… :( ).

Read article →

3 August 2016 · Piotr Esden-Tempski

Paparazzi UAV at DefCon 24

Defcon24-1We will be at DefCon 24. A yearly hacker conference in Las Vegas, Nevada. If you are there make sure to say hi. To get in touch just send a mention or private message to @paparazziuav on twitter or a contact us in our Gitter Discuss channel.

1BitSquared will be there selling their hardware. If you are interested send them a message to @1bitsquared on twitter. They will have Elle0, Lisa/S, Lisa/MX, Lisa/M autopilots for sale as well as Lisa/S starter kits and Quad Kits. The new Black Magic Probe v2 programming and debugging adapter will be available at the Hacker Warehouse in the Vendor area.

Read article →

24 July 2016 · Gautier Hattenberger

Flights at the ISARRA2016 conference

Last May, the ISARRA conference (International Society for Atmospheric Research using Remotely Piloted Aircraft) was held in Toulouse, France (http://www.meteo.fr/cic/meetings/2016/isarra/).

The week before the conference, a few teams of researchers gathered to share experiences and fly their drones at the Atmospheric Research Center of Lannemezan near the Pyrenees. Among them was some of the oldest users of Paparazzi: Martin Muller (http://blog.pfump.org), the team of Joachim Reuder from the Geophysical Institute of Bergen, the UAV Lab of ENAC and the French Meteorological Research Center who was hosting the event.

Read article →

4 January 2016 · Piotr Esden-Tempski

Paparazzi UAV at 32C3 Recap

IMG_3320Here is a short review of our Paparazzi UAV meet up at the 32C3.

For those of you who have never heard of the Chaos Communication Congress, it is a hacker conference that takes place every year between Christmas and New Year’s Eve in Germany. For many years it was held in Berlin, but with the increased attendance a larger venue was needed, it is now being held in Hamburg, Germany.

Most people arrive in Hamburg on the 26th of December for day 0 of the conference. We met our assembly in the large Hackcenter hall. EZ who helped organize lodging for a lot of us also found and reserved tables for us. Usually it was the CCC organizers who were reserving the tables for the so called Assemblies. This time they did not do that for any Assembly with less than a 100 members. This shows how big the event is getting.

Read article →

5 September 2015 · paparazzi

IMAV 2015 Competition

This year‘s International Micro Air Vehicles Conference and Flight Competition (IMAV 2015) is organized by the Institute of Flight Screen Shot 2015-10-24 at 1.57.42 AM System Dynamics of the RWTH Aachen University and the German Institute of Navigation. It takes place in Aachen, Germany from September 15 - 18, 2015. If you are in the area, you should check out the event.

IMAV is a yearly event that combines a diversified scientific conference with a technological competition involving Micro Air Vehicles (MAVs). Such a combination allows research groups from all over the world to share their knowledge, and stimulates them to focus on research that can be used in real life scenarios. Every year the competition scenarios become more advanced and more extensive. However, competitors are given the opportunity to either do complete missions, or to focus on sub-elements of the mission scenario.

Read article →