PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Competition

6 July 2012 · paparazzi

ATMOS Hybrid UAV

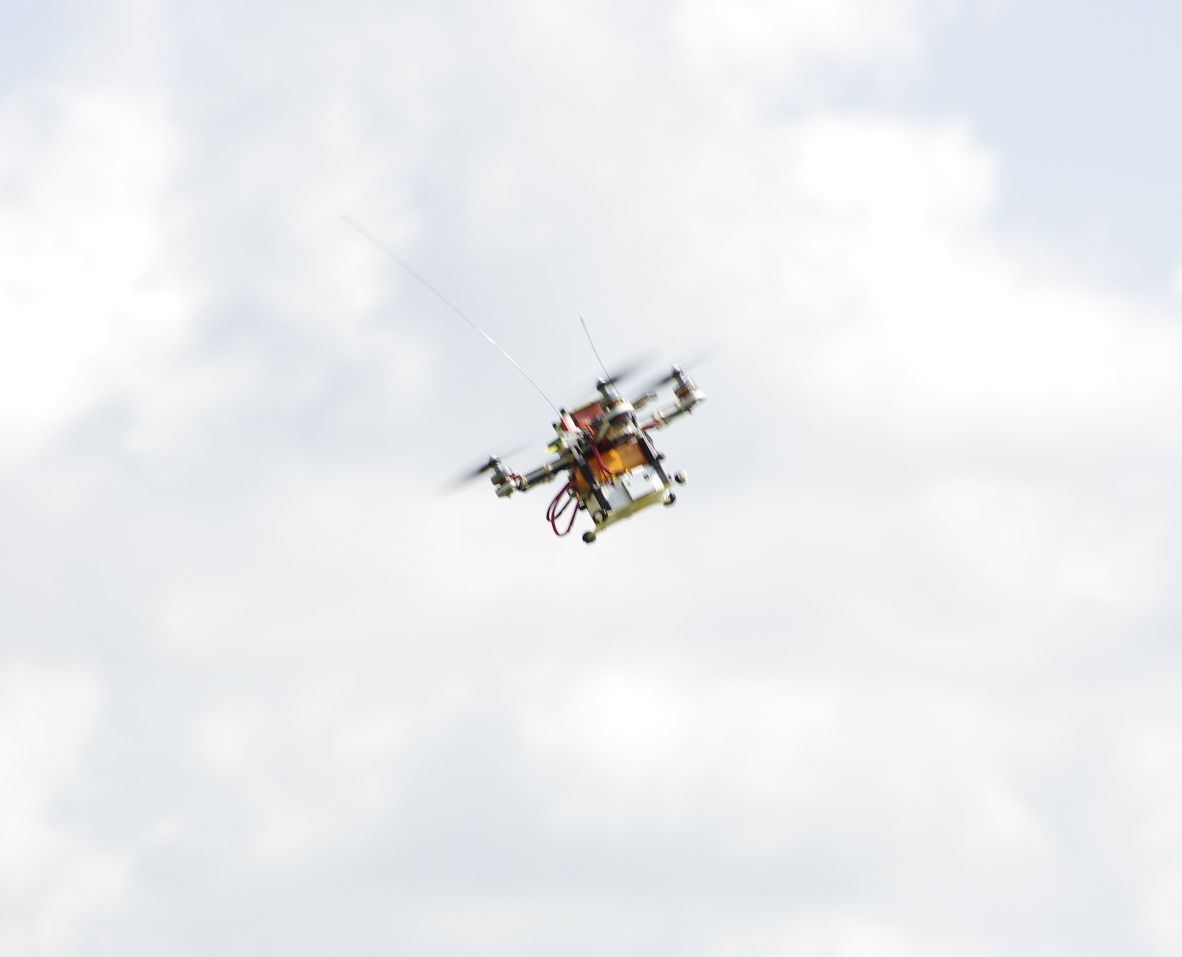
AtmosATMOS, a hybrid airplane-quadrotor developed at the MavLab of TU-Delft, was awarded third place (out of 140) in the UAVForge Competition. There were more than 140 initial contestants and after several selection rounds with only 12 finalists, the paparazzi Lisa/M powered ATMOS was one of the few that could actually make it to the remote target site miles away in an RF unfriendly environment. No team fully completed the baseline objectives which is why no prices were issued. The vertical takeoff and landing, together with long range thanks to the wing and flexibility thanks to open-source paparazzi were key factors in this event [1].
Read article →

6 July 2012 · paparazzi

1st Place at IMAV 2012 for ENAC Paparazzi Team

Blender_at_IMAV2012Blender, the small but deserving quadrotor of the ENAC Paparazzi Team took the 1st place in the “Outdoor autonomy challenge” and 3rd place in the “Outdoor flight dynamics challenge” during the IMAV2012 competition in Braunschweig, Germany. Completing its missions with overflowing enthusiasm thanks to the new NavGo autopilot. NavGo is the latest in the long line of award winning Paparazzi hardware available. See the list of Paparazzi hardware here.

Read article →

18 September 2011 · paparazzi

IMAV 2011

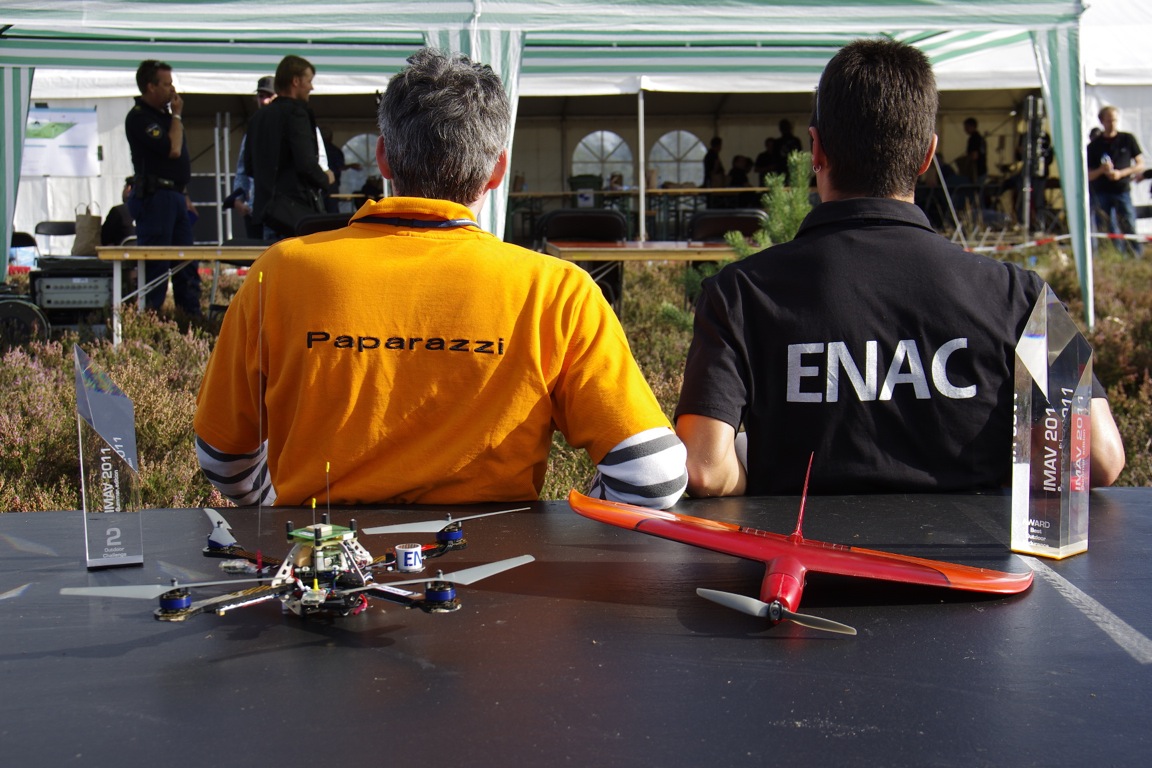
Enac_imav11_1This year IMAV 2011 in Delft, Netherlands went really well for all of the participants, we have seen lots of successful flights. ENAC Paparazzi Team took the 2nd place in general “Outdoor Autonomy Challenge” and Fire Storm demonstrated 105+ minutes of flight and took the “Best Outdoor Endurance Award”.  He was waiting for this day for 2 years since the cancelation of IMAV 09. Additionally, Fire Storm flew its endurance mission with the new Umarim V1.0 autopilot board which will be released soon.

Read article →

9 July 2010 · paparazzi

IMAV 2010 Competition

The IMAV 2010  International Micro Air Vehicles Conference and Flight Competition took place today in Braunschweig, Germany. The ENAC Paparazzi team took home 1st place for the outdoor
autonomy mission and 2nd place for the indoor flight dynamics
challenge. Both the indoor and the outdoor event consisted of two separate competitions, one focusing on high maneuverability, the other one focussing on the MAV’s ability to perform a complex
autonomous mission.

Read article →

30 September 2009 · paparazzi

Outback Challenge 2009

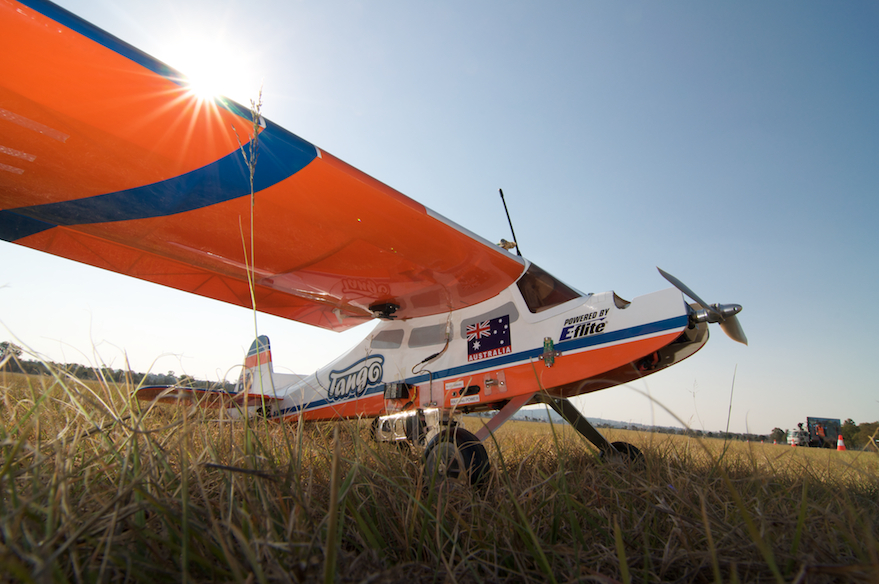
Brisbane Grammar School UAV Brisbane Grammar School UAV

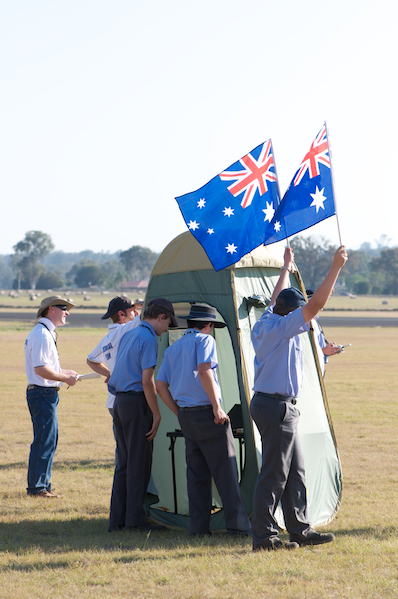
Team “Look mAh, no hands!” signalling the UAV is in fully autonomous mode Team “Look mAh, no hands!” signalling the UAV is in fully autonomous mode

Paparazzi was a big success at the 2009 UAV Outback Challenge held at Kingaroy Airport, Queensland, Australia, Sep. 28-30. Team “Look mAh, no hands!” representing Brisbane Grammar School, won the ‘Robot Airborne Delivery Challenge’ placing 1st, after performing an autonomous mission phase including autonomous payload release. The team consisted of four members in their senior years of high-school, and was led by team captain Ben Paratz. Many thanks to the paparazzi community, not only for the autopilot itself but for the assistance that was enthusiastically given whenever needed. Link to competition

Read article →

15 September 2009 · paparazzi

EMAV 09 Results

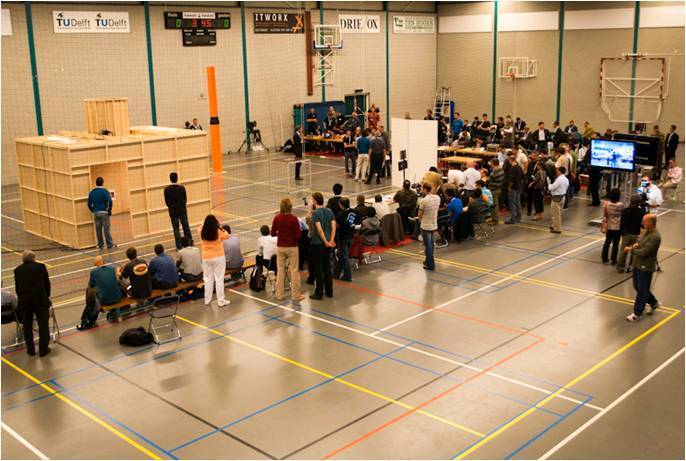
The EMAV09 competition took place in Delft, Netherlands. With Emav09ENAC’s Paparazzi team winning second place in the outdoor mission this year.

d91d22d039d685689a61bf04fdc5dc66.media.686x461

Read article →