PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Competition

22 February 2023 · Gautier Hattenberger

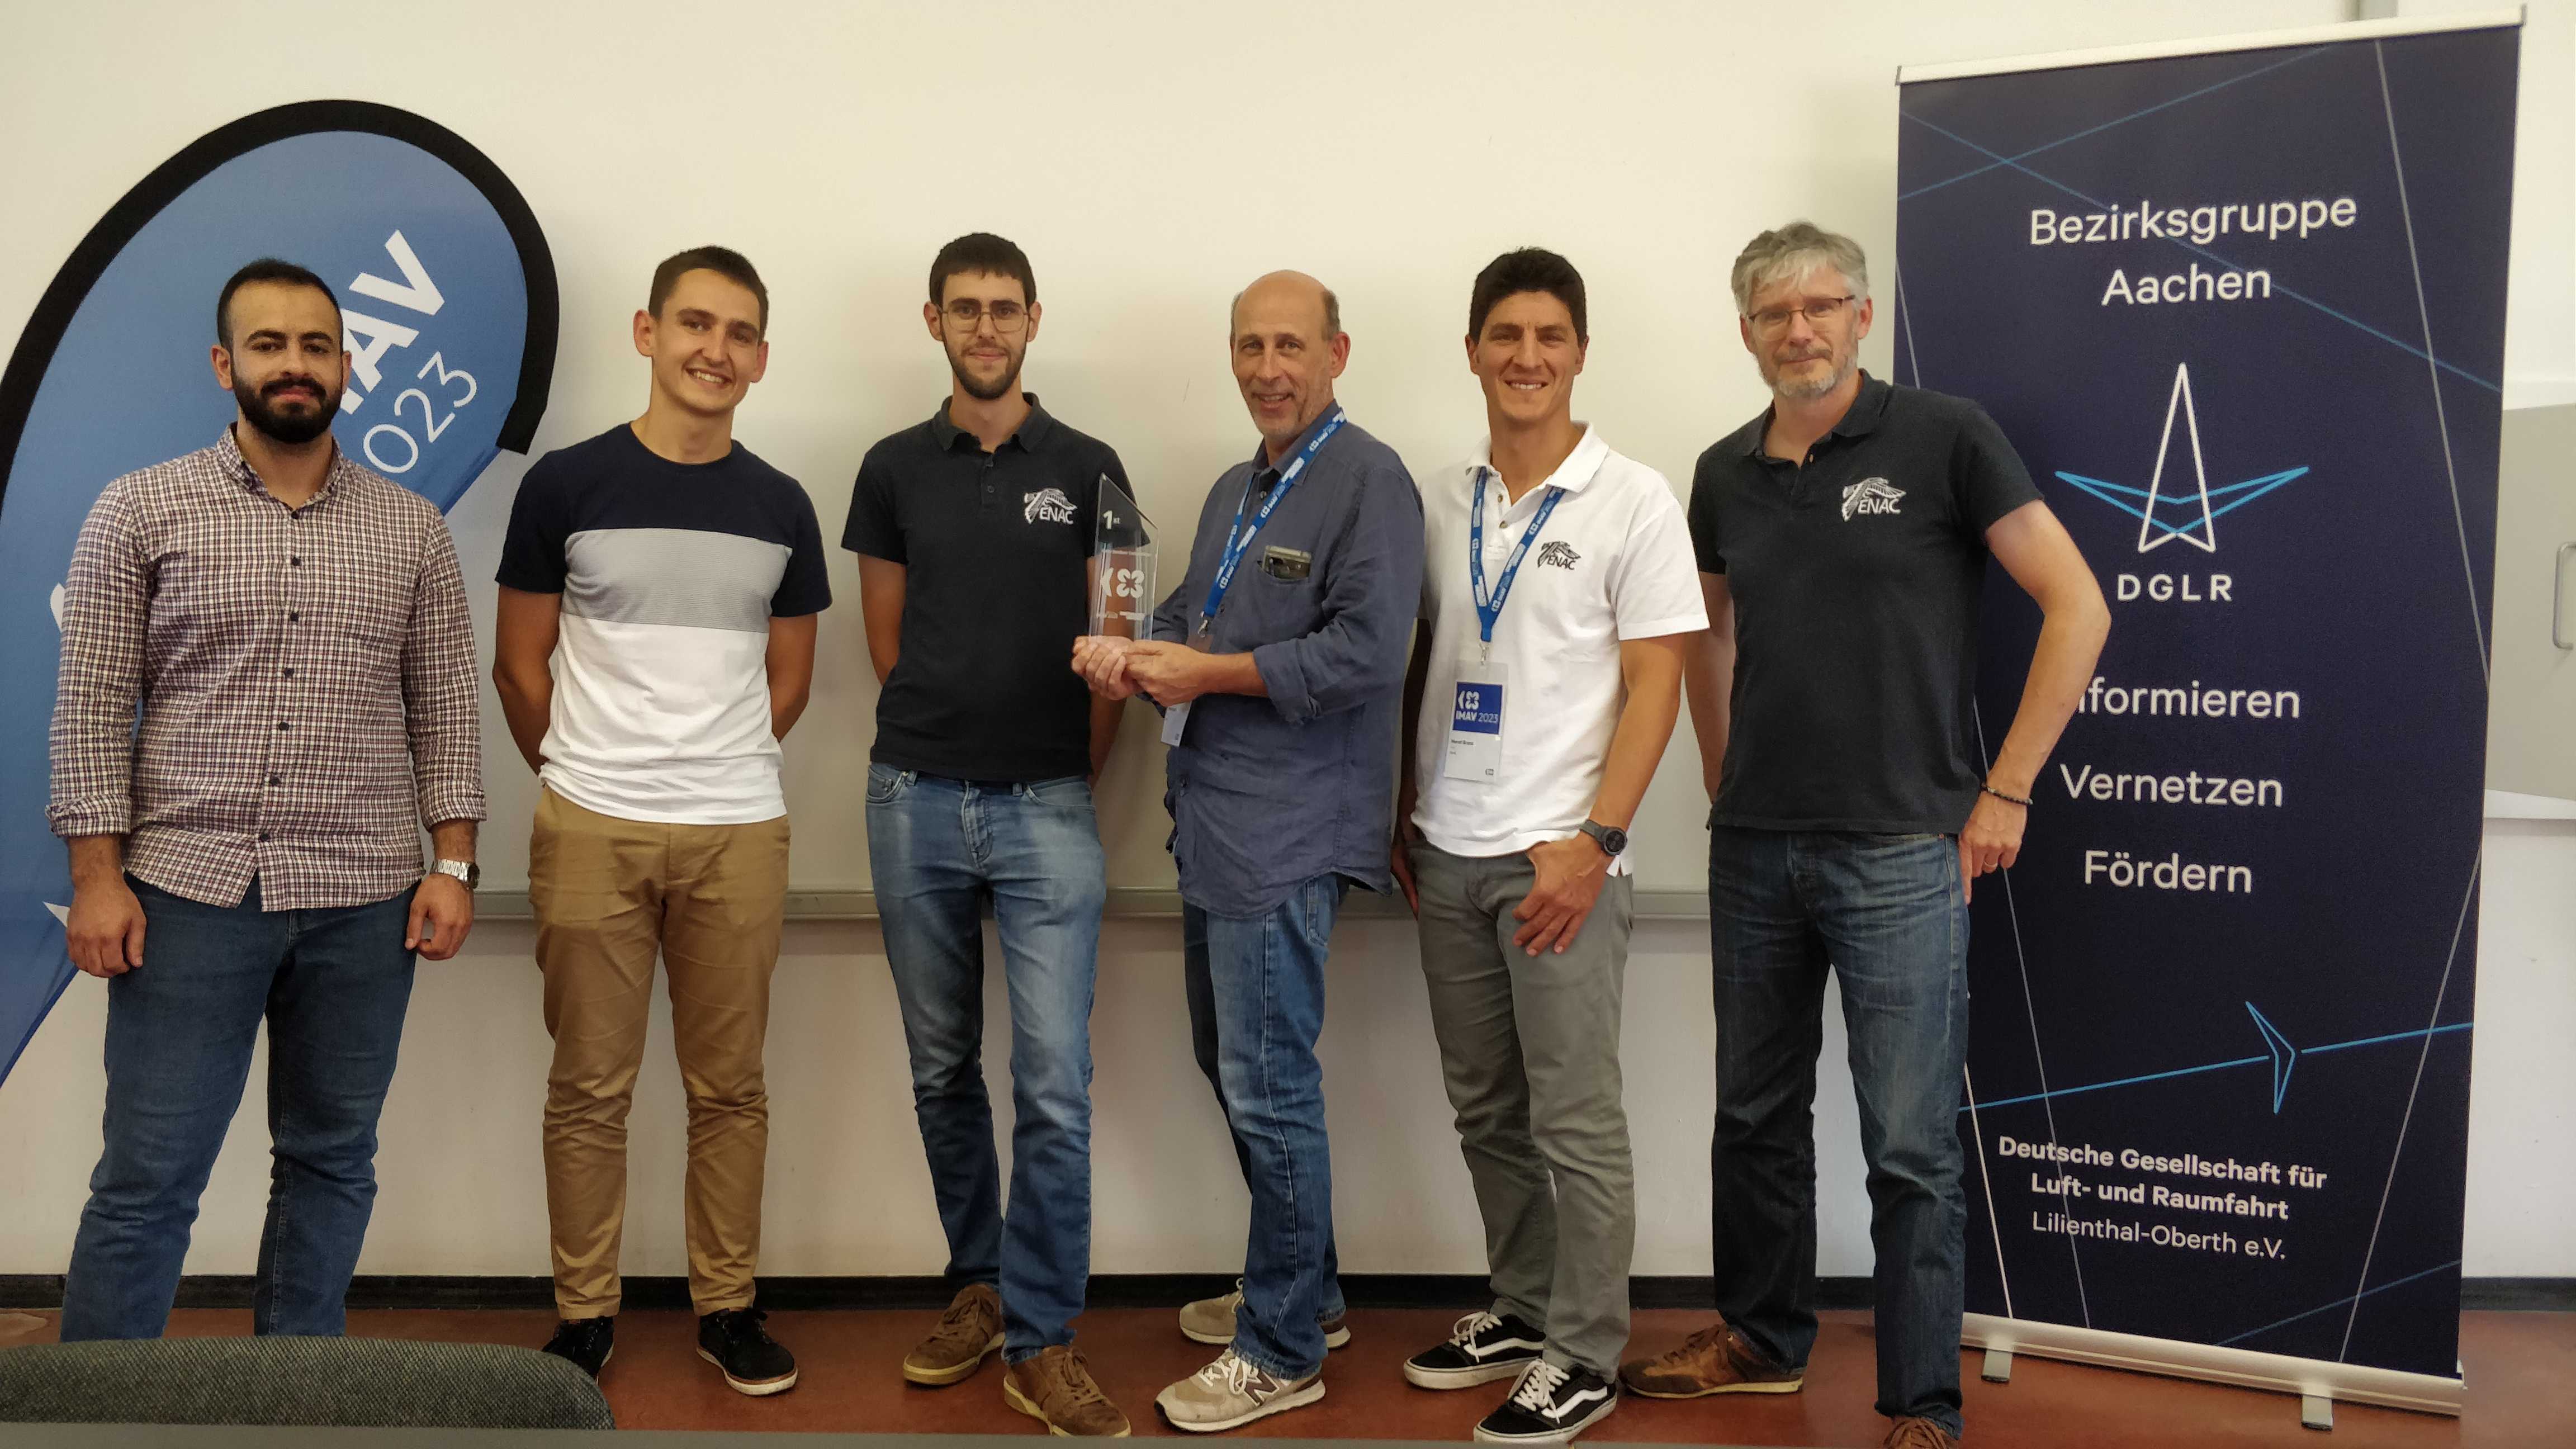
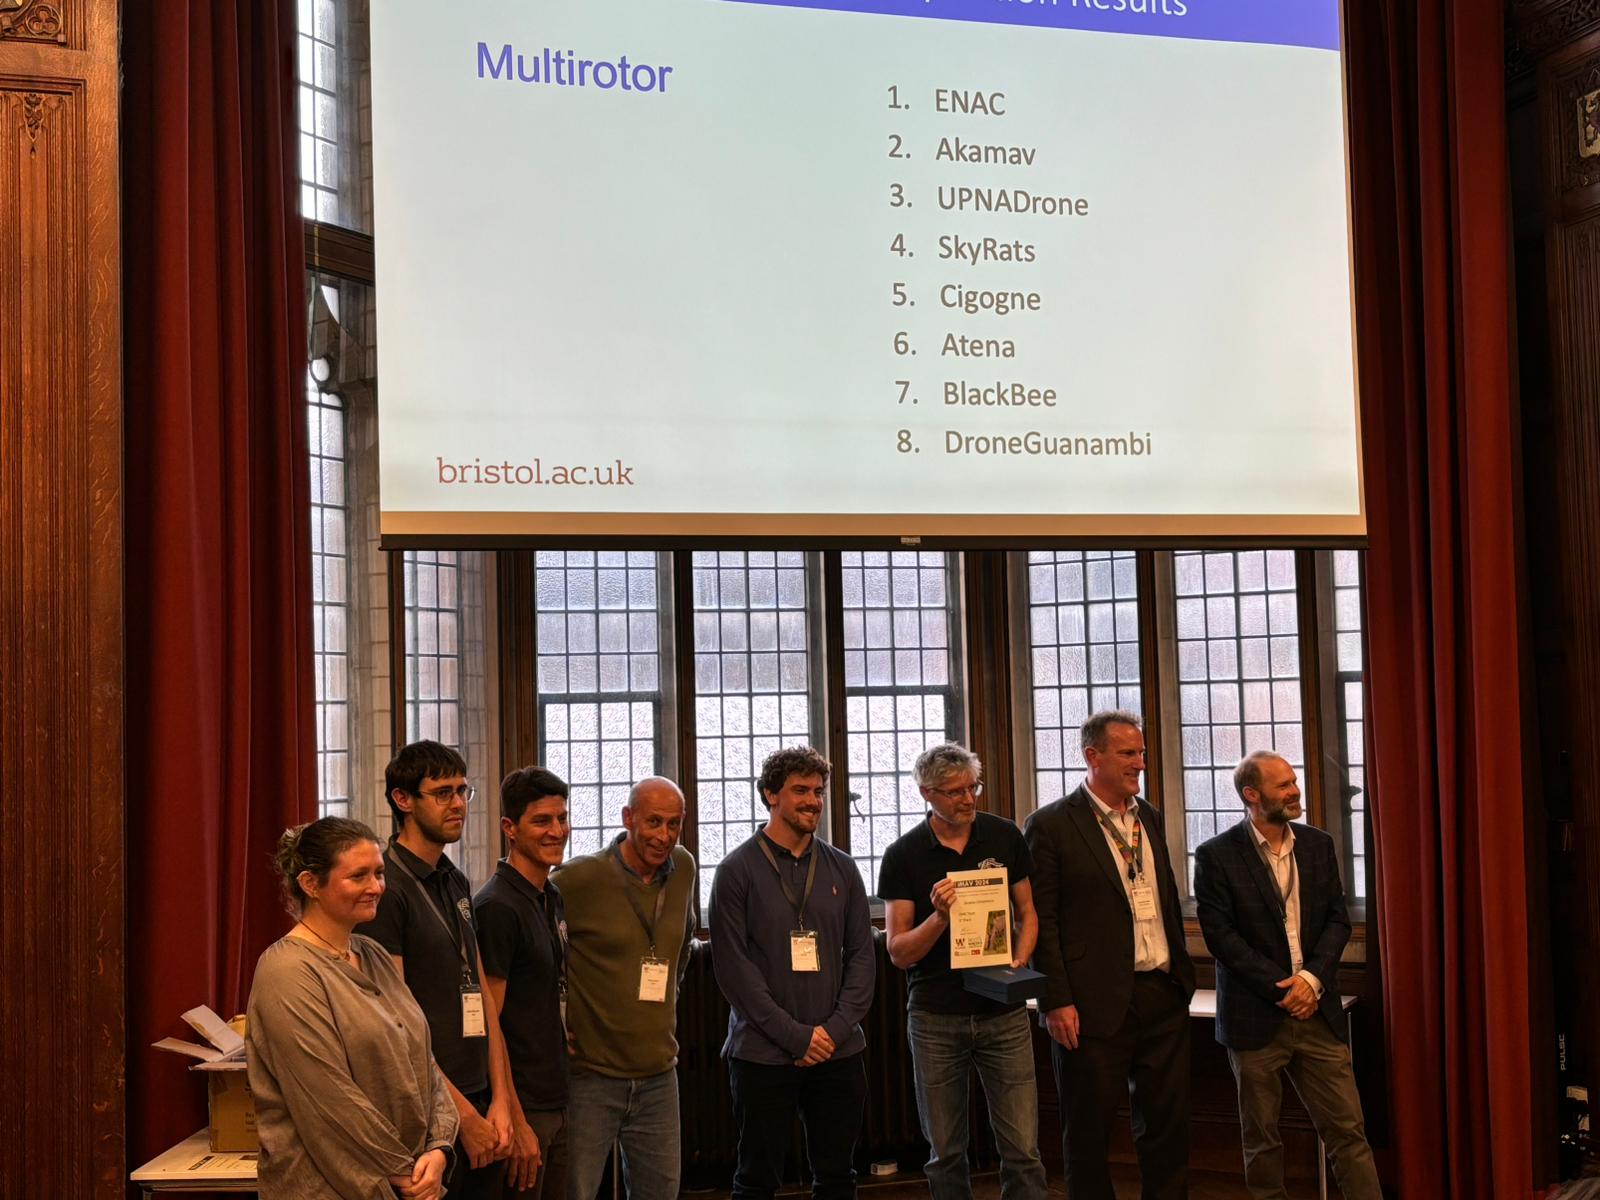
ENAC Team wins at IMAV2022

The International Conference and Competition on MAV was organized by TUDelft mid-September 2022. The ENAC took part to the outdoor competition, a package delivery challenge, with several multi-rotors and a hybrid tail-sitter, all powered by Paparazzi.

They won the competition with a quite large amount of points. Nevertheless, all teams performed well with some innovative platforms.

Several papers have been presented to the conference by the ENAC team and the other participants. The proceedings are freely available on the conference website.

Read article →

28 November 2018 · Gautier Hattenberger

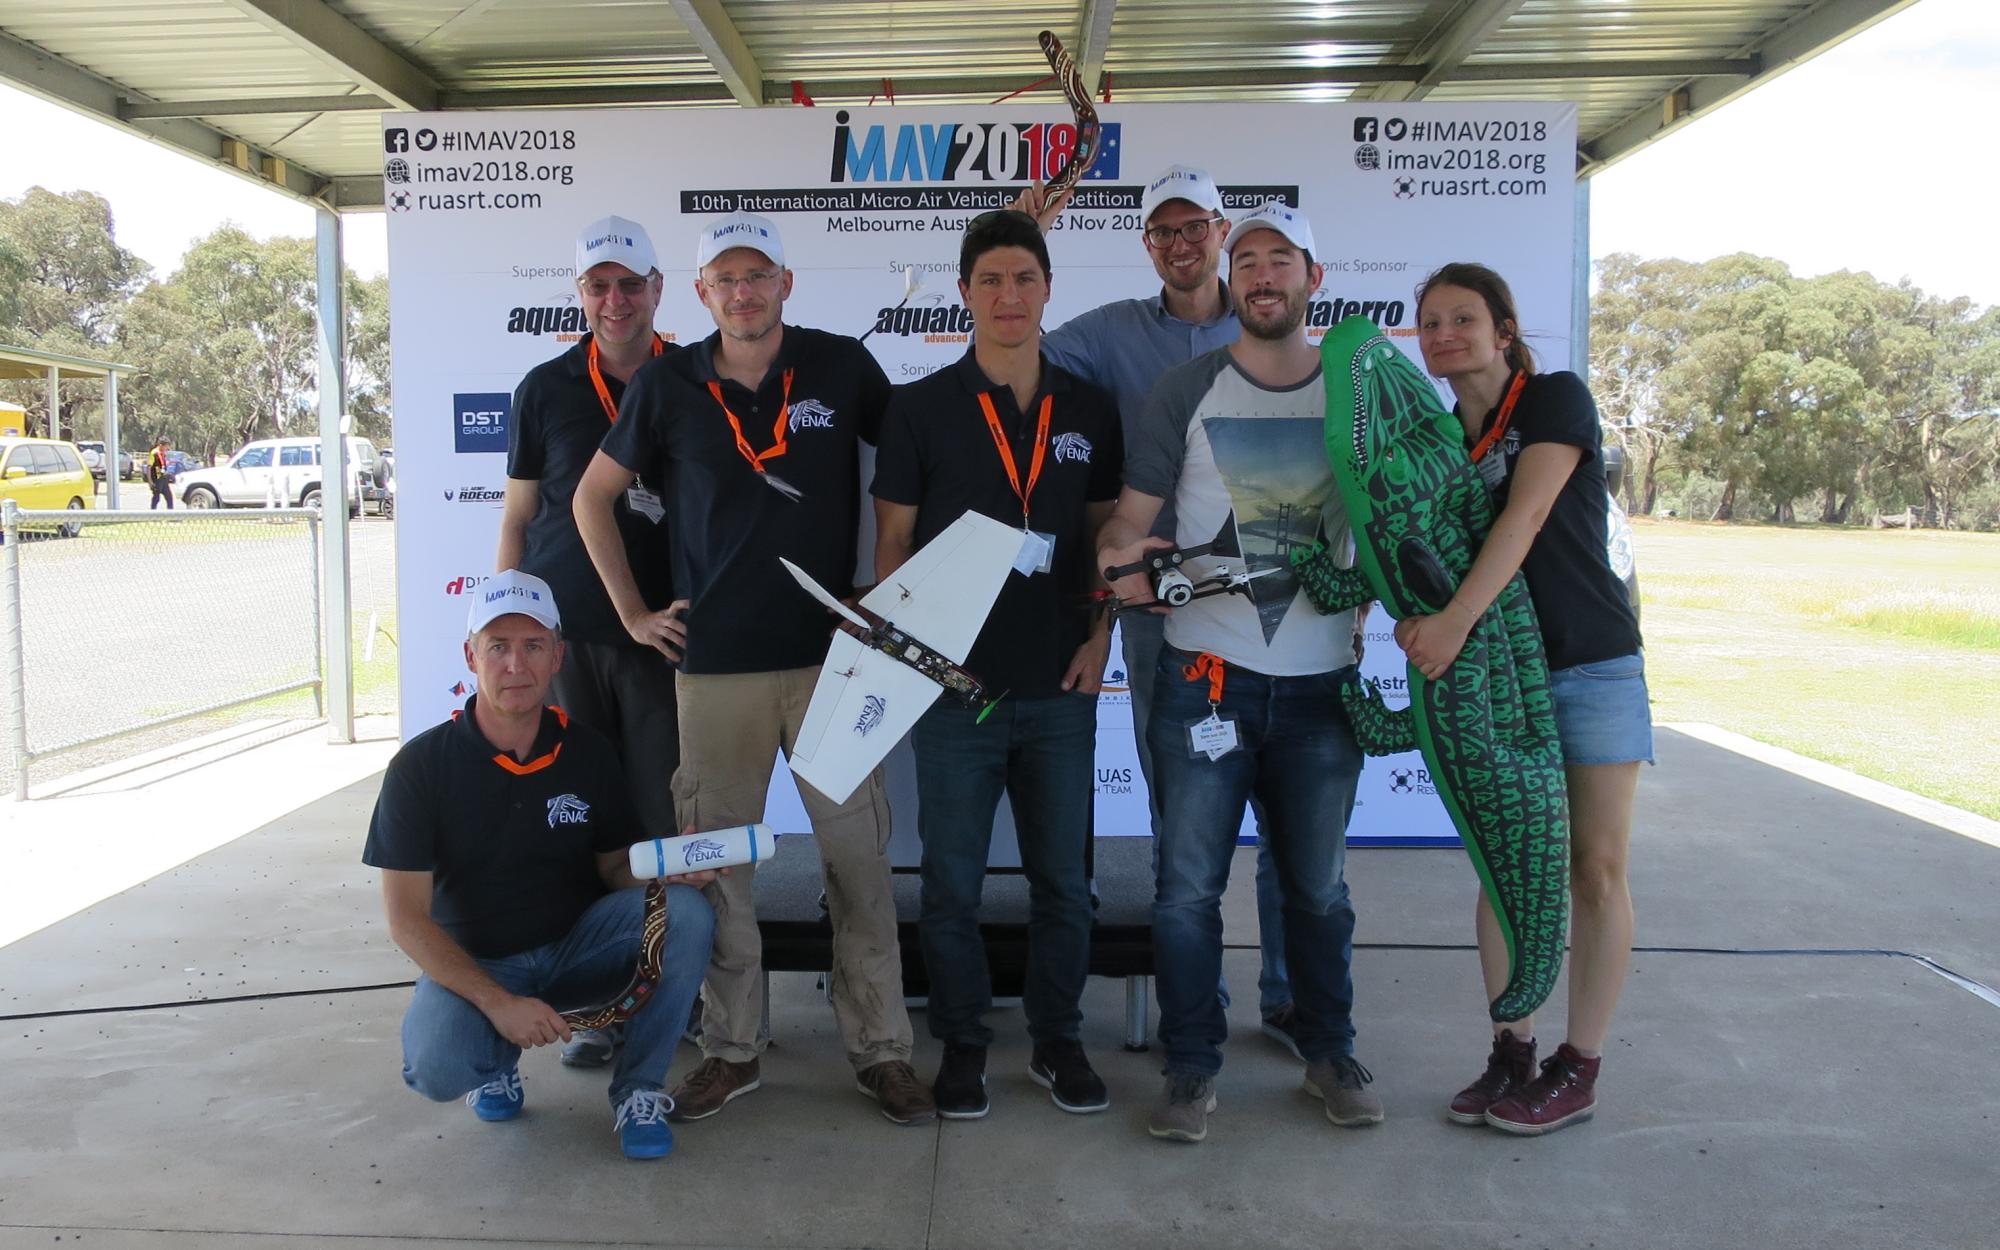
Paparazzi wins at IMAV2018

Enac UAV team and TUDelft MAVLAB team took part to the IMAV2018 conference and competition in Australia with great success!

For the first time, the two academic lead developers of the Paparazzi UAV system join efforts to participate to the Outdoor competition and won this event far ahead.

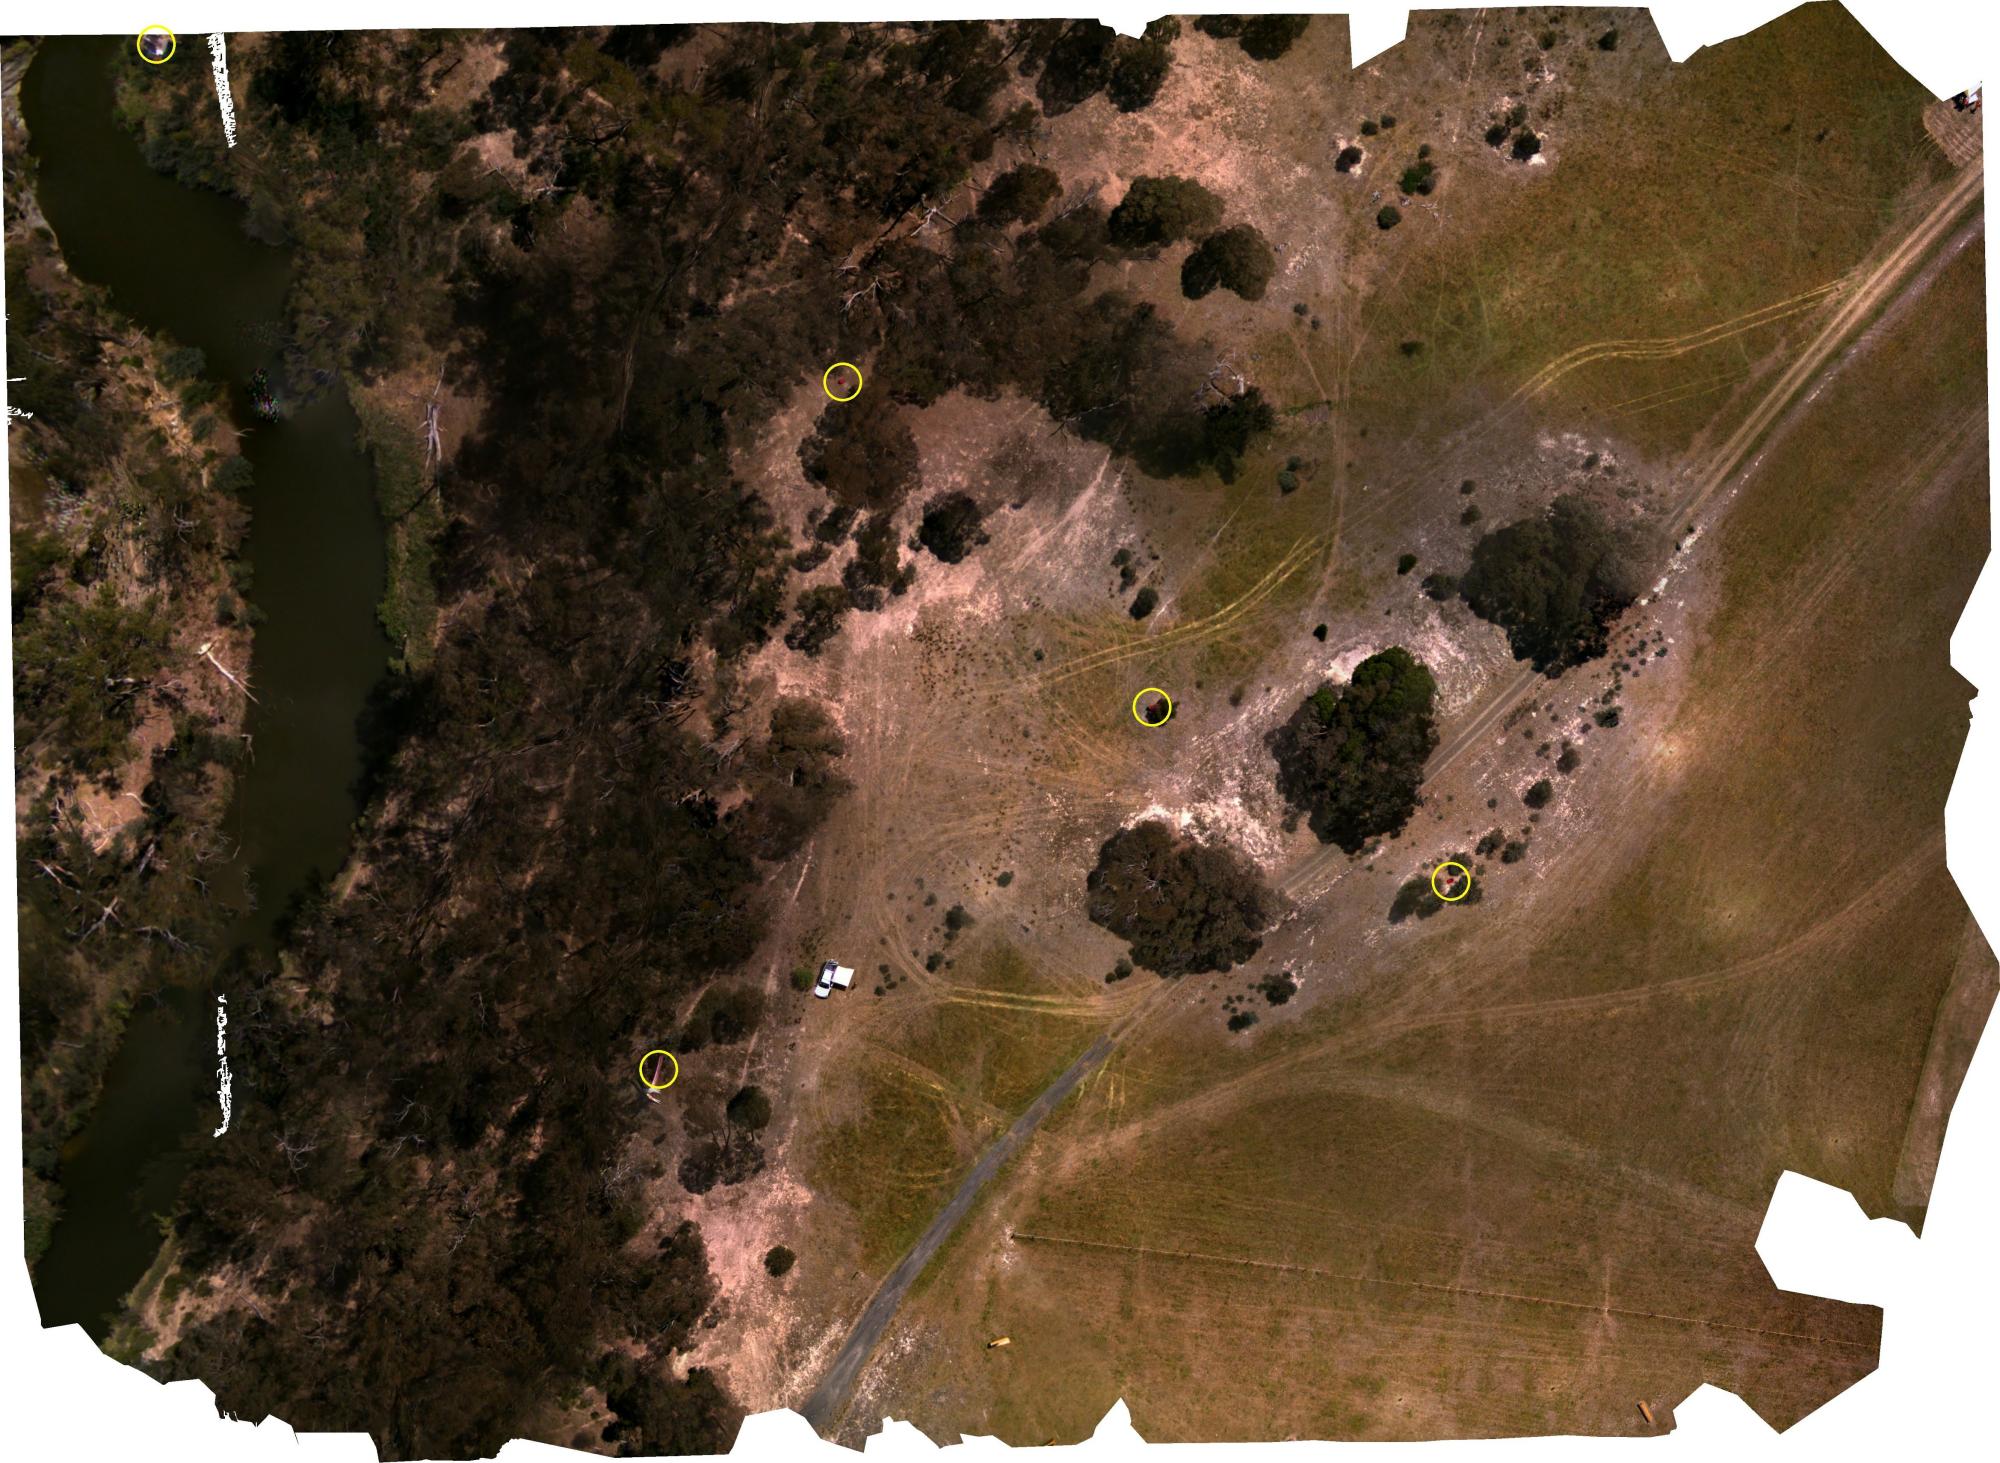
Several tasks have been completed, including a mapping (performed using OpenDroneMap) of the flight area with automatic detection of hazards hidden in the field (with a light fixed wing aircraft) and an autonomous obstacles avoidance navigation near trees (with Bebop2 + SlamDunk from Parrot).

Read article →

24 October 2016 · Gautier Hattenberger

IMAV2016

The International Micro-Air Vehicle Conference and Competition was held last week in Beijing, China, organized by the Beijing Institute of Technology and the National University of Singapore.

As usual, the level of the teams involved in the competition is higher year after year and we had a great show. The team from the MAVLAB of TUDelft was participating to both indoor and outdoor session. During the outdoor, they unfortunately couldn’t show their best due to many communication issues, preventing them to fully use their RTK Bebop2 (and also some regressions in Paparazzi code, hum hum… :( ).

Read article →

20 September 2016 · Rich Burton

DELFTACOPTER - Hybrid Drone on a Mission

DELFTACOPTER, an electric, long range, transitioning autonomous delta-wing helicopter, is on a mission. What mission? In this case, it’s the 2016 Outback Medical Express challenge and the MAVLab Team at TUDelft has high hopes for their hybrid aircraft.

This year’s Outback Medical Express mission requires a UAV to pick up and bring back a blood sample of an ill-fated person called “Outback Joe” located at an inaccessible roughly known location 30 kilometer away remote location with unknown terrain.

Read article →

5 September 2015 · paparazzi

IMAV 2015 Competition

This year‘s International Micro Air Vehicles Conference and Flight Competition (IMAV 2015) is organized by the Institute of Flight Screen Shot 2015-10-24 at 1.57.42 AM System Dynamics of the RWTH Aachen University and the German Institute of Navigation. It takes place in Aachen, Germany from September 15 - 18, 2015. If you are in the area, you should check out the event.

IMAV is a yearly event that combines a diversified scientific conference with a technological competition involving Micro Air Vehicles (MAVs). Such a combination allows research groups from all over the world to share their knowledge, and stimulates them to focus on research that can be used in real life scenarios. Every year the competition scenarios become more advanced and more extensive. However, competitors are given the opportunity to either do complete missions, or to focus on sub-elements of the mission scenario.

Read article →

27 May 2015 · Danika Esden-Tempski

TU Delft Student Challenge 2015

Students at the TU Delft MavLab compete with ARDrones running Paparazzi to fly seamlessly around obstacles without injuring the aircraft. The object to autonomously avoid all obstacles. This is a fantastic demonstration of the flexibility of the Paparazzi system and its ability to fly accurately around waypoints.

Read article →

16 August 2014 · Piotr Esden-Tempski

IMAV 2014 Recap

IMAV 2014 was a great experience this year. If you don’t know what it is, its a micro air vehicle competition and conference that was held in Delft, Netherlands.

During the three days of the conference, there were many very interesting talks and presentations as well as an incredible showcase of research talent during the competition. Here is a playlist of the talks, they can be found on the TU Delft MAVlab YouTube channel.

Read article →

12 August 2014 · paparazzi

IMAV 2014 Live Streams

Imav_logoThe Micro Aerial Vehicle Laboratory (MAVLab) of Delft University of Technology (TU Delft) is proud the present the 2014 International Micro Air Vehicle Conference (IMAV 2014), now offering the possibility of attending the conference by live stream free-of-cost. The live stream will support most platforms showing innovative keynotes of pioneers in the industry as well as the current state-of-the-art presented by many researchers working on MAV’s. The schedule is published on the website of the conference. Tuesday, August 12th, 2014

Read article →

20 September 2013 · Piotr Esden-Tempski

IMAV 2013

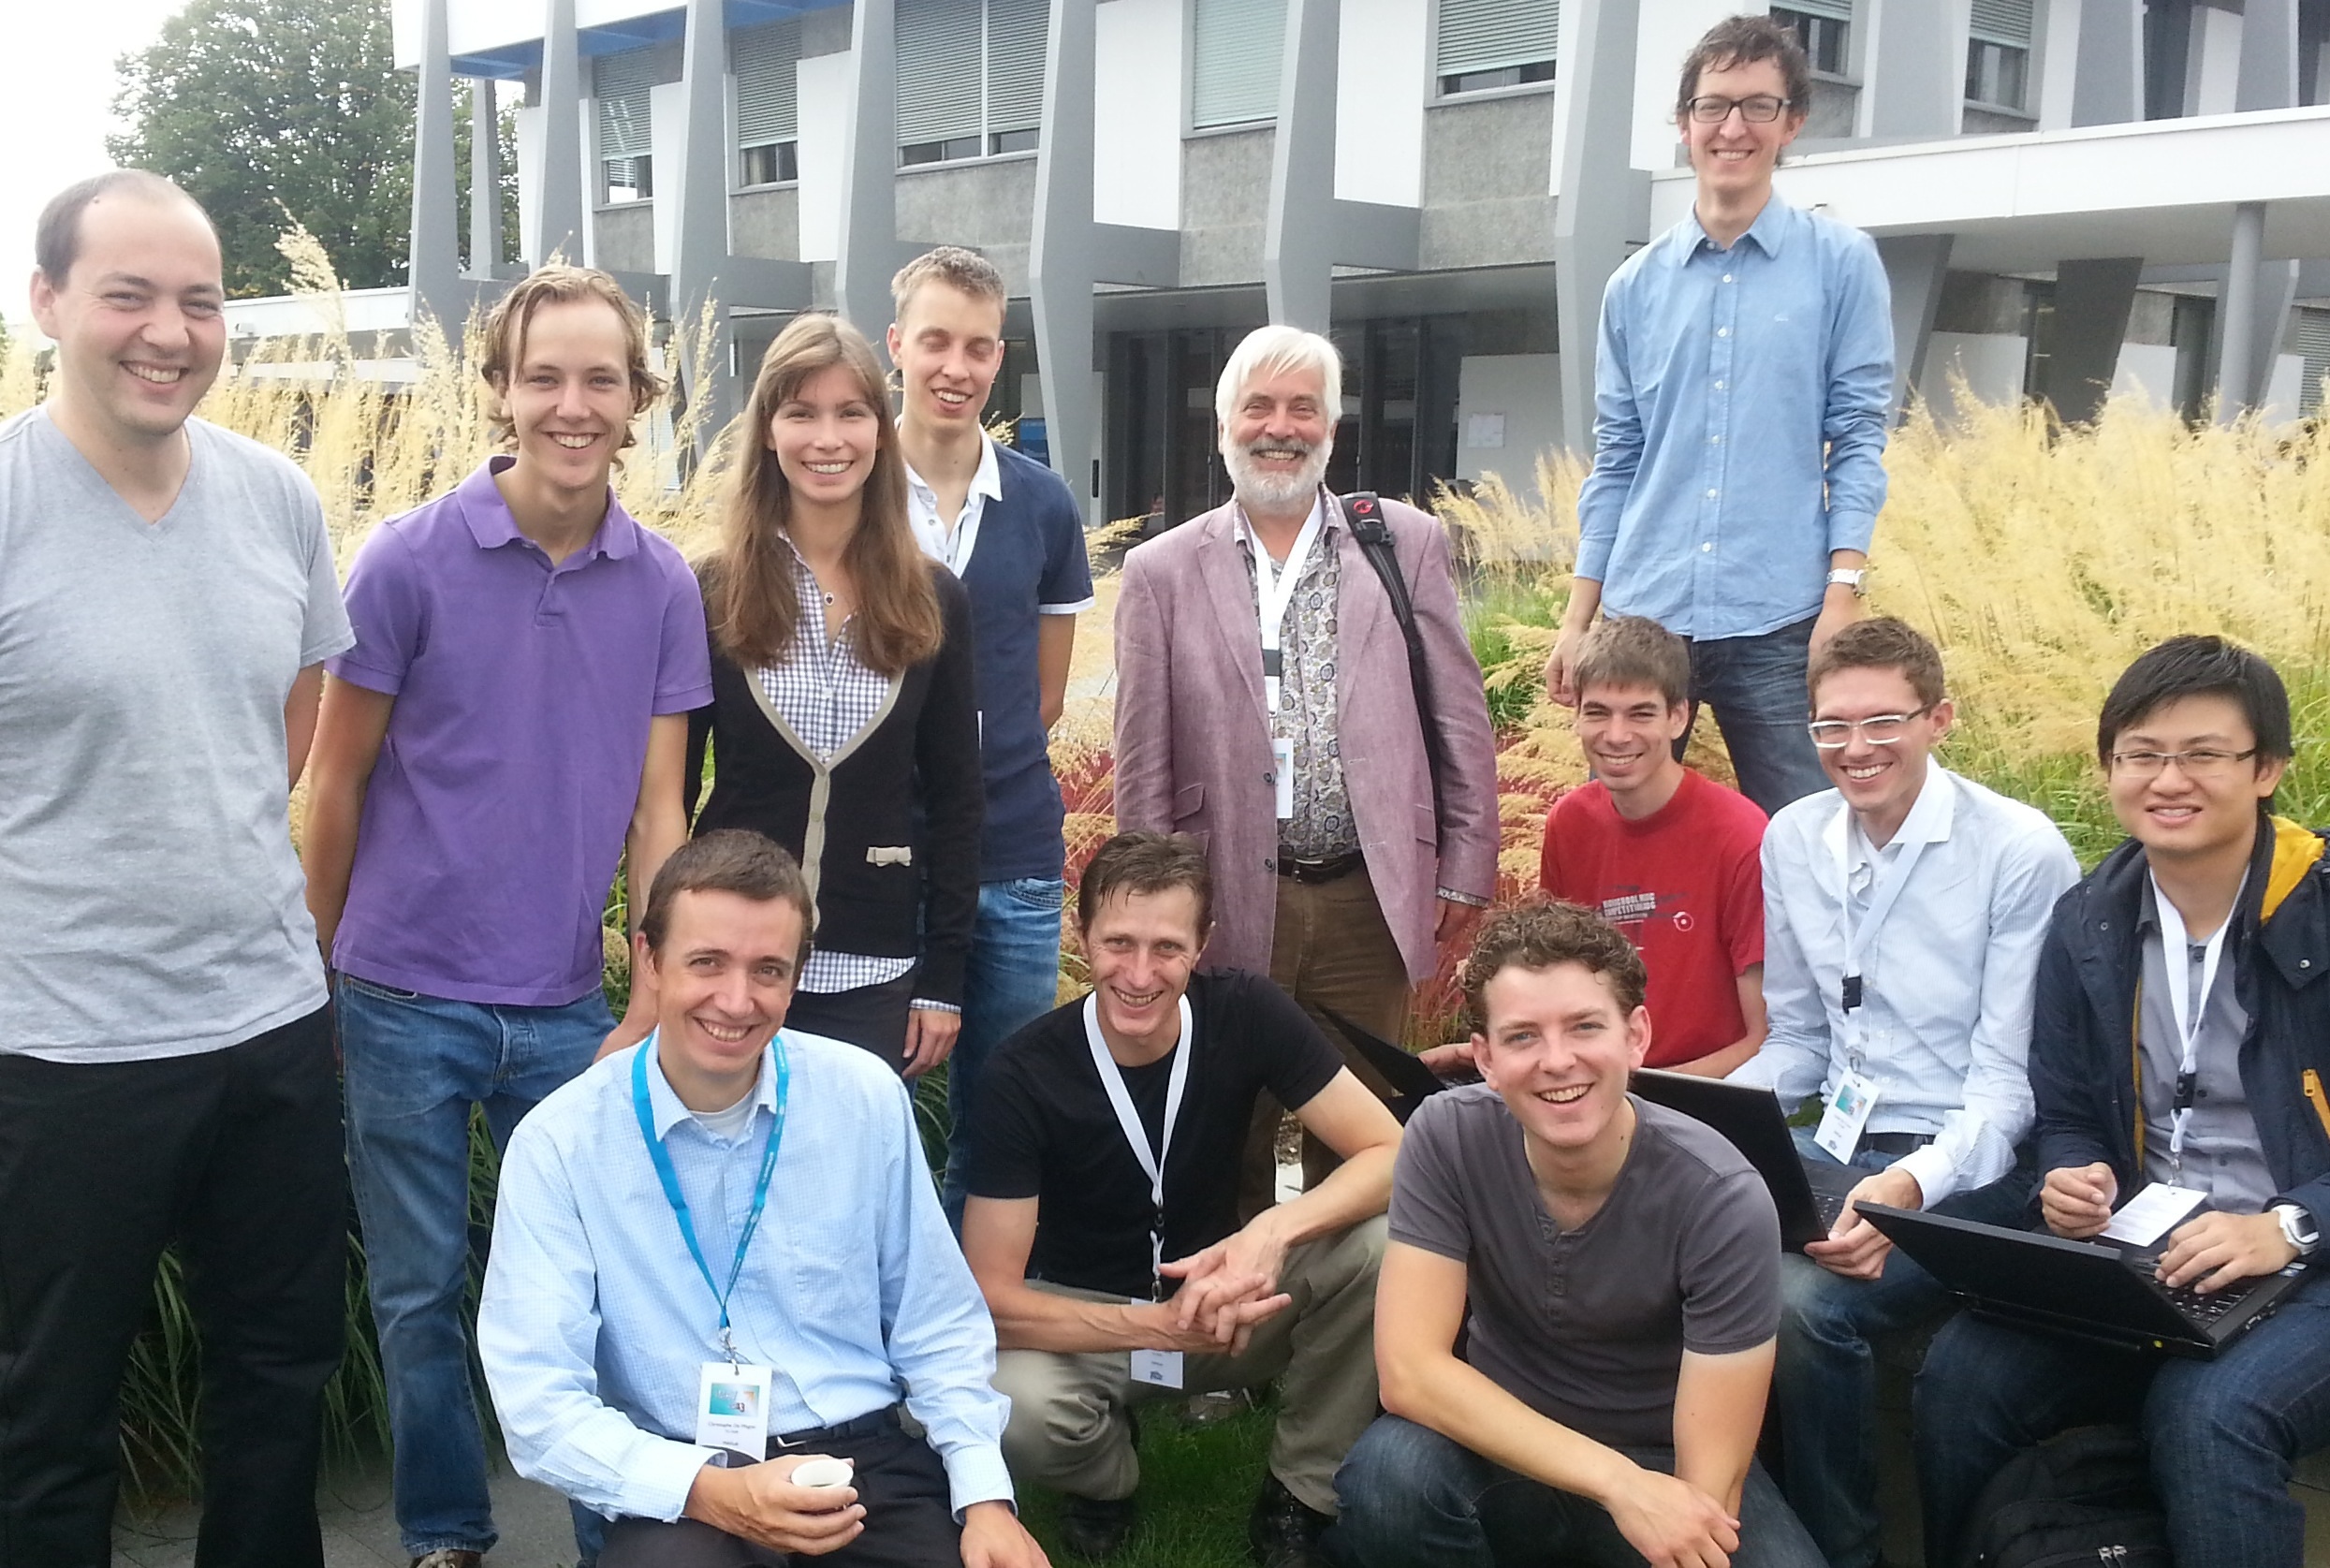
Mavlabimav2013The MavLab team of TU Delft consisted of 12 people coming from aerospace, computer science, embedded programming and artificial intelligence. Thanks to the enormous team efforts in the last months, the team has won prizes in all the categories in which it participated at IMAV 2013 in Toulouse, France:

Outdoor: 1st place

With an autonomous swarm of 12 MAVs operated by a single operator. The MAVs only had to be plugged in and started with their own flight plan, while the operator could monitor their mission status and intervene where necessary. Our participation featured four main innovations: (1) a single operator for 12 MAVs, 3 hybrid UAVs, 7 Parrot AR drones and 2 mini-quadrotors, (2) onboard vision processing on the AR drone with Paparazzi, (3) hybrid UAVs able to fly under any attitude, and (4) the world’s smallest open source autopilot,  Lisa/S (2 grams). The wind conditions were terrible on the outdoor competition day, with 6 Bft, and most teams had their MAVs blown away. Everybody was impressed with how the hybrid UAVs were able to cope nicely with these conditions and were still able to perform a precision landing.
Read article →