PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Community

28 November 2010 · Piotr Esden-Tempski

Welcome to the all new Paparazzi UAV Blog
Hello everyone,

As the Paparazzi community is very active and getting bigger every day, we have decided that it is time to make a blog that reflects the thriving development and keeps everyone up to date. We hope to inform everyone about new features, challenges and plans.

Paparazzi is the only really Open-Source (hardware and software) UAV project in the world with proven capability and stability.

To support that statement we offer the following statistics:
Read article →

19 November 2010 · Piotr Esden-Tempski

We Moved To GIT

GithubThe paparazzi software repository now has a new happy life on github:

https://github.com/paparazzi/paparazzi

We believe the switch from Subversion to the fast git version control system will make development easier, faster and more fun. It also makes it easier for YOU to contribute. You can easily fork paparazzi on github, commit your bugfixes and new features and send us a pull request.

More info on how to get the paparazzi code from github can be found here.

Read article →

1 August 2010 · Felix Ruess

Code Refactor

OrganizedCodeAfter many years of development, so many new autopilot boards and aircraft types have been added that a sourcecode reorganization was needed. This undertaking is started and will simplify the continuous evolution of the project.

To benefit from these important changes, it only requires you to update your airframe configuration document once. After you have updated, you should not notice the significant reorganization that is going on behind the scenes. This change will benefit your aircrafts flying successfully for the years to come. The required changes are described on Update Your Airframe Configuration.

Read article →

9 July 2010 · paparazzi

IMAV 2010 Competition

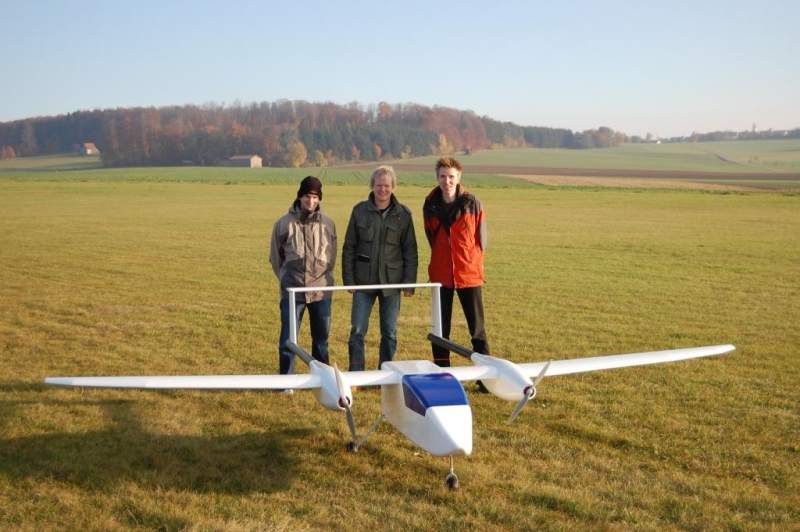
The IMAV 2010  International Micro Air Vehicles Conference and Flight Competition took place today in Braunschweig, Germany. The ENAC Paparazzi team took home 1st place for the outdoor
autonomy mission and 2nd place for the indoor flight dynamics
challenge. Both the indoor and the outdoor event consisted of two separate competitions, one focusing on high maneuverability, the other one focussing on the MAV’s ability to perform a complex
autonomous mission.

Read article →

22 May 2010 · paparazzi

Tragically We Lost Pascal Brisset

PascalTPSPascal Brisset, also known as Hecto, and the father of the Paparazzi project died in an accident while climbing in the Pyrénées mountains in the south of France. He had dedicated the last seven years of his life to the success of the project. He was taking care of a huge part of the project by himself. To name only a few : development and maintenance of the entire ground segment, navigation and flight plan algorithms, code generation and build system, distribution packaging, server infrastructure…

Read article →

30 September 2009 · paparazzi

Outback Challenge 2009

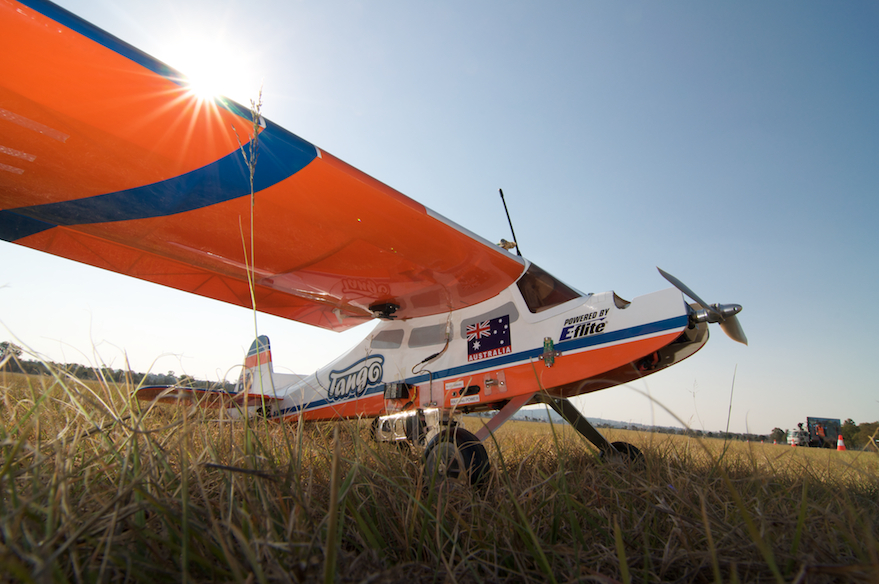
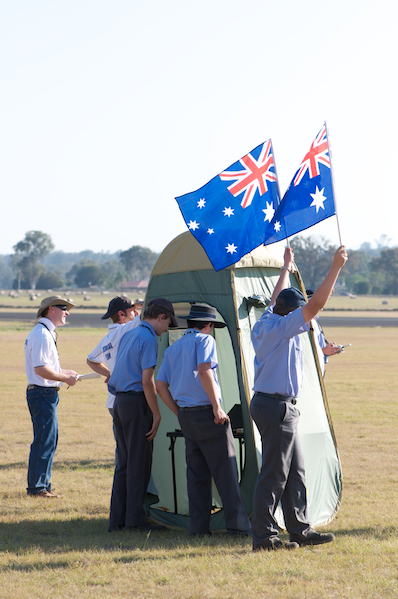
Brisbane Grammar School UAV Brisbane Grammar School UAV

Team “Look mAh, no hands!” signalling the UAV is in fully autonomous mode Team “Look mAh, no hands!” signalling the UAV is in fully autonomous mode

Paparazzi was a big success at the 2009 UAV Outback Challenge held at Kingaroy Airport, Queensland, Australia, Sep. 28-30. Team “Look mAh, no hands!” representing Brisbane Grammar School, won the ‘Robot Airborne Delivery Challenge’ placing 1st, after performing an autonomous mission phase including autonomous payload release. The team consisted of four members in their senior years of high-school, and was led by team captain Ben Paratz. Many thanks to the paparazzi community, not only for the autopilot itself but for the assistance that was enthusiastically given whenever needed. Link to competition

Read article →

15 September 2009 · paparazzi

EMAV 09 Results

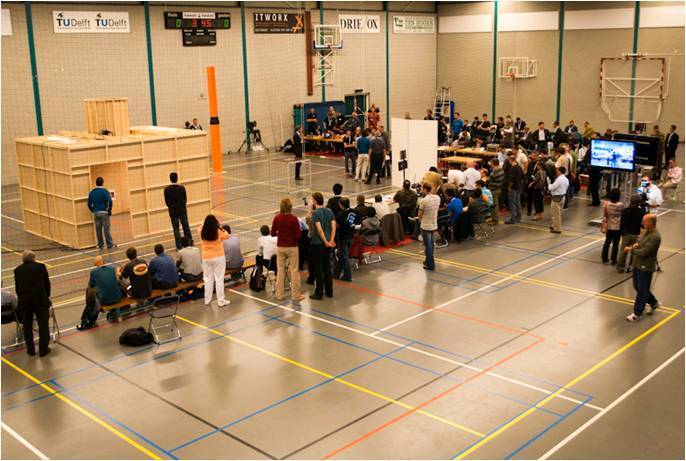
The EMAV09 competition took place in Delft, Netherlands. With Emav09ENAC’s Paparazzi team winning second place in the outdoor mission this year.

d91d22d039d685689a61bf04fdc5dc66.media.686x461

Read article →