We are now on Facebook
 If you are on Facebook you might be happy to hear that we now have a Paparazzi UAV Facebook page. Join us there and like our page. We hope this is another good way to follow along with the project and the community.
Research and development of open-source UAV systems since 2003
If you are on Facebook you might be happy to hear that we now have a Paparazzi UAV Facebook page. Join us there and like our page. We hope this is another good way to follow along with the project and the community.
Students at the TU Delft MavLab compete with ARDrones running Paparazzi to fly seamlessly around obstacles without injuring the aircraft. The object to autonomously avoid all obstacles. This is a fantastic demonstration of the flexibility of the Paparazzi system and its ability to fly accurately around waypoints.
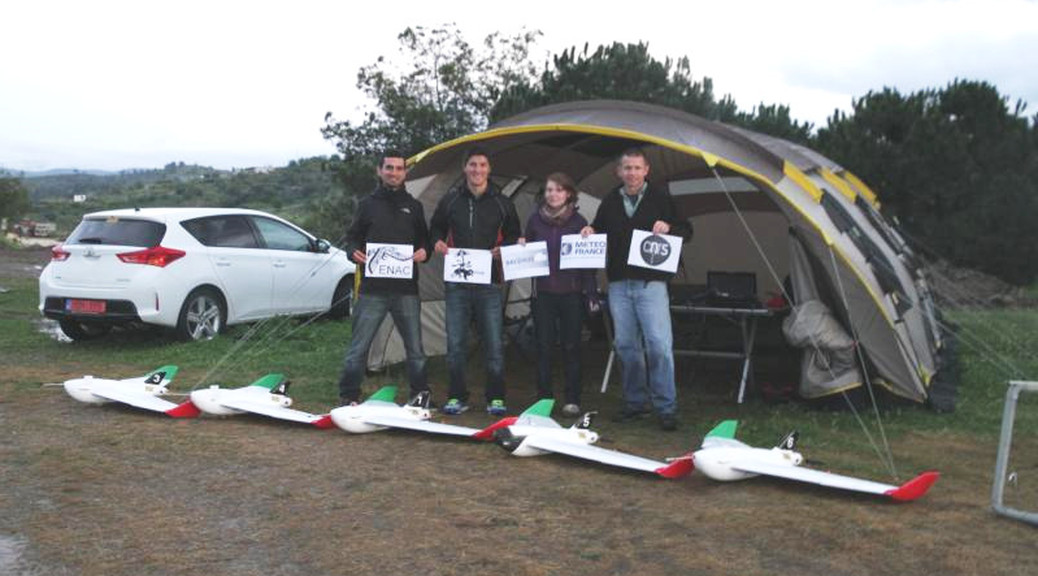 The National Center for Meteorological Research (CNRM-GAME, Toulouse, France) conducted an airborne experiment in Cyprus in March 2015 as part of the BACCHUS project. The main goal of CNRM’s contribution is to complement the ground-based observations of aerosol and cloud condensation nuclei with airborne measurements to characterize the vertical distribution of aerosol, radiative fluxes, 3D wind vectors and meteorological state parameters. As payloads were limited to 500g (and total weight < 2.5kg), multiple RPAS (remotely piloted aircraft systems) were instrumented for a specific scientific focus. The Paparazzi system was used to navigate the RPAS. During the campaign, airborne measurements were taken over 4 weeks (5 March to 2 April, 2015) with 52 research flights and 38 hours of flight time. Vertical profile were regularly sampled up to 2100 m.asl (limited by authorized flight ceiling) and often observed the layers of dust originating from the Arabian Peninsula and the Sahara Desert. RPAS profiles generally show a well-mixed boundary layer and compare well with ground-based LIDAR observations. Flights below and within clouds were also coordinated with satellite overpasses to perform ’top-down’ closure of cloud micro-physical properties.
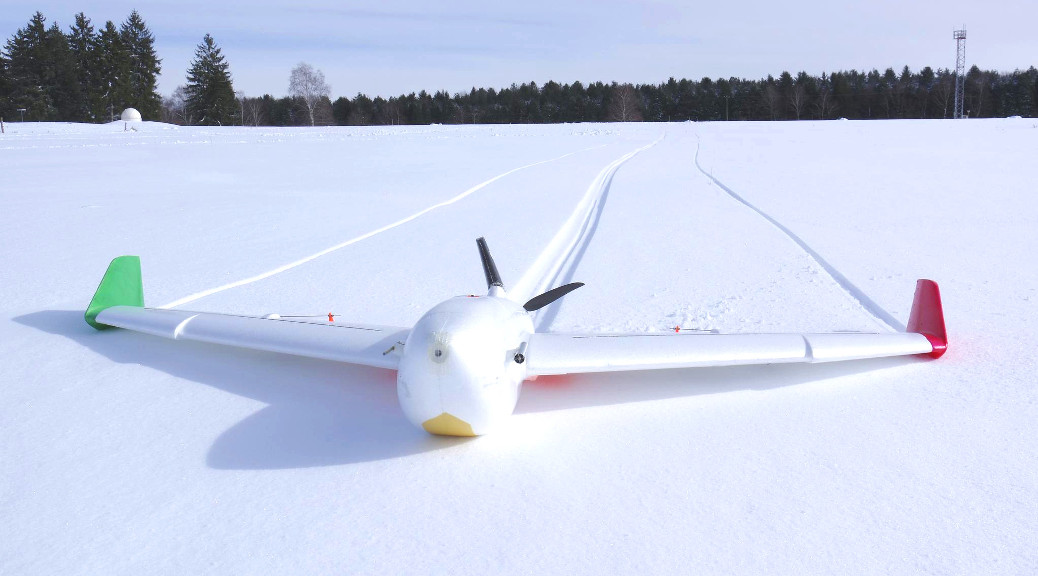 The ENAC team has been flying several aircraft (X6-Skywalker, Easystar, Funjet) at the Atmospheric Research Center of Lannemezan, close to the Pyrenees in the south of France. The goal was to prepare several meteorological planes for research studies held by Meteo France that will be held next month in Cyprus. Weather conditions were pretty harsh some times, with snow and icy fog, but also provided some really nice pictures, and of course interesting flights up to 1400m AGL with meteorological instruments.
 The Paparazzi Development Team is pleased to announce the release of a brand new version of Paparazzi; v5.4, giving you the option to enjoy lots of new features and improvements, happy new year!
If you’re curious to know what has been added and improved you can, go here for an overview. For your enjoyment and to view what all those changes look like, click here.
If you are already using paparazzi with Git, to enjoy all improvements you can switch to this new version via:
Great BBC interview with Bart Remes, head of the Mavlab at TU Delft. Bart shows off the Lisa/S Nano Quadcopter and comments on the usefulness and safety of sub-miniature UAV.
 As you know paparazzi is a very modular platform. To show the world how modular we are, we worked hard on implementing paparazzi into the Parrot Bebop. At the Micro Aerial Vehicle Laboratory (MAVLab) of Delft University of Technology faculty Aerospace engineering (TU Delft) we received a pre-production model of the Bebop. We did our best to have paparazzi integrated before the launch of the Bebop. If you want to follow the progress check our (youtube channel).
IMAV 2014 was a great experience this year. If you don’t know what it is, its a micro air vehicle competition and conference that was held in Delft, Netherlands.
During the three days of the conference, there were many very interesting talks and presentations as well as an incredible showcase of research talent during the competition. Here is a playlist of the talks, they can be found on the TU Delft MAVlab YouTube channel.
 The Micro Aerial Vehicle Laboratory (MAVLab) of Delft University of Technology (TU Delft) is proud the present the 2014 International Micro Air Vehicle Conference (IMAV 2014), now offering the possibility of attending the conference by live stream free-of-cost. The live stream will support most platforms showing innovative keynotes of pioneers in the industry as well as the current state-of-the-art presented by many researchers working on MAV’s. The schedule is published on the website of the conference.
Tuesday, August 12th, 2014
Paparazzi  UAV and 1BitSquared will be attending this years DefCon 22 in Las Vegas, Nevada. It takes place from August 7th through 10th, 2014.
We will be at the Hak5 vendor booth, with Lisa/S autopilots, Black Magic Probe, Nano Quad kits and more. Please come by and say hi!