PAPARAZZI UAV BLOG

Research and development of open-source UAV systems since 2003

Community

1 March 2016 · Bart Remes

Paparazzi UAV on Pixhawk teaser

Hi all Open-Source enthusiasts,

Today we are happy to announce we’ll be adding an extra autopilot board to there long list of supported autopilots.

The Pixhawk autopilot board will be integrated in our next software release! The video shows the first flight with Paparazzi UAV on a Pixhawk, more videos will follow.

Why choose Paparazzi UAV?

If you are looking for an advanced, modular open-source autopilot which has features others can only dream of, you choose Paparazzi UAV.
Read article →

12 January 2016 · Piotr Esden-Tempski

1BitSquared launches German Store

1BitSquared has just launched their German online store. This is the first dedicated Paparazzi UAV hardware supplier in Europe.

With a store in Europe they can provide faster delivery times of Paparazzi UAV hardware for all the European users and developers. Now you can purchase Lisa/M(X), Lisa/S, Elle0 autopilots and accessories for Paparazzi UAV within Europe without having to pick up your order at your customs office. We hope this will make the entry into Paparazzi and working with the system easier, knowing that you can get new parts and hardware faster from a local supplier.

Read article →

6 January 2016 · Danika Esden-Tempski

Wiki Front Page Update

With the coming of the new year we decided it was time for a refresh of the appearance of the Wiki front page. Stripping away its colorful design and removing the boxes around text we thought it would help make the information cleaner and easier to read. We have added new icons to help clarify how you can best connect with the community and where to find what you need.

We hope people like the new look of the Wiki and find navigating it to be an easier experience, as always new contributions are welcome. Happy flying everyone!

Read article →

4 January 2016 · Piotr Esden-Tempski

Paparazzi UAV at 32C3 Recap

IMG_3320Here is a short review of our Paparazzi UAV meet up at the 32C3.

For those of you who have never heard of the Chaos Communication Congress, it is a hacker conference that takes place every year between Christmas and New Year’s Eve in Germany. For many years it was held in Berlin, but with the increased attendance a larger venue was needed, it is now being held in Hamburg, Germany.

Most people arrive in Hamburg on the 26th of December for day 0 of the conference. We met our assembly in the large Hackcenter hall. EZ who helped organize lodging for a lot of us also found and reserved tables for us. Usually it was the CCC organizers who were reserving the tables for the so called Assemblies. This time they did not do that for any Assembly with less than a 100 members. This shows how big the event is getting.

Read article →

15 December 2015 · Piotr Esden-Tempski

Lisa/S Nano Quadcopter featured on sUAS News

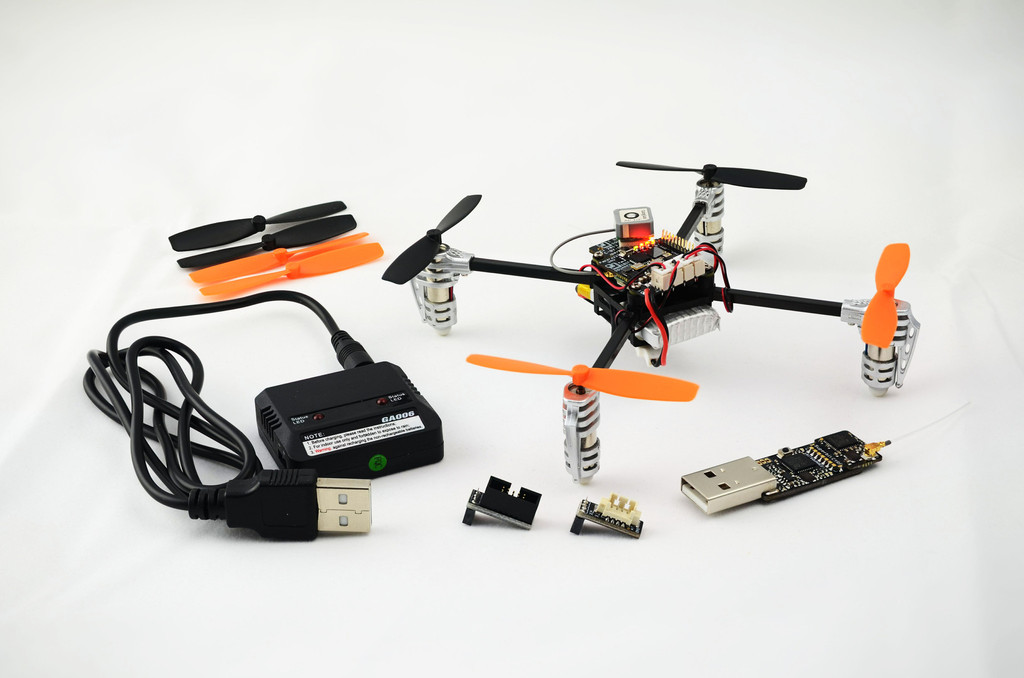
LadyLisa_Assembled_Kit_5_adjusted_1024x1024In the light of the recent FAA registration limits, the great guys at sUAS News wrote an article featuring the Paparazzi UAV powered Lisa/S nano Quadcopter. This platform was developed by 1BitSquared in collaboration with the TU-Delft MAV lab team, provides all the autonomous capabilities while being way below the FAA regulated limits for registration. The Lisa/S nano Quadcopter weighs only 39g while the FAA requires all aircraft above 250g to be registred.

Read article →

4 December 2015 · Gautier Hattenberger

Multi-UAV flights for simultaneous meteorological measurements

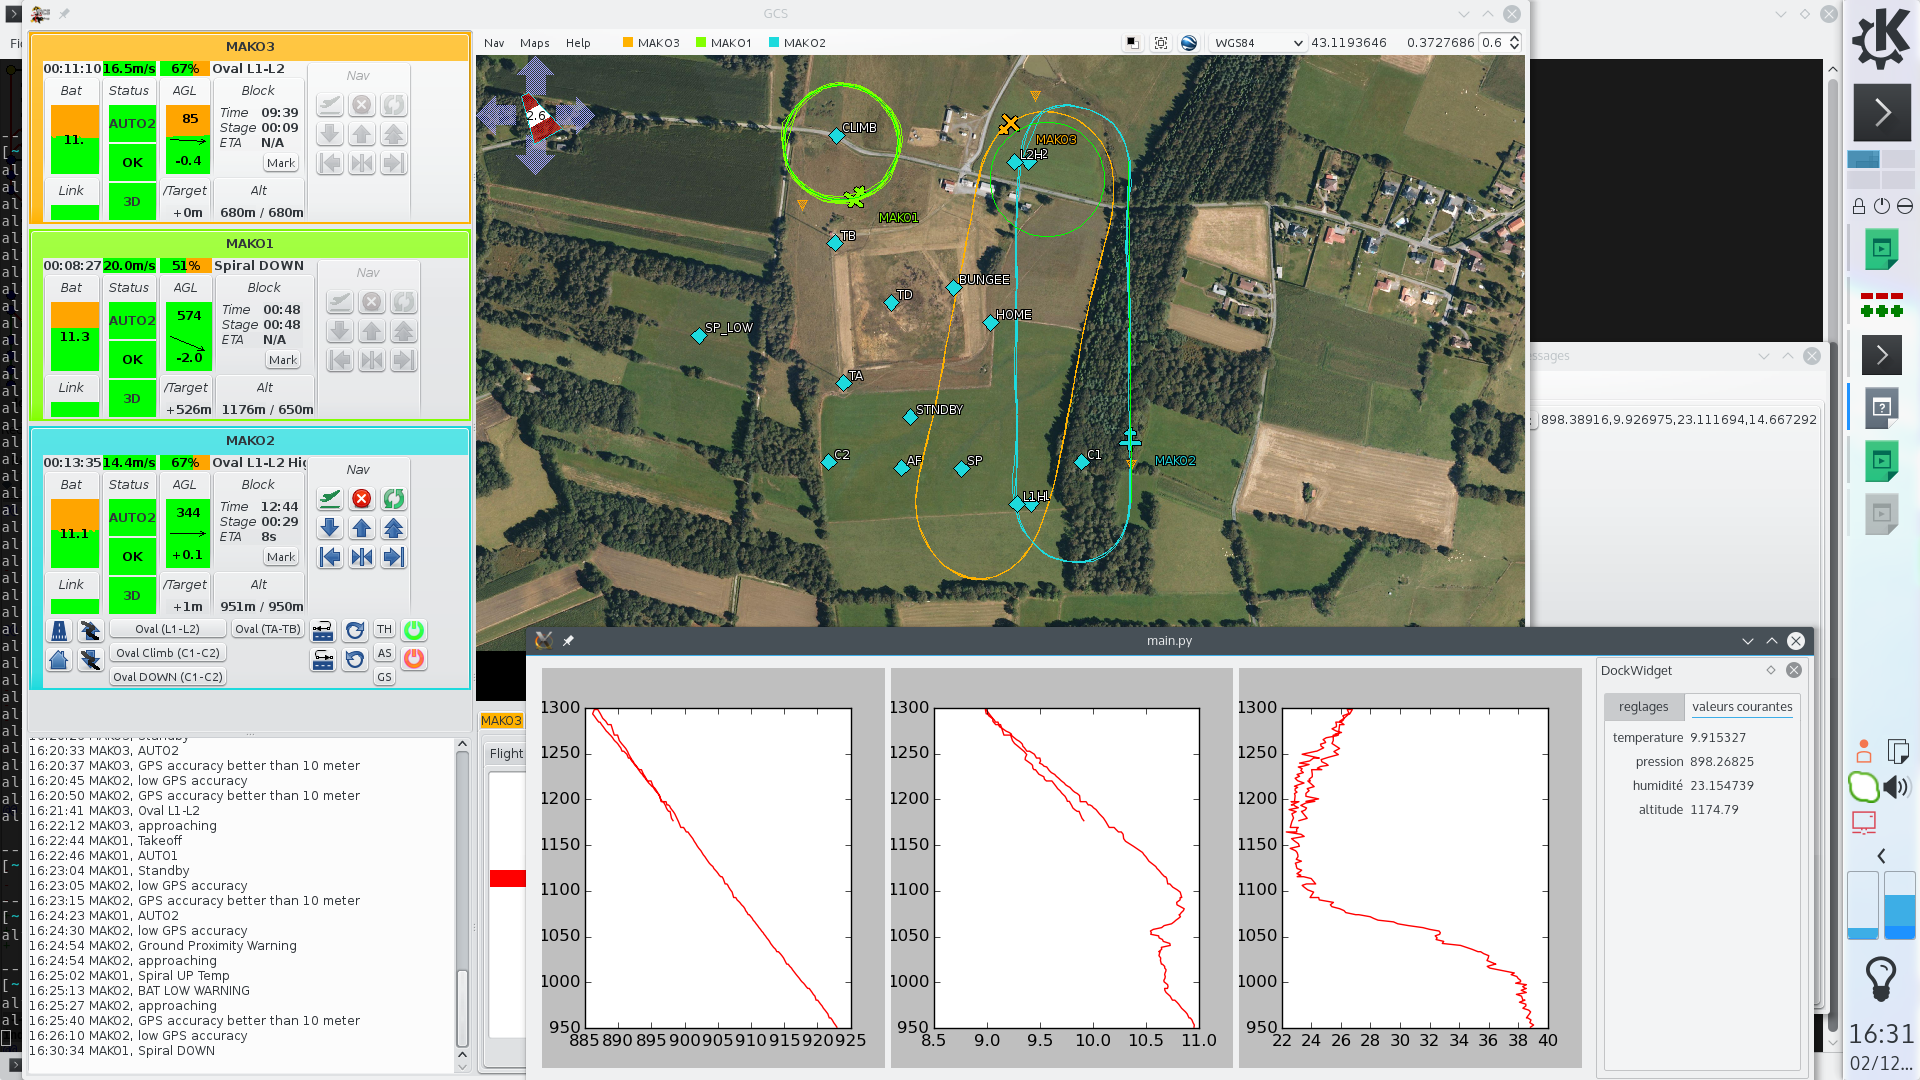
ENAC UAV Lab team and Meteo-France (CNRS-GAME and ENM) teams have spent several days at the Atmospheric Research Center of Lannemezan (in the south of France) in order to perform experiments for simultaneous meteorological measurements through multi-UAV flight.

This was part of a research project called VOLTIGE aimed at studying the formation of cloud and fog events. One of the planes is measuring the turbulence near the ground, a second plane is flying above the cloud or the fog with a radiation sensor and the last one is making a vertical profile of temperature, pressure and humidity up to 1500 meters AGL.GCS screenshot multi-uav

Read article →

1 December 2015 · Piotr Esden-Tempski

Elle0 Autopilot

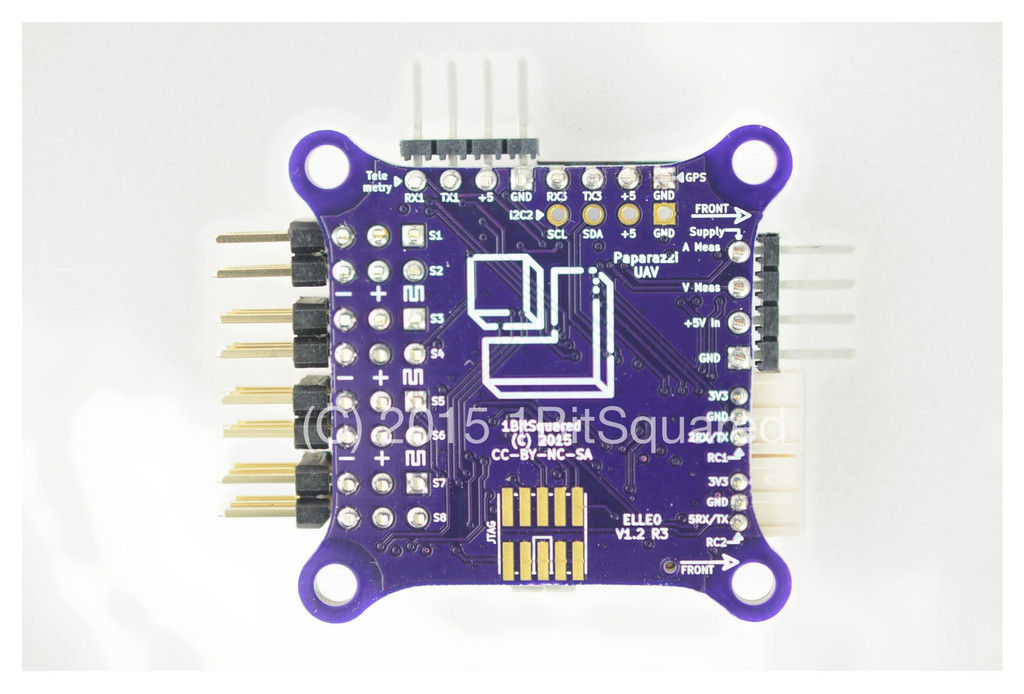
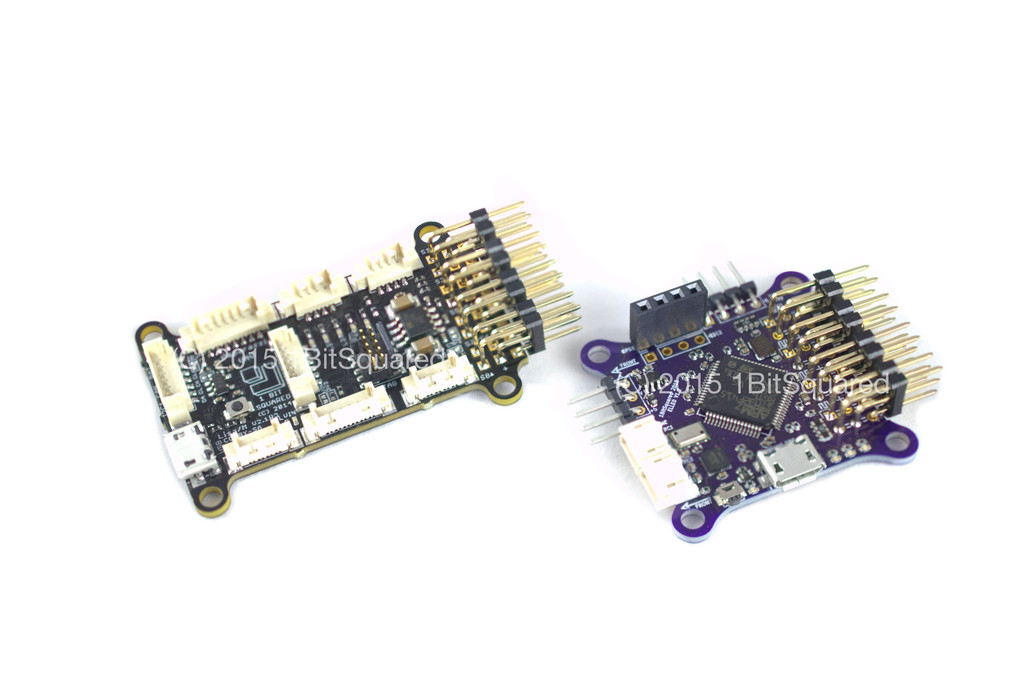
Elle0-in-hand-watermark_1024x1024Elle0-back-watermark_1024x10241BitSquared has released Elle0, a new Paparazzi UAV autopilot. Elle0 is the lowest cost autopilot developed specifically for use with the Paparazzi UAV framework. It was inspired by the Lisa/MX and Apogee autopilots and has been stripped down to the most essential features while preserving the flexibility that Paparazzi autopilots are famous for.

Here are some of the specs:

  • STM32F4 168MHz ARM Cortex-M4 microcontroller with FPU
    • 1 Mbyte of Flash memory
    • 192+4 Kbytes of SRAM including 64-Kbyte of CCM (core coupled memory) data RAM
    • Cryptographic acceleration: hardware acceleration for AES 128, 192, 256, Triple DES, HASH (MD5, SHA-1), and HMAC
    • True random number generator
  • 3 axis gyroscope (connected over SPI for high speed sampling and low latency)
  • 3 axis accelerometer (connected over SPI for high speed sampling and low latency)
  • 3 axis magnetometer (connected over SPI for high speed sampling and low latency)
  • barometer (connected over dedicated SPI for low noise operation and low latency)
  • 1 I2C auxilary sensor connection
  • 2 TTL level serial ports for telemetry radio and GPS
  • 2 serial input interfaces for remote control receivers (using Spektrum compatible JST connectors)
  • 1 USB port for easy firmware upgrade
  • 8 PWM outputs/inputs for servos or legacy PPM RC receivers
  • 2 Analog inputs for system battery voltage and current measurement
  • CAN TX and RX lines are accessible

Elle0-LisaMX-angle-watermark_1024x1024Mechanically Elle0 is designed around the 30.5mm M3 hole pattern, popularized by the Nano Quad community. But Elle0 can be used on more than just Nano Quads, it has everything on board to control anything from a small Quad through a big Octocopter to Airplanes or Helicopters. For an autonomous UAV you just need to add a GPS, Telemetry radio and maybe RC receivers. ;)

Read article →

19 November 2015 · Piotr Esden-Tempski

Parrot Bebop 2 Support

screen-shot-2015-11-17-at-2-44-14-pm-pngParrot has released their new Bebop 2 camera quadcopter. Paparazzi UAV already has support for that new platform.

screen-shot-2015-11-17-at-2-43-39-pm-png Thanks to the great work of the TU-Delft MavLab team and especially Freek van Tienen it is possible to replace the stock functionality of the Parrot Bebop 2 with Paparazzi UAV.

This change gives the platform a lot of autonomous flight enhancements like dynamic flight plans, as well as improved stabilization algorithms like the INDI controller.

Read article →

19 October 2015 · paparazzi

BACCHUS Meteorological Project

BACCHUS Research GroupResearchers from the GMEI/MNPCA have recently returned from a one month field measurement campaign at the weather
station of Mace Head in Ireland. Their report was very positive with more than forty scientific flights, up to 3350m above sea level, some of them synchronized with a
meteorological satellite overpass, for the study of interactions between clouds and aerosols. Several unmanned aircraft, equipped with the Paparazzi UAV
systems, have been used, carrying meteorological, aerosol, cloud and 3D wind sensors. A bungee was used for taking-off, while a big net was needed in
order to recover the planes, since the ground was not suitable for traditional landings. This campaign was part of the BACCHUS project (Impact of
Biogenic versus Anthropogenic emissions on Clouds and Climate: towards a Holistic UnderStanding).

Read article →